Mobile robot trajectory tracking using noisy RSS measurements: an RFID approach
Related Experiment Video
Updated: May 5, 2026
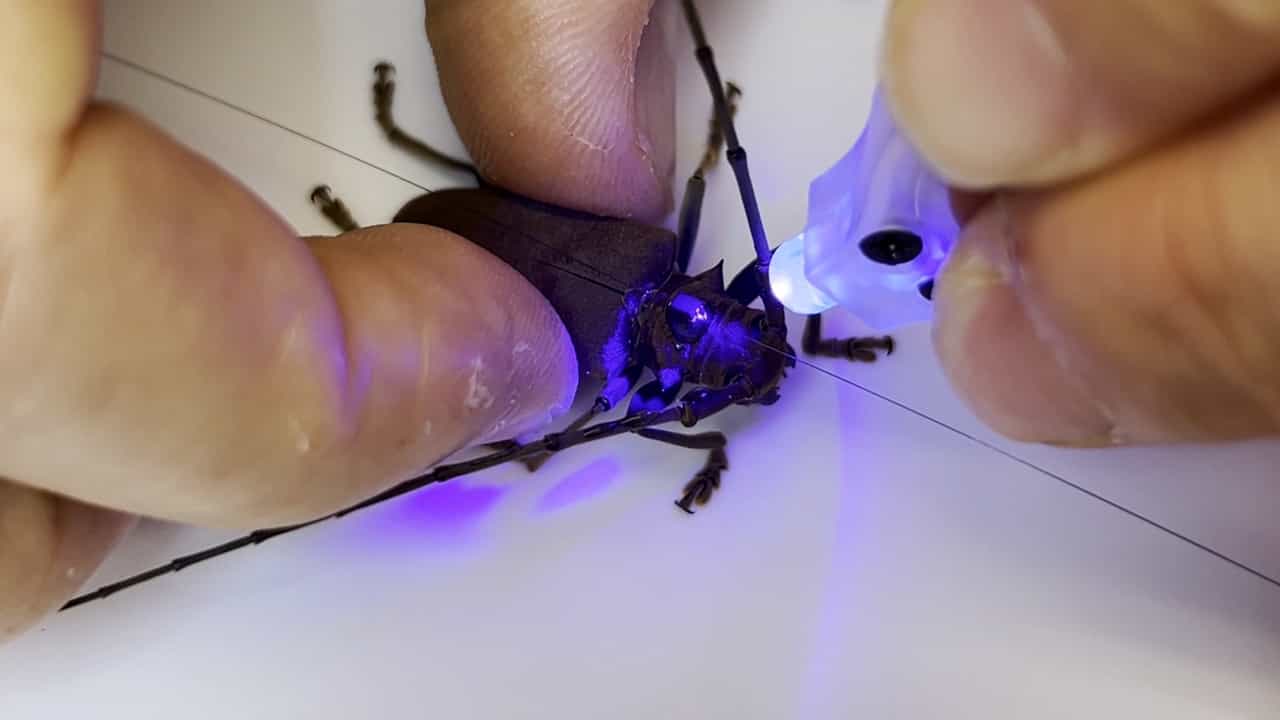
Harmonic Radar Tags for Insect Tracking: Lightweight, Low-cost, and Accessible
Published on: May 13, 2025
1Machine Intelligence, Robotics, and Mechatronics Laboratory, School of Electrical Engineering and Computer Science, University of Ottawa, Ontario, Canada.

Abstract:
Most RF beacons-based mobile robot navigation techniques rely on approximating line-of-sight (LOS) distances between the beacons and the robot. This is mostly performed using the robot's received signal strength (RSS) measurements from the beacons. However, accurate mapping between the RSS measurements and the LOS distance is almost impossible to achieve in reverberant environments. This paper presents a partially-observed feedback controller for a wheeled mobile robot where the feedback signal is in the form of noisy RSS measurements emitted from radio frequency identification (RFID) tags. The proposed controller requires neither an accurate mapping between the LOS distance and the RSS measurements, nor the linearization of the robot model. The controller performance is demonstrated through numerical simulations and real-time experiments.