Related Experiment Video
Updated: May 4, 2026

An Experimental Platform to Study the Closed-loop Performance of Brain-machine Interfaces
Published on: March 10, 2011
A fast closed-loop process dynamics characterization
Miroslav R Mataušek1, Tomislav B Šekara1
1Faculty of Electrical Engineering, University of Belgrade, Belgrade 11120, Serbia.

Abstract:
Stable, integrating and unstable processes, including dead-time, are analyzed in the loop with a known PI/PID controller. The ultimate gain and frequency of an unknown process G(p)(s), and the angle of tangent to the Nyquist curve G(p)(iω) at the ultimate frequency, are determined from the estimated Laplace transform of the set-point step response of amplitude r0. Gain G(p)(0) is determined from the measurements of the control variable and known r0. These estimates define a control relevant model G(m)(s), making possible the use of the previously determined and memorized look-up tables to obtain PID controller guaranteeing desired maximum sensitivity and desired sensitivity to measurement noise. Simulation and experimental results, from a laboratory thermal plant, are used to demonstrate the effectiveness and merits of the proposed method.

Related Concept Videos
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:21
Control System Problem
When forming a closed-loop system, issues can arise if the poles cross into the unstable region, leading to potential...
 01:20
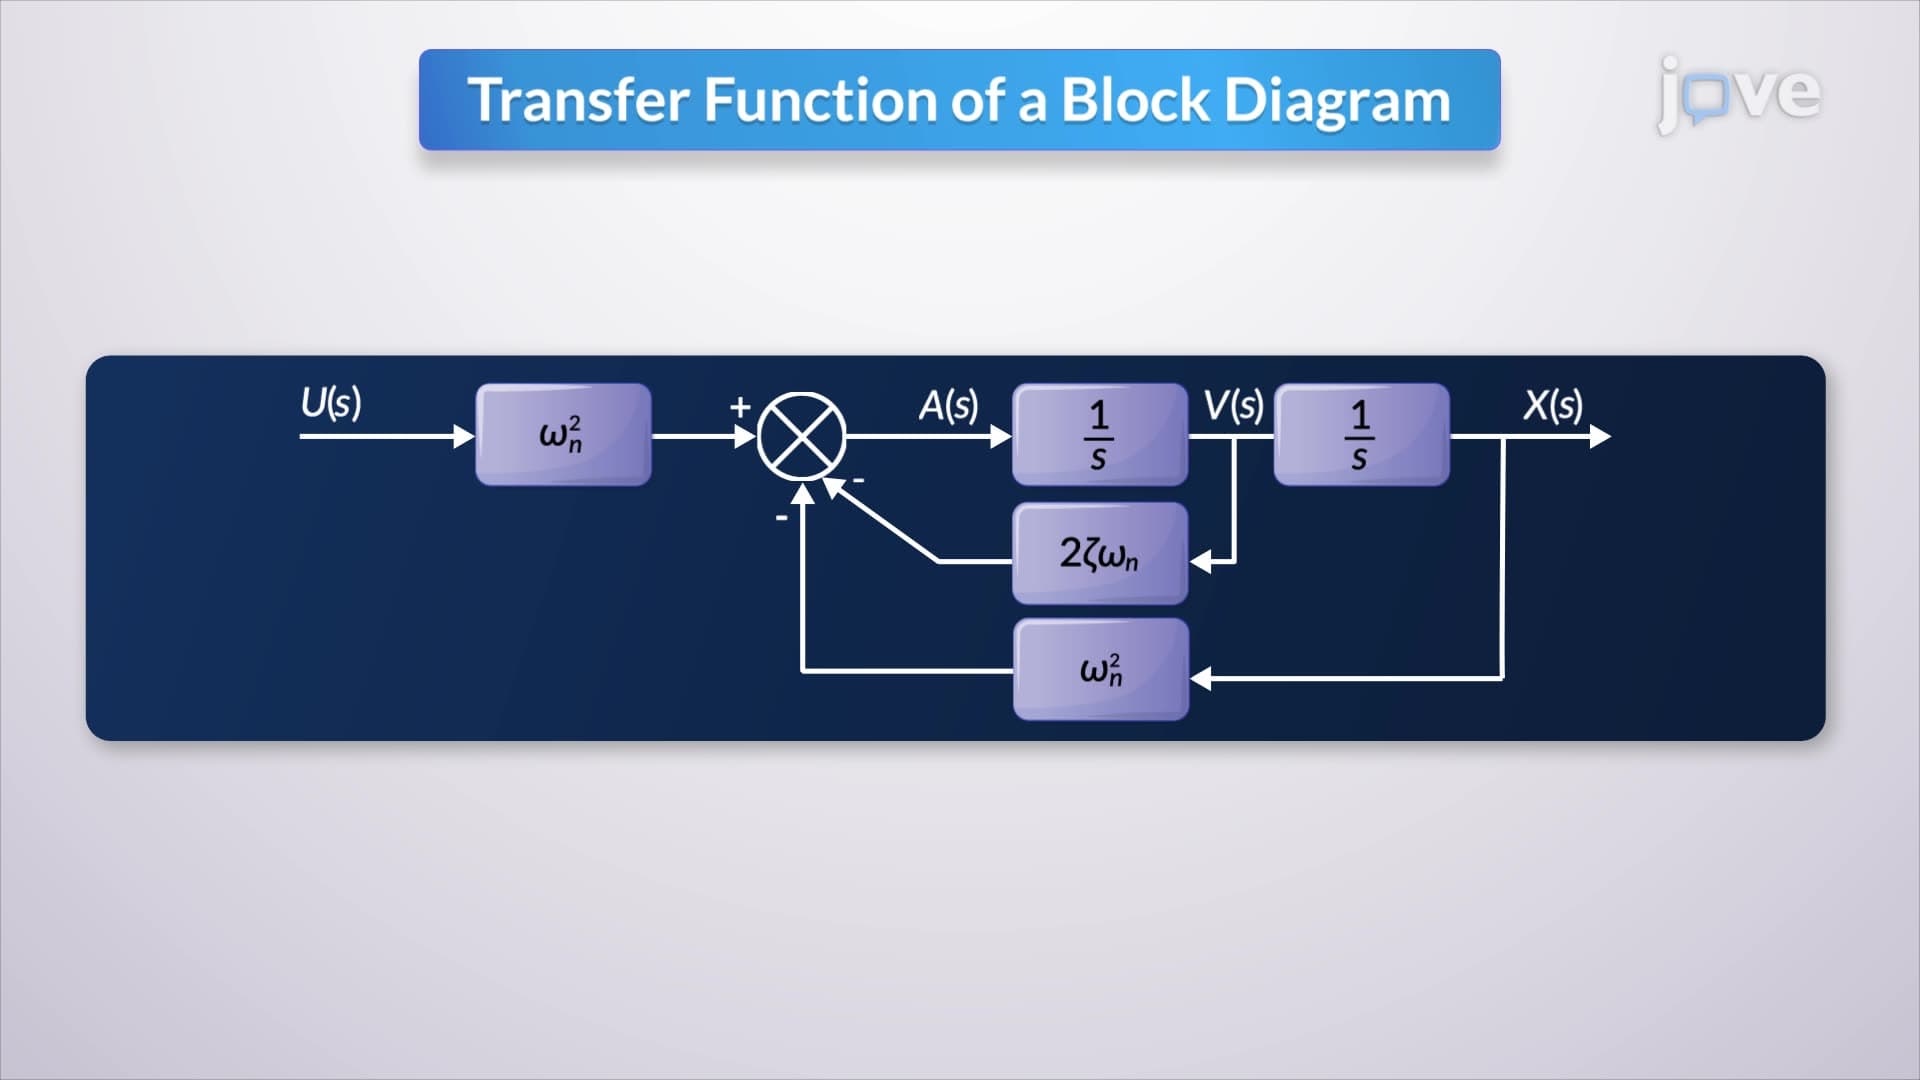
Relation between Mathematical Equations and Block Diagrams
 01:20
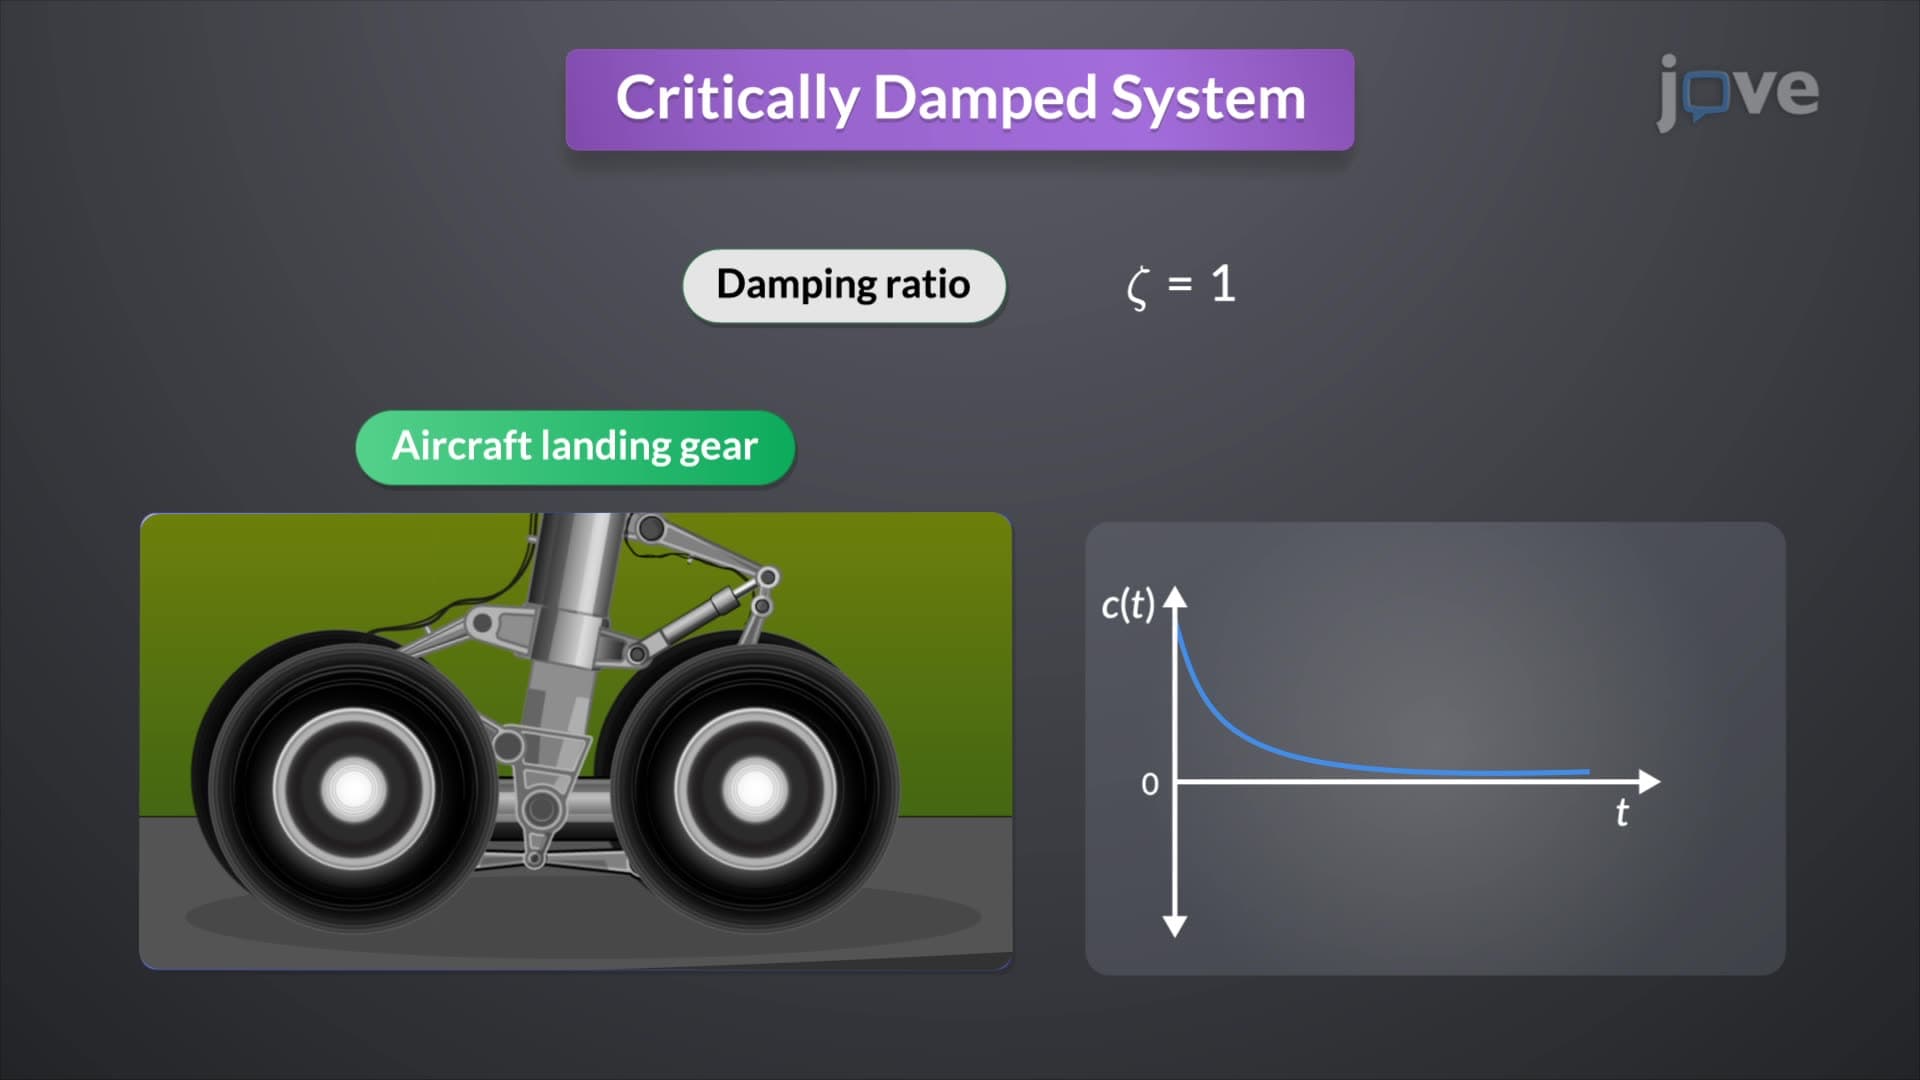
Second Order systems I
By reinterpreting the system, one can derive the closed-loop transfer function, which...
 01:18
Second Order systems II
 01:21
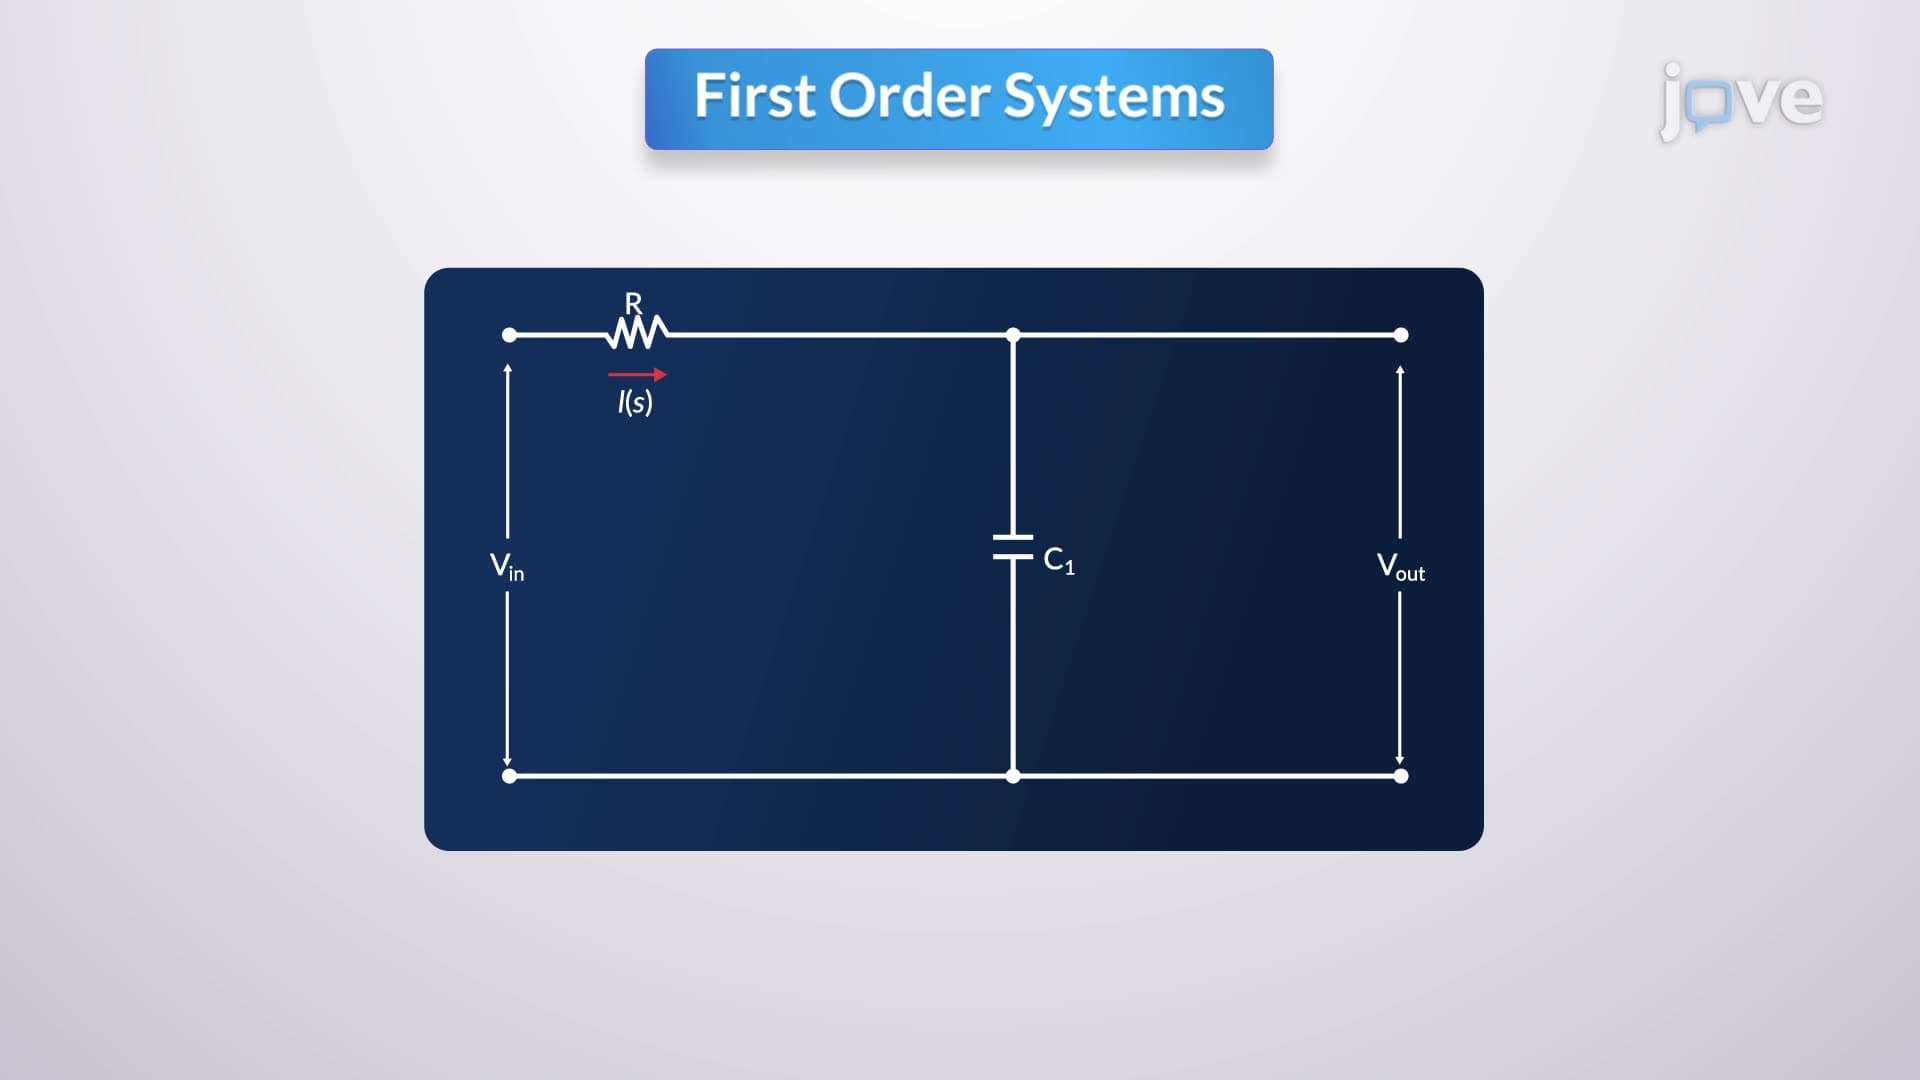
First Order Systems
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...