Related Experiment Video
Updated: Mar 17, 2026

Capturing Dynamic Finger Gesturing with High-resolution Surface Electromyography and Computer Vision
Published on: March 28, 2025
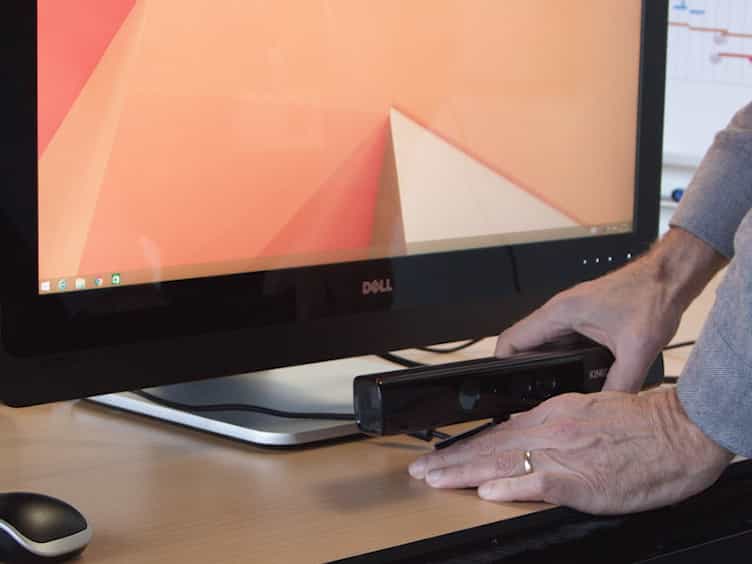
Human Arm Motion Tracking by Orientation-Based Fusion of Inertial Sensors and Kinect Using Unscented Kalman Filter

Abstract:
Due to various applications of human motion capture techniques, developing low-cost methods that would be applicable in nonlaboratory environments is under consideration. MEMS inertial sensors and Kinect are two low-cost devices that can be utilized in home-based motion capture systems, e.g., home-based rehabilitation. In this work, an unscented Kalman filter approach was developed based on the complementary properties of Kinect and the inertial sensors to fuse the orientation data of these two devices for human arm motion tracking during both stationary shoulder joint position and human body movement. A new measurement model of the fusion algorithm was obtained that can compensate for the inertial sensors drift problem in high dynamic motions and also joints occlusion in Kinect. The efficiency of the proposed algorithm was evaluated by an optical motion tracker system. The errors were reduced by almost 50% compared to cases when either inertial sensor or Kinect measurements were utilized.
More Related Videos
Related Concept Videos
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
 01:10
Relative Motion Analysis - Acceleration
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...