Predictor-based control for an inverted pendulum subject to networked time delay
Related Experiment Video
Updated: Mar 8, 2026
Author Spotlight: Enhancing Engineering Education via WebVR-Based Online Laboratories
Published on: February 23, 2024

Abstract:
The inverted pendulum is considered as a special class of underactuated mechanical systems with two degrees of freedom and a single control input. This mechanical configuration allows to transform the underactuated system into a nonlinear system that is referred to as the normal form, whose control design techniques for stabilization are well known. In the presence of time delays, these control techniques may result in inadequate behavior and may even cause finite escape time in the controlled system. In this paper, a constructive method is presented to design a controller for an inverted pendulum characterized by a time-delayed balance control. First, the partial feedback linearization control for the inverted pendulum is modified and coupled with a state predictor to compensate for the delay. Several coordinate transformations are processed to transform the estimated partial linearized system into an upper-triangular form. Second, nested saturation and backstepping techniques are combined to derive the control law of the transformed system that would complete the design of the whole control input. The effectiveness of the proposed technique is illustrated by numerical simulations.
Related Concept Videos
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:10
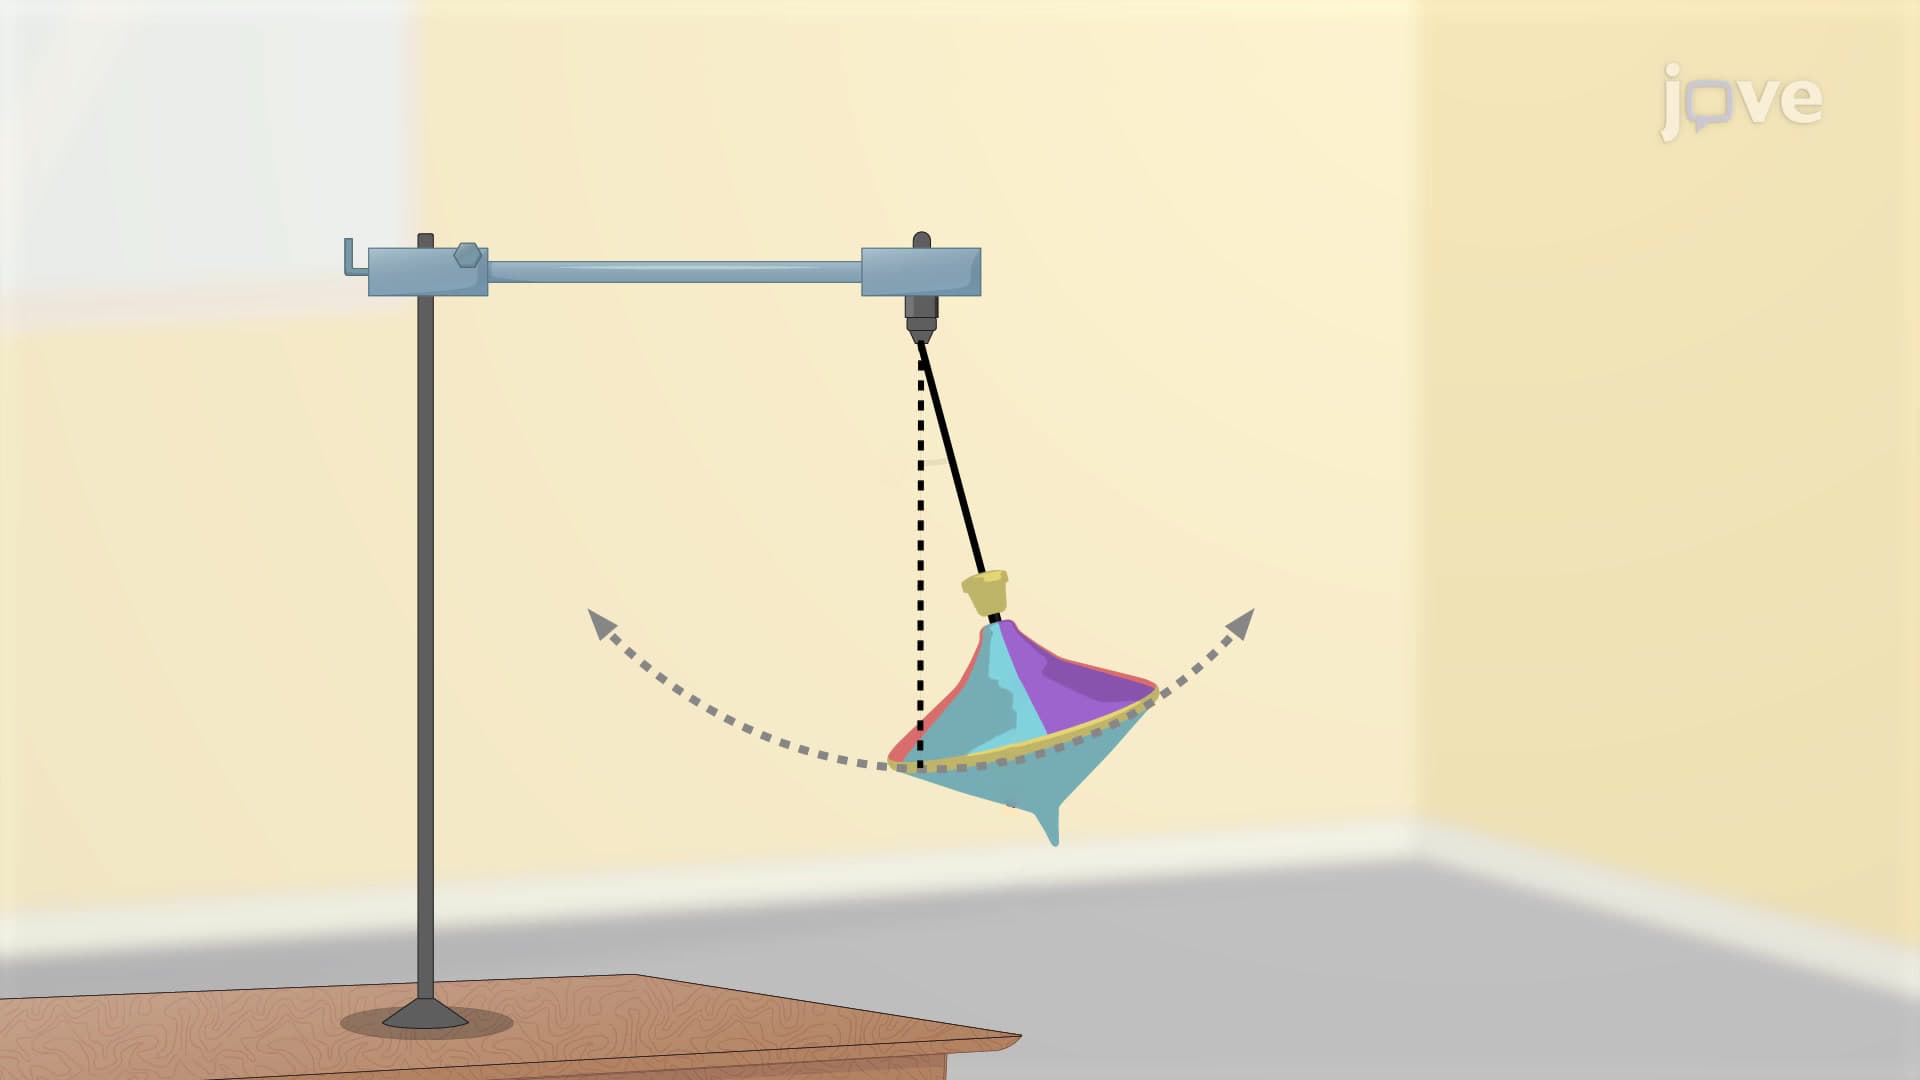
Simple Pendulum
The period of a simple pendulum depends on two factors: its length and the acceleration due to gravity. The period is completely independent of any other factors, such as mass or maximum displacement. For small displacements, a pendulum is...
 01:06
Physical Pendulum
When dealing with complicated systems, the mass moment of inertia is an important parameter, as it...
 01:09
Torsional Pendulum
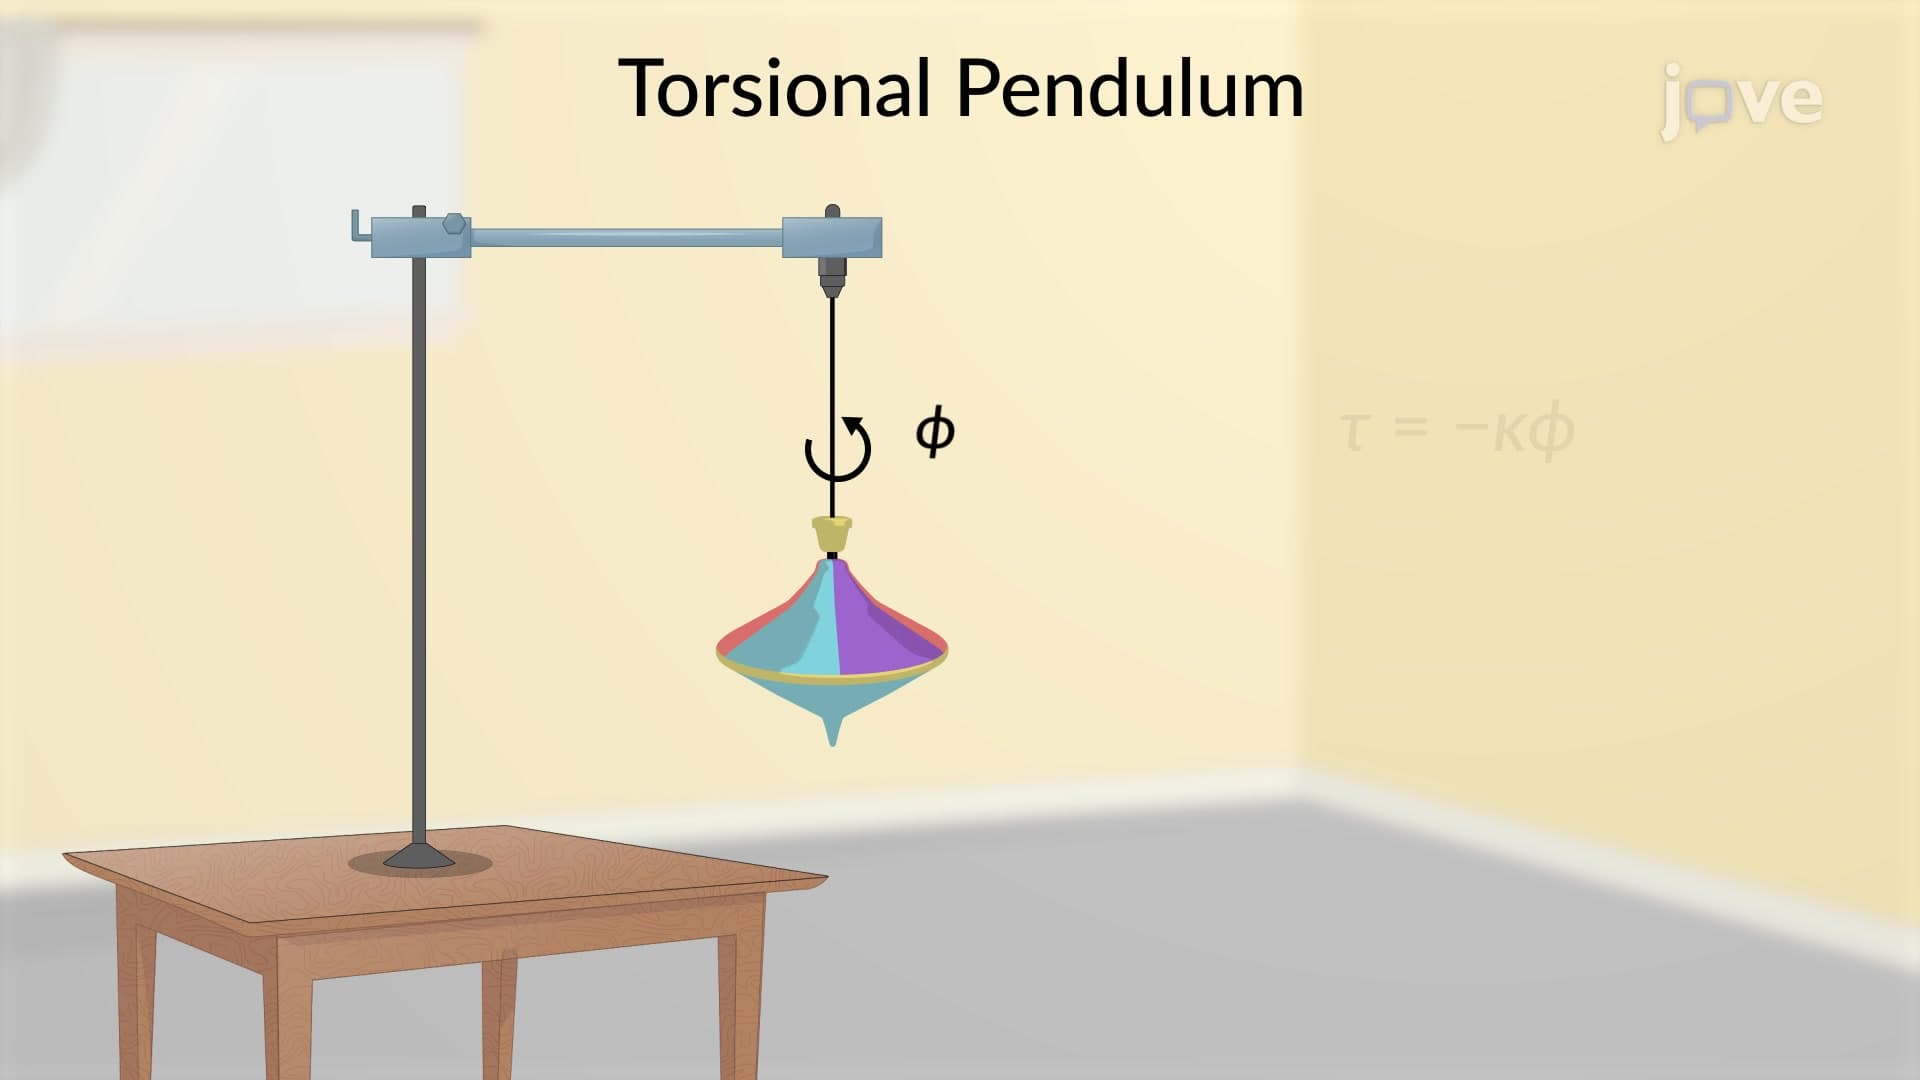
As long as the rigid body's angular displacement is small, its oscillation can be modeled as a linear angular oscillation. The amplitude of the oscillation is an angle. The role of mass is played...
 01:28
Stability
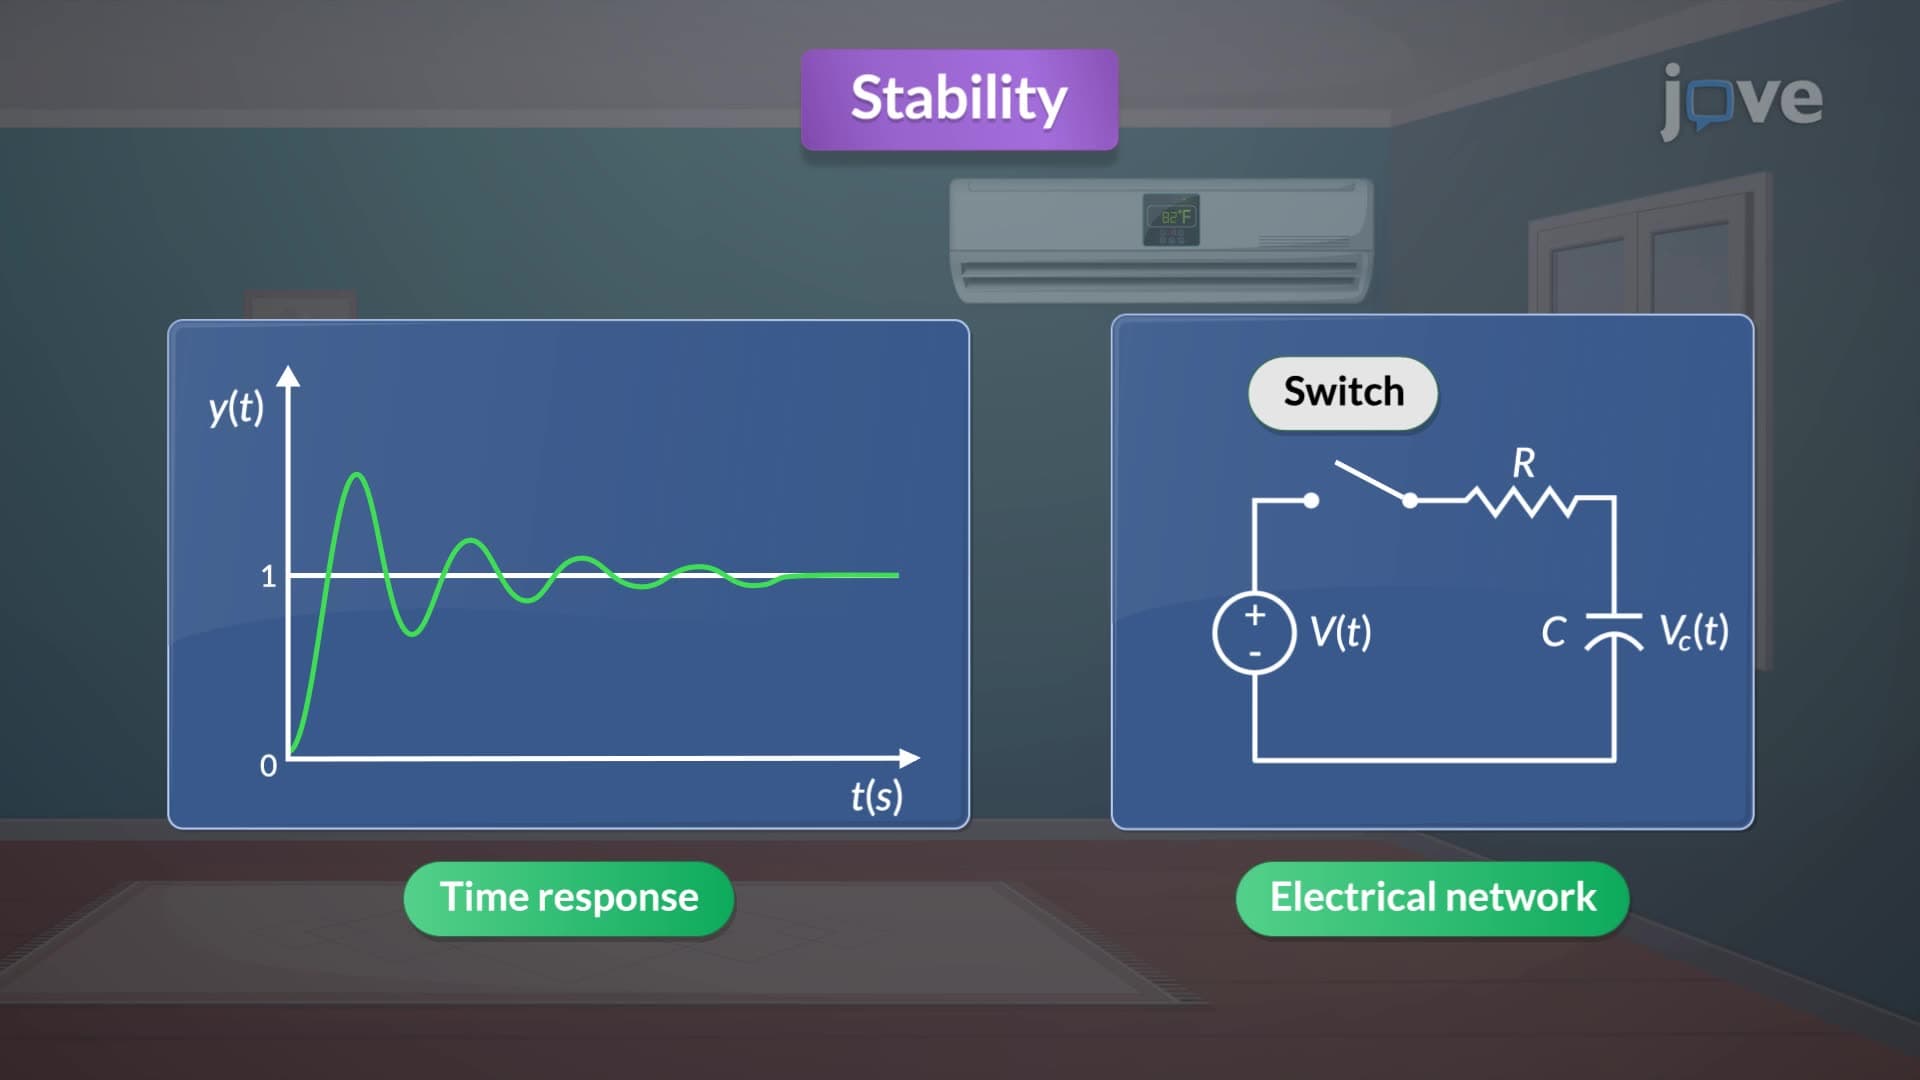
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...