Outdoor flocking of quadcopter drones with decentralized model predictive control
Related Experiment Video
Updated: Feb 26, 2026
Electroantennography-based Bio-hybrid Odor-detecting Drone using Silkmoth Antennae for Odor Source Localization
Published on: August 27, 2021
Quan Yuan1, Jingyuan Zhan1, Xiang Li1
1Adaptive Networks and Control Lab, Department of Electronics Engineering, Fudan University, Shanghai 200433, China; Research Center of Smart Networks and Systems, School of Information Science and Engineering, Fudan University, Shanghai 200433, China.

Abstract:
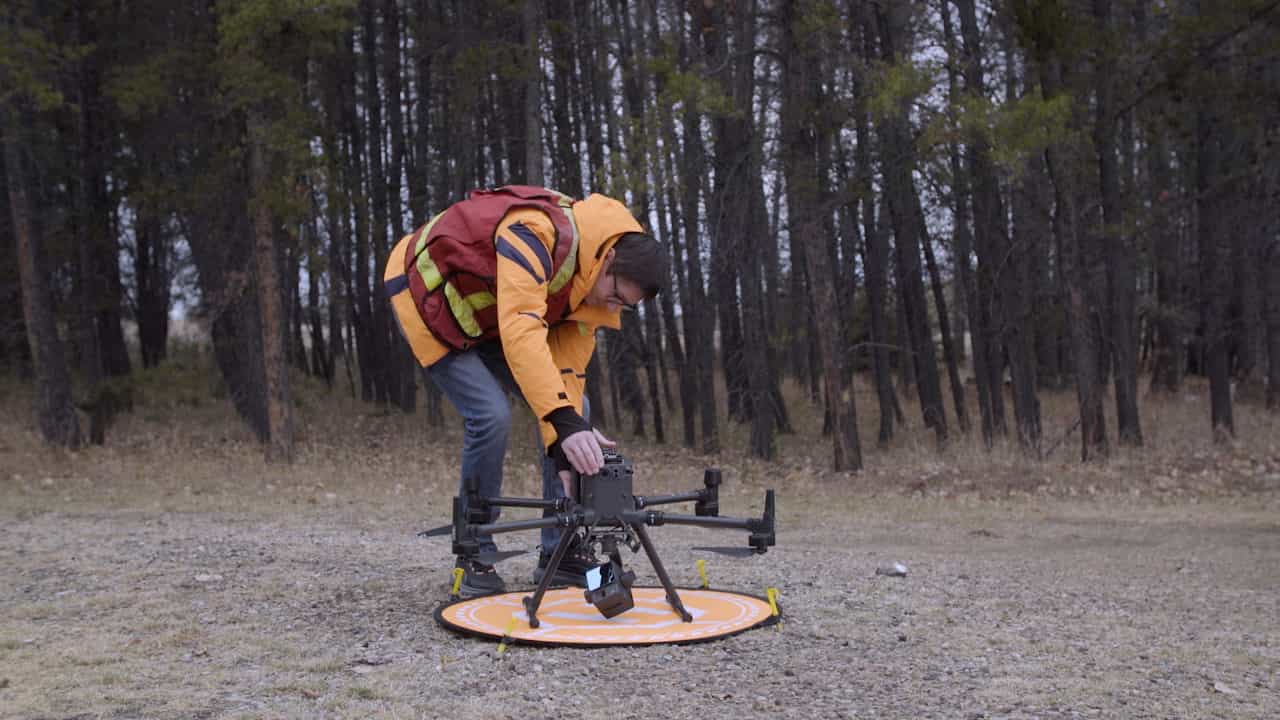
In this paper, we present a multi-drone system featured with a decentralized model predictive control (DMPC) flocking algorithm. The drones gather localized information from neighbors and update their velocities using the DMPC flocking algorithm. In the multi-drone system, data packages are transmitted through XBee® wireless modules in broadcast mode, yielding such an anonymous and decentralized system where all the calculations and controls are completed on an onboard minicomputer of each drone. Each drone is a double-layered agent system with the coordination layer running multi-drone flocking algorithms and the flight control layer navigating the drone, and the final formation of the flock relies on both the communication range and the desired inter-drone distance. We give both numerical simulations and field tests with a flock of five drones, showing that the DMPC flocking algorithm performs well on the presented multi-drone system in both the convergence rate and the ability of tracking a desired path.
Related Concept Videos
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:19
PID Controller
 01:24
Fast Decoupled and DC Powerflow
 01:24
PI Controller: Design
 01:29
Application of Linearization and Approximation
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...