Related Experiment Video
Updated: Feb 21, 2026
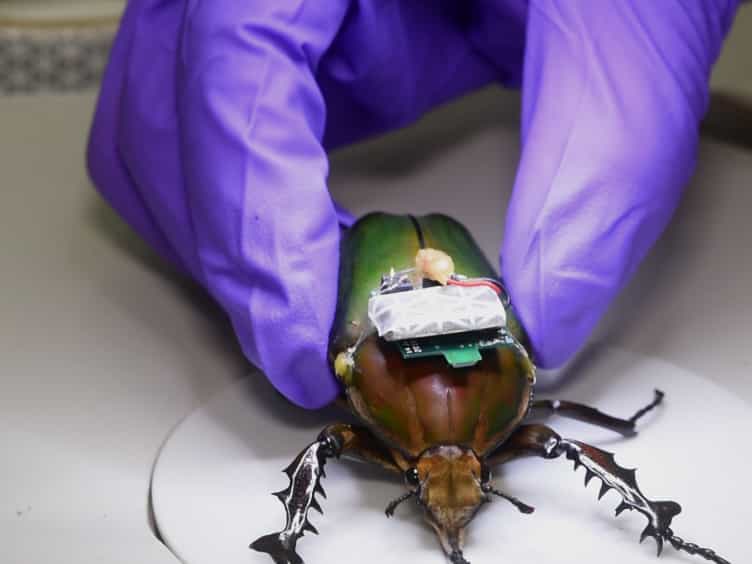
Insect-machine Hybrid System: Remote Radio Control of a Freely Flying Beetle Mercynorrhina torquata
Published on: September 2, 2016
Head movements quadruple the range of speeds encoded by the insect motion vision system in hawkmoths
Shane P Windsor1, Graham K Taylor2
1Department of Aerospace Engineering, University of Bristol, University Walk, Bristol BS8 1TR, UK.

Abstract:
Flying insects use compensatory head movements to stabilize gaze. Like other optokinetic responses, these movements can reduce image displacement, motion and misalignment, and simplify the optic flow field. Because gaze is imperfectly stabilized in insects, we hypothesized that compensatory head movements serve to extend the range of velocities of self-motion that the visual system encodes. We tested this by measuring head movements in hawkmoths Hyles lineata responding to full-field visual stimuli of differing oscillation amplitudes, oscillation frequencies and spatial frequencies. We used frequency-domain system identification techniques to characterize the head's roll response, and simulated how this would have affected the output of the motion vision system, modelled as a computational array of Reichardt detectors. The moths' head movements were modulated to allow encoding of both fast and slow self-motion, effectively quadrupling the working range of the visual system for flight control. By using its own output to drive compensatory head movements, the motion vision system thereby works as an adaptive sensor, which will be especially beneficial in nocturnal species with inherently slow vision. Studies of the ecology of motion vision must therefore consider the tuning of motion-sensitive interneurons in the context of the closed-loop systems in which they function.
More Related Videos
 08:13
SwarmSight: Real-time Tracking of Insect Antenna Movements and Proboscis Extension Reflex Using a Common Preparation and Conventional Hardware
Published on: December 25, 2017
 09:00
Insect-controlled Robot: A Mobile Robot Platform to Evaluate the Odor-tracking Capability of an Insect
Published on: December 19, 2016
Related Concept Videos
 01:05
Mechanism of Ciliary Motion
The cilia are made up of microtubules in a 9+2 arrangement, with nine microtubule doublet ring bundles, surrounding a pair of central singlet microtubule bundles. The doublet microtubule bundles are...
 01:47
Osmoregulation in Insects
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 00:53
Migration
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...