Related Experiment Video
Updated: Feb 7, 2026


The Modular Design and Production of an Intelligent Robot Based on a Closed-Loop Control Strategy
Published on: October 14, 2017
Dual closed-loop sliding mode control for a decoupled three-link wheeled mobile manipulator
1Dept. of Mechanical Engineering, Pusan National University, 63 beon-gil, Busandaehak-ro, Jangjeong-dong, Geumjeong-gu, Busan city, 46241, South Korea.

Abstract:
This paper presents a dual closed-loop sliding mode control strategy for a wheeled mobile manipulator with three-wheeled mobile platform (WMP) and three-link manipulator. The Euler-Lagrange method combined partially with the Newtonian method is applied to obtain full dynamic model and decoupled model is constructed in order to provide simple dynamic model for controller's structure to be simplified. Instead of the conventional velocity command trajectory based kinematic backstepping control method, a dual closed-loop control system is designed. A virtual velocity command based on sliding mode surface is generated in outer loop and the gap between a generated virtual command velocity and real velocity is compensated by an inner loop sliding mode controller. Outer loop helps to faster posture trajectory generation for locomotion of the WMP. Next, a finite-time sliding mode controller with an assumed feedforward dynamic gain method is designed for joint trajectory tracking for three-link manipulator by adding finite-time control terms in the designed controllers to obtain faster settling time and stronger robustness. The designed controllers were implemented into microprocessor connected to DC and dynamixel motor systems equipped in mobile platform and manipulator, respectively. Comparative simulation and experiment with a conventional sliding mode control show the effectiveness of the proposed dual closed-loop finite time sliding mode control scheme.


Related Concept Videos
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:04
¹³C NMR: ¹H–¹³C Decoupling
A broadband decoupling technique is used to simplify these complex, sometimes overlapping, signals. Broadband decoupling relies on a...
 01:07
What is a Mode?
There can be more than one mode in a data set if multiple values have the same highest frequency. For instance, suppose that the Statistics exam scores of 20 students are: 50; 53; 59; 59; 63; 63; 72; 72; 72; 72; 72; 76; 78; 81; 83; 84; 84; 84; 90; 93. Here, the mode is 72, as it occurs most frequently, five times.
A data set with two modes is called bimodal. For example,...
 02:04
Covalently Linked Protein Regulators
These groups modify specific amino acids in a protein....
 01:24
Fast Decoupled and DC Powerflow
 01:14
Ventilatory Modes
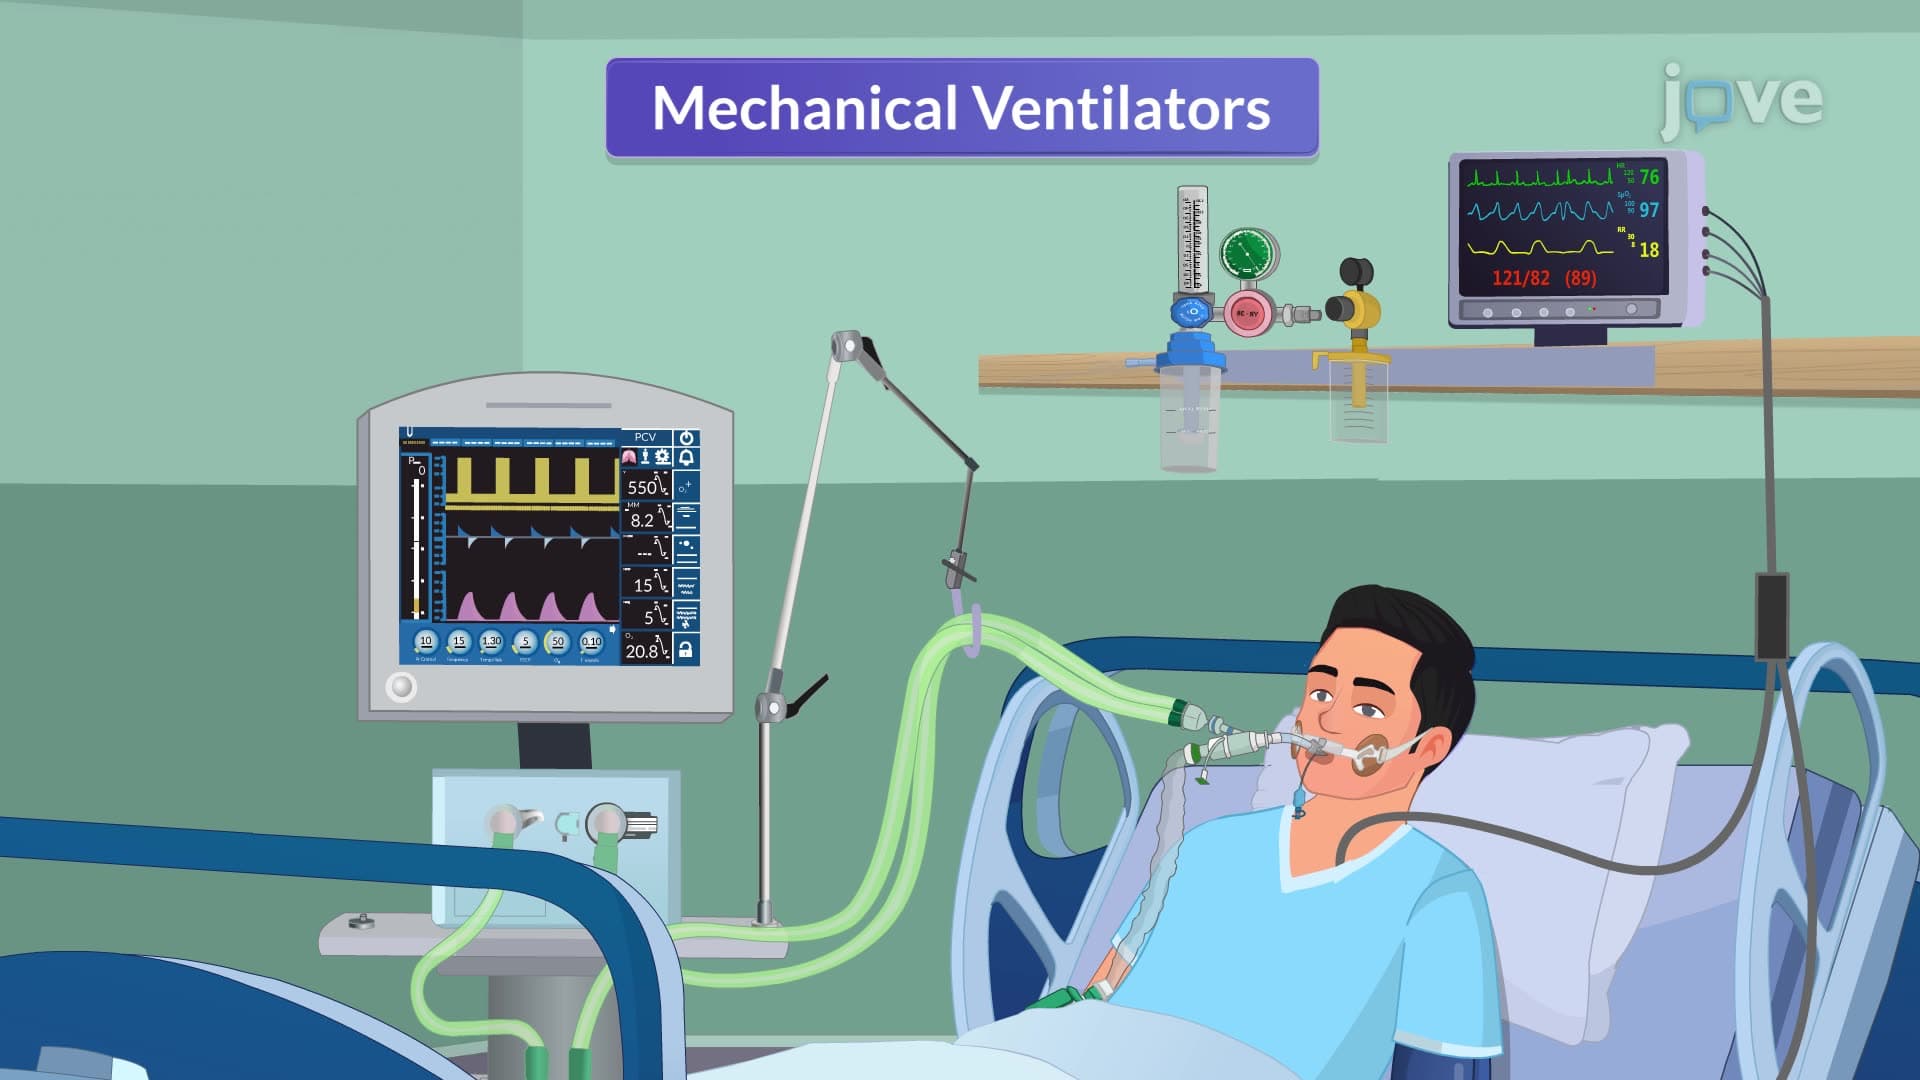
There are three ventilatory modes: full support, partial support, and spontaneous. These are described below.
Full Support Modes
Full support modes include controlled mechanical ventilation, continuous mandatory...