Related Experiment Video
Updated: Feb 6, 2026


Author Spotlight: UAV Remote Sensing for Efficient Invasive Plant Biomass Estimation
Published on: February 9, 2024
Robust Landmark Detection and Position Measurement Based on Monocular Vision for Autonomous Aerial Refueling of UAVs

Abstract:
In this paper, a position measurement system, including drogue's landmark detection and position computation for autonomous aerial refueling of unmanned aerial vehicles, is proposed. A multitask parallel deep convolution neural network (MPDCNN) is designed to detect the landmarks of the drogue target. In MPDCNN, two parallel convolution networks are used, and a fusion mechanism is proposed to accomplish the effective fusion of the drogue's two salient parts' landmark detection. Considering the drogue target's geometric constraints, a position measurement method based on monocular vision is proposed. An effective fusion strategy, which fuses the measurement results of drogue's different parts, is proposed to achieve robust position measurement. The error of landmark detection with the proposed method is 3.9%, and it is obviously lower than the errors of other methods. Experimental results on the two KUKA robots platform verify the effectiveness and robustness of the proposed position measurement system for aerial refueling.
More Related Videos
 08:42
Monocular Visual Deprivation and Ocular Dominance Plasticity Measurement in the Mouse Primary Visual Cortex
Published on: February 8, 2020
 05:46
Author Spotlight: Advancements in Refractive Surgical Correction for Presbyopia and Exploring Postoperative Visual Acuity
Published on: September 20, 2024
Related Concept Videos
 01:24
Vision
 01:24
Color Vision
 02:05
Position of Equilibrium in Acid-Base Reactions
 01:22
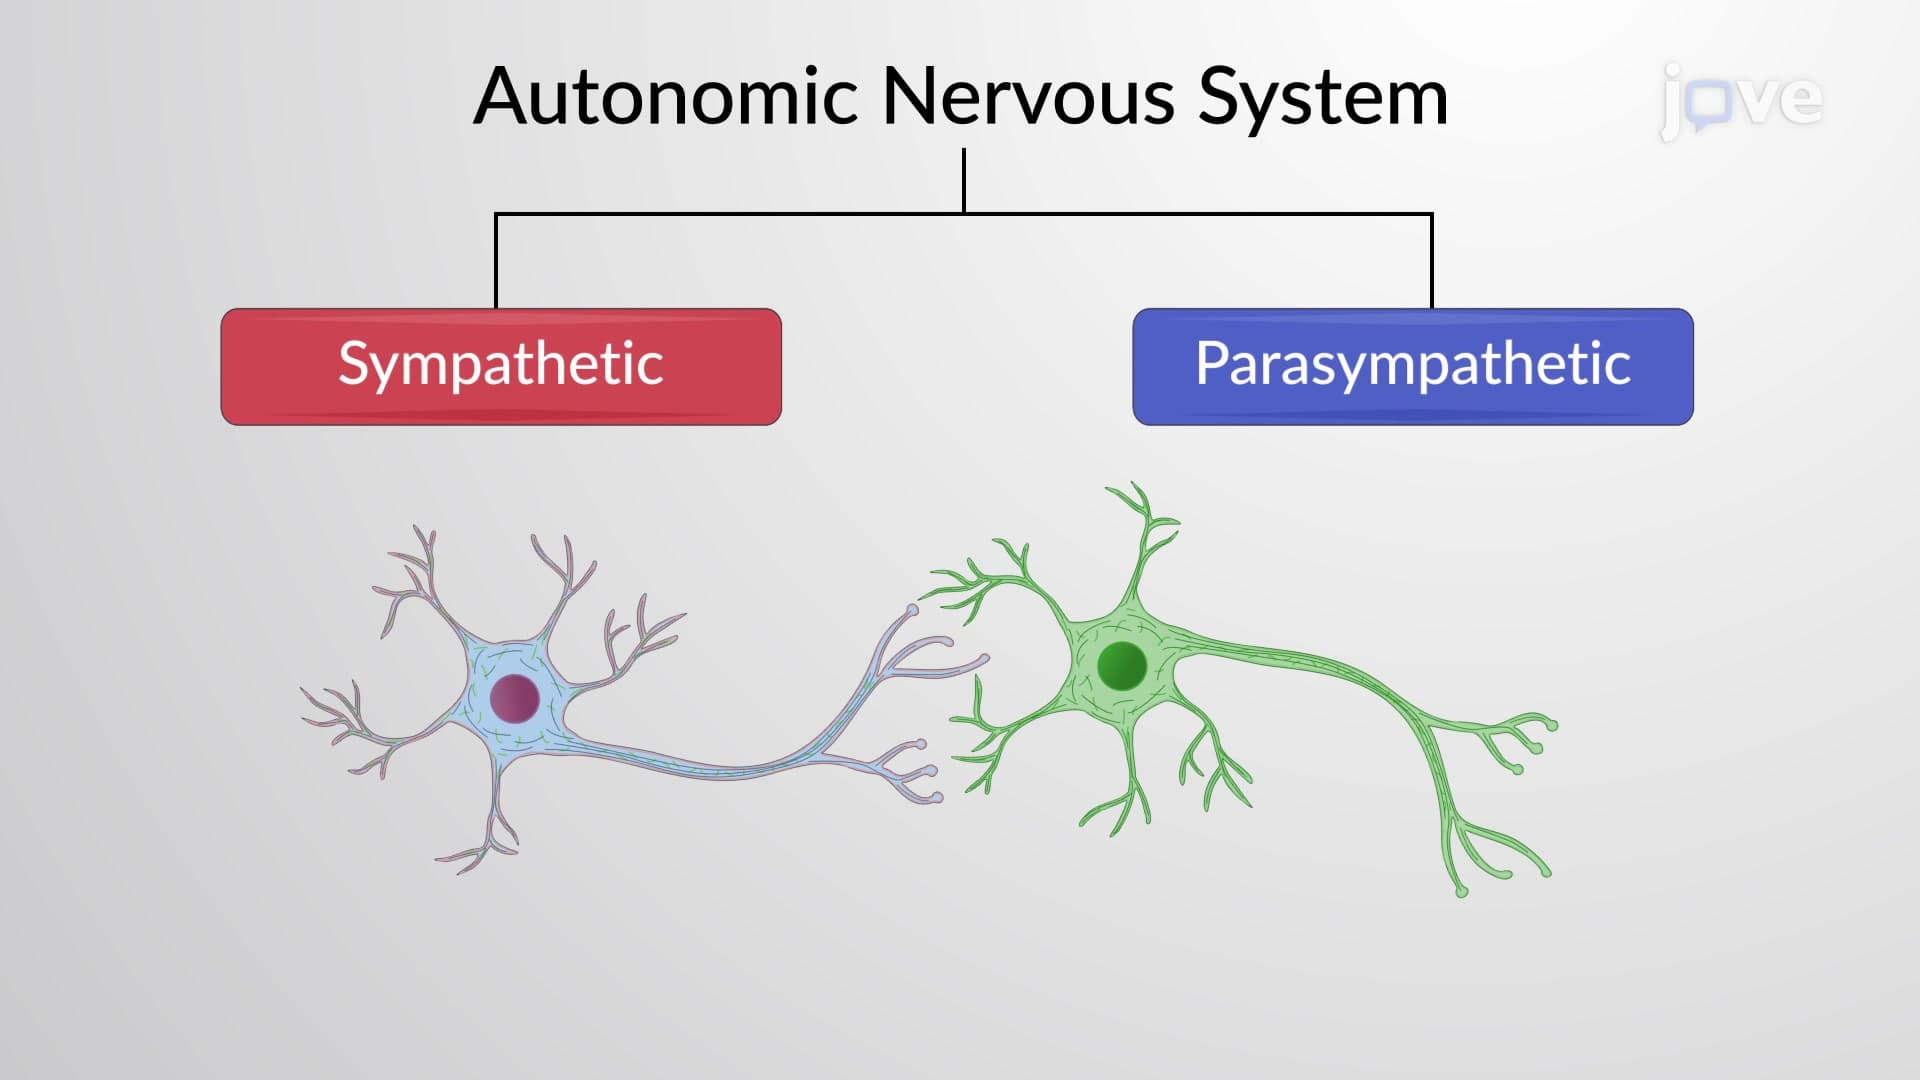
Autonomic Nervous System
The ANS comprises two main divisions: the sympathetic and parasympathetic divisions. These divisions function antagonistically to maintain a dynamic...
 01:26
Autonomic Nervous System: Overview
 01:18
Disorders of the Autonomic Nervous System
Raynaud's disease, also known as Raynaud's...