Related Experiment Video
Updated: Feb 1, 2026

Author Spotlight: Microbial Control and Monitoring Strategies for Cleanroom Environments and Cellular Therapies
Published on: March 17, 2023
Implementation of a ball inverted pendulum with omnidirectional moving ability using a robust fuzzy control strategy
Chih-Hui Chiu1, Wen-June Wang2
1Department of Communications, Navigation and Control Engineering, National Taiwan Ocean University, No.2, Beining Rd., Jhongjheng District, Keelung City, 20224, Taiwan, ROC.

Abstract:
A robust fuzzy controller (RFC) is proposed for a ball inverted pendulum (BIP) system control problem. A Mamdani-type fuzzy controller and a compensated control technique are combined in the proposed control system. This controller is used for real-world control of a BIP with unknown system uncertainties. Using this method, the approximation error caused by the trial-and-error fuzzy control design procedure is minimized. Moreover, the decoupled technique provides a simple method for achieving asymptotic stability control for angle and position of a BIP control system. The concept of this approach is to decouple the entire system into two subsystems. Next, the primary subsystem combines the information provided by the secondary subsystem. And then a control force is generated to drive both subsystems toward their targets, respectively. Thus, the platform can move to any position without constraints. The stability of RFC, which is based on the Lyapunov stability theorem, is guaranteed. Furthermore, to verify the effectiveness of the control algorithm, several numerical simulations and dynamic simulation in the automatic dynamic analysis of mechanical systems (ADAMS) environment with MATLAB are implemented. Finally, the efficiency of the RFC is verified with real-time implementation of the BIP.
Related Concept Videos
 01:20
Inverting and Non-inverting OpAmps
 01:06
Physical Pendulum
When dealing with complicated systems, the mass moment of inertia is an important parameter, as it...
 01:14
Conservation of Mass in Moving, Nondeforming Control Volume
In the context of a detention basin, the conservation of mass states that the total mass of water entering the basin must equal the mass leaving the basin plus any accumulation of...
 01:10
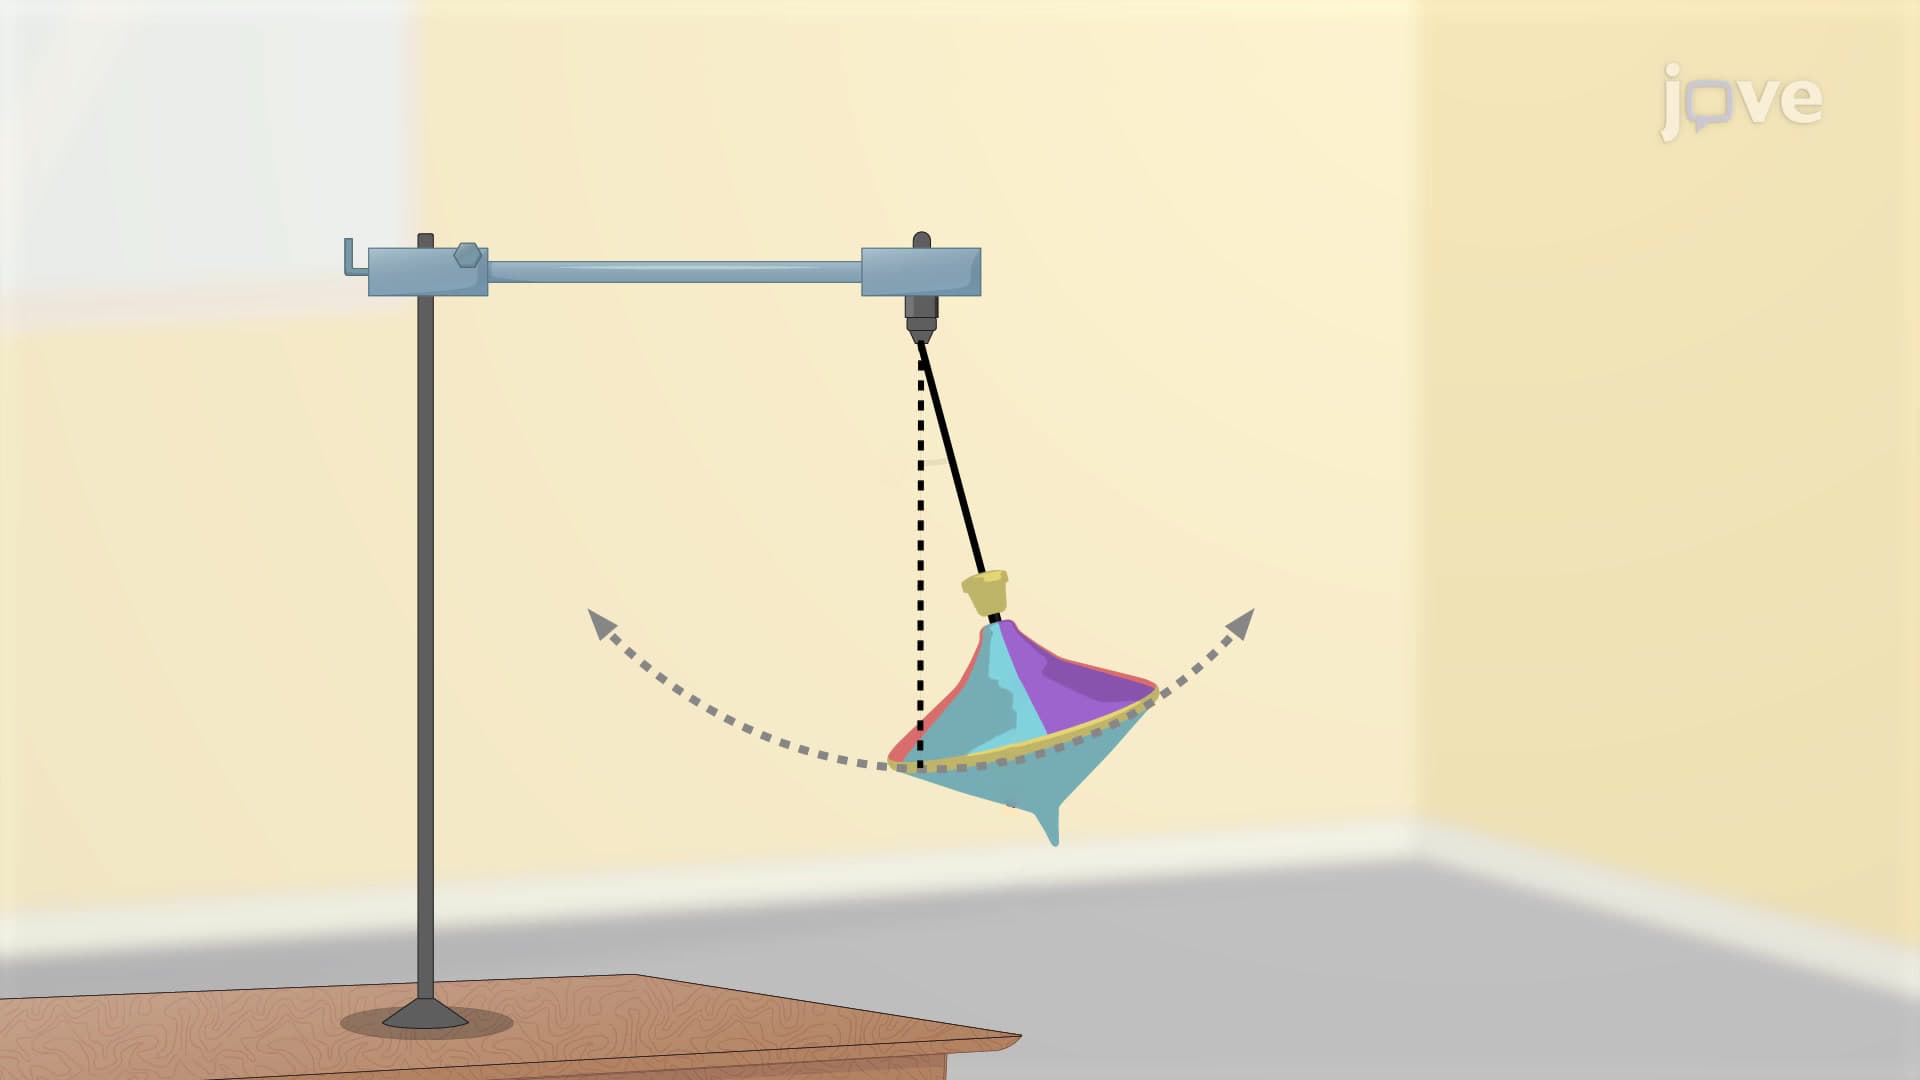
Simple Pendulum
The period of a simple pendulum depends on two factors: its length and the acceleration due to gravity. The period is completely independent of any other factors, such as mass or maximum displacement. For small displacements, a pendulum is...
 01:09
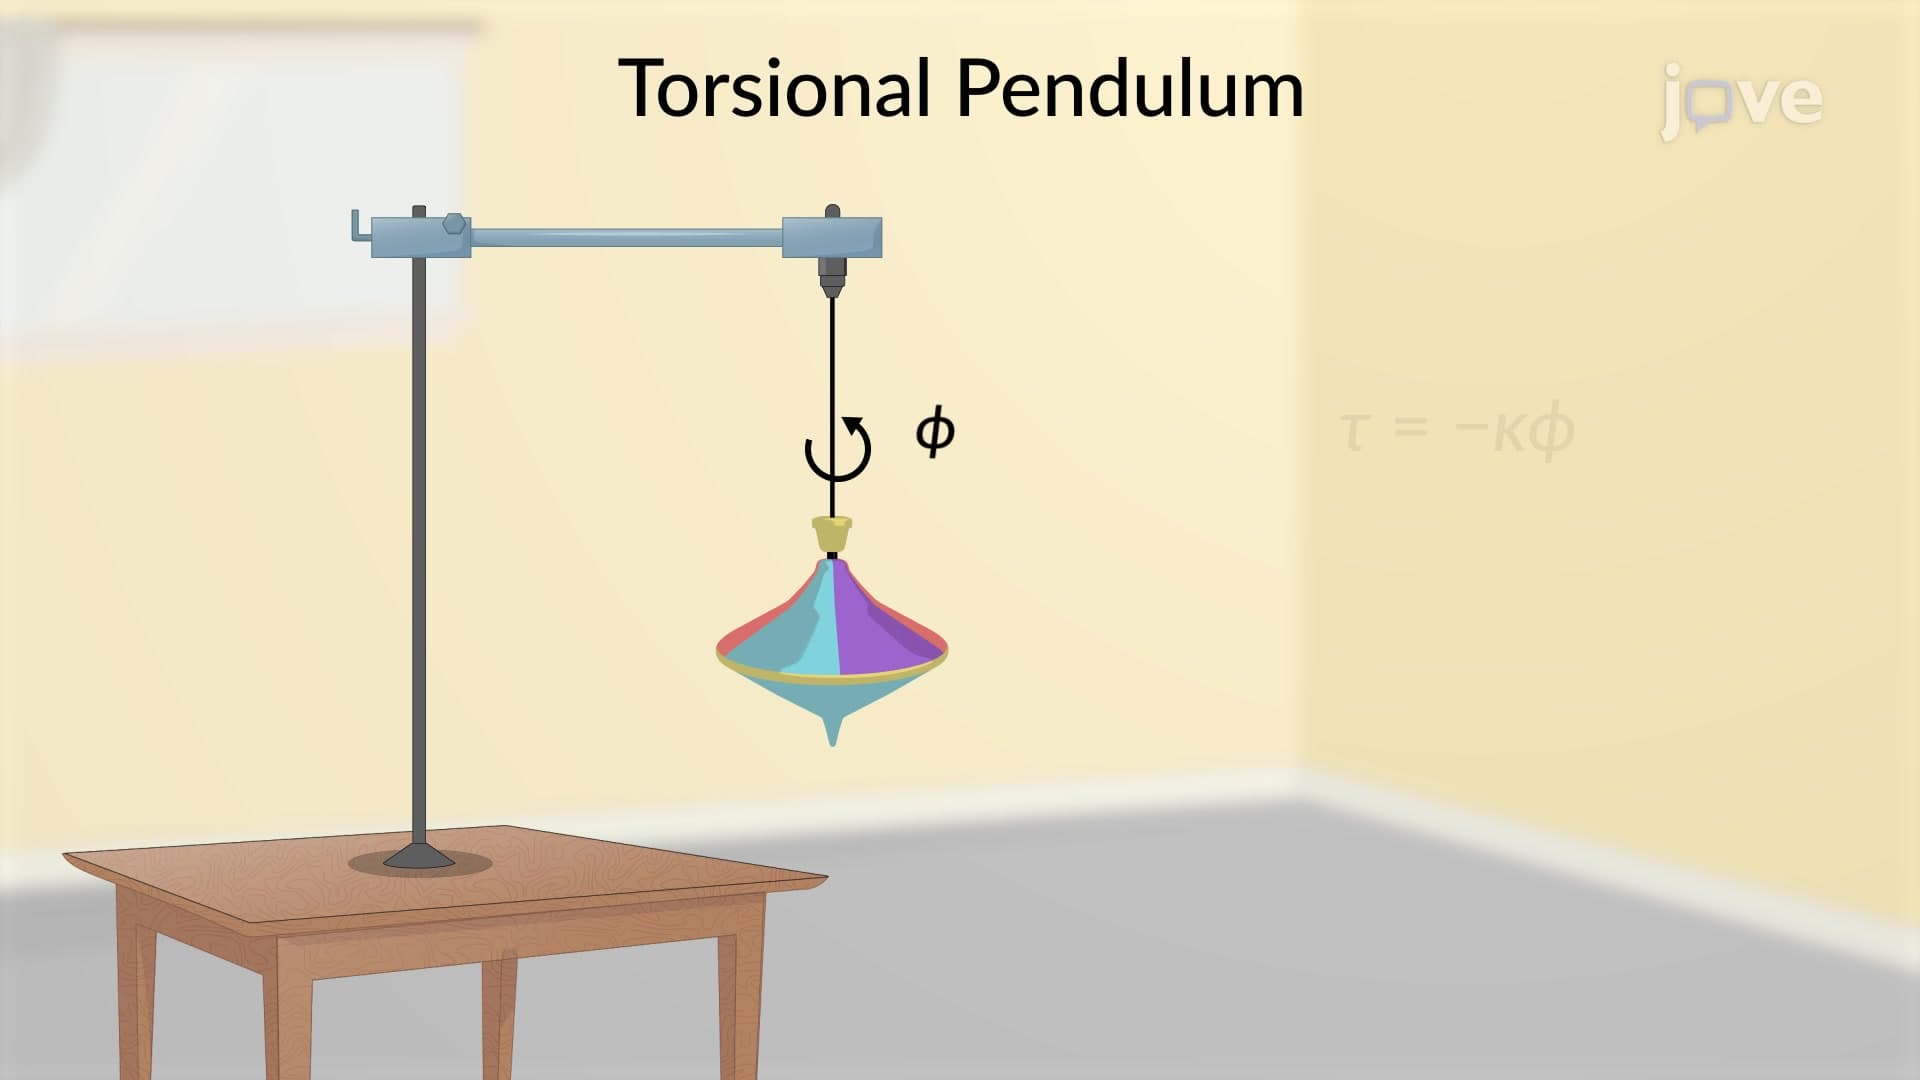
Torsional Pendulum
As long as the rigid body's angular displacement is small, its oscillation can be modeled as a linear angular oscillation. The amplitude of the oscillation is an angle. The role of mass is played...
 01:15
Nursing Implementation
The five steps to implementing effective nursing care include reassessing the patient, reviewing and revising the existing nursing care plan, organizing the resources and care delivery, anticipating and preventing complications, and implementing nursing interventions.