Related Experiment Video
Updated: Jan 31, 2026
Mimicking and Measuring Occlusal Erosive Tooth Wear with the "Rub&Roll" and Non-contact Profilometry
Published on: February 2, 2018
A Torque-actuated dissipative spring loaded inverted pendulum model with rolling contact and Its application to
Chia-Jui Hu1, Tso-Kang Wang, Chun-Kai Huang
1Department of Mechanical Engineering, National Taiwan University, Taipei, Taiwan, Republic of China.

Abstract:
We report on the development and analysis of a new torque-actuated dissipative spring loaded inverted pendulum model with rolling contact (TDR-SLIP), which is a successor to the previously developed spring loaded inverted pendulum model with rolling contact (R-SLIP) model. The stability properties of the models were analyzed numerically via steps-to-fall analysis and return map analysis, wherein the dimensionless parameters are varied to analyze their effects on the dynamic performance of the model, including torque, damping constant, spring constant, touchdown angle, touchdown speed, and landing angle. Because the involvement of torque and damping in the TDR-SLIP model is similar to other recently developed torque-actuated dissipative spring loaded inverted pendulum studies, their performance was compared so that the unique features of the TDR-SLIP model, such as rolling contact, could be investigated. To undertake the comparison, a method for yielding parameter equivalency between these two models is also reported. In addition to its analytical role, the TDR-SLIP model served as a template to initiate the stable running behavior of the empirical robot acted as the anchor. Two sets of legs were evaluated-the original compliant half-circular leg of the robot and the new mechanical legs, which resemble the morphology of the TDR-SLIP model. Two types of control strategies were tested-position-based control and hybrid control. The experimental results reveals that the low-damped compliant half-circular leg and the mechanical leg match the behaviors of the R-SLIP model and the TDR-SLIP model, respectively, and the robot with hybrid control performs more stably and more closely to the model profile. In addition, when the robot's motion follows the template's stable dynamics, the energy cost of the leg in stance can be significantly lower than that in flight.
More Related Videos

Related Concept Videos
 01:20
Inverting and Non-inverting OpAmps
 01:06
Physical Pendulum
When dealing with complicated systems, the mass moment of inertia is an important parameter, as it...
 01:10
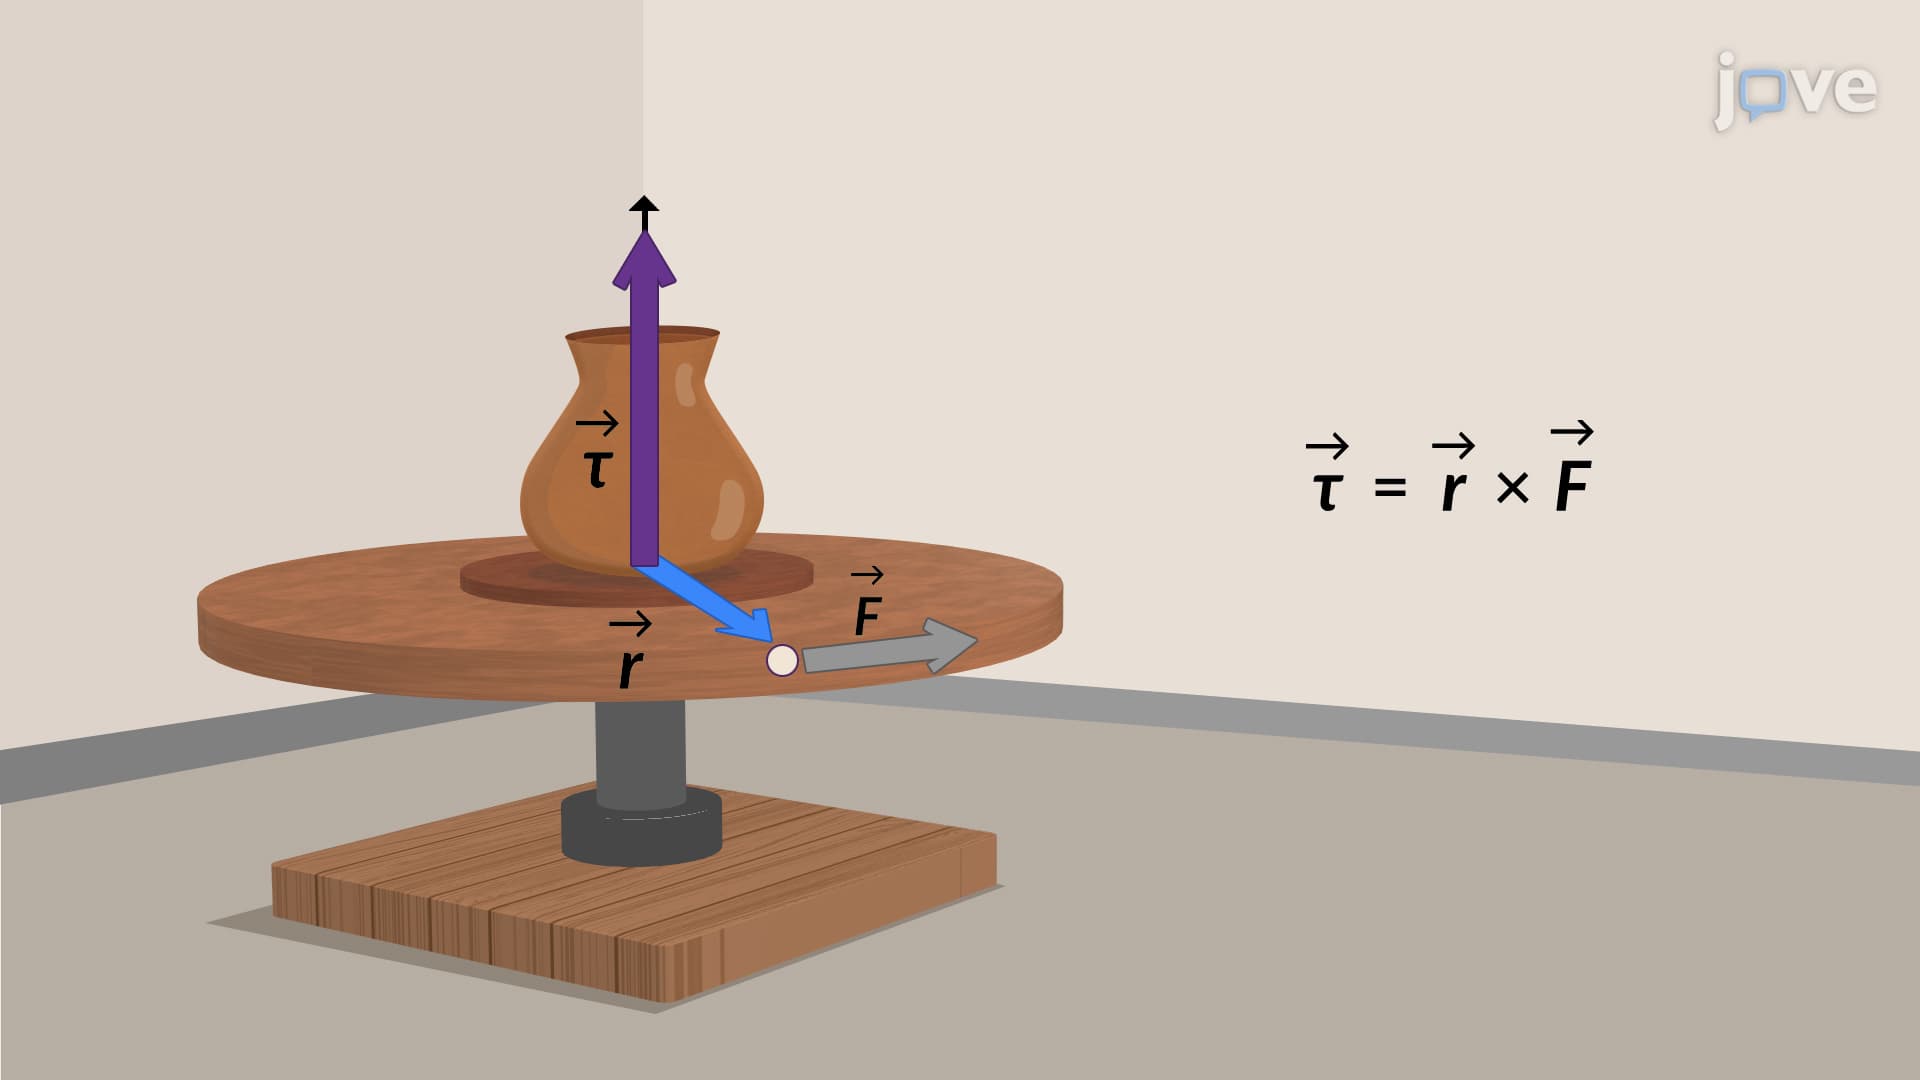
Torque
Torque can be considered as the rotational counterpart to force. Since forces change the translational...
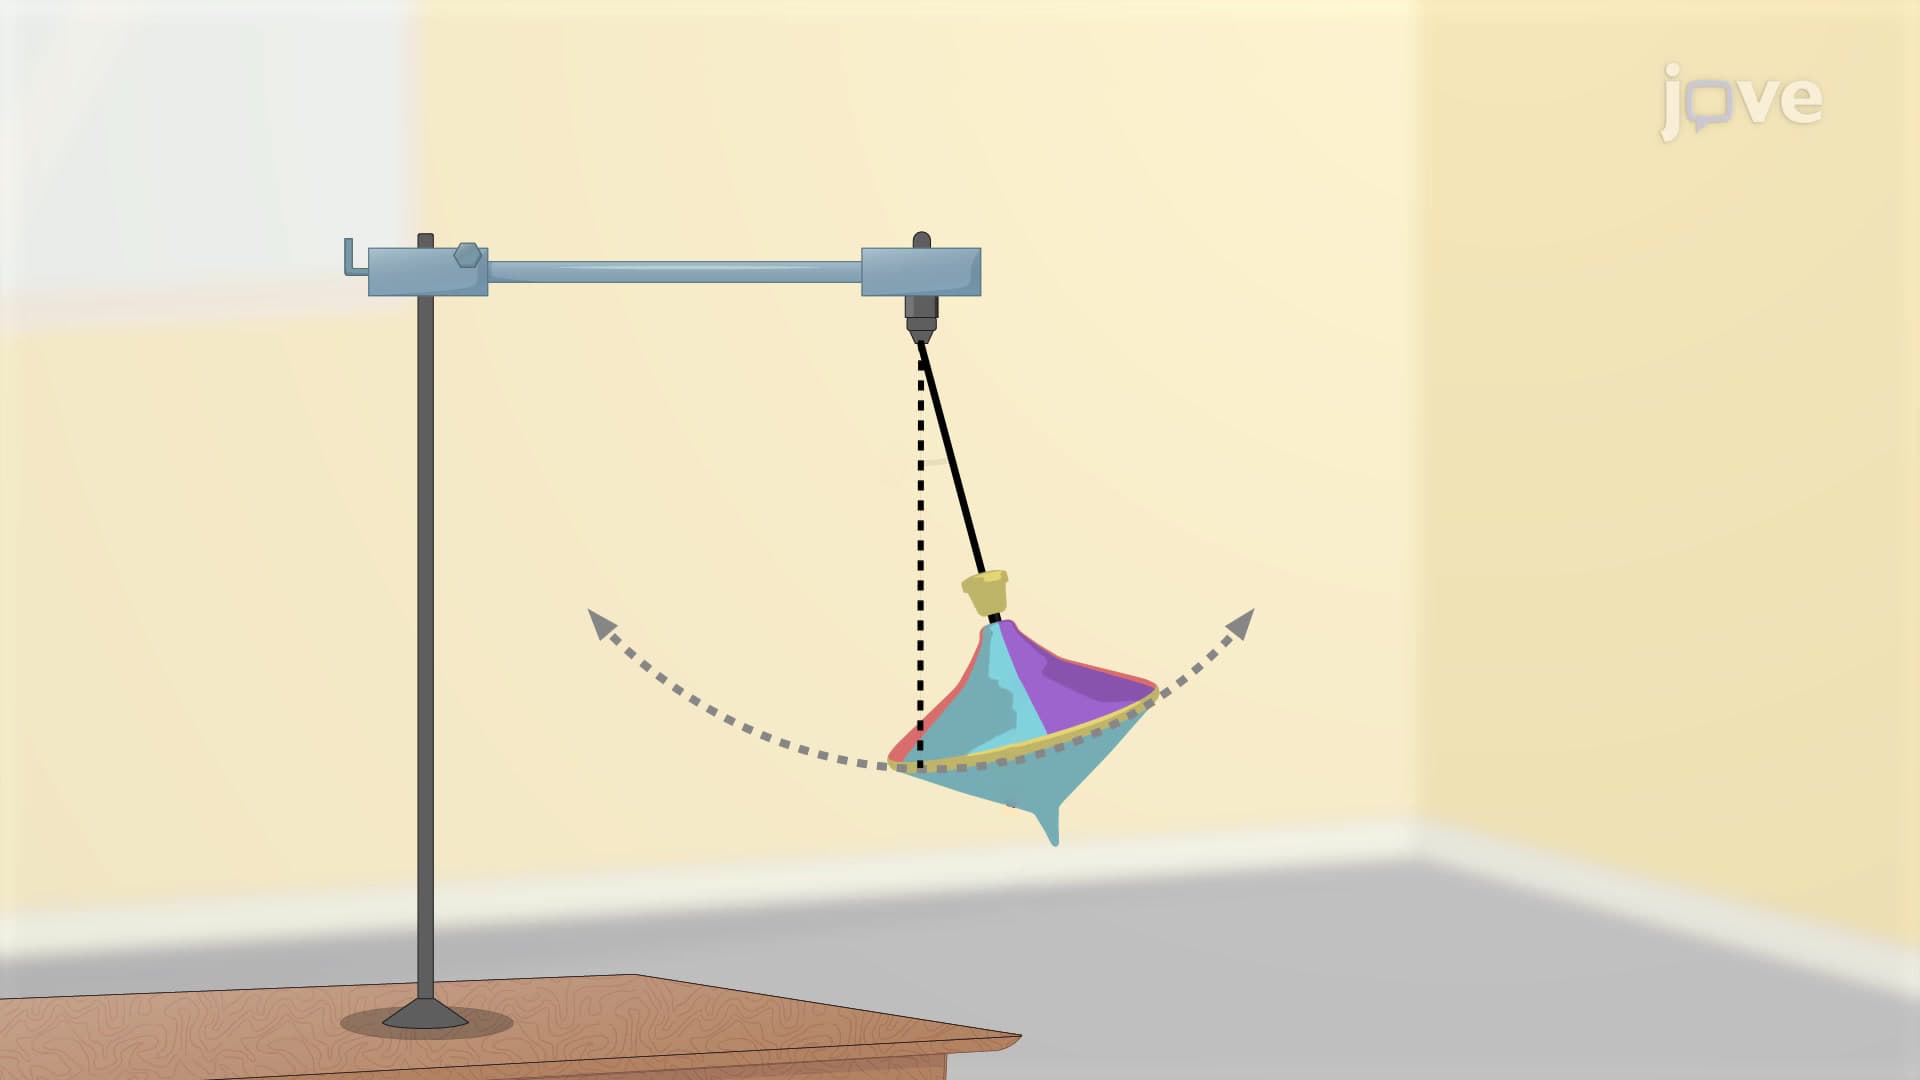 01:10
Simple Pendulum
The period of a simple pendulum depends on two factors: its length and the acceleration due to gravity. The period is completely independent of any other factors, such as mass or maximum displacement. For small displacements, a pendulum is...
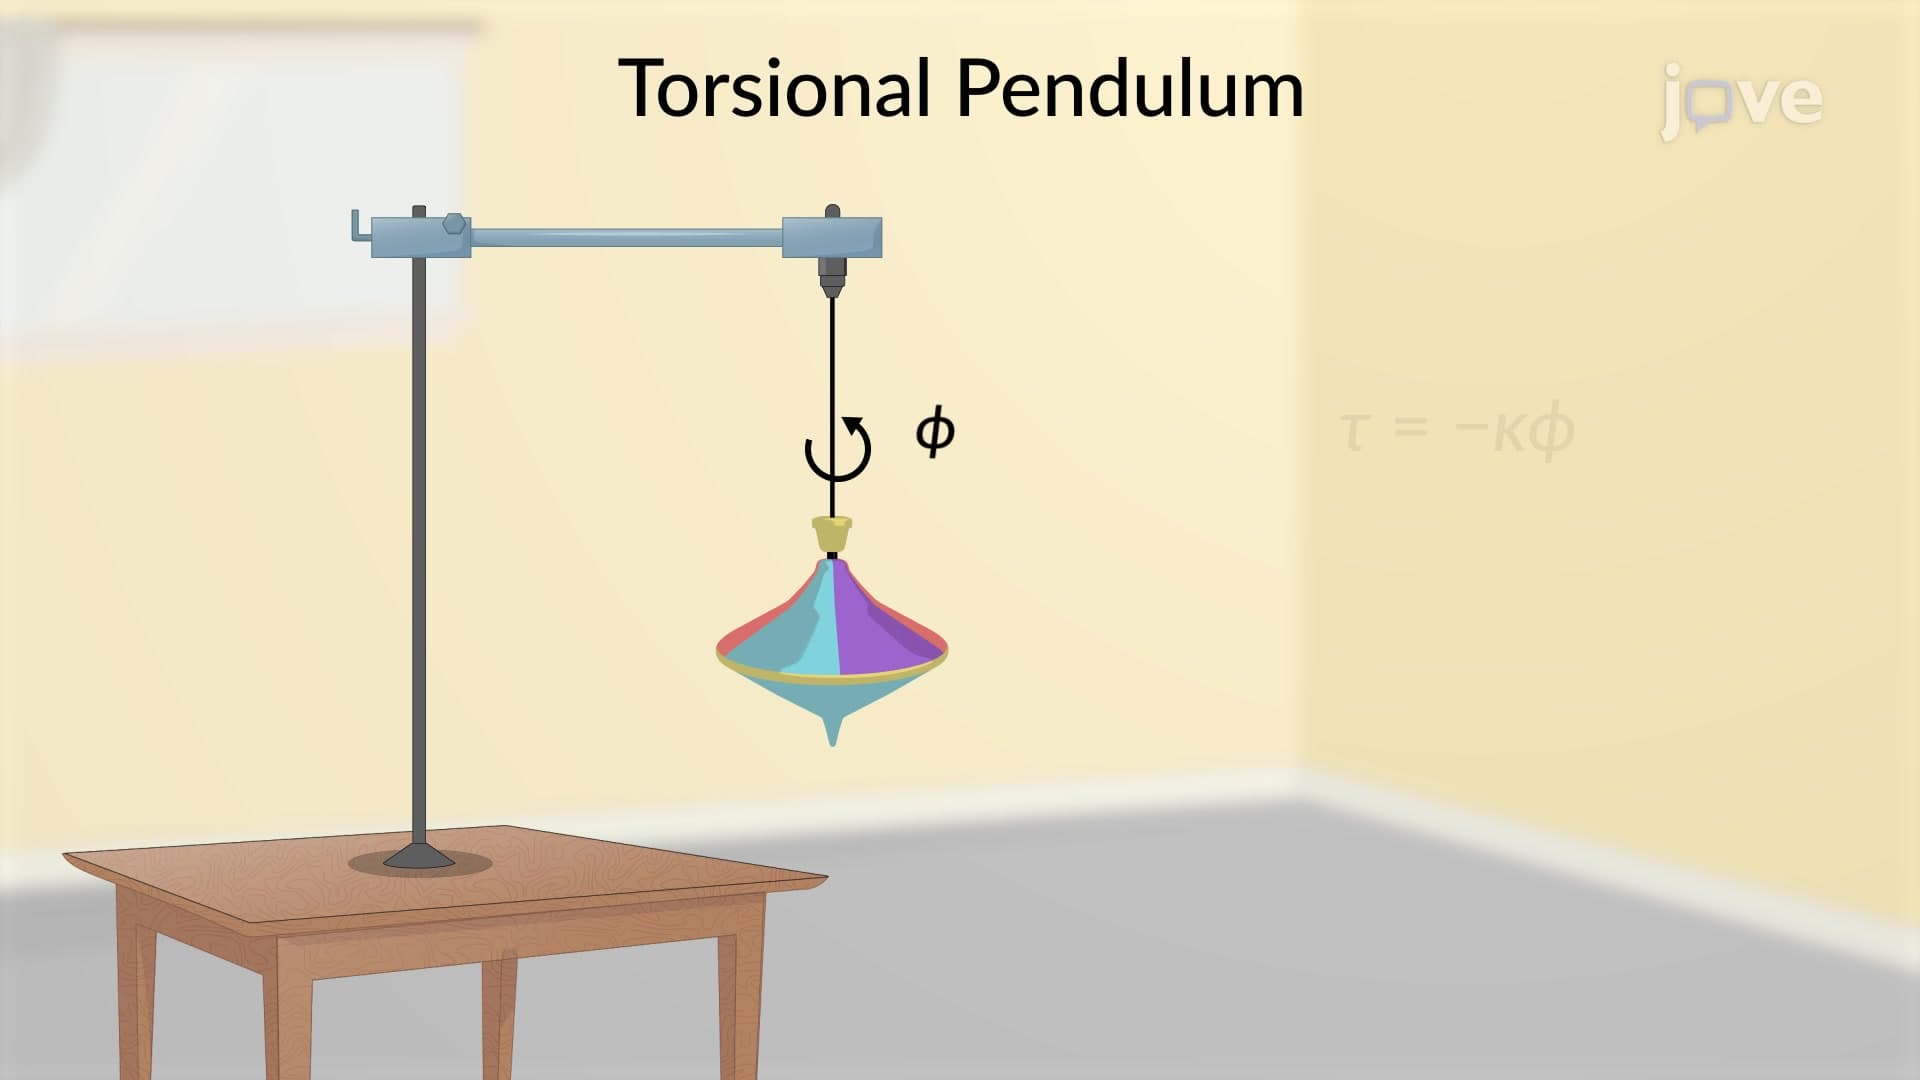 01:09
Torsional Pendulum
As long as the rigid body's angular displacement is small, its oscillation can be modeled as a linear angular oscillation. The amplitude of the oscillation is an angle. The role of mass is played...
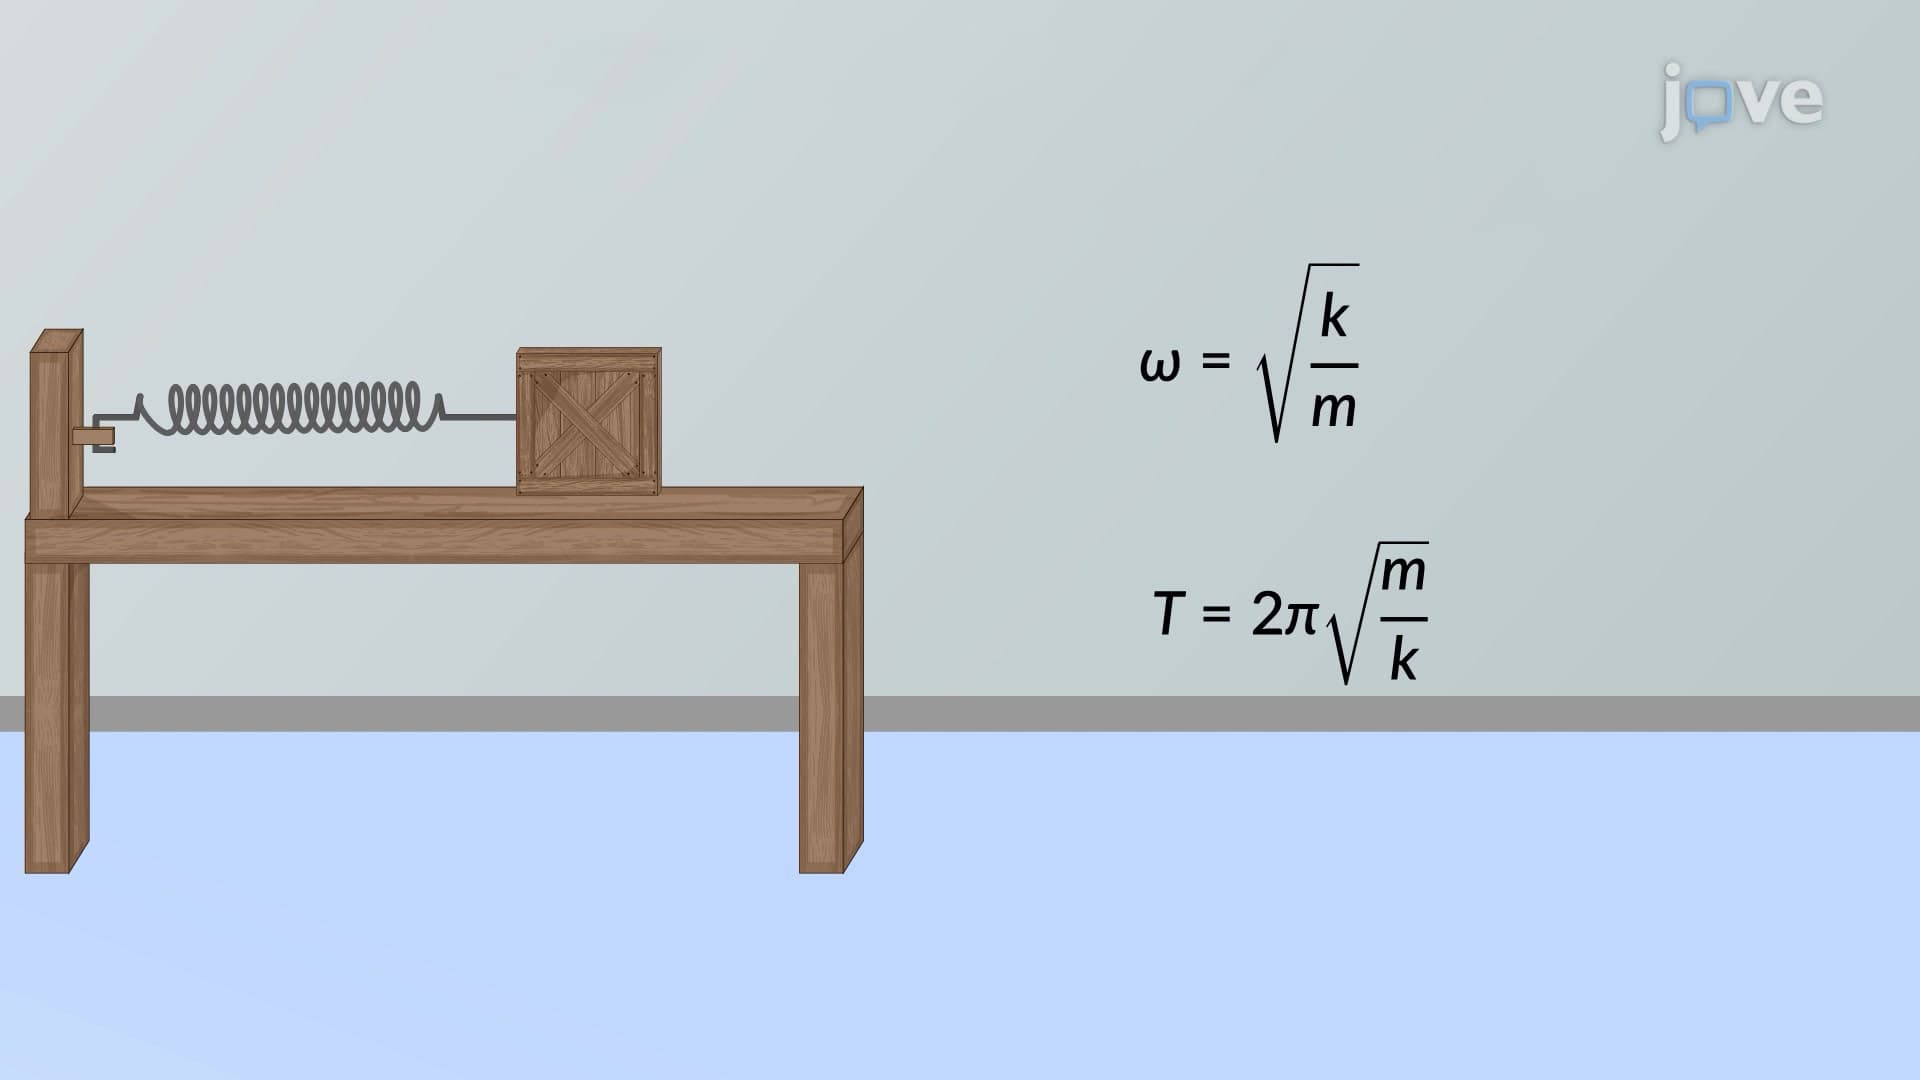 01:17
Frequency of Spring-Mass System
Consider a block on a spring on a frictionless surface. There...