Related Experiment Video
Updated: Jan 25, 2026


Experimental Methods to Study Human Postural Control
Published on: September 11, 2019
Evaluation of gap-metric based multi-model control schemes for nonlinear systems: An experimental study
G Maruthi Prasad1, A Seshagiri Rao1
1Department of Chemical Engineering, National Institute of Technology, Warangal - 506 004, Telangana State, India.

Abstract:
Many methods are proposed in the literature for control of nonlinear systems based on multi model approaches. Most of these methods are by simulation. An experimental investigation provides more understanding and also practical difficulties of nonlinear process control. This paper presents an experimental evaluation and comparison of gap metric based weighting methods for design of multi-model control schemes for control of levels in a spherical tank process and a conical tank process. IMC-PI controllers are designed for the corresponding linear models. A simulation study is first carried out to examine the performance of the level control on these nonlinear systems, in which the weights for local controllers combination are calculated by the weighting functions. The two weighting functions (1- δ and 1/δ) based on the gap metric value of particular linear model are calculated and used for constructing the global multi model controller. Level control in spherical and conical tank systems is studied to show the effective experimental implementation of the considered multi model control schemes.
Related Concept Videos
 01:10
Control Systems
At the heart...
 01:22
Multi-input and Multi-variable systems
In the absence of...
 01:25
Control Systems: Applications
In modern vehicles, control systems manage various functions to enhance performance and safety. The steering wheel and accelerator are primary inputs in a car's control system. The...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:21
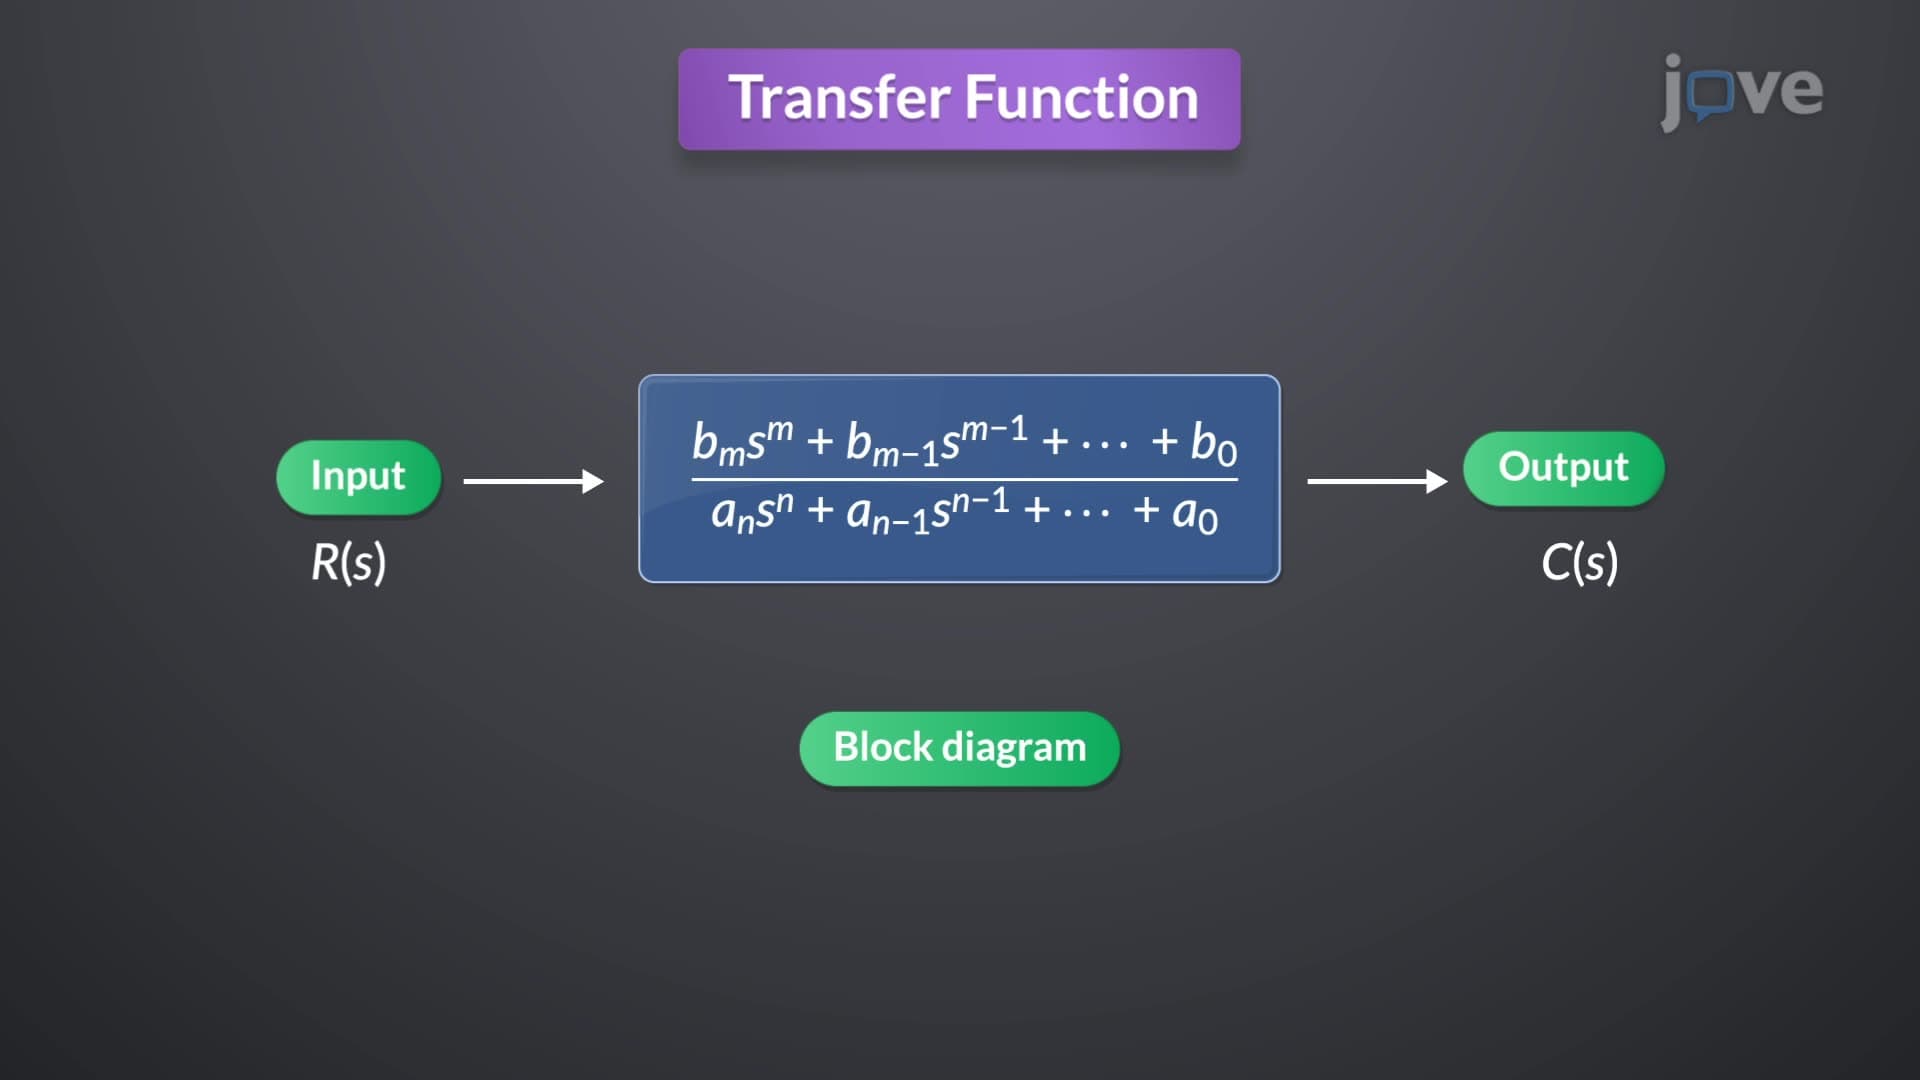
Transfer Function in Control Systems
To derive the transfer function, consider a general nth-order linear time-invariant...