High-precision tracking differentiator via generalized discrete-time optimal control
Related Experiment Video
Updated: Jan 24, 2026
Picometer-Precision Atomic Position Tracking through Electron Microscopy
Published on: July 3, 2021
Hehong Zhang1, Yunde Xie2, Longhua She2
1Interdisciplinary Graduate School, Nanyang Technological University, Singapore.

Abstract:
An enhanced discrete-time tracking differentiator (TD) with high precision based on discrete-time optimal control (DTOC) law is proposed. This law takes the form of state feedback for a double-integral system that adopts the Isochronic Region approach. There, the control signal sequence is determined by a linearized criterion based on the position of the initial state point on the phase plane. The proposed control law can be easily extended to the TD design problem by combining the first-state variable of the double-integral system with the desired trajectory. To improve the precision of the discretization model, we introduced a zero-order hold on the control signal. We also discuss the general form of DTOC law by analysing the relationship between boundary transformations and boundary characteristic points. After comparing the simulation results from three different TDs, we determined that this new TD achieves better performance and higher precision in signal-tracking filtering and differentiation acquisition than do existing TDs. Also the comparisons of the computational complexities between the proposed DTOC law and normal one are demonstrated. For confirmation of its utility, we processed raw phasor measurement units data via the proposed TD. In the absence of complex power system modelling and historical data, it was verified that the proposed TD is suitable for applications of real-time synchrophasor estimations, especially when the states are corrupted by noise.
Related Concept Videos
 01:26
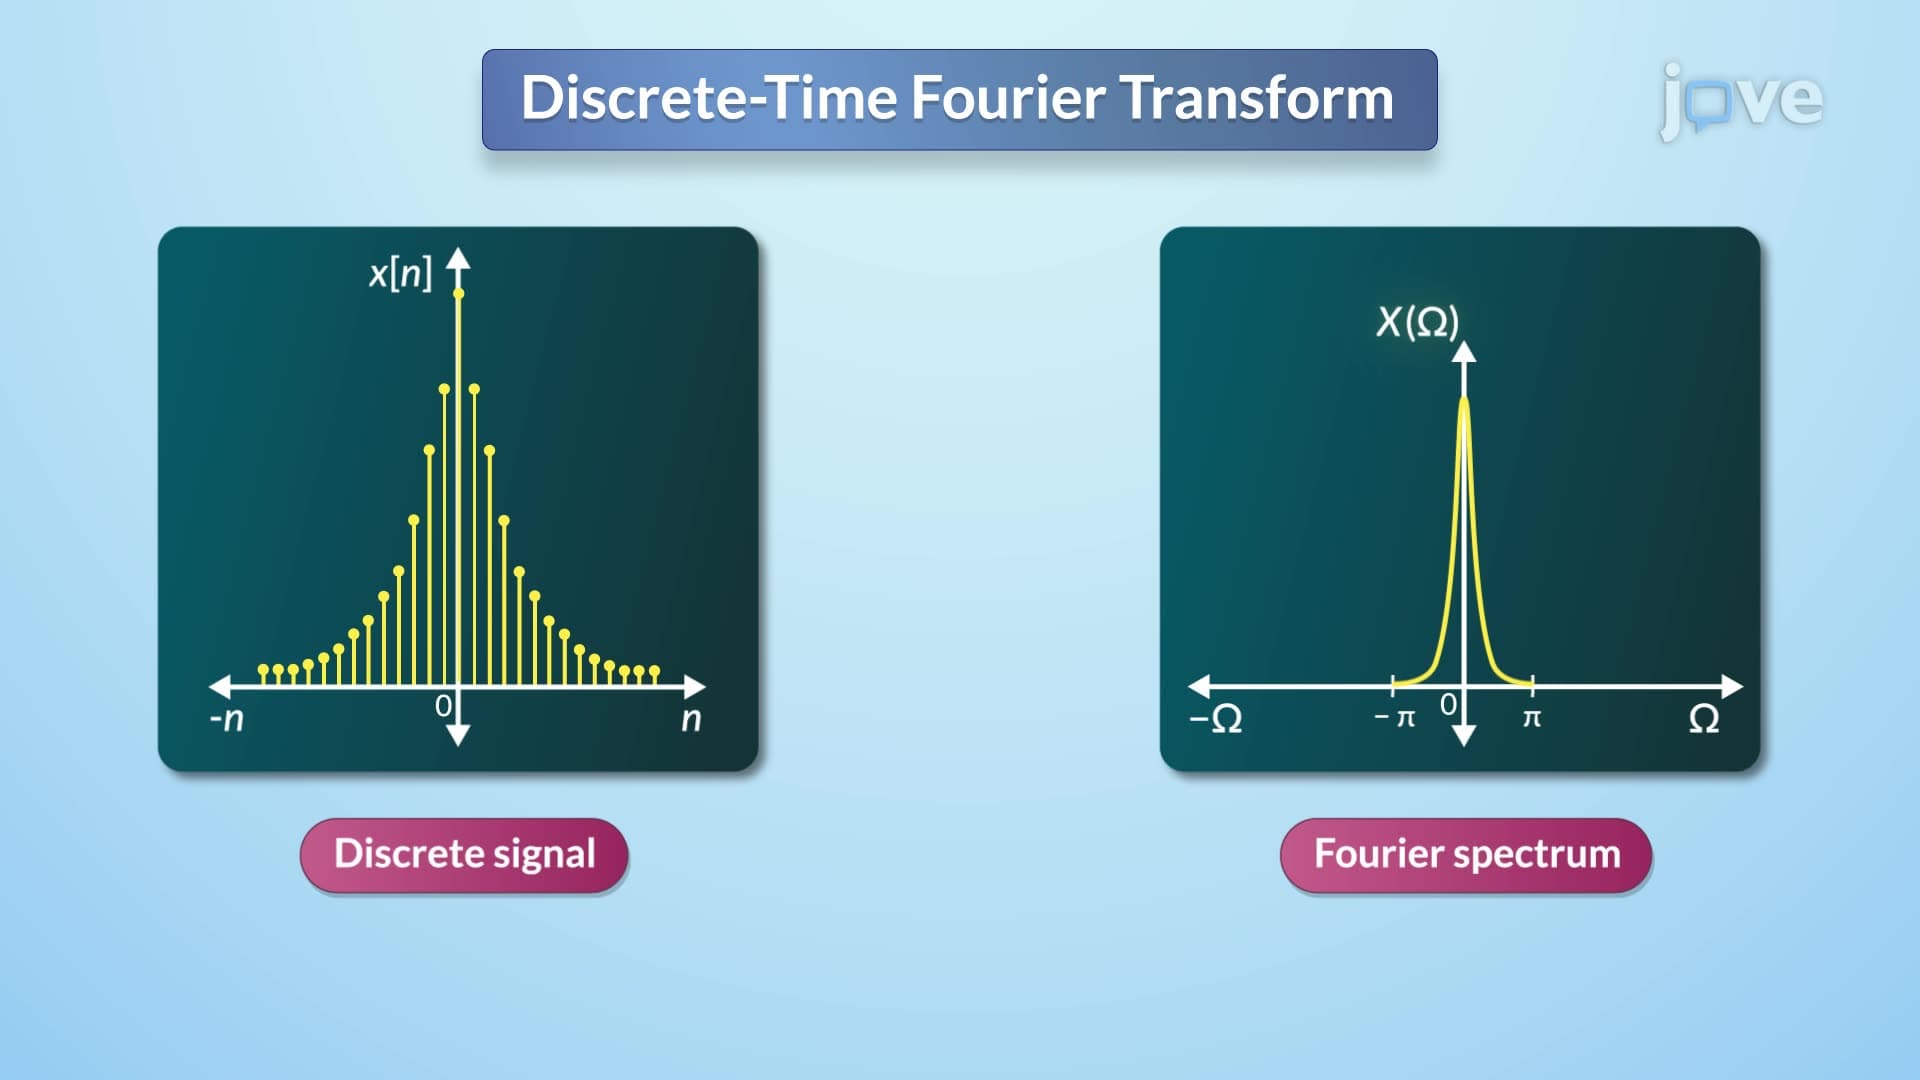
Discrete-time Fourier transform
One of the notable...
 01:16
Basic Discrete Time Signals
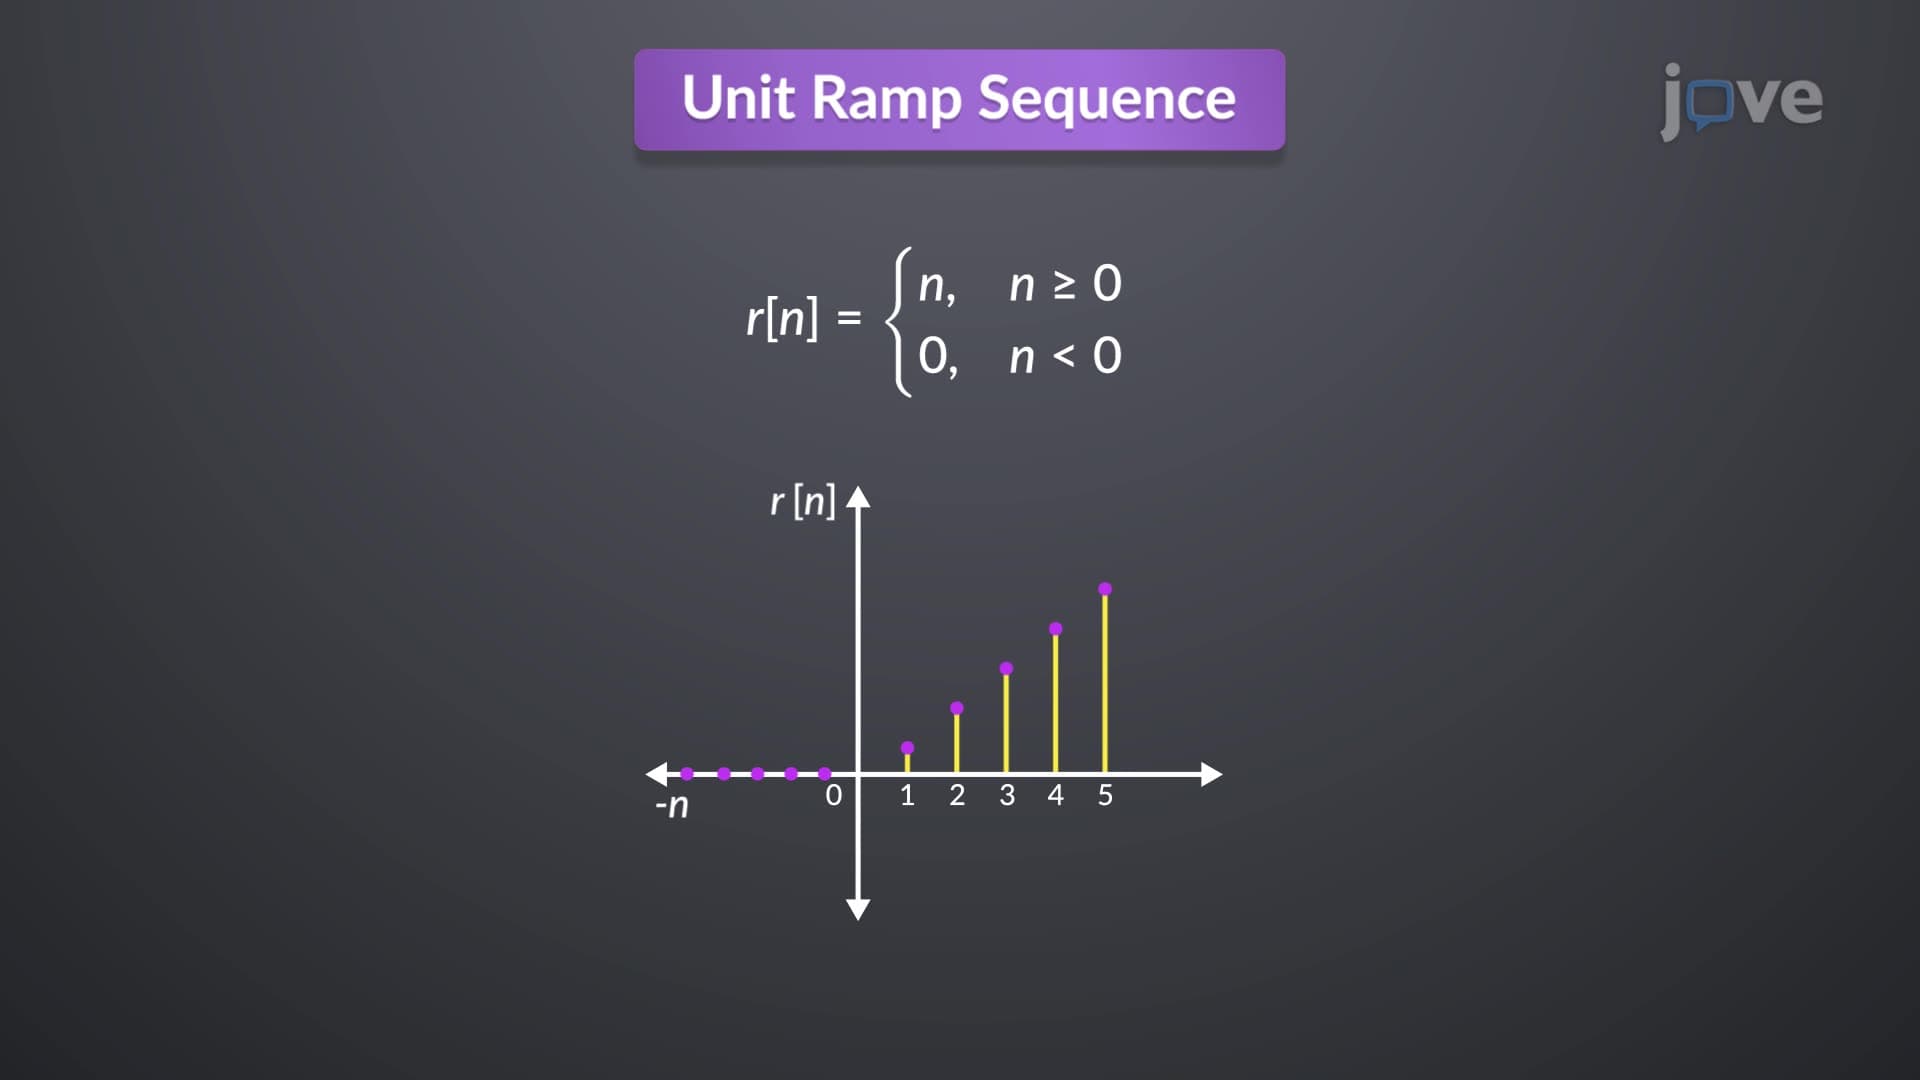
The unit impulse or sample sequence is mathematically expressed as zero for all n values except at n=0, where it is one. The unit impulse sequence, denoted by δ(n), is the first difference of the unit step sequence, while the unit step sequence u(n) is the...
 01:20
Discrete-Time Fourier Series
For a discrete-time periodic signal x[n]...
 01:24
BIBO stability of continuous and discrete -time systems
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
 01:22
Generalized Hooke's Law
 01:30
Generalized Anxiety Disorder