Online Nash-optimization tracking control of multi-motor driven load system with simplified RL scheme
Related Experiment Video
Updated: Jan 20, 2026
Author Spotlight: Enhancing Engineering Education via WebVR-Based Online Laboratories
Published on: February 23, 2024
Yongfeng Lv1, Xuemei Ren1, Jing Na2
1School of Automation, Beijing Institute of Technology, Beijing 100081, China.

Abstract:
Although the optimal tracking control problem (OTCP) has been addressed recently, only the single-input system is considered in the recent literature. In this paper, the OTCP of unknown multi-motor driven load systems (MMDLS) is addressed based on a simplified reinforcement learning (RL) structure, where all the motor inputs with different dynamics will be obtained as a Nash equilibrium. Thus, the performance indexes associated with each input can be optimized as an outcome of a Nash equilibrium. Firstly, we use an identifier to reconstruct MMDLS dynamics, such that the accurate model required in the general control design is avoided. We use the identified dynamics to drive Nash-optimization inputs, which include the steady-state controls and the RL-based controls. The steady-state controls are designed with the identified system model. The RL-based controls are designed using the optimization method with the simplified RL-based critic NN schemes. We use the simplified RL structures to approximate the cost function of each motor input in the optimal control design. The NN weights of both the identified algorithm and simplified RL-based structure are approximated by using a novel adaptation algorithm, where the learning gains can be optimized adaptively. The weight convergences and the Nash-optimization MMDLS stability are all proved. Finally, numerical MMDLS simulations are implemented to show the correctness and the improved performance of the proposed methods.
Related Concept Videos
 01:28
Load-frequency control
 01:18
Hierarchy of Motor Control
 01:14
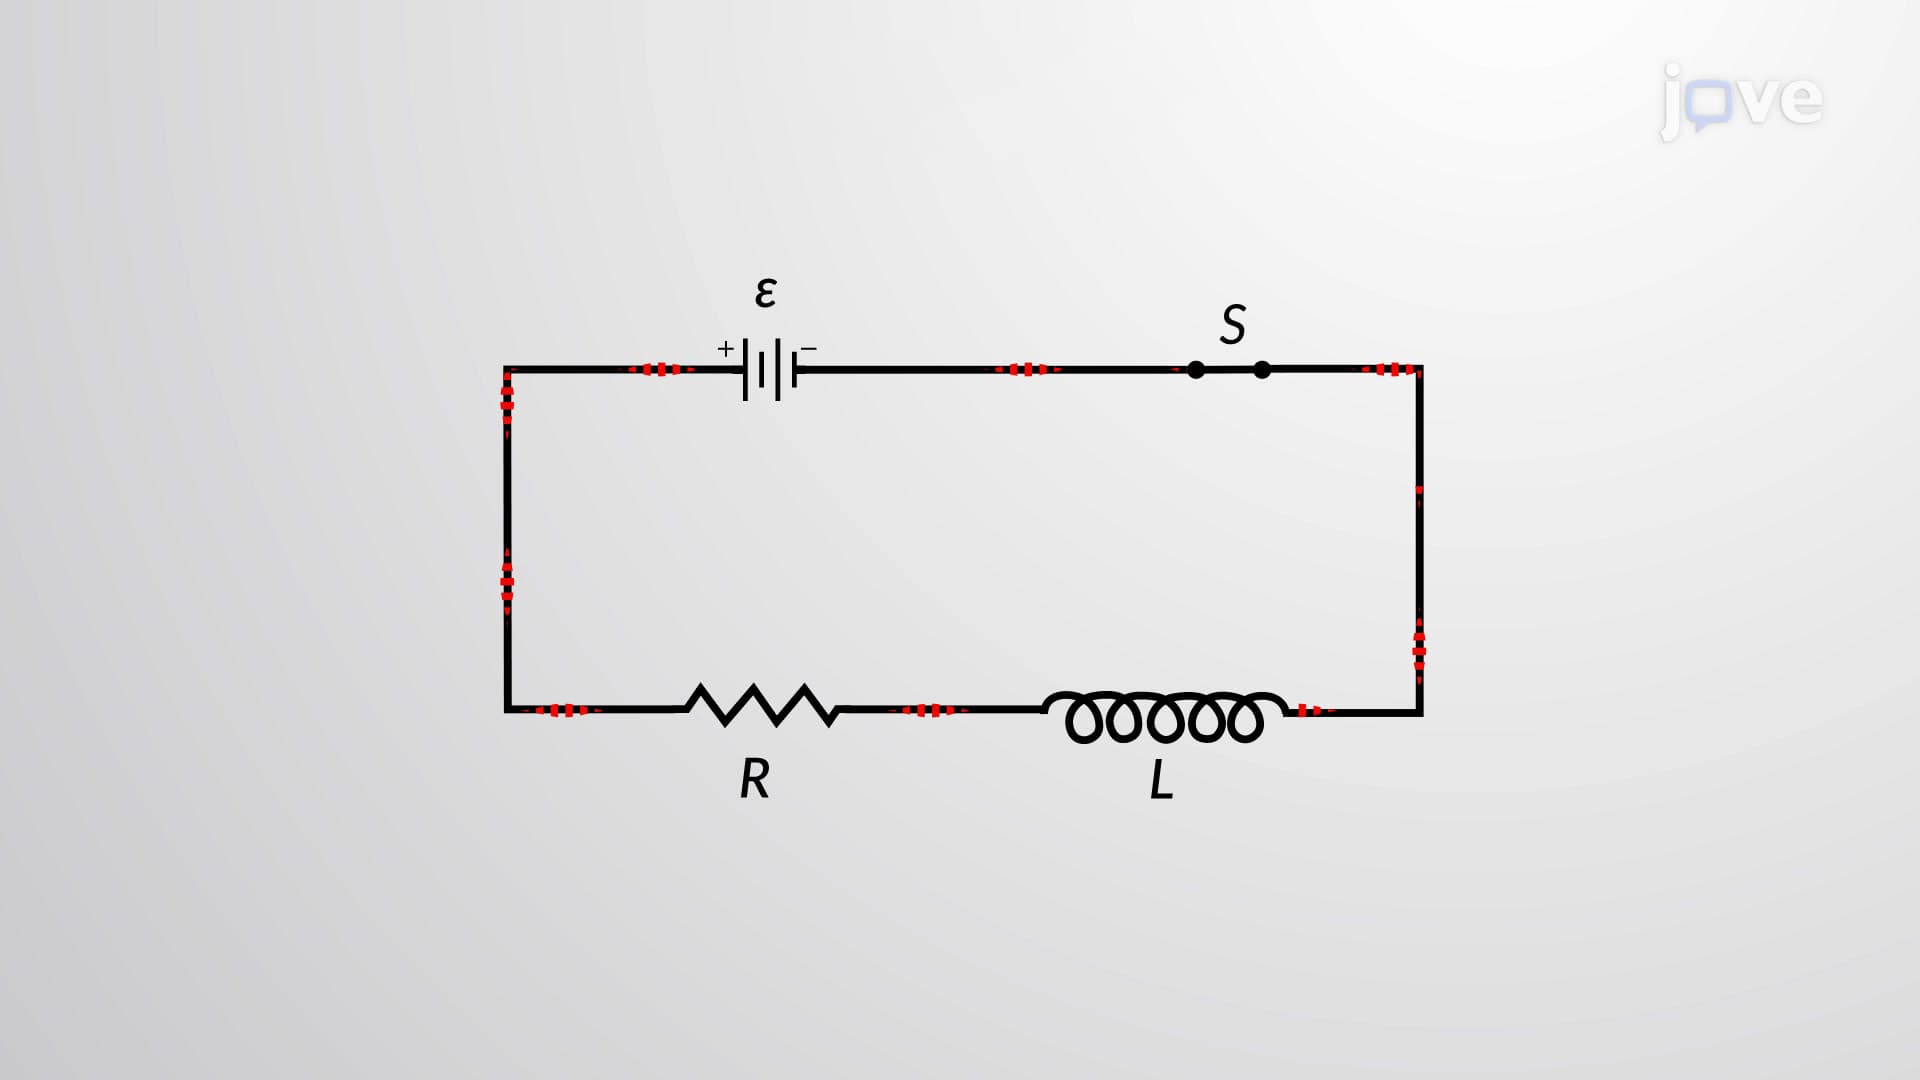
RL Circuits
 01:34
The Z-Scheme of Electron Transport in Photosynthesis
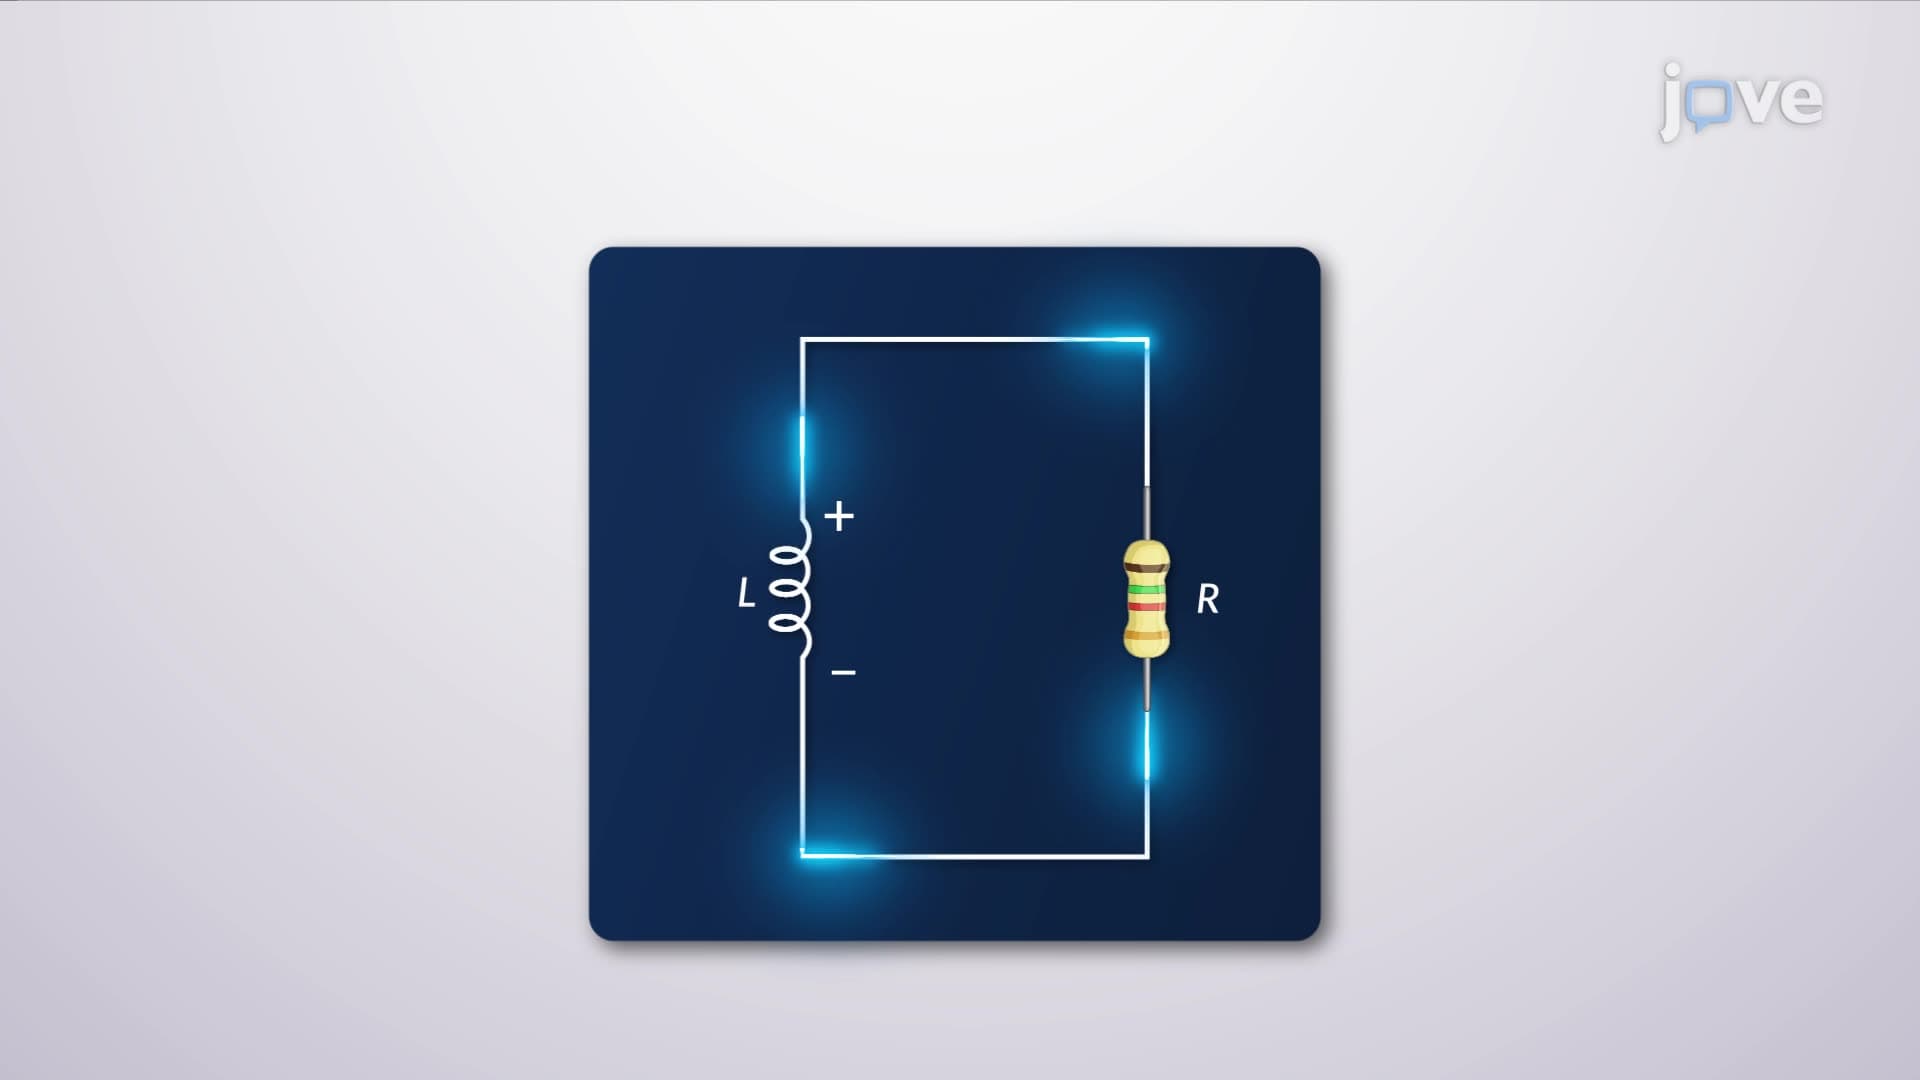 01:14
RL Circuit without Source
Applying Kirchhoff's voltage law around the loop of the circuit and substituting the voltages across the inductor and resistor yields a first-order differential equation. A logarithmic equation is obtained by rearranging the terms in this equation,...
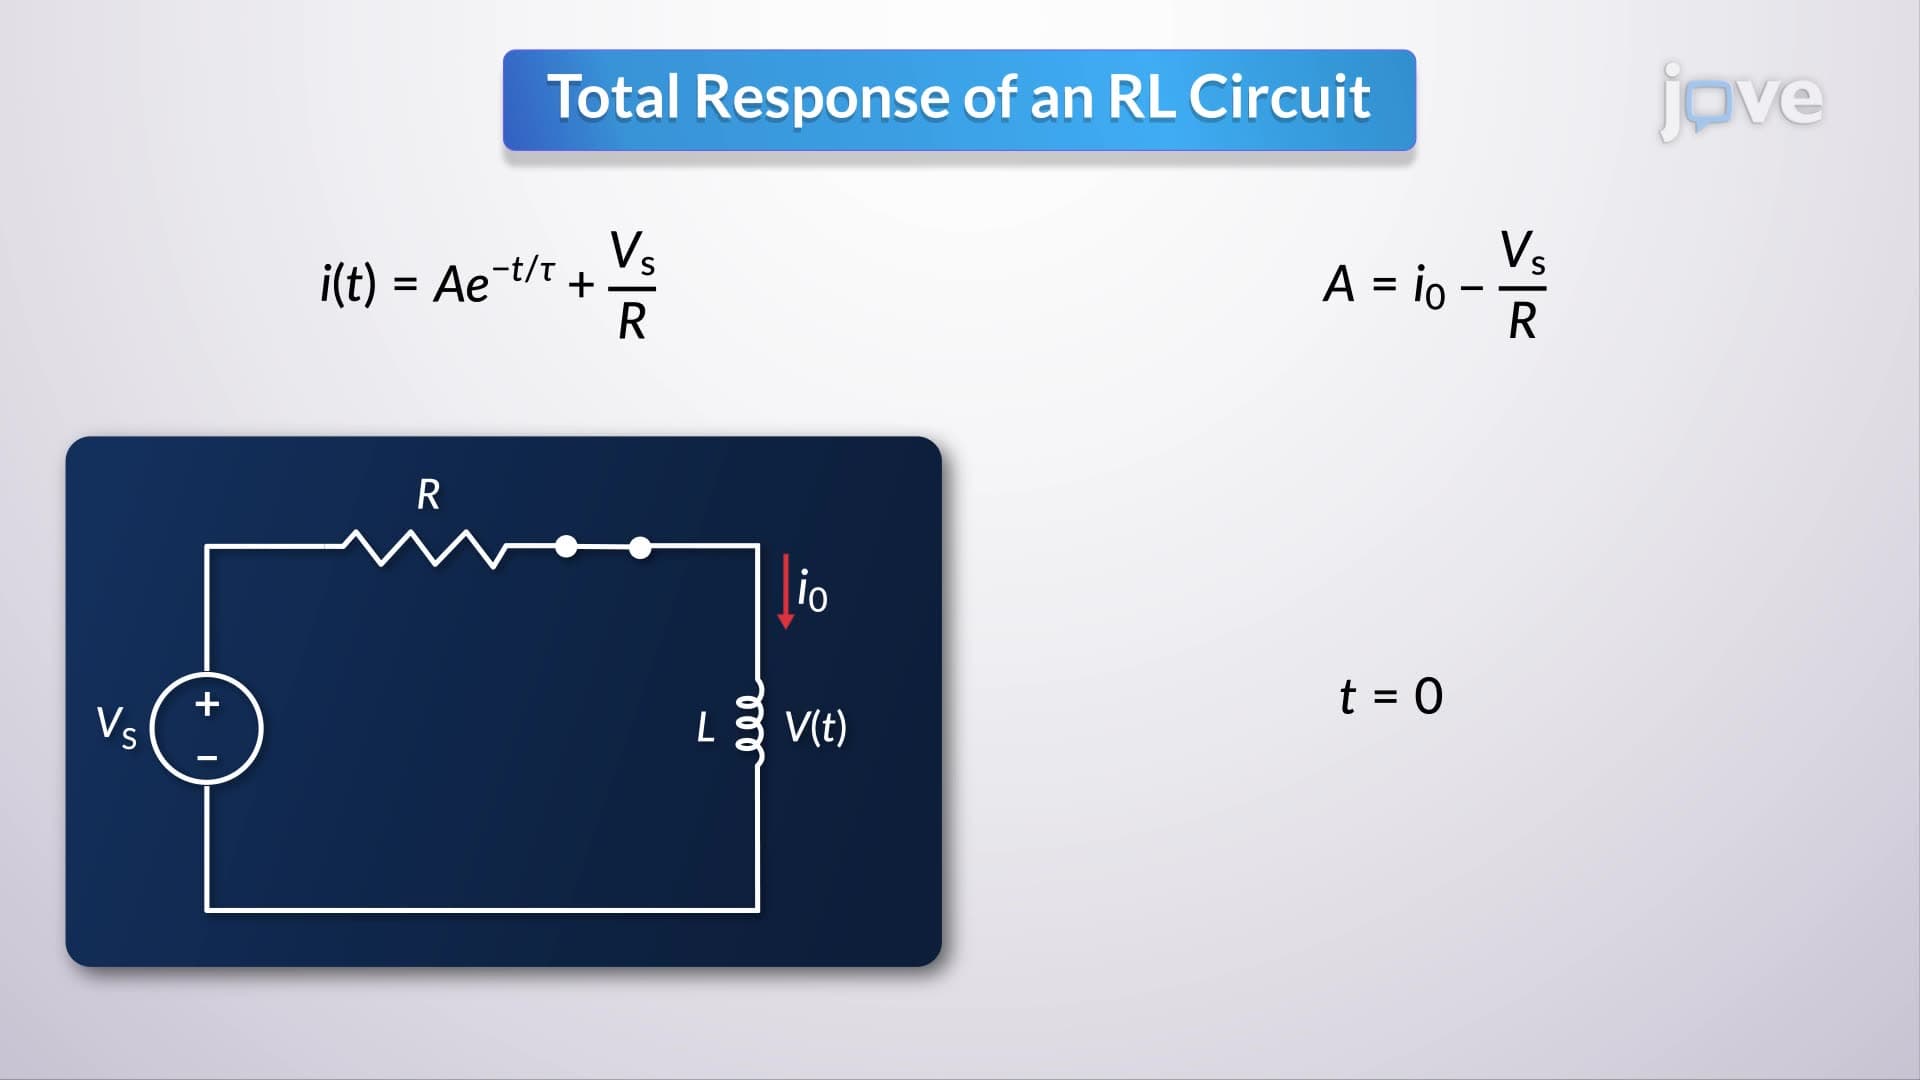 01:14
RL Circuit with Source
The transient response of the circuit is its temporary reaction to the sudden application of the DC source. This response is characterized by a current that exponentially decays to zero as time approaches infinity. During this transitional period, the inductor behaves like a short circuit, causing the source...