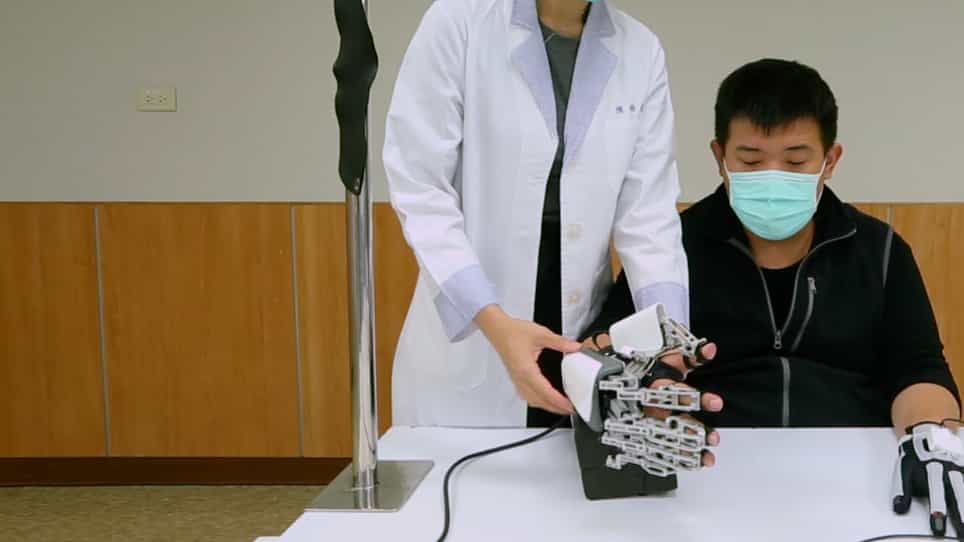
Related Experiment Video
Updated: Dec 28, 2025

Estimation of Contact Regions Between Hands and Objects During Human Multi-Digit Grasping
Published on: April 21, 2023
Grasp Prediction Toward Naturalistic Exoskeleton Glove Control
Raghuraj Chauhan1, Bijo Sebastian1, Pinhas Ben-Tzvi1
1Robotics and Mechatronics Lab, Mechanical Engineering Department, Virginia Polytechnic Institute and State University, Blacks-burg, VA 24060 USA.

Abstract:
This paper presents accurate grasp prediction algorithms that can be used for naturalistic, synergistic control of exoskeleton gloves with minimal user input. Recent research in exoskeleton systems has focused mainly on the development of novel soft or hard mechanical designs and actuation systems for rehabilitative and assistive applications. On the other hand, estimating user intent for intelligent grasp assistance is a problem that has remained largely unaddressed. As demonstrated by existing studies, the complex motions of human hand can be mapped to a latent space, thereby reducing perceived noise in individual joint angles as well as the number of variables upon which the prediction must be performed. To this extent, we present two latent space grasp prediction algorithms for intelligent exoskeleton glove control. The first presented algorithm is based on a linear regression to determine the slope and prediction horizon. The second algorithm is based on a Gaussian process trajectory matching where the trajectory of the grasping motion is probabilistically compared to existing data in order to form a prediction. Both algorithms were tested on published motion data collected from healthy subjects. In addition, the experimental validation of the algorithms was done using the RML glove (Robotics and Mechatronics Lab), which yielded similar prediction accuracy as compared to the simulation results. The proposed prediction algorithm can act as the backbone for a shifting authority controller that simultaneously amplifies the user's motion while guiding them toward their desired grasp. Preliminary work in this direction is also described in the paper, with directions for future research.