Real-time collision avoidance planning for unmanned surface vessels based on field theory
Related Experiment Video
Updated: Dec 14, 2025
Quantitatively Measuring In situ Flows using a Self-Contained Underwater Velocimetry Apparatus SCUVA
Published on: October 31, 2011
Yun Li1, Jian Zheng2
1Merchant Marine College, Shanghai Maritime University, Shanghai 201306, China.

Abstract:
With the development of commercial application of unmanned surface vessels, the real-time collision avoidance is the research focus on the multi-vessels situation, the structure complexity and time consumption problem limit its efficiency. To simplify the complex model and enhance the collision avoidance performance, the field theory is used to describe the navigation of ships abstractly, from which a more simplified optimization model of collision avoidance is derived, so the synthetic field regarding the virtual spatial electric field and velocity field is presented to exhibit the situation of ship motion. On the basis of the field environment, the more simplified collision avoidance model is designed, combining with the improved Electromagnetism-like mechanism algorithm, to generate the optimal collision avoidance strategy, for considering the energy and other loss. The complete algorithm has been compared and validated under the different layout, it is worth mentioning that the algorithm can potentially be developed to advance collision-free navigation in multi-vessels situation.
More Related Videos
 06:28
A Networked Desktop Virtual Reality Setup for Decision Science and Navigation Experiments with Multiple Participants
Published on: August 26, 2018
 07:52
Author Spotlight: Advancing Human Brain Modulation – Optimized Protocols for Transcranial Ultrasound Stimulation Experiments
Published on: June 28, 2024
Related Concept Videos
 01:11
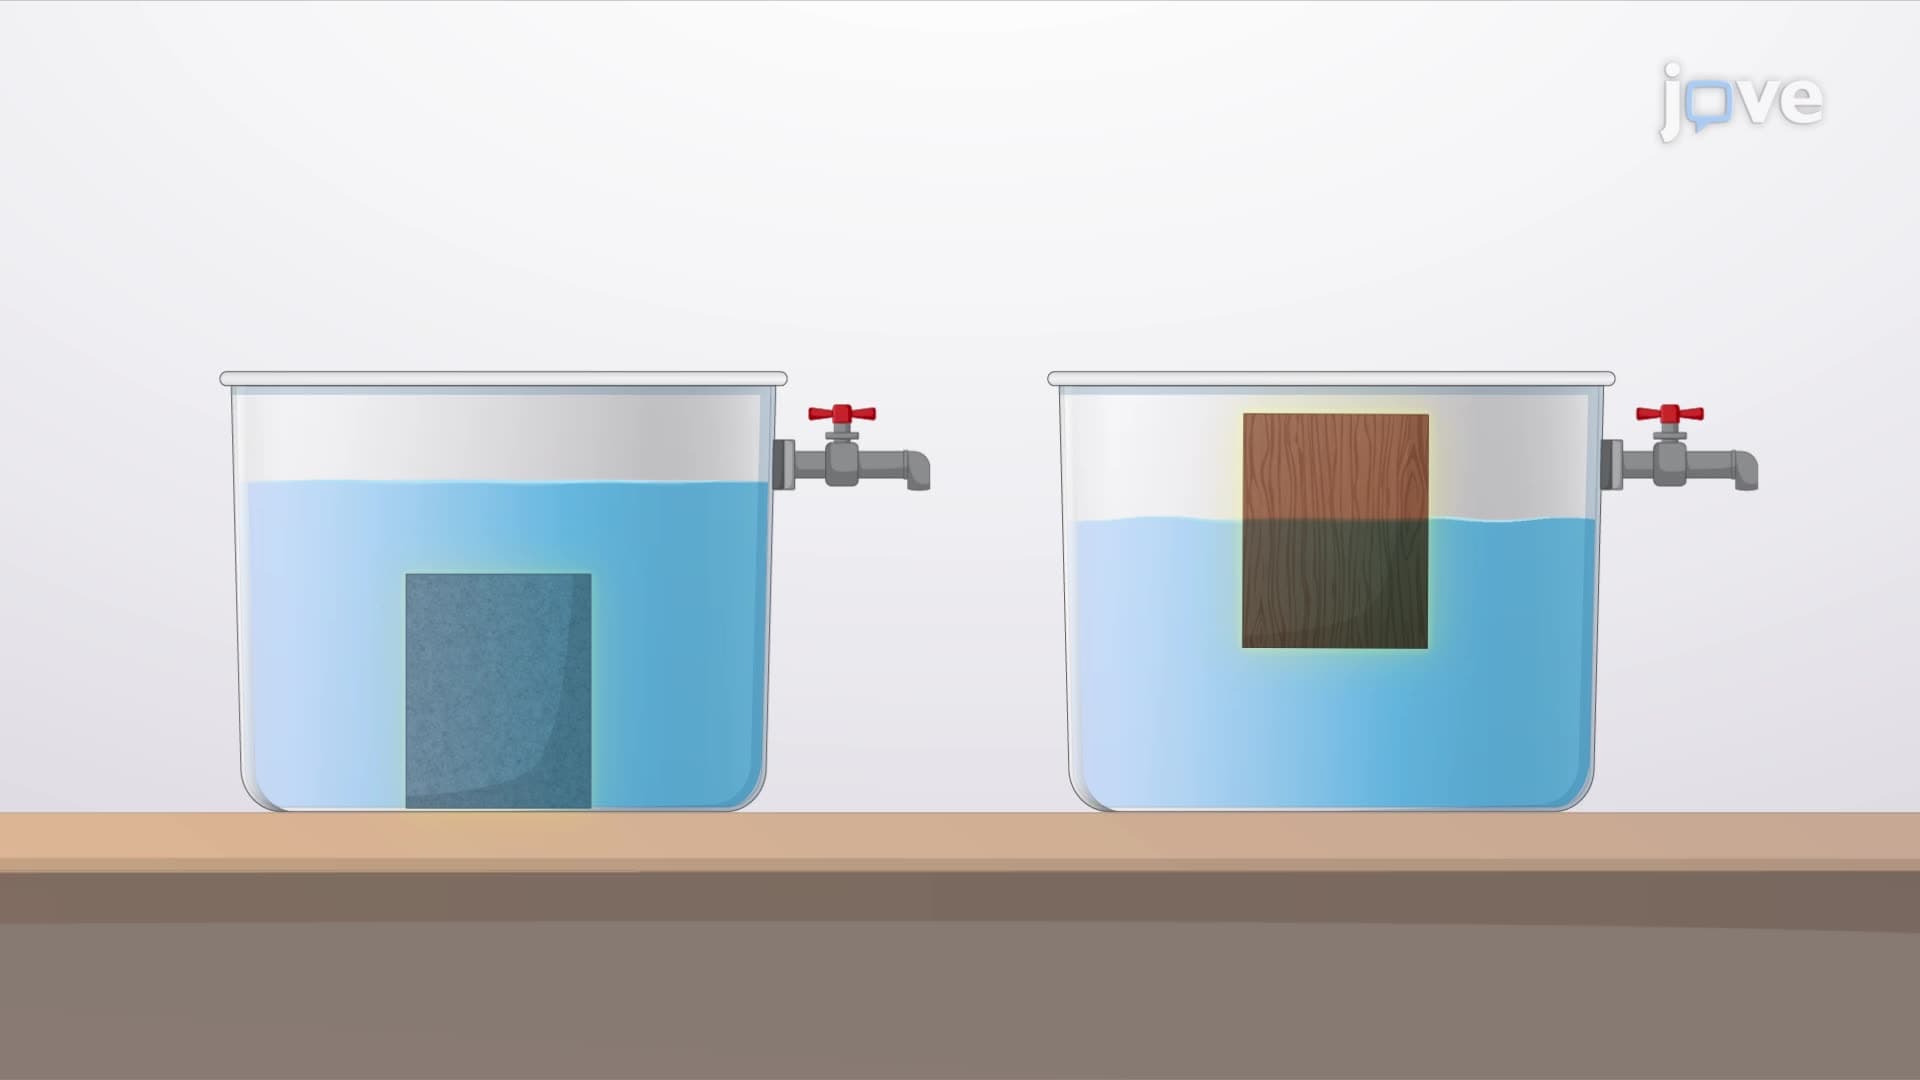
Buoyancy and Stability for Submerged and Floating Bodies
 01:18
Uniform Depth Channel Flow: Problem Solving
 01:06
Collisions in Multiple Dimensions: Problem Solving
A small car of mass 1,200 kg traveling east at 60 km/h collides at an intersection with a truck of mass 3,000 kg traveling due north at 40 km/h. The two vehicles are locked together. What is the...
 01:15
Elastic Collisions: Case Study
 01:10
Design Example: Measuring Distance Between Two Points with Obstructions
 01:30
Typical Model Studies