Related Experiment Video
Updated: Dec 12, 2025

The Modular Design and Production of an Intelligent Robot Based on a Closed-Loop Control Strategy
Published on: October 14, 2017
Robust ADP-based solution of a class of nonlinear multi-agent systems with input saturation and collision avoidance
Saeed Khankalantary1, Iman Izadi1, Farid Sheikholeslam1
1Department of Electrical and Computer Engineering, Isfahan University of Technology, Isfahan 84156-83111, Iran.

Abstract:
In this paper, robust tracking control for a class of nonlinear systems with external disturbance in the presence of input saturation and collision avoidance constraints is investigated. Both of these constraints are considered in a non-quadratic cost function. To obtain optimal control laws, a technique is proposed based on adaptive dynamic programming (ADP) assuming the worst case of disturbance, and without requiring any knowledge of the system dynamics. The proposed algorithm uses neural networks to estimate the optimal cost functions, control policies, and the worst case of disturbance. The Lyapunov theory is used to analyze the convergence of the estimations. Simulation results show the effectiveness of the developed ADP method.

Related Concept Videos
 01:06
Collisions in Multiple Dimensions: Problem Solving
A small car of mass 1,200 kg traveling east at 60 km/h collides at an intersection with a truck of mass 3,000 kg traveling due north at 40 km/h. The two vehicles are locked together. What is the...
 01:29
Mechanistic Models: Compartment Models in Algorithms for Numerical Problem Solving
In individual population analyses, different algorithms are employed, such as Cauchy's method, which uses a...
 01:16
Statically Indeterminate Problem Solving
 01:13
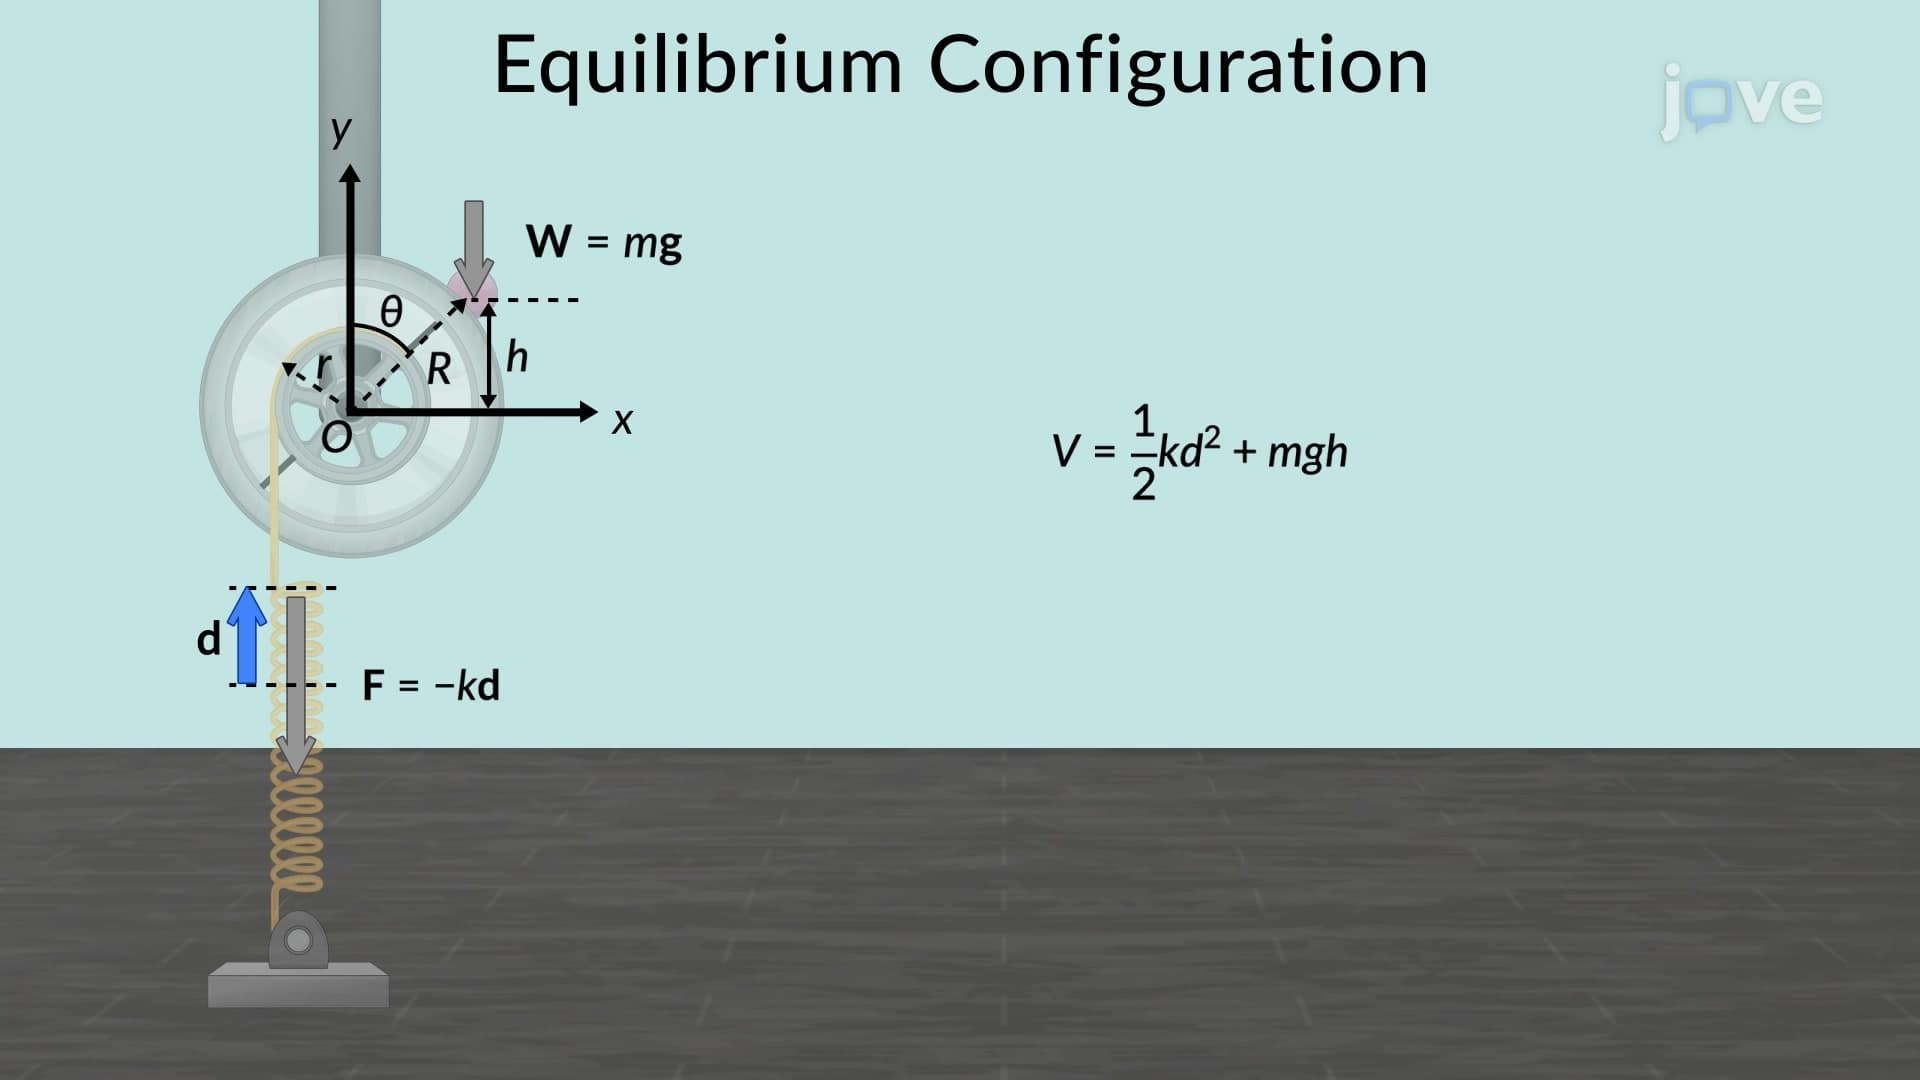
Stability of Equilibrium Configuration: Problem Solving
Problem-solving in the context of the stability of equilibrium configuration...
 01:59
Solution Equilibrium and Saturation
 01:27
State Space Representation
Consider an RLC circuit, a...