Velocity estimation of flexible dynamics systems using virtual sensing
Related Experiment Video
Updated: Dec 6, 2025
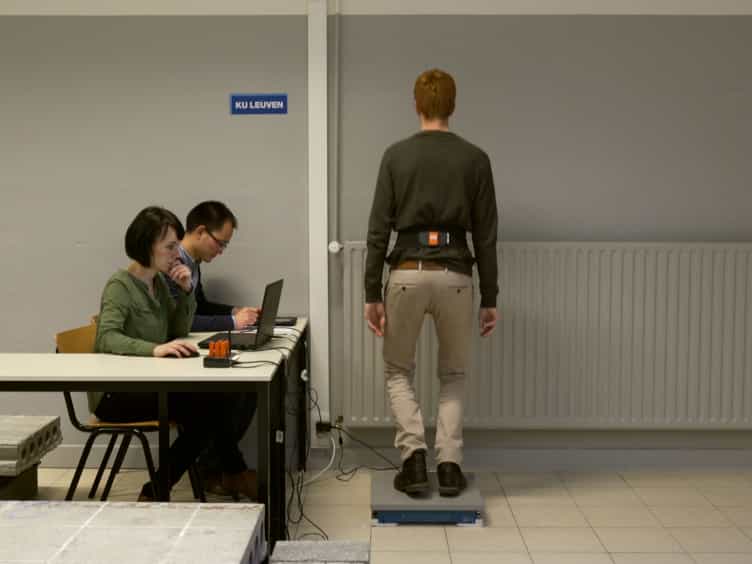
Simulation of Human-induced Vibrations Based on the Characterized In-field Pedestrian Behavior
Published on: April 13, 2016
Alireza Naderi Akhormeh1, Hoomaan MoradiMaryamnegari2, Abdol Majid Khoshnood3
1Aerospace Engineering Department, K.N. Toosi University of Technology, Tehran, Iran.

Abstract:
In this paper, multiple virtual sensors derived from the equations of motion of a flexible dynamics system, are utilized to form a novel virtual sensing system able to estimate the angular and translation velocities. Measuring only the elastic displacement of the flexible body by a strain gauge, angular velocities are estimated by the first virtual sensor composed of a kinetics equation related to the flexibility, and the nonlinear Kalman and particle filters. Moreover, for translational velocities to be also estimated, specific forces are measured by accelerometers. The second virtual sensor including the equation of translational motion, is added to the virtual sensing system, leading not only the velocities to be estimated with high performance but the accumulated errors of the sensors to be corrected.
Related Concept Videos
 01:06
Virtual Work for a System of Connected Rigid Bodies
Next,...
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
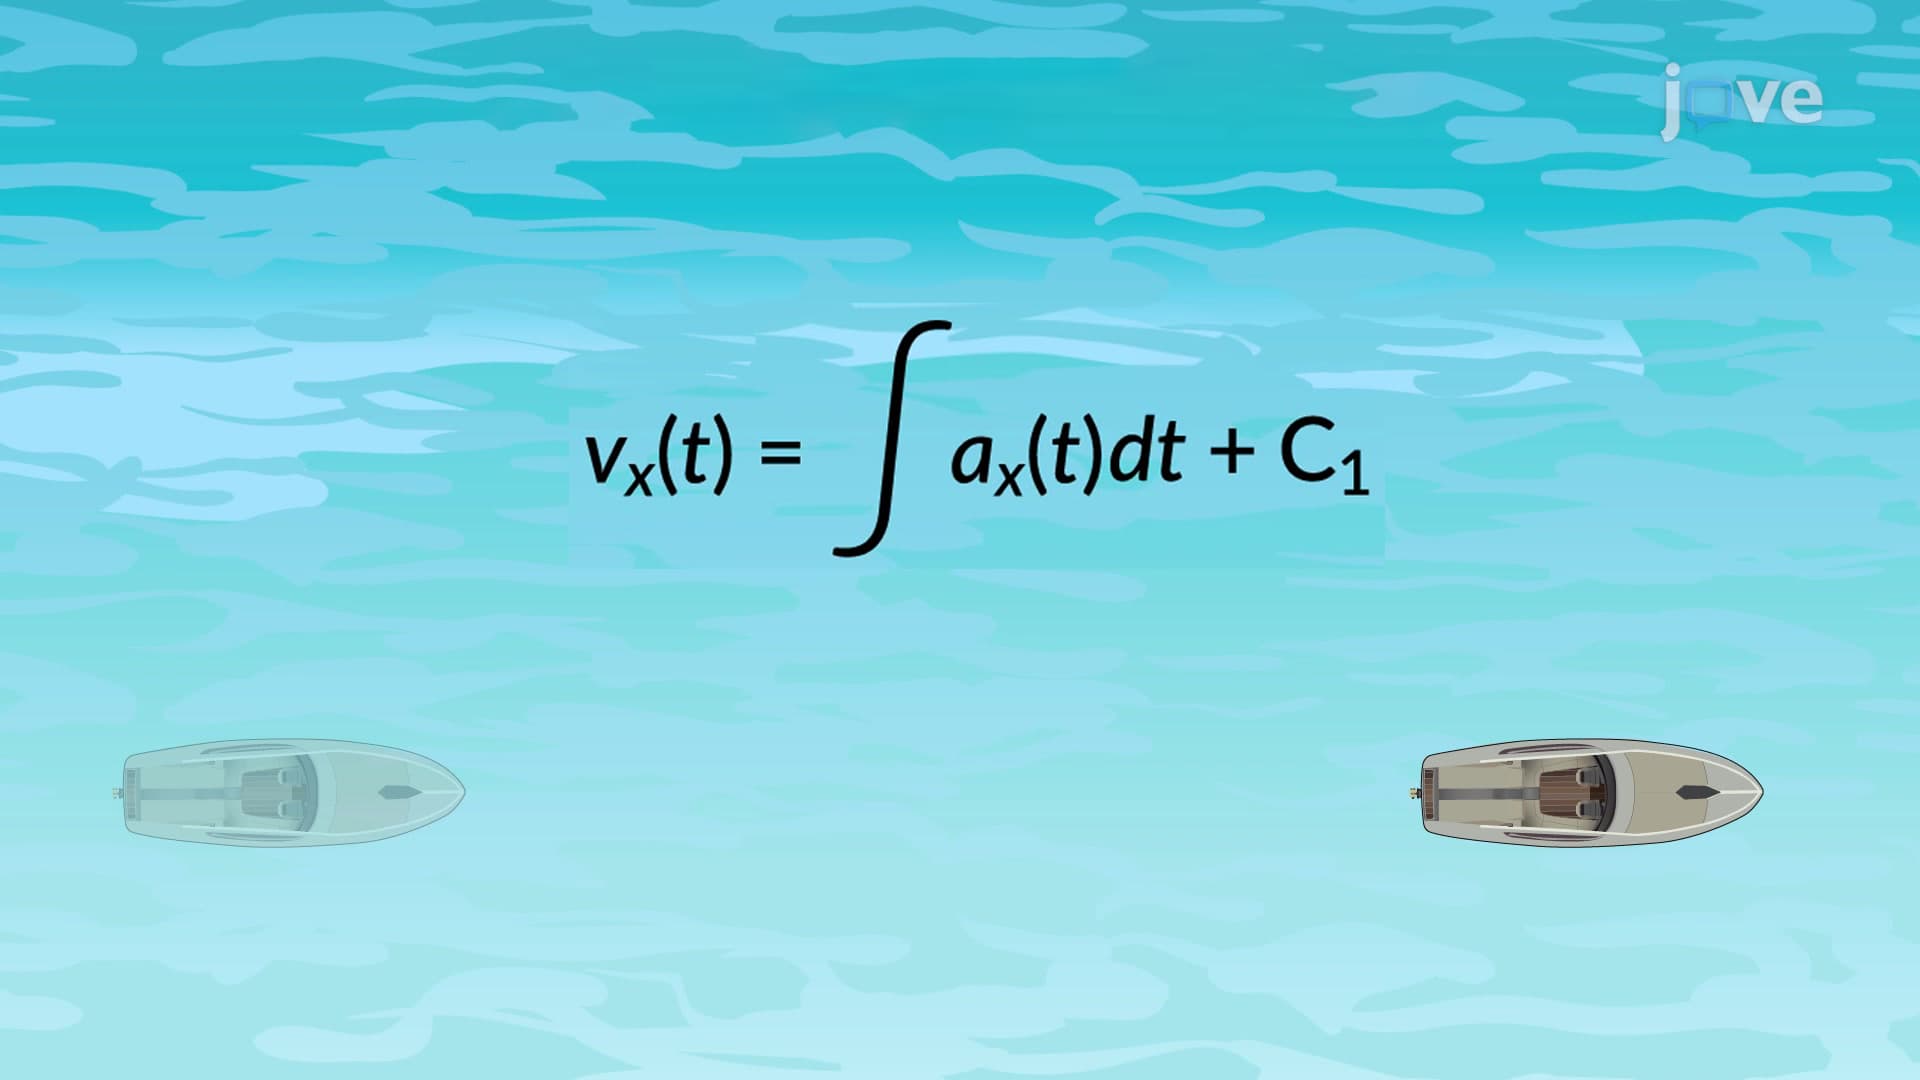 01:13
Velocity and Position by Integral Method
Consider an example to calculate the velocity and position from the acceleration function. A motorboat is traveling at a constant velocity of 5.0 m/s when it starts to decelerate to arrive at the dock. Its acceleration is...
 01:30
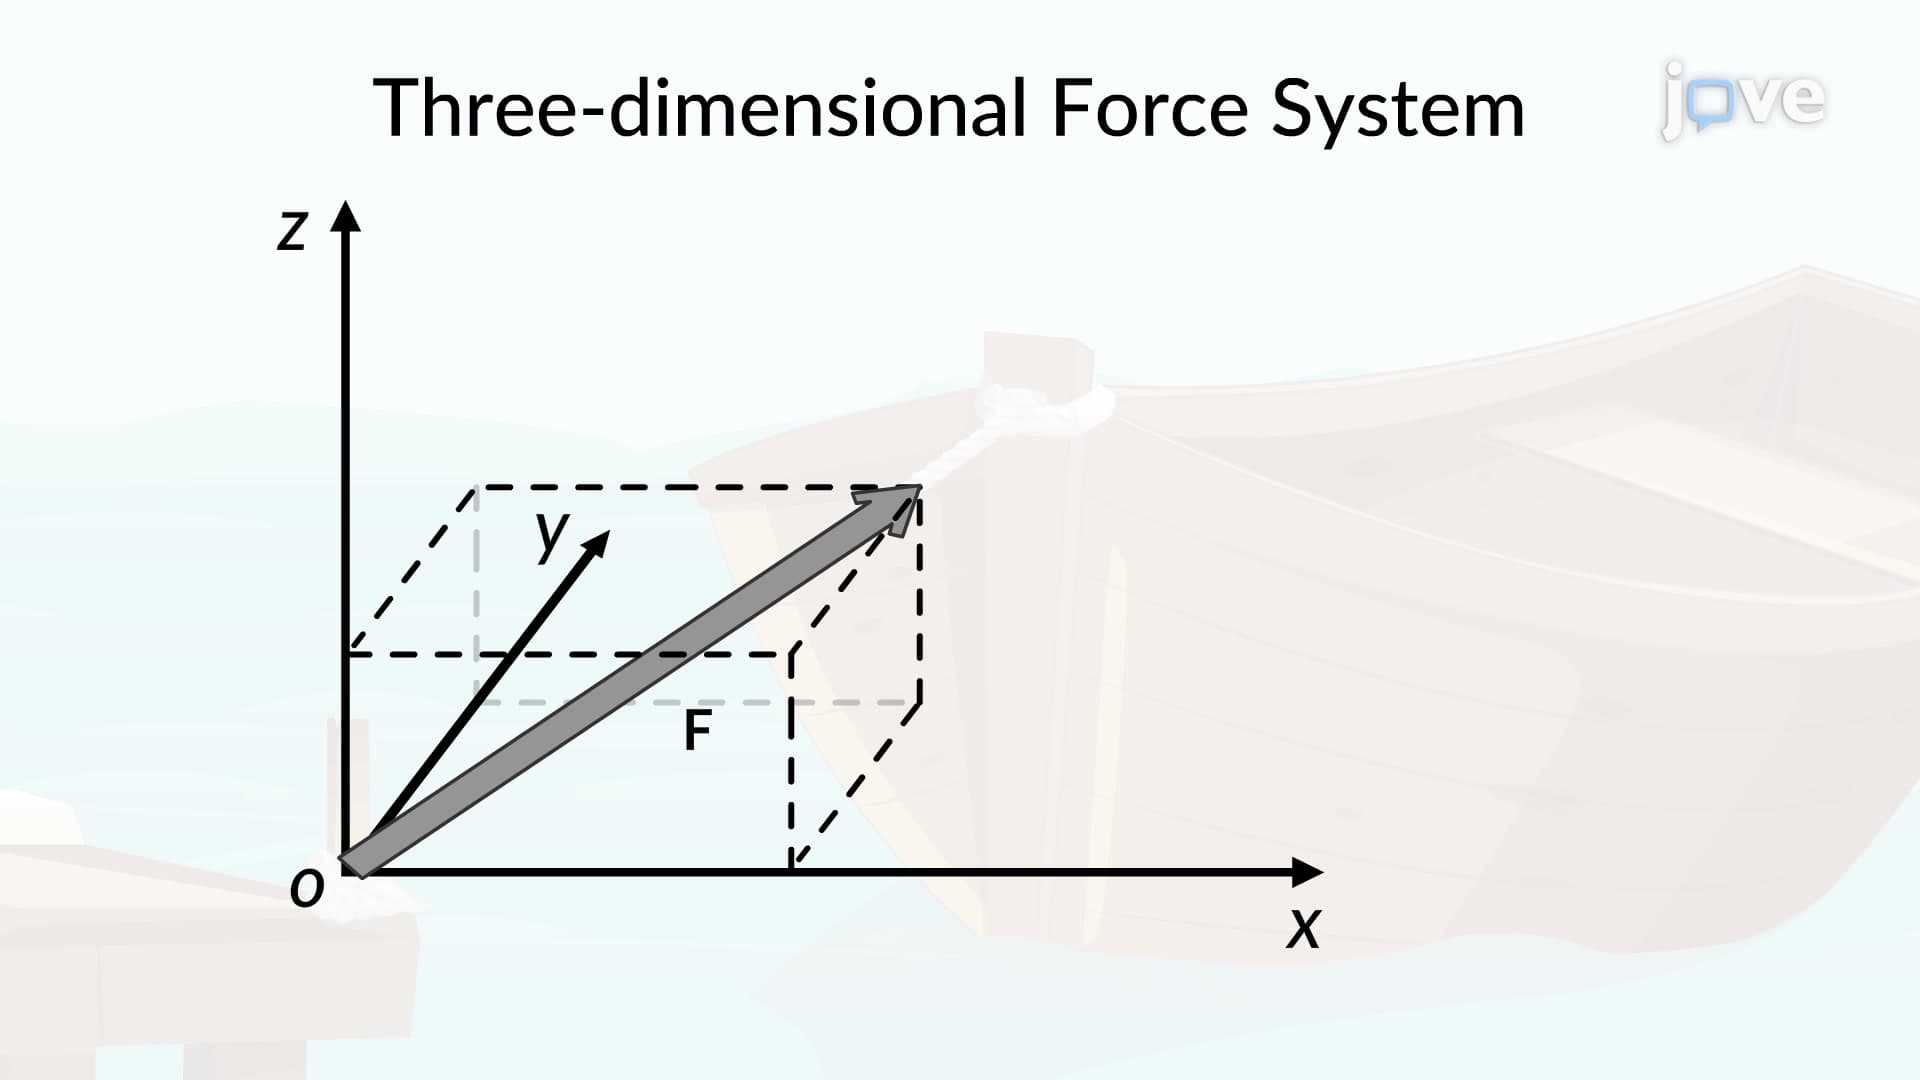
Three-Dimensional Force System