Contact transition control with acceleration feedback enhancement for a quadrotor
Related Experiment Video
Updated: Nov 27, 2025

Method to Measure Tone of Axial and Proximal Muscle
Published on: December 14, 2011
Kui Yi1, Jianda Han2, Xiao Liang2
1State Key Laboratory of Robotics, Shenyang Institute of Automation, Chinese Academy of Sciences, Shenyang 110016, PR China; Institutes for Robotics and Intelligent Manufacturing, Chinese Academy of Sciences, Shenyang 110169, PR China; University of Chinese Academy of Sciences, Beijing 100049, PR China.

Abstract:
A stable transition from free-motion to contact phase is extremely significant for a UAV interacting with its objects and environment. Oscillations may occur at the contact point if the force controller of the UAV fails to accommodate to the environment parameters, which are usually unknown to the UAV. In this paper, the acceleration feedback control is proposed to enhance the robustness of a classic force controller. This intends to achieve a smooth and stable contact transition of the UAV while interacting with different stiffness environments with non-zero approaching velocity. Extensive flight tests are conducted on a quadrotor UAV to verify the performance of the proposed algorithm with respect to different-stiffness environments. The experimental results are also compared with those without the acceleration feedback enhancement, to demonstrate the improvement of the proposed scheme.

Related Concept Videos
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:16
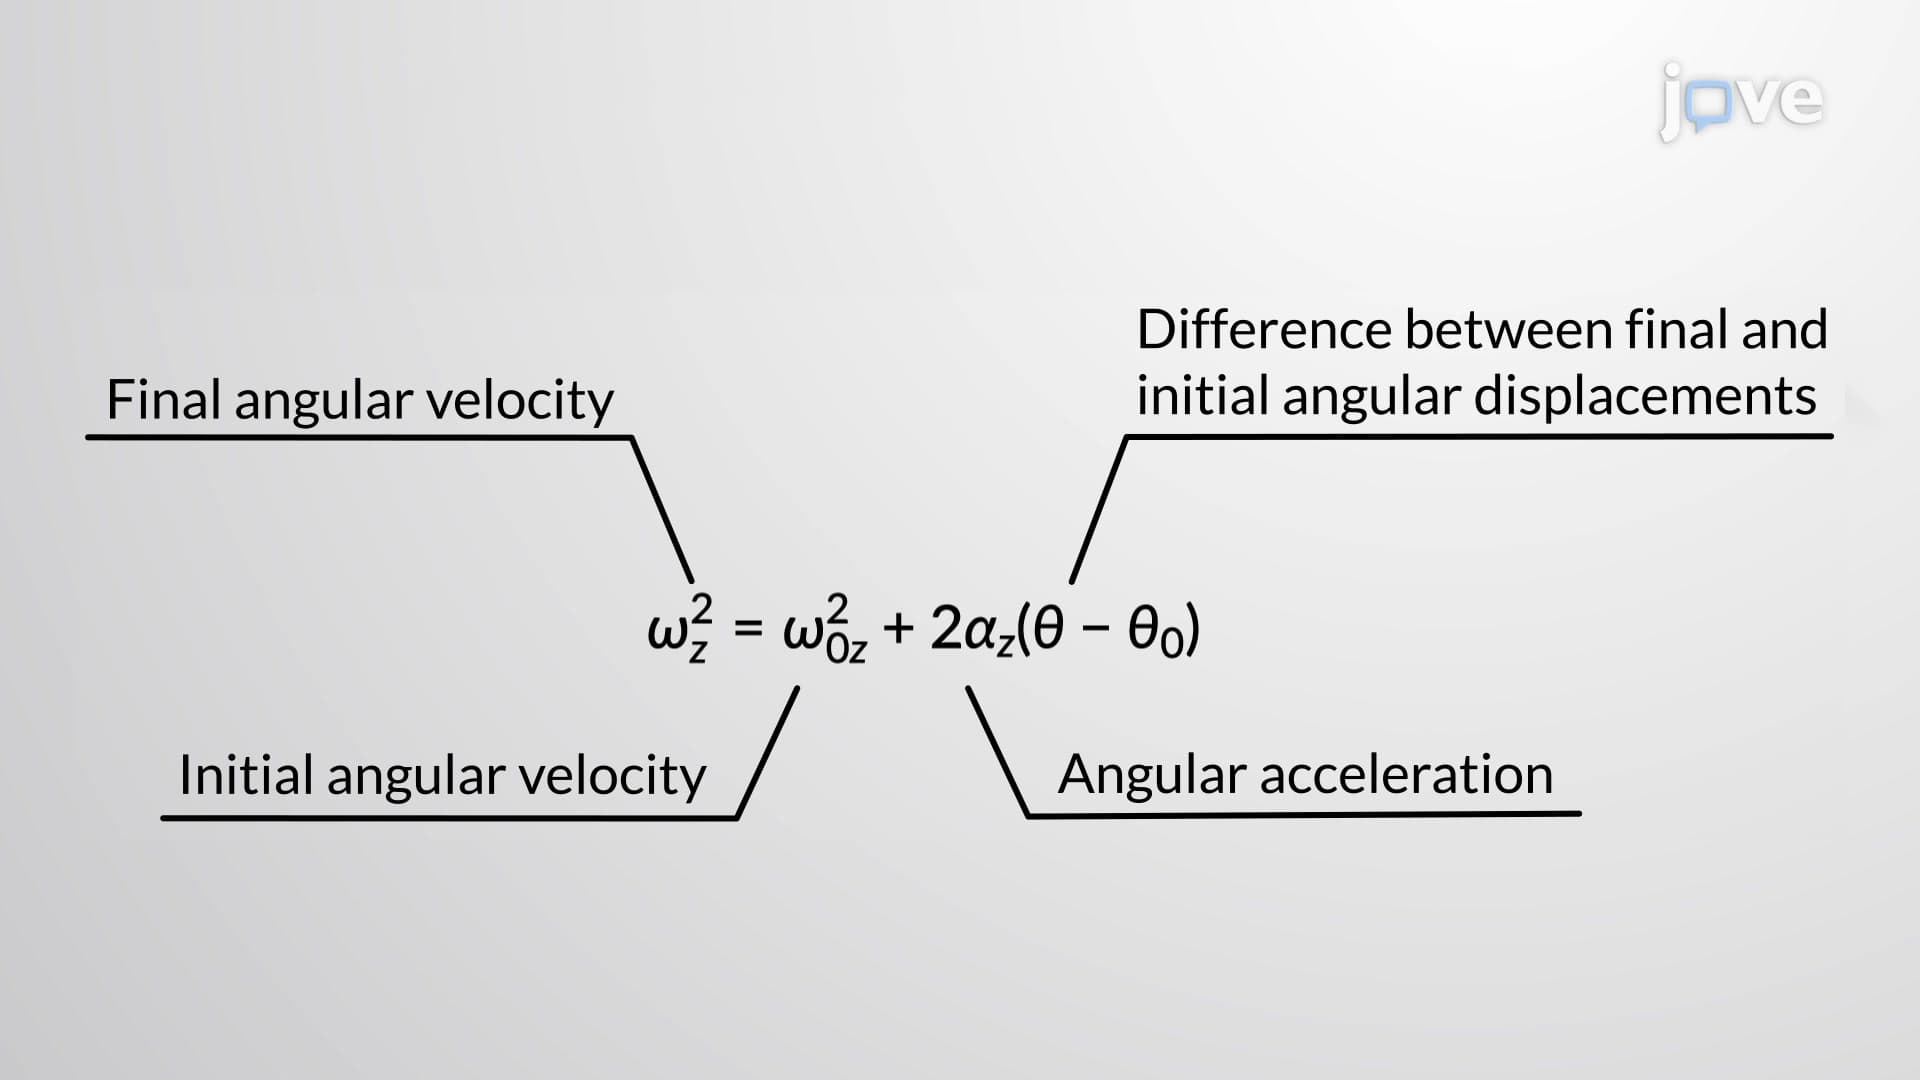
Rotation with Constant Angular Acceleration - II
The first...
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...
 01:37
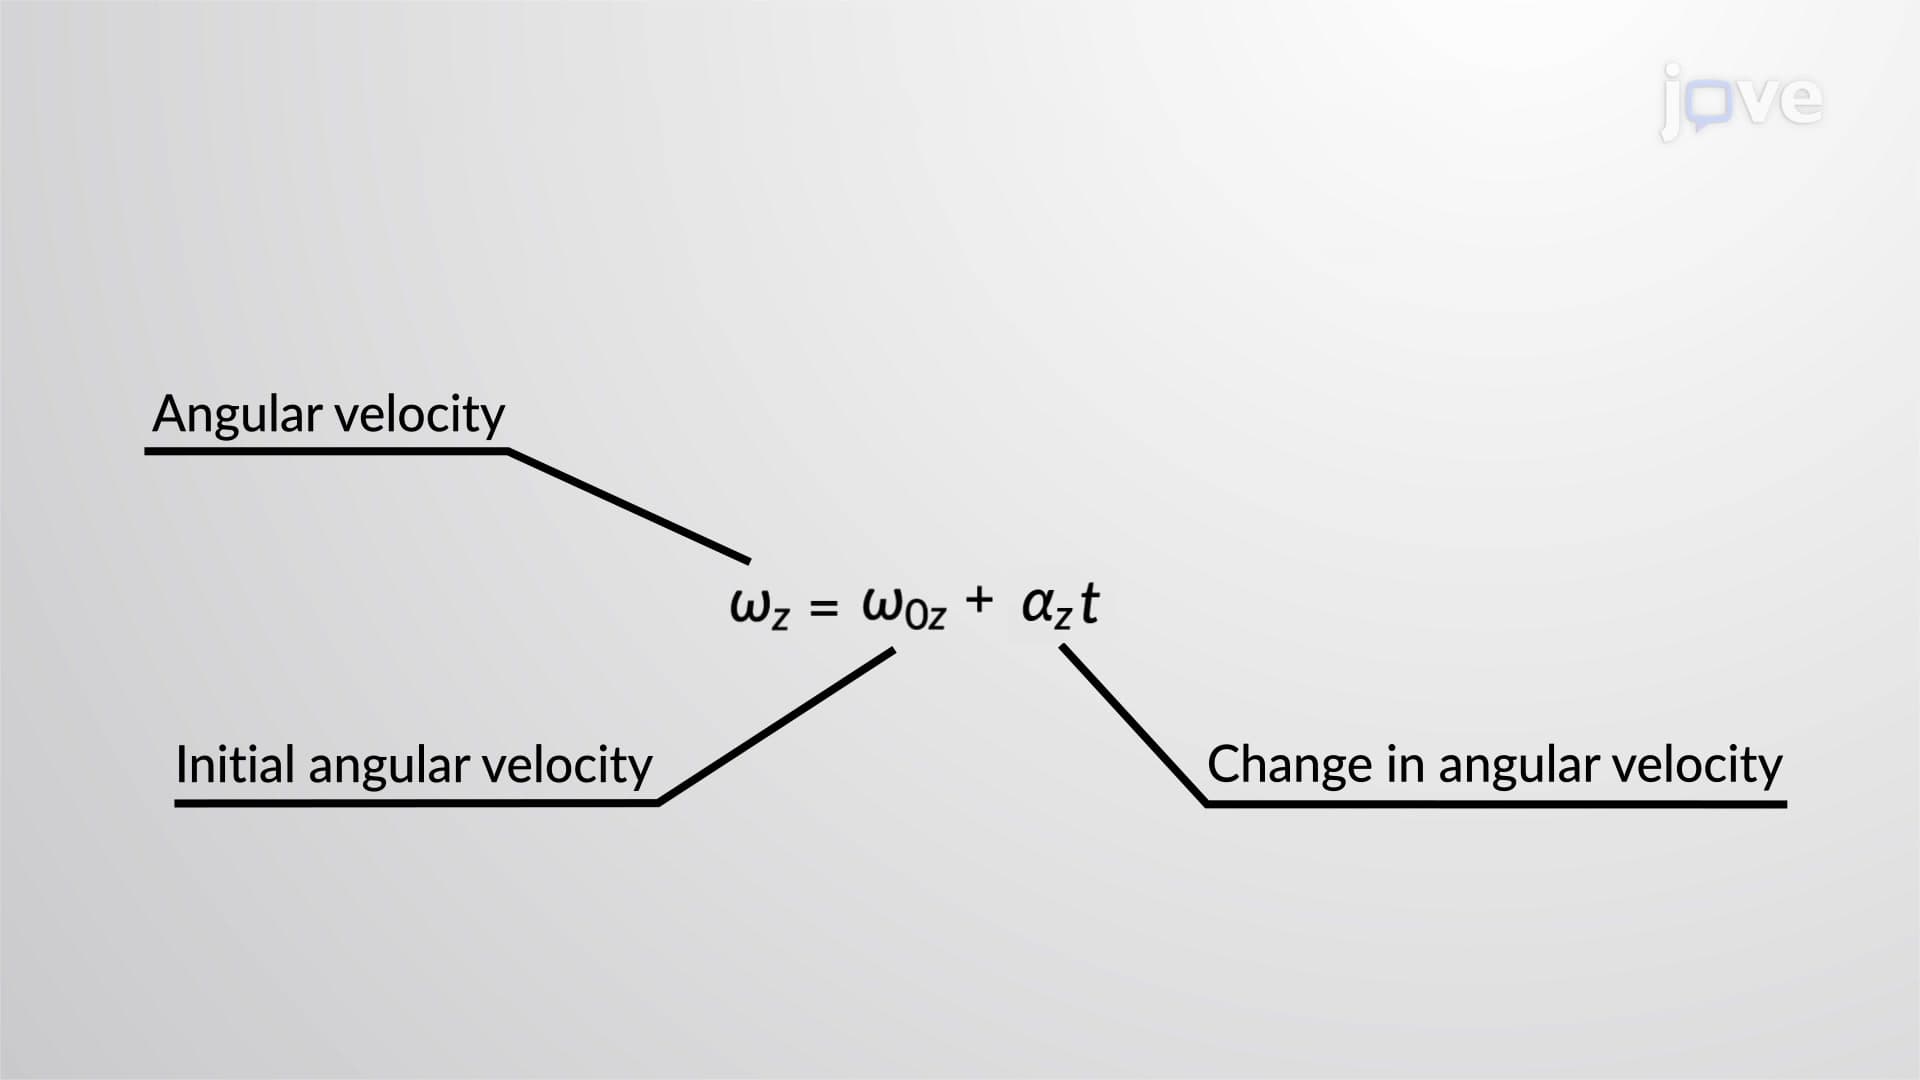
Rotation with Constant Angular Acceleration - I
Using our intuition, we can begin to see how rotational quantities such as angular displacement, angular velocity, angular acceleration, and time are related to one another. For example, if a flywheel...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...