Transportation and swing reduction for double-pendulum tower cranes using partial enhanced-coupling nonlinear controller with initial saturation
Related Experiment Video
Updated: Nov 27, 2025
Author Spotlight: Enhancing Engineering Education via WebVR-Based Online Laboratories
Published on: February 23, 2024
Zheng Tian1, Lili Yu1, Huimin Ouyang1
1College of Electrical Engineering and Control Science, Nanjing Tech University, No.30, Puzhu Road(s), Nanjing, 211816, China.

Abstract:
Achieving both jib and trolley positioning and swing reduction become more difficult when tower cranes appear double-pendulum characteristic in dynamic. Moreover, in actual applications, the initial output value of actuators is usually physically constrained and the model uncertainties and external disturbances always exist. To solve these problems, a partial enhanced-coupling nonlinear controller with initial saturation is designed and analyzed by Lyapunov technique and LaSalle's invariance theorem. The control performance and strong robustness are severally verified by lots of simulations.

Related Concept Videos
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:14
Stability of structures
 01:06
Forced Oscillations
 01:09
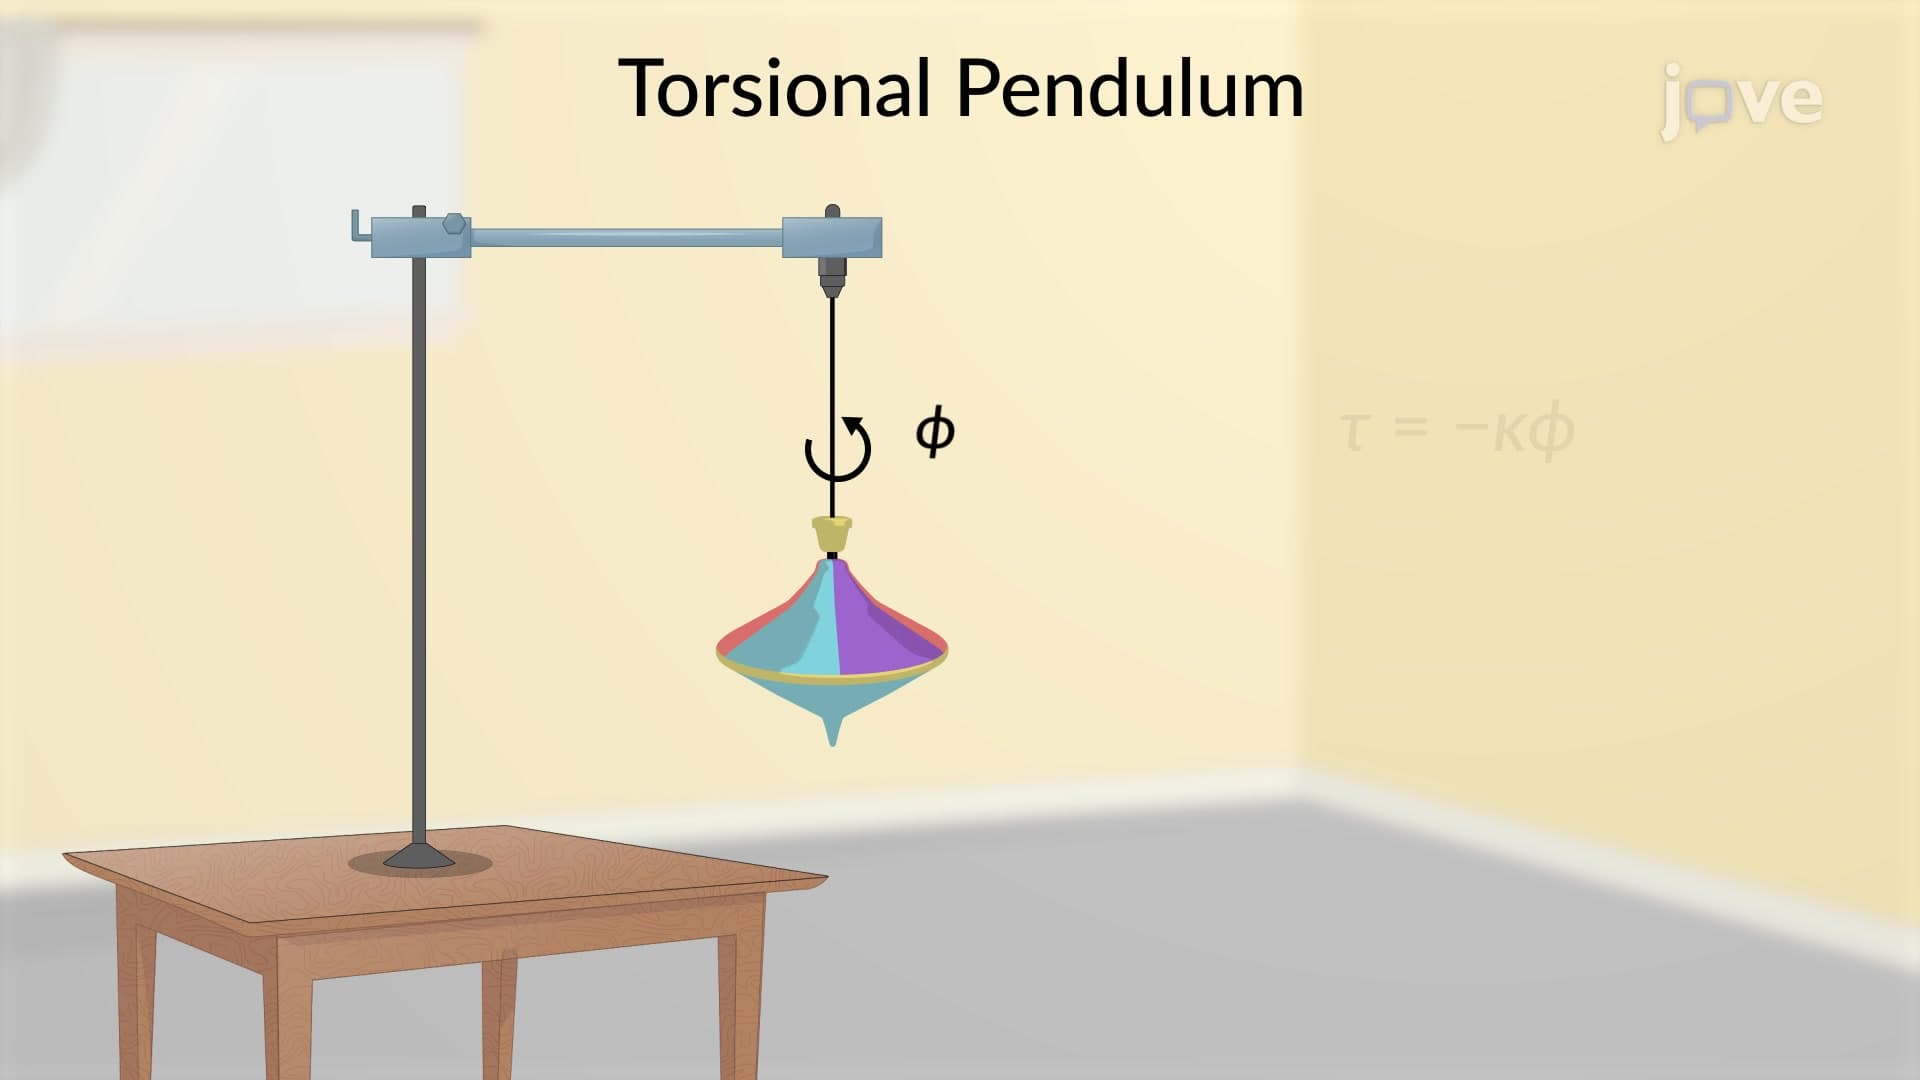
Torsional Pendulum
As long as the rigid body's angular displacement is small, its oscillation can be modeled as a linear angular oscillation. The amplitude of the oscillation is an angle. The role of mass is played...
 01:19
Concept of Resonance and its Characteristics