Related Experiment Video
Updated: Nov 22, 2025


Closed-loop Neuro-robotic Experiments to Test Computational Properties of Neuronal Networks
Published on: March 2, 2015
Neural Network Based Contact Force Control Algorithm for Walking Robots
1Department of Mechanical Engineering, KAIST, Daejeon 34141, Korea.

Abstract:
Walking algorithms using push-off improve moving efficiency and disturbance rejection performance. However, the algorithm based on classical contact force control requires an exact model or a Force/Torque sensor. This paper proposes a novel contact force control algorithm based on neural networks. The proposed model is adapted to a linear quadratic regulator for position control and balance. The results demonstrate that this neural network-based model can accurately generate force and effectively reduce errors without requiring a sensor. The effectiveness of the algorithm is assessed with the realistic test model. Compared to the Jacobian-based calculation, our algorithm significantly improves the accuracy of the force control. One step simulation was used to analyze the robustness of the algorithm. In summary, this walking control algorithm generates a push-off force with precision and enables it to reject disturbance rapidly.
More Related Videos


Related Concept Videos
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:29
Two-Dimensional Force System: Problem Solving
The first step to solving a two-dimensional force system problem is to draw a free-body diagram of the object under consideration. This diagram helps identify all the external forces acting on the object, including their...
 01:20
Two-Dimensional Force System
 01:30
Three-Dimensional Force System
 01:05
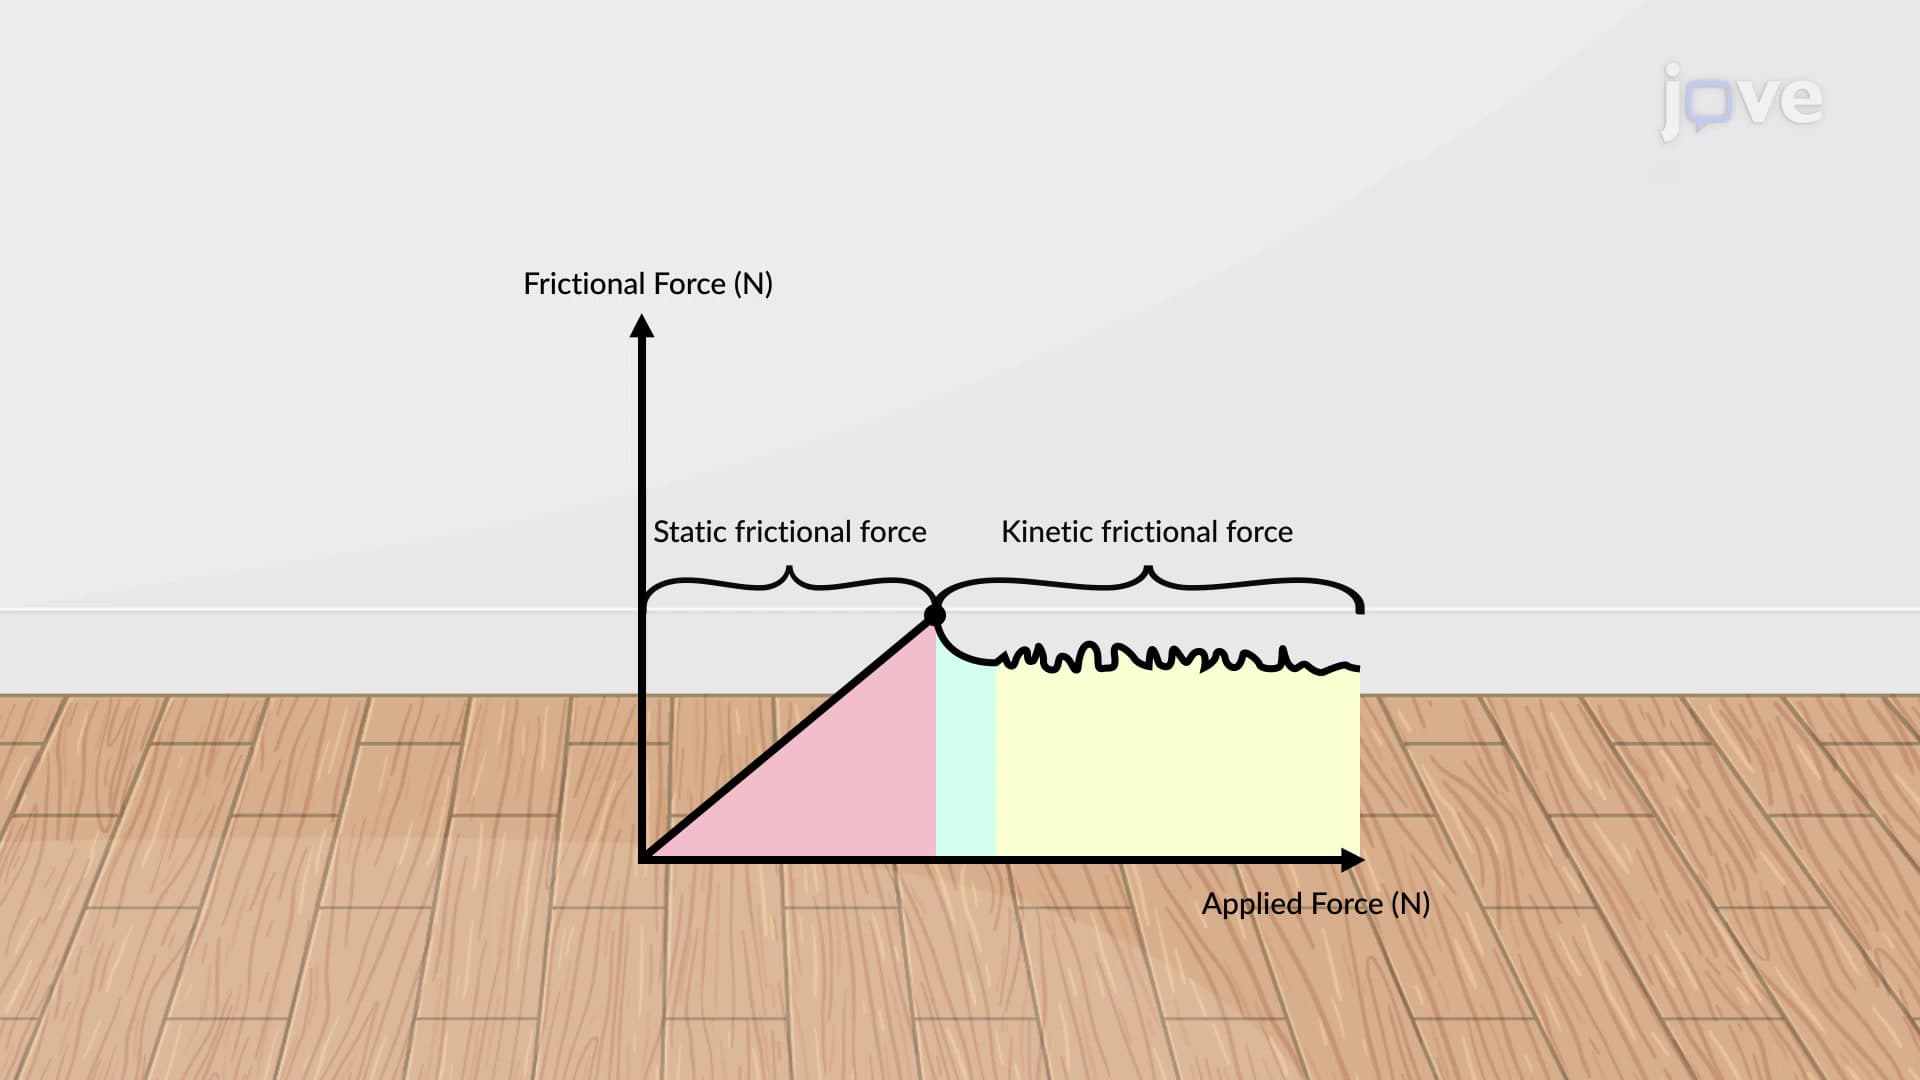
Static and Kinetic Frictional Force
However, if two systems are in contact and are stationary relative to one...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...