Global exponential attitude tracking for spacecraft with gyro bias estimation

Eduardo Espíndola-López1, Yu Tang1
1National Autonomous University of Mexico, Mexico.

Abstract:
Relying on contraction analysis, this paper addresses the global attitude tracking problem of a spacecraft when angular velocity measurements are corrupted by bias. A nonlinear observer with exponential convergence is designed firstly to estimate the bias in gyro sensors. Then an exponentially convergent attitude tracking controller with gyro bias correction is devised. Next, to remove the topological constraints of unit quaternions for global stability, a switching variable with hysteresis is incorporated in the control loop, enhancing the robustness in the presence of measurement noise and energy efficiency by preventing the unwinding phenomenon. Numeric simulations are shown to illustrate the performance and compare with other similar controllers in terms of tracking error, estimation error and energy efficiency, as well as the robustness to noisy measurements and time-varying bias in gyro sensors.
More Related Videos
Related Concept Videos
 01:24
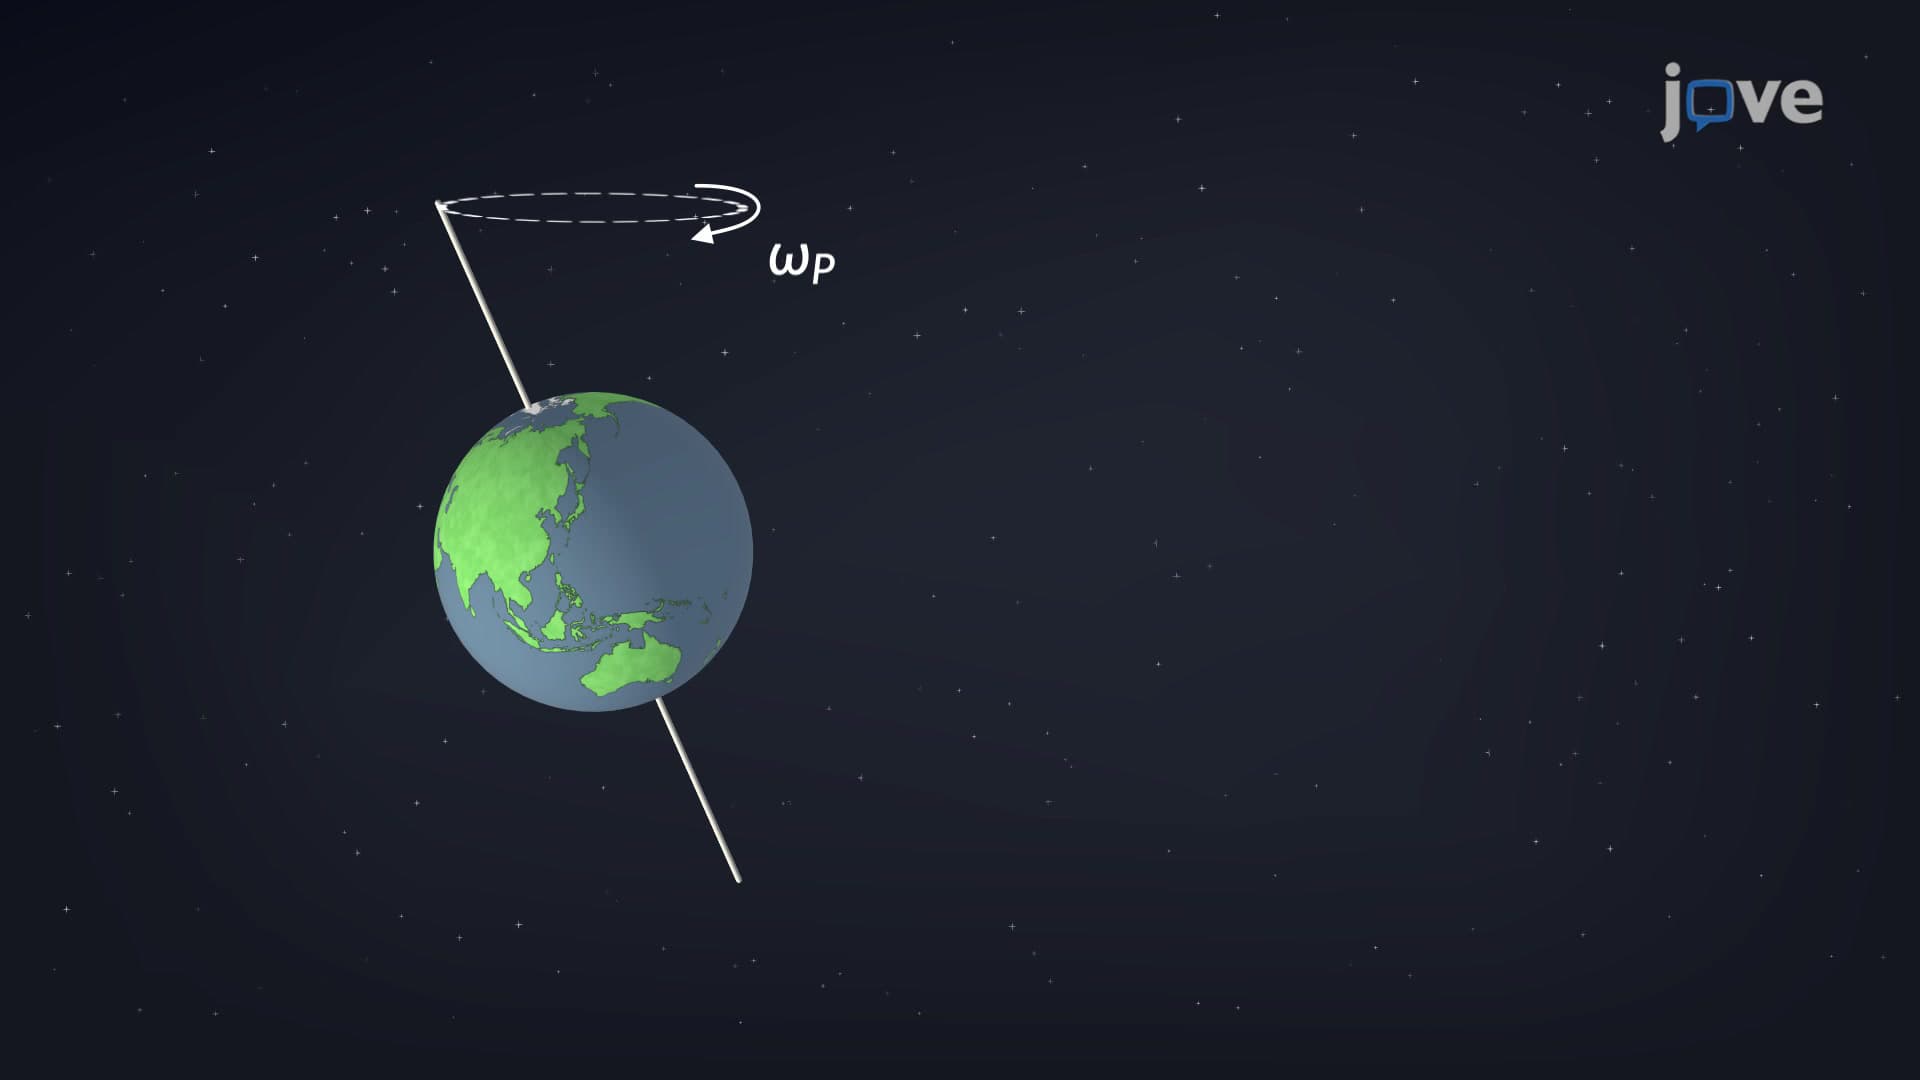
Gyroscope: Precession
 01:02
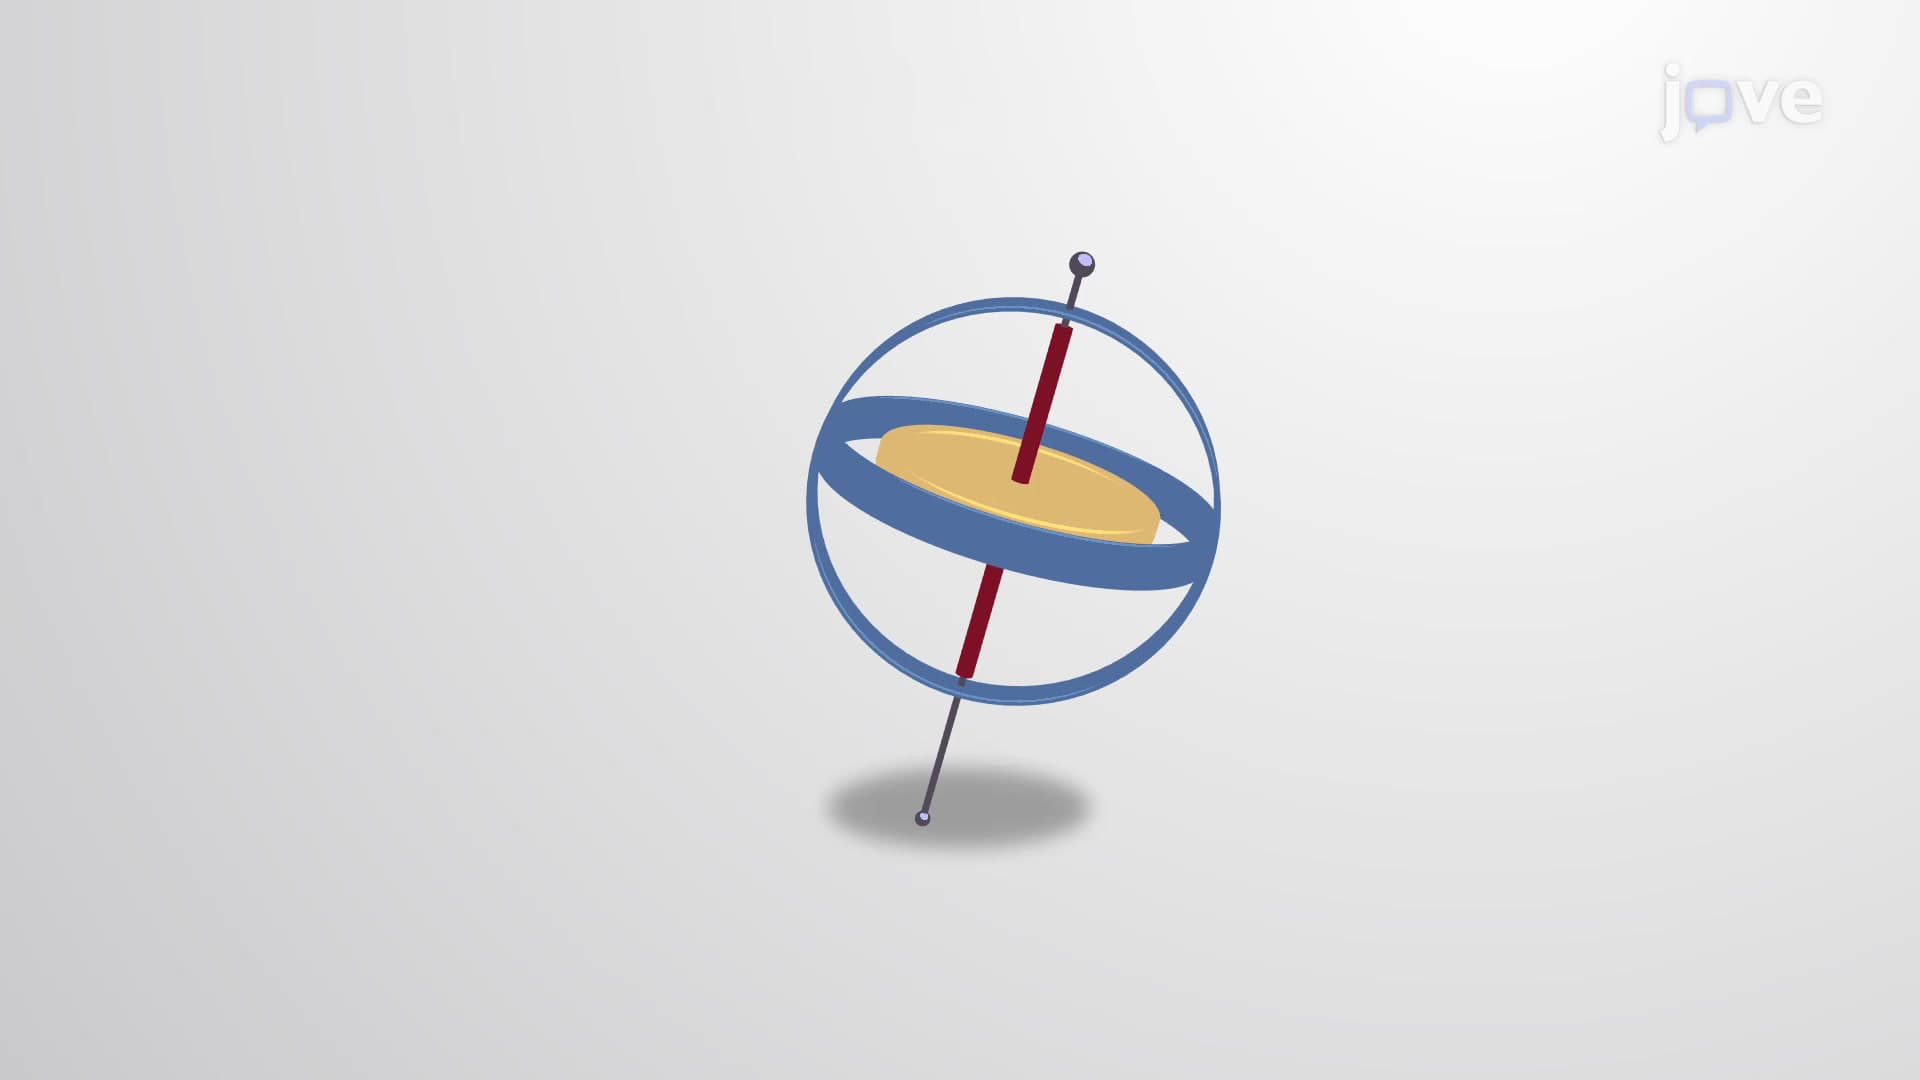
Gyroscope
 01:26
Errors in Global Positioning System
 01:19
Azimuths and Bearings
 01:30
Types of Global Positioning System Surveys
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...