Stability and Control of a Pacing Quadruped Using Stabilizing Switching Design
Related Experiment Video
Updated: Sep 29, 2025
Engineering Platform and Experimental Protocol for Design and Evaluation of a Neurally-controlled Powered Transfemoral Prosthesis
Published on: July 22, 2014
Eric W McClain1, Ali Samare Filsoofi1, Sanford Meek1
1Department of Mechanical Engineering and the Robotics Center, University of Utah, Salt Lake City, UT 84112, USA.

Abstract:
In this paper we present a method for control and stabilizing a pacing quadruped robot using state feedback switching. In the pacing gait, a quadruped cycles between the left and right pairs of legs to achieve locomotion. This results in two discrete stance configurations, each being unstable. The quadruped can achieve dynamic stability by switching between these stances in an appropriate manner. We model our system using two sets of non-linear dynamical equations which we have the control of switching between actively. In order to stabilize our system, we propose a state feedback switching law based on the linearized models of our system for each set of equations. Using this switching law, we are able to stabilize the robot in the roll direction. This, combined with the passive stability achieved with the design of the robot's legs, results in a stable pacing gait. The performance of the proposed controller is evaluated on a complete dynamical model in simulation and stability is verified using a Poincaré map.

Related Concept Videos
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:19
Root-Locus Method
This system can be represented by a block...
 01:24
PI Controller: Design
 01:28
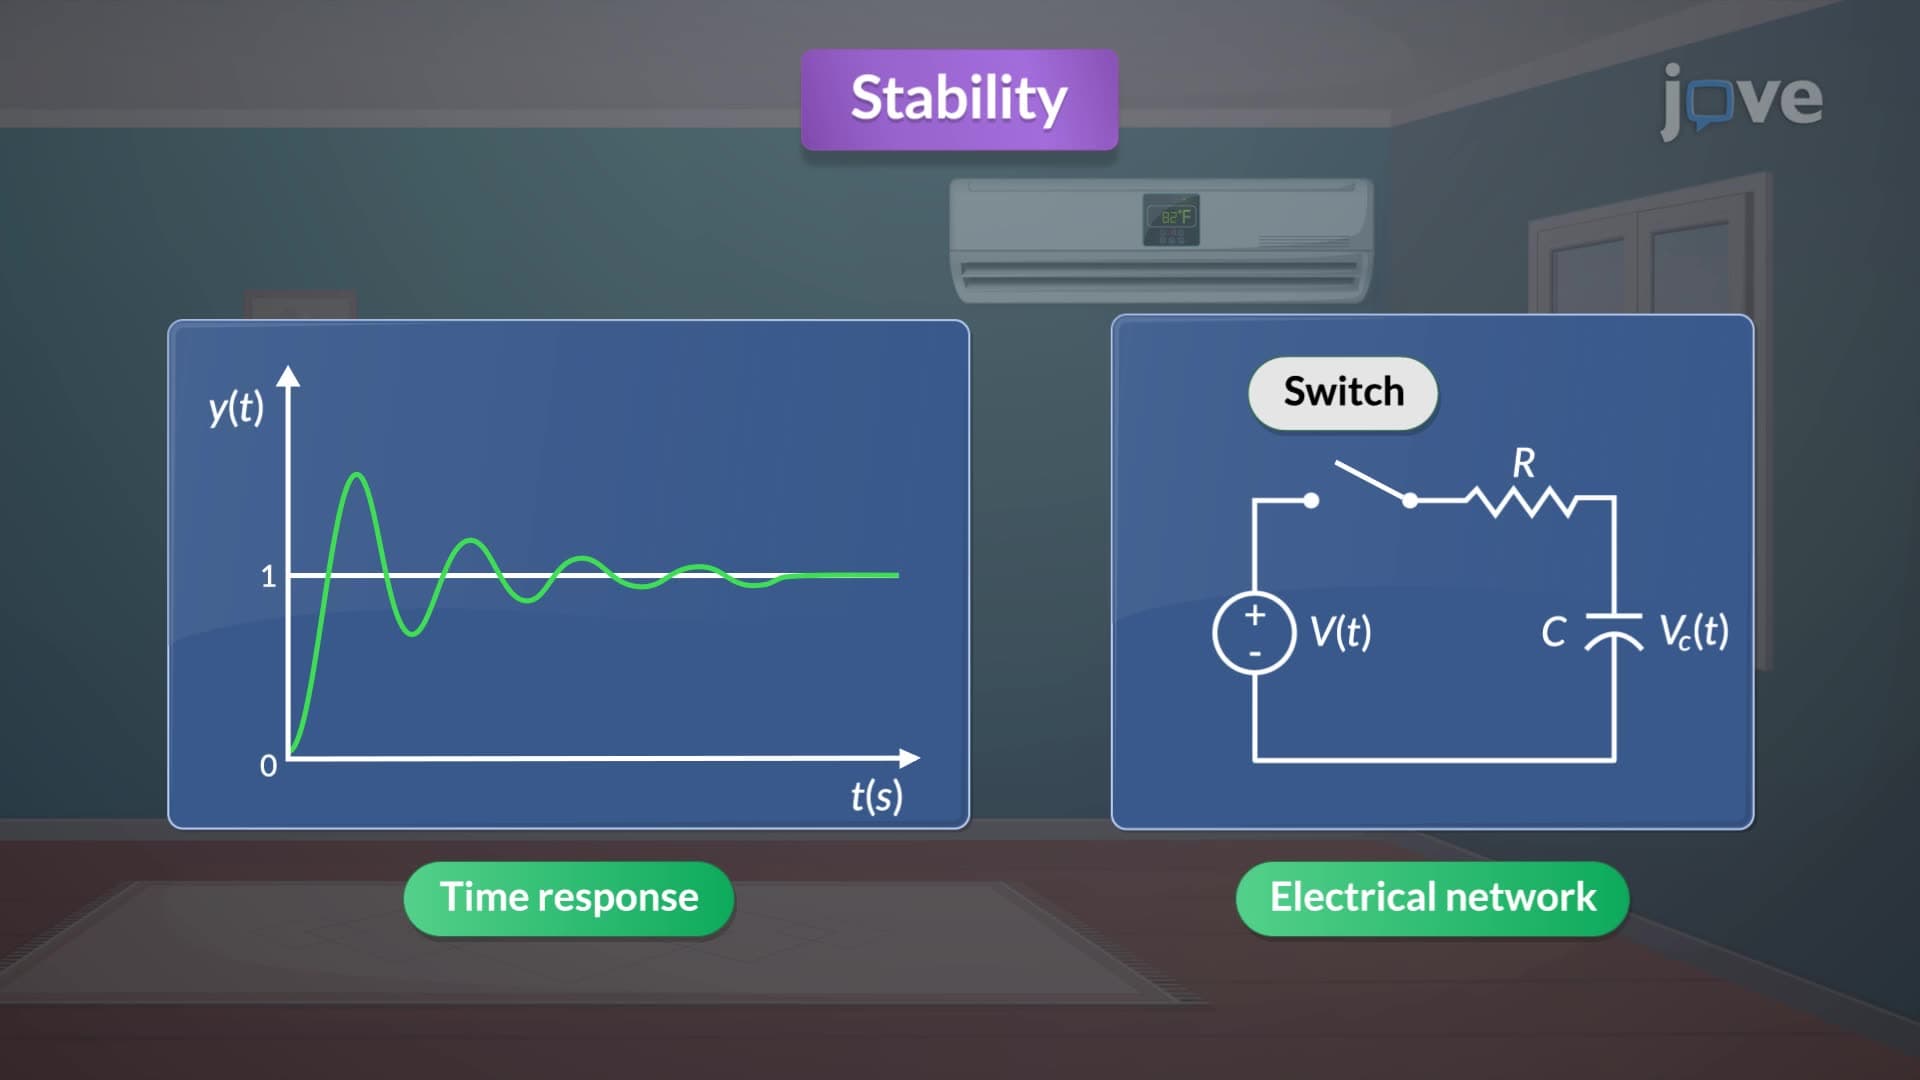
Stability
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
 01:24
Pole and System Stability
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...