Related Experiment Video
Updated: Sep 4, 2025
Real-Time DC-dynamic Biasing Method for Switching Time Improvement in Severely Underdamped Fringing-field Electrostatic MEMS Actuators
Published on: August 15, 2014
Enhanced fractional order sliding mode control for a class of fractional order uncertain systems with multiple
Weijia Zheng1, YangQuan Chen2, Xiaohong Wang3
1School of Mechatronic Engineering and Automation, Foshan University, 33 Guangyun Road, Foshan, China.

Abstract:
To improve the control performance of the fractional order uncertain systems with multiple mismatched disturbances, an enhanced fractional order sliding mode control (FOSMC) method is developed in this paper. The multiple disturbances and uncertainties are estimated by the finite-time disturbance observers (FTDO) and a fractional order extended state observer (FOESO), respectively. A fractional order switching law is designed to provide a fast convergence mode for the system states. Then a novel FOSMC law is developed by incorporating the feedforward compensation, the fractional order switching law, and the auxiliary state for input saturation. The proposed method is applied to numerical examples and to a motor speed control problem. The effectiveness of the proposed method is demonstrated by the performance comparisons with some existing control methods.
More Related Videos
 06:45
Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
 08:18
WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
Related Concept Videos
 01:18
Second Order systems II
 01:20
Second Order systems I
By reinterpreting the system, one can derive the closed-loop transfer function, which...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:21
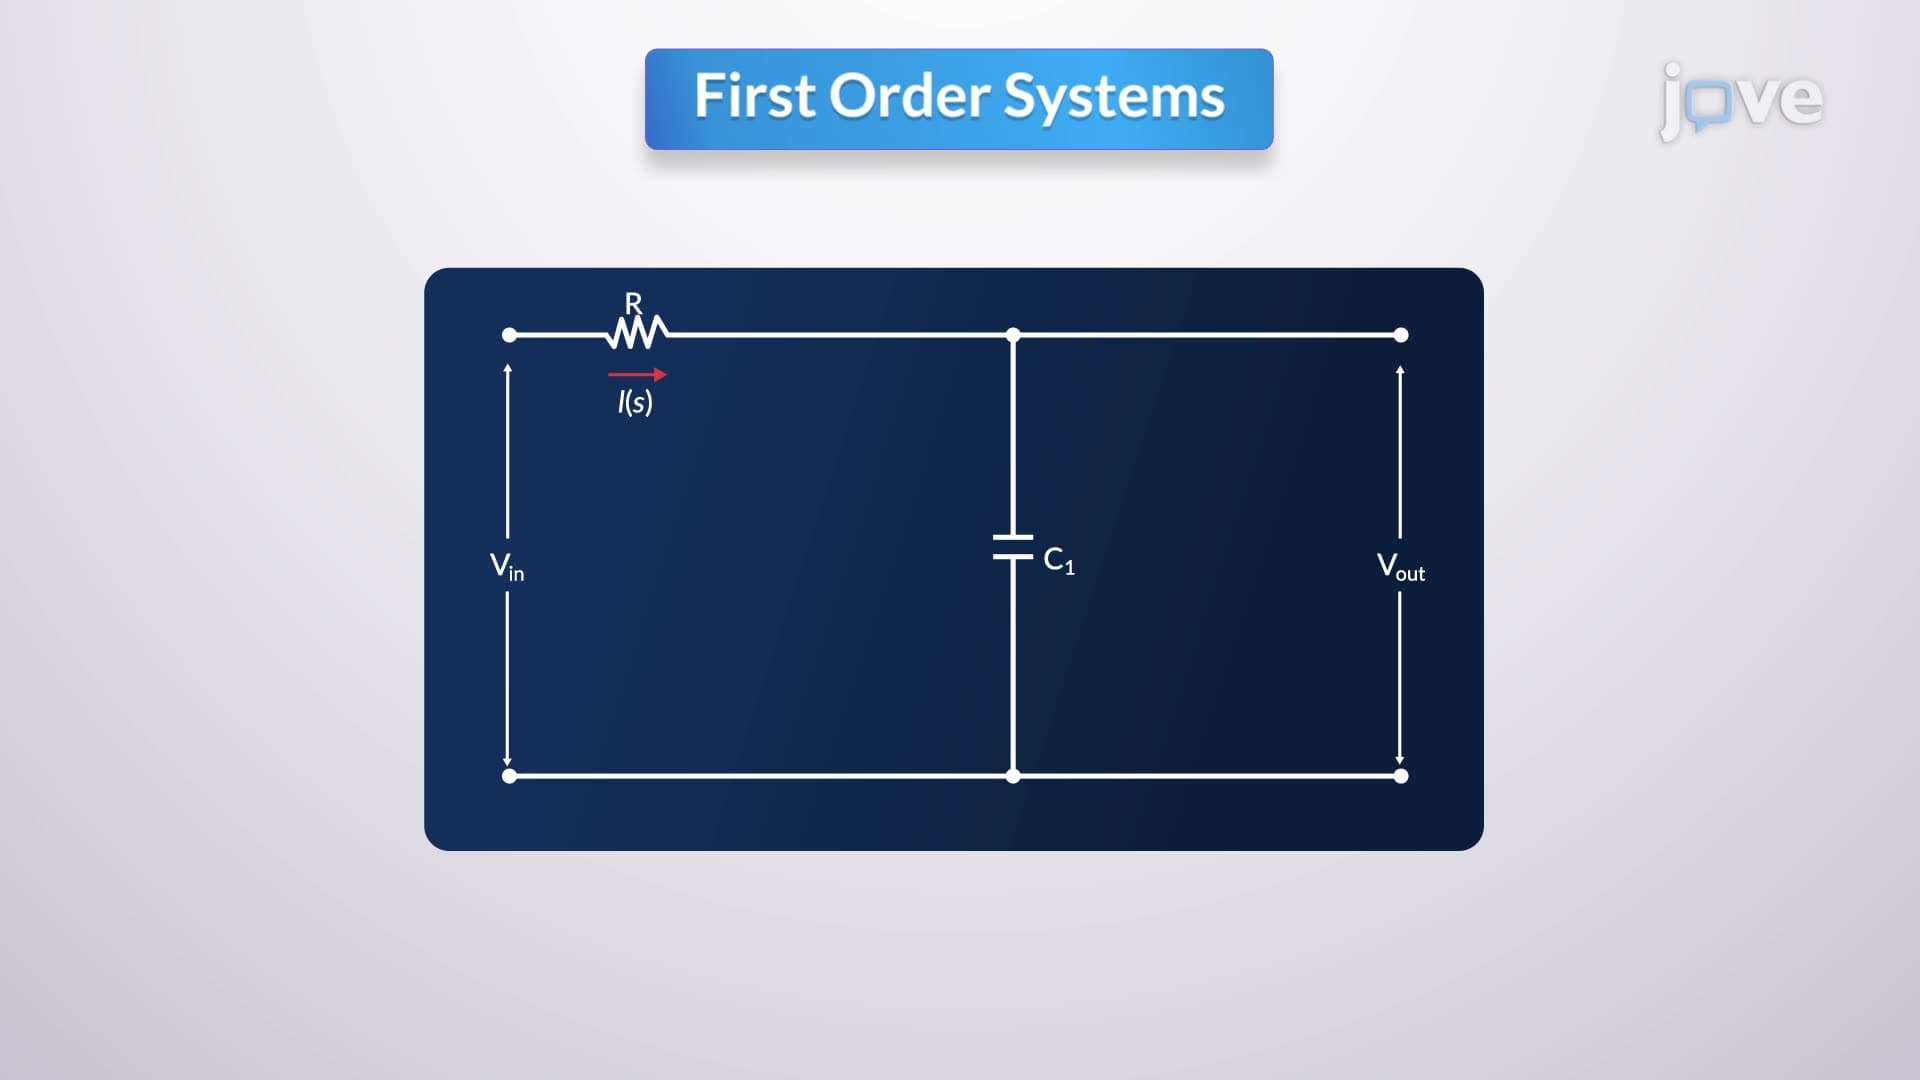
First Order Systems
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...