Related Experiment Video
Updated: Aug 25, 2025
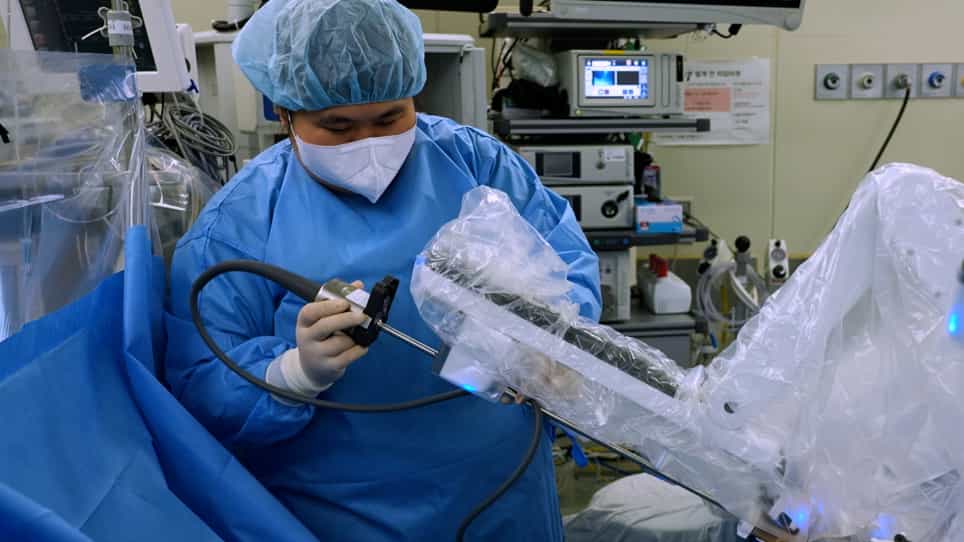
Robot-Assisted Kidney Transplantation
Published on: July 19, 2021
A novel assessment model for teaching robot-assisted living donor nephrectomy in abdominal transplant surgery
Jesse T Davidson1, Julie M Clanahan1, Neeta Vachharajani1
1Washington University School of Medicine, Department of Surgery, Section of Abdominal Transplant and Hepatobiliary Surgery, Saint Louis, MO, USA.

Background:
An increasing number of transplant centers have adopted robot-assisted living donor nephrectomy. Thus, a transplant fellow assessment tool is needed for promoting operative independence in an objective and safe manner.
Methods:
In this pilot study, data was prospectively collected on both fellow performance with focus on technique, efficiency, and communication ("overall RO-SCORE"), and operative steps ("operative steps RO-SCORE"). Robotic user performance metrics were analyzed from the da Vinci Xi system, including fellow percent active control time (ACT) and handoff counts.
Results:
From July 2020 to February 2021, twenty-one robot-assisted donor nephrectomies were performed. In regression analysis, fellow performance (based on both RO-SCOREs and robot % ACT) was significantly associated with both time and case number, with time-to-independence modelled at 8.4-14.2 months, and case number-to-independence estimated at 15-22 cases. Robot user metrics provided valid objective measures alongside RO-SCOREs.
Conclusions:
This pilot study provides an effective assessment tool for promoting operative competency in robot-assisted donor nephrectomy among transplant fellows.
Related Concept Videos
 01:26
Kidney Transplant II: Surgical Procedure
 01:28
Kidney Transplant I: Introduction
 01:16
Kidney Transplant III: Nursing Management