Hippocampus experience inference for safety critical control of unknown multi-agent linear systems
Related Experiment Video
Updated: Aug 16, 2025

Closed-loop Neuro-robotic Experiments to Test Computational Properties of Neuronal Networks
Published on: March 2, 2015
Adolfo Perrusquía1, Weisi Guo1
1School of Aerospace, Transport and Manufacturing, Cranfield University, Bedford, MK43 0AL, UK.

Abstract:
Risk mitigation is usually addressed in simulated environments for safety critical control. The migration of the final controller requires further adjustments due to the simulation assumptions and constraints. This paper presents the design of an experience inference algorithm for safety critical control of unknown multi-agent linear systems. The approach is inspired in the close relationship between three main areas of the brain cortex that enables transfer learning and decision making: the hippocampus, the neocortex, and the striatum. The hippocampus is modelled as a stable linear model that communicates to the striatum how the real-world system is expected to behave. The hippocampus model is controlled by an adaptive dynamic programming (ADP) algorithm to achieve an optimal desired performance. The neocortex and the striatum are designed simultaneously by an actor control policy algorithm that ensures experience inference to the real-world system. Experimental and simulations studies are carried out to verify the proposed approach.


Related Concept Videos
 01:22
Multi-input and Multi-variable systems
In the absence...
 01:06
Collisions in Multiple Dimensions: Problem Solving
A small car of mass 1,200 kg traveling east at 60 km/h collides at an intersection with a truck of mass 3,000 kg traveling due north at 40 km/h. The two vehicles are locked together. What is the...
 01:19
Role of Hippocampus in Memory
 01:13
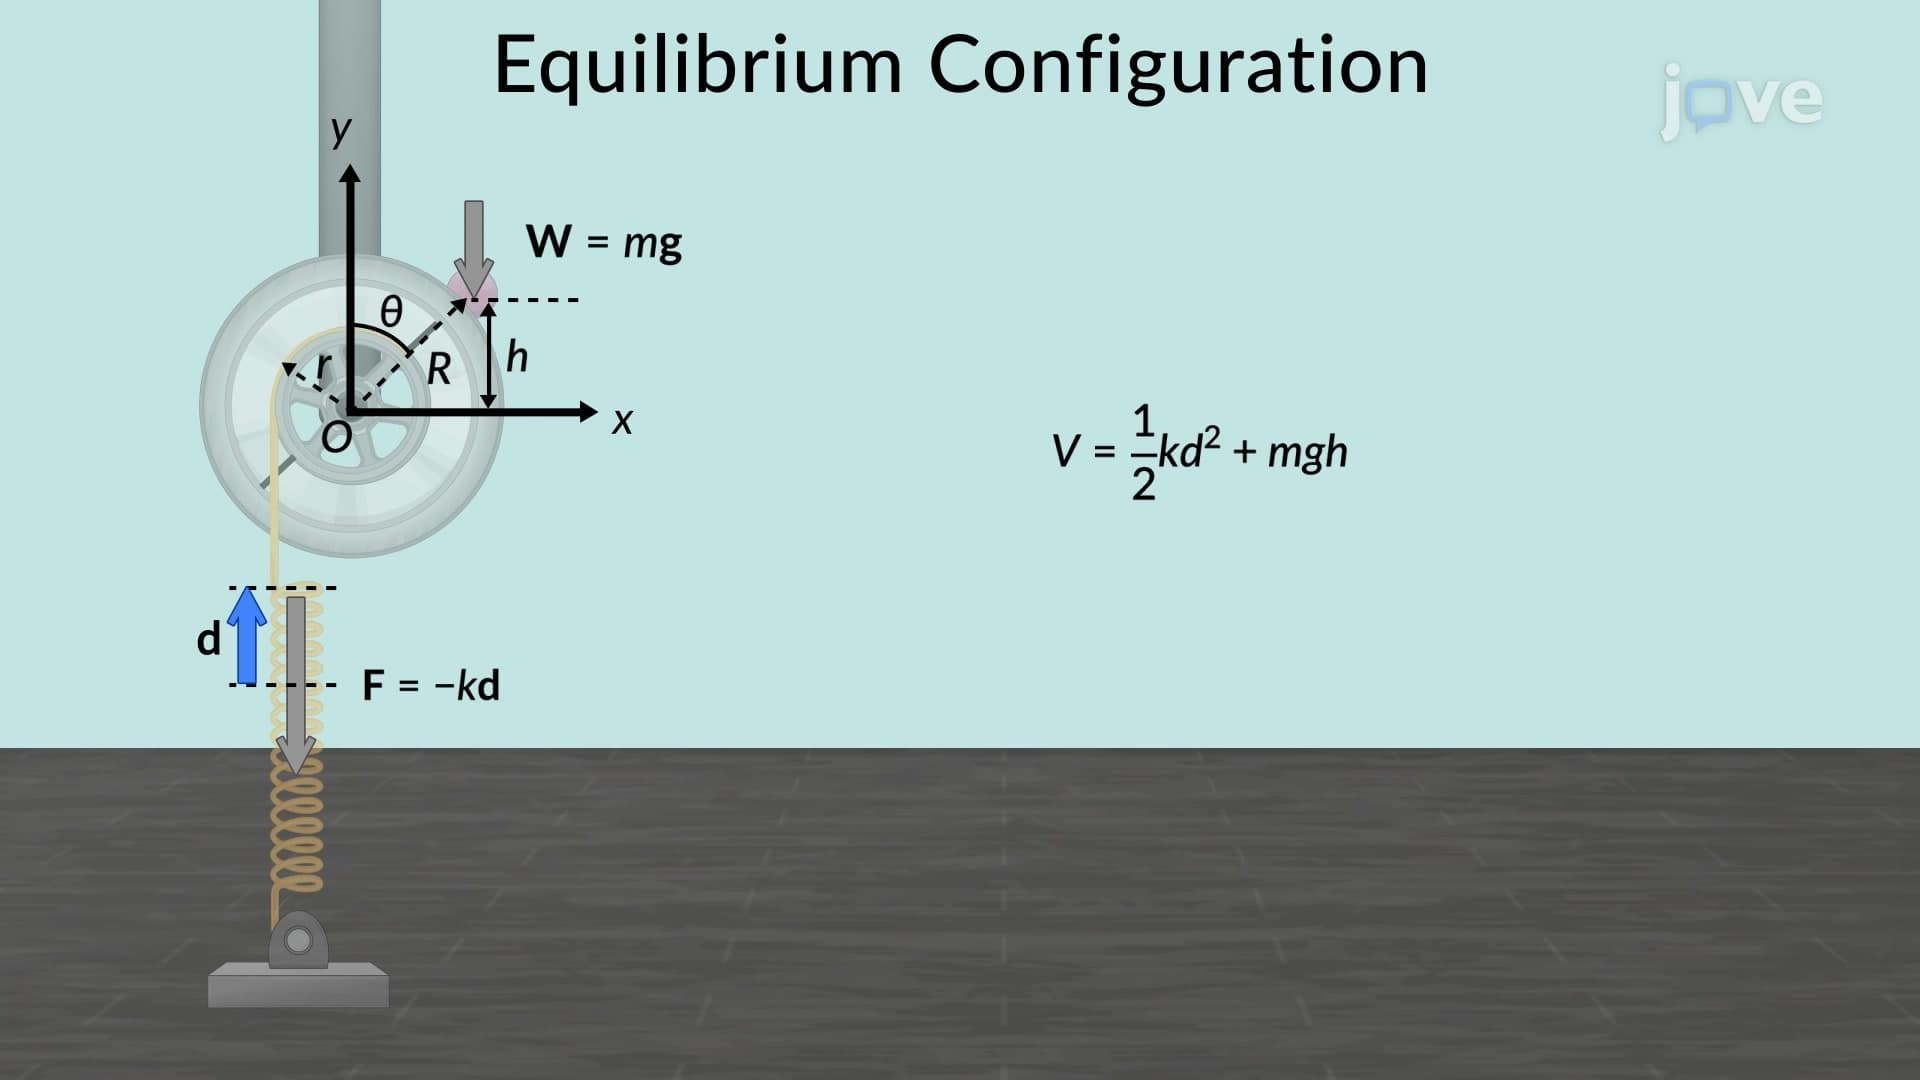
Stability of Equilibrium Configuration: Problem Solving
Problem-solving in the context of the stability of equilibrium configuration...
 01:16
Statically Indeterminate Problem Solving
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...