Related Experiment Video
Updated: Aug 12, 2025

Simulation of Human-induced Vibrations Based on the Characterized In-field Pedestrian Behavior
Published on: April 13, 2016
Footstep localization and force estimation through structural vibrations using the FEEL Algorithm
1Advanced Smart Systems and Evaluation Technologies (ASSET), LLC 1400 Laurel Street, Suite 1B, Columbia, SC 29201, USA.

Abstract:
Locating individuals within a space has numerous potential uses within a smart environment. Many different technologies have been explored towards this end though privacy-concerns, the need to wear a device, and/or extensive building modifications have presented challenges towards adoption. Structural vibrations caused by footsteps have been shown to overcome these challenges though current methods rely on time-of-flight variations. This paper presents the use of the Force Estimation and Event Localization (FEEL) Algorithm that utilizes lower sampling rates, less sensors, etc than time-of-flight methods towards locating persons. Improvements to FEEL's force estimation and SDFE localization method are additionally presented with demonstrated increases in accuracy. Analysis of 1100 footsteps resulted in 98.6% localization accuracy using the improved FEEL. Ground force reactions (GRF) were estimated by FEEL and used to estimate participant body-weight-ratios (BWR). Estimated BWRs were within ranges reported in previous works for both barefoot and shoe cases.
Related Concept Videos
 01:19
Vibrating Concrete
 01:15
Discrete Fourier Transform
 01:05
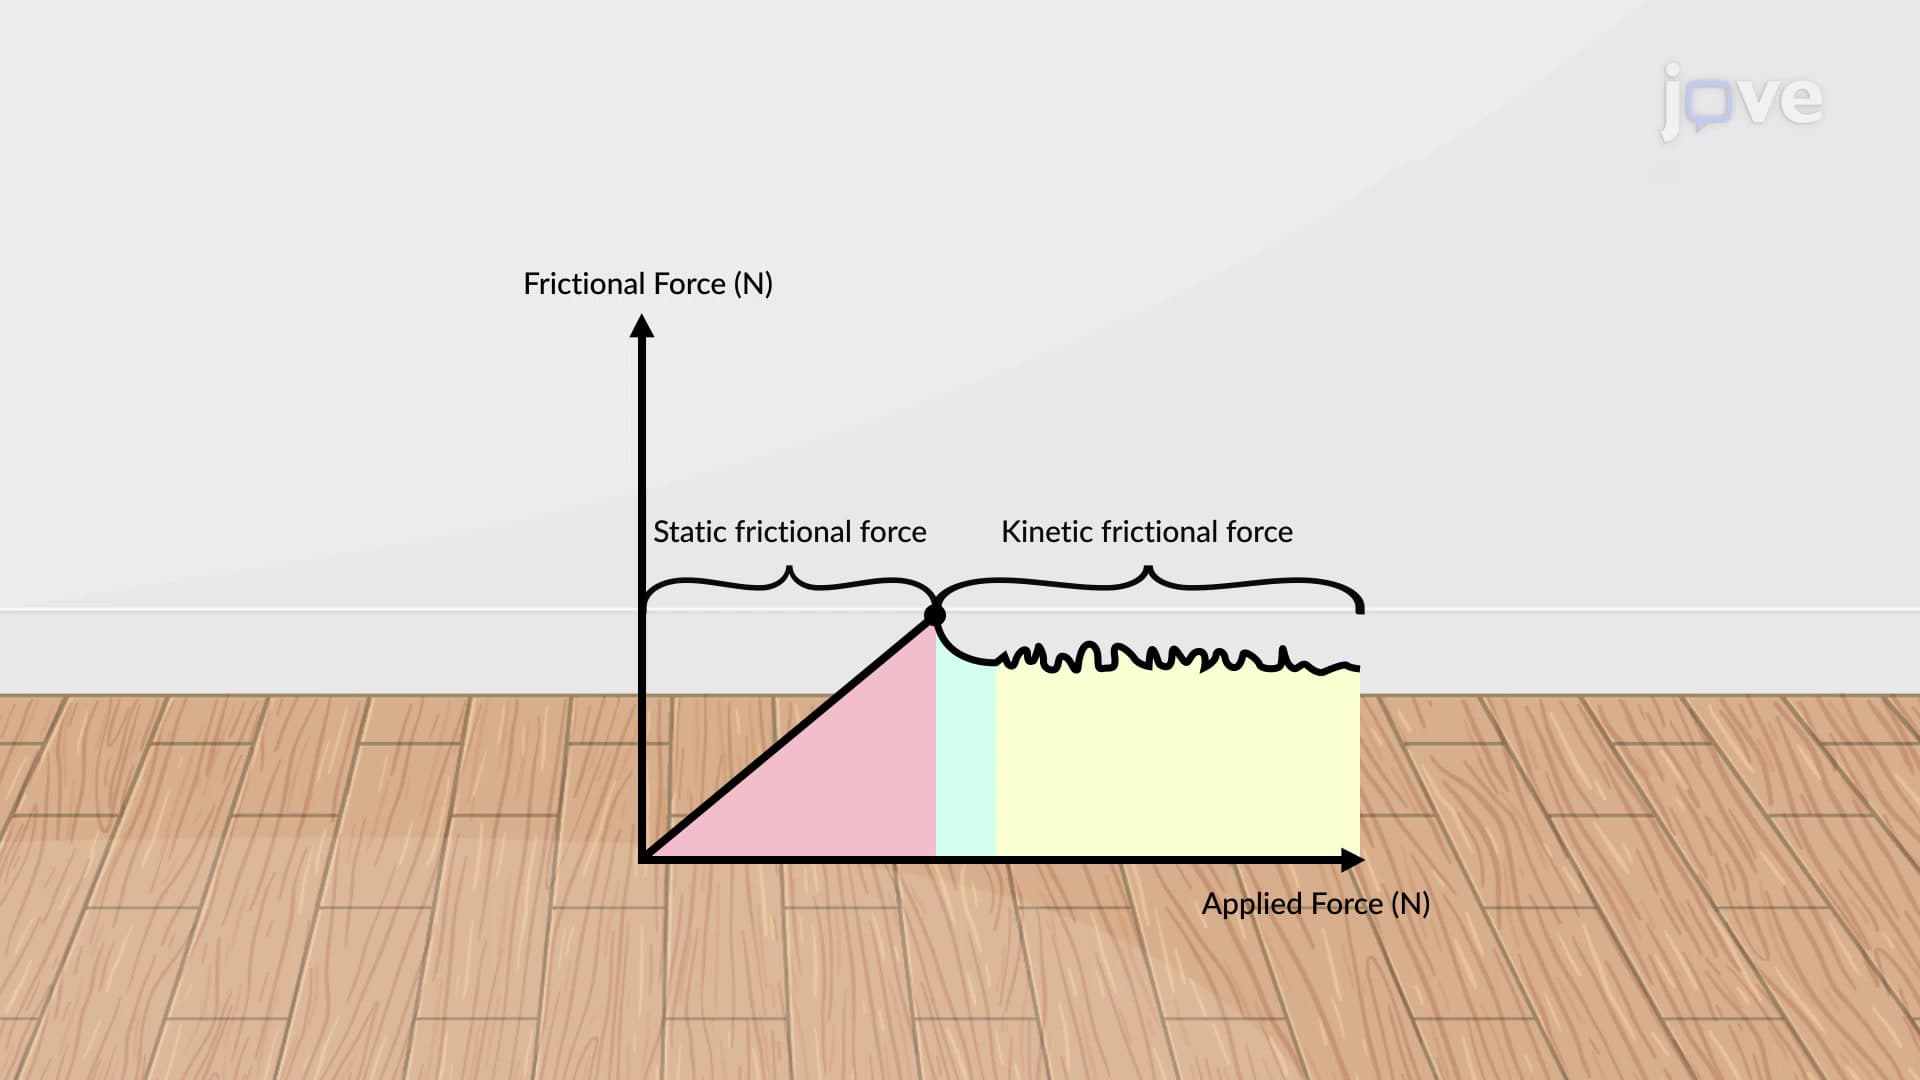
Static and Kinetic Frictional Force
However, if two systems are in contact and are stationary relative to one...
 01:21
Perceiving Loudness, Pitch, and Location
Place theory, or place coding, suggests that different pitches are heard because various sound waves activate specific locations along the cochlea's basilar membrane. The brain determines the pitch of a sound by...
 01:15
Equilibrium and Balance