Related Experiment Video
Updated: Aug 8, 2025

Interactive and Visualized Online Experimentation System for Engineering Education and Research
Published on: November 24, 2021
Design of a fractional-order atmospheric model via a class of ACT-like chaotic system and its sliding mode chaos
Manisha Krishna Naik1, Chandrali Baishya1, Pundikala Veeresha2
1Department of Studies and Research in Mathematics, Tumkur University, Tumkur 572103, Karnataka, India.

Abstract:
Investigation of the dynamical behavior related to environmental phenomena has received much attention across a variety of scientific domains. One such phenomenon is global warming. The main causes of global warming, which has detrimental effects on our ecosystem, are mainly excess greenhouse gases and temperature. Looking at the significance of this climatic event, in this study, we have connected the ACT-like model to three climatic components, namely, permafrost thaw, temperature, and greenhouse gases in the form of a Caputo fractional differential equation, and analyzed their dynamics. The theoretical aspects, such as the existence and uniqueness of the obtained solution, are examined. We have derived two different sliding mode controllers to control chaos in this fractional-order system. The influences of these controllers are analyzed in the presence of uncertainties and external disturbances. In this process, we have obtained a new controlled system of equations without and with uncertainties and external disturbances. Global stability of these new systems is also established. All the aspects are examined for commensurate and non-commensurate fractional-order derivatives. To establish that the system is chaotic, we have taken the assistance of the Lyapunov exponent and the bifurcation diagram with respect to the fractional derivative. To perform numerical simulation, we have identified certain values of the parameters where the system exhibits chaotic behavior. Then, the theoretical claims about the influence of the controller on the system are established with the help of numerical simulations.
More Related Videos
 11:53
The Modular Design and Production of an Intelligent Robot Based on a Closed-Loop Control Strategy
Published on: October 14, 2017
 06:45
Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
Related Concept Videos
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:18
Second Order systems II
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:20
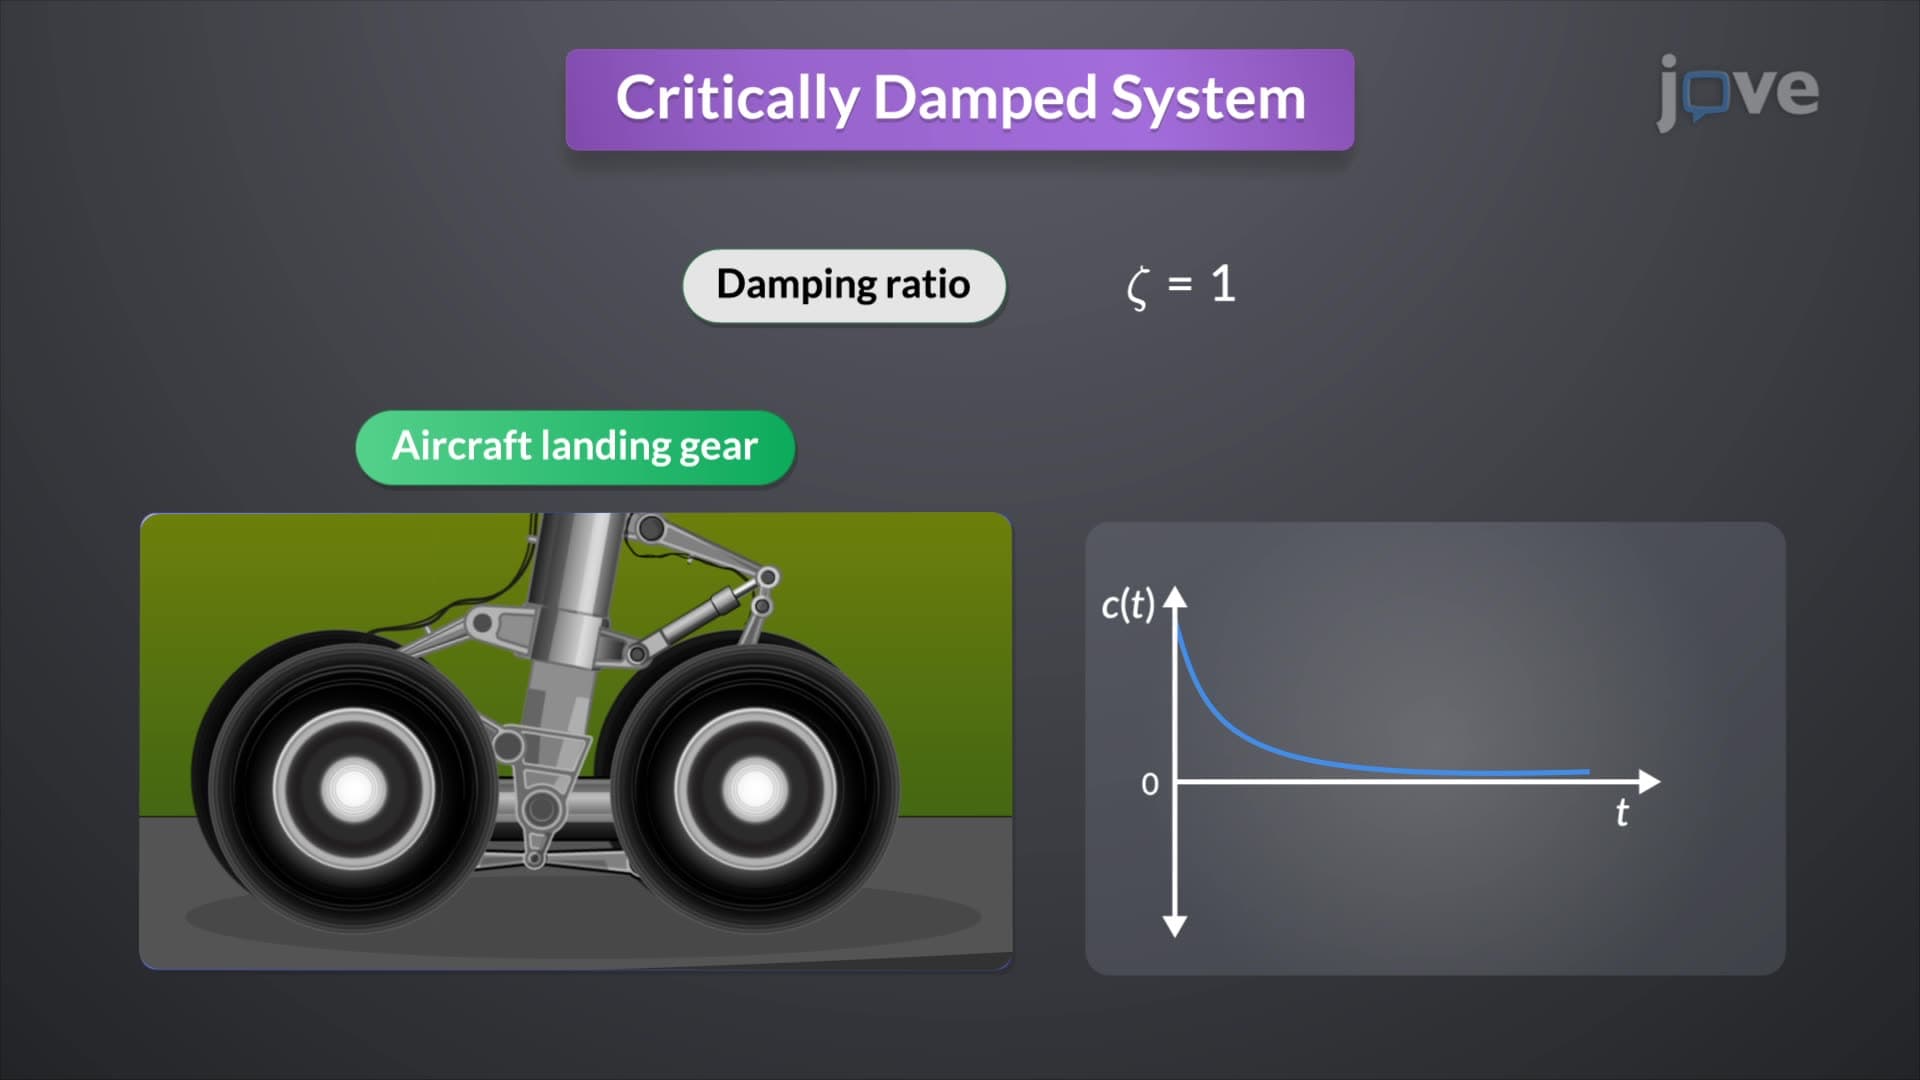
Second Order systems I
By reinterpreting the system, one can derive the closed-loop transfer function, which...
 01:27
Time and frequency -Domain Interpretation of PI Control
Acting as a low-pass filter, the PI controller slows the system's response and extends settling times. This requires...
 01:24
Time and frequency -Domain Interpretation of Phase-lead Control
The design of phase-lead control involves the strategic placement of poles and zeros to balance steady-state error and system...