Trajectory tracking control with state restricted gains for a magnetic pendulum using electromagnetic actuators

Rafael Perez-San Lázaro1, Rita Fuentes-Aguilar2, Isaac Chairez2
1Escuela de Ingenieria y Ciencias, Tecnologico de Monterrey Campus Guadalajara, Jalisco, Mexico.

Abstract:
Electromagnetic actuation results suitable for wireless driven motion, where the estimation of the force between magnetic elements is usually required. This force can lead to states where the magnetic-mechanical system remains fixed, requiring constraints to avoid the transgression of these states, and Barrier Lyapunov Functions (BLF) are useful for this purpose. This work presents an adaptive controller with BLF in a magnetic pendulum with state restrictions. It employs fixed electromagnets to induce motion on a pendulum with a permanent magnet as its bob. The force between the magnetic elements is obtained through approximation functions. A new implementation strategy for the control gains introduces the effect of state restrictions on the control action based on a control BLF. Results are analyzed in both simulations and experimental stages, which prove the advantages of employing BLF controllers in mechanical systems that require the avoidance of specific boundaries.
More Related Videos
 11:44
Real-Time DC-dynamic Biasing Method for Switching Time Improvement in Severely Underdamped Fringing-field Electrostatic MEMS Actuators
Published on: August 15, 2014
 09:13
Remote Magnetic Navigation for Accurate, Real-time Catheter Positioning and Ablation in Cardiac Electrophysiology Procedures
Published on: April 21, 2013
Related Concept Videos
 01:17
Magnetic Damping
If, however, the bob is a slotted metal plate, the magnet produces a much smaller effect. When a slotted metal plate enters the field, an emf is induced by the change in flux; however, it is less effective because the slots limit the...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:10
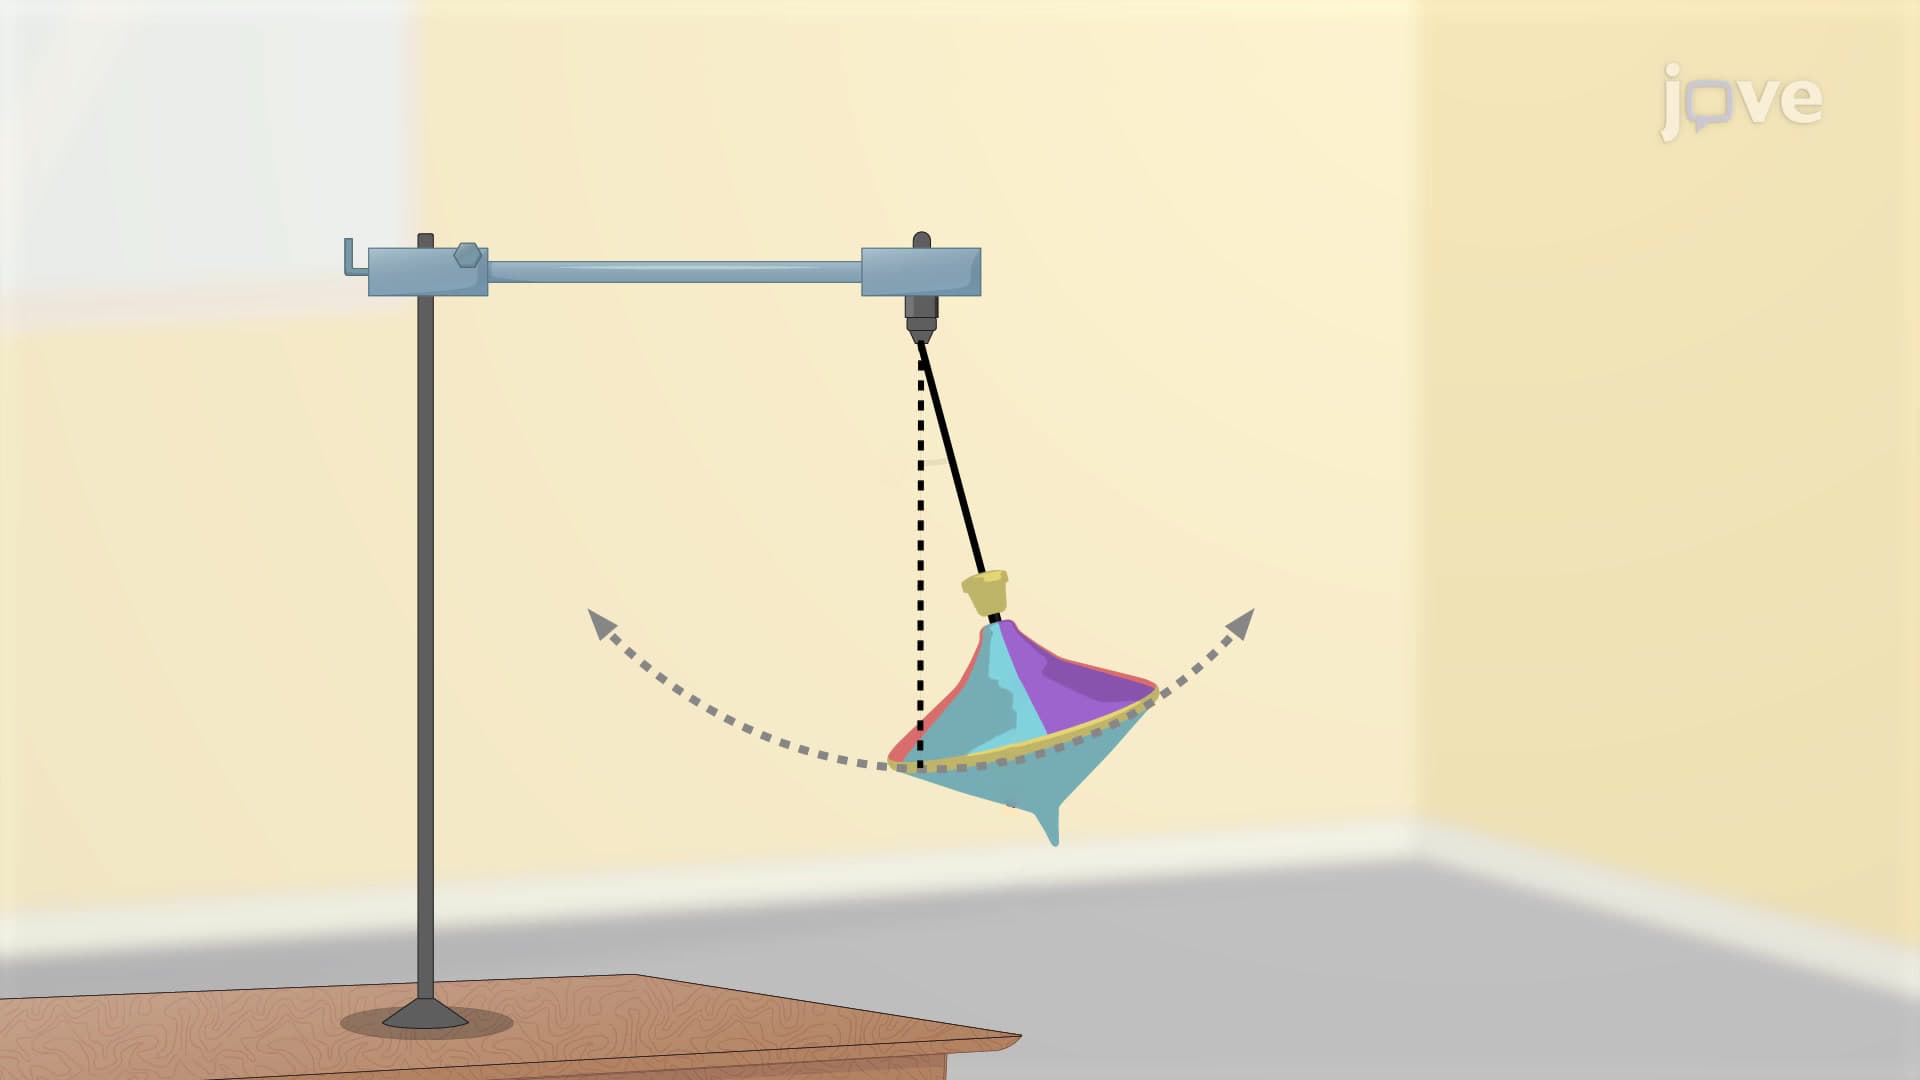
Simple Pendulum
The period of a simple pendulum depends on two factors: its length and the acceleration due to gravity. The period is completely independent of any other factors, such as mass or maximum displacement. For small displacements, a pendulum...
 01:09
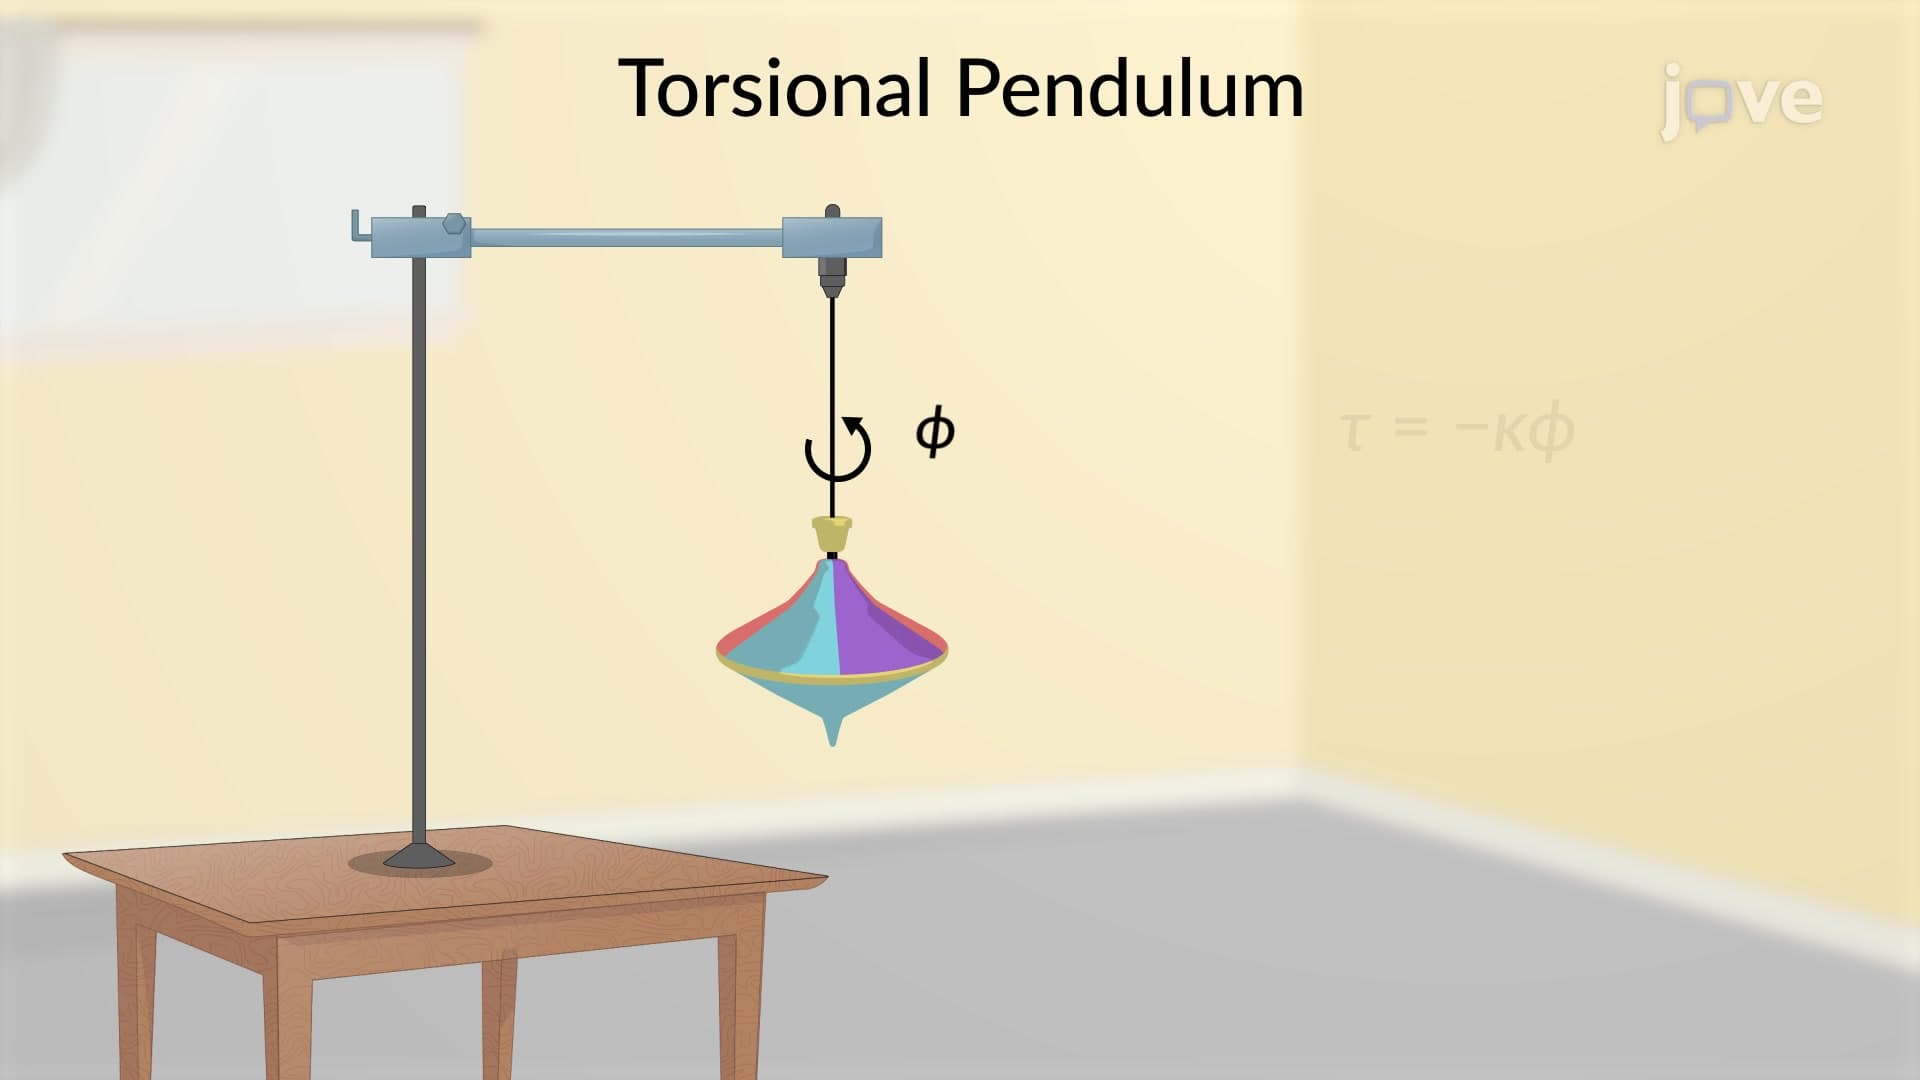
Torsional Pendulum
As long as the rigid body's angular displacement is small, its oscillation can be modeled as a linear angular oscillation. The amplitude of the oscillation is an angle. The role of mass is played...
 01:06
Physical Pendulum
When dealing with complicated systems, the mass moment of inertia is an important parameter, as it...
 01:12
Measuring Acceleration Due to Gravity
A simple pendulum can be described as a point mass and a string. Meanwhile, a physical pendulum is any object whose oscillations are similar to a simple pendulum, but cannot be modeled as a point mass on a string because its mass is distributed over a larger area. The behavior of a physical pendulum can be modeled using the principles of...