Driving safety zone model oriented motion planning framework for autonomous truck platooning
Related Experiment Video
Updated: Jul 15, 2025
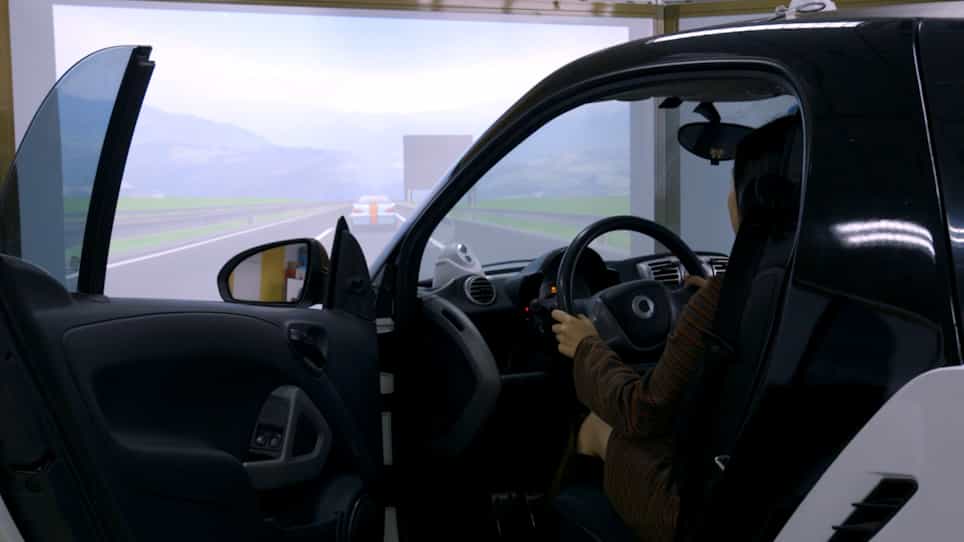
Tactile Vibrating Toolkit and Driving Simulation Platform for Driving-Related Research
Published on: December 18, 2020
Hong Wang1, Lei Song1, Zichun Wei2
1School of Vehicle and Mobility, Tsinghua University, Beijing 10081, China.

Abstract:
A driving-safety-zone-model-oriented motion planning framework (DSZMF) is proposed for autonomous platoons in heterogeneous driving environments with complex driving behaviors and interactions between human-driven and autonomous vehicles. As an extension of the responsibility-sensitive-safety (RSS) model, the driving safety zone model ensures that autonomous truck platoons adhere to explicit and implicit traffic rules as rational traffic participants. It consists of three zones created by safe distances and artificial potential field (APF), namely the restricted zone, the coordinated zone, and pre-cautionary zone. The Rational Traffic Participant (RTP) module is created by using a Finite State Machine (FSM) to provide an optimized platooning behavioral strategy based on the dynamic states of surrounding vehicles. Furthermore, the distributed model predictive controllers are utilized for motion planning, while the H infinity controller is developed to maintain the string stability of the autonomous platoon. The proposed DSZMF generates behavioral decisions by thoroughly considering the driving safety zone model, string stability, and multiple vehicle dynamics constraints. Finally, three critical scenarios are co-simulated for case studies, and the simulation results demonstrate that the DSZMF improves the safe time integration rate over the existing MCF by 18.9%, 11.1%, and 11.6% in three scenarios, respectively. In addition, DSZMF increases the minimum longitudinal and lateral Time to Collision (TTC) values to reduce collision risks. The case studies validate the efficacy of the proposed method for safety assurance and collaborative control of the autonomous platoon.


Related Concept Videos
 01:21
Distributed Loads: Problem Solving
 01:22
Planar Rigid-Body Motion
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:18
Hierarchy of Motor Control
 01:17
Rolling Resistance: Problem Solving
 01:19
Distributed Loads
For example, consider a bookshelf filled with books stacked vertically adjacent to each other. The weight of the books is evenly distributed over the length of the shelf. As a result, the pressure at different locations on the surface of the...