Related Experiment Video
Updated: Jul 14, 2025

WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
Adaptive fuzzy prescribed time tracking control for nonlinear systems with input saturation
Haixiu Xie1, Yuanwei Jing1, Georgi M Dimirovski2
1College of Information Science and Engineering, Northeastern University, Shenyang 110819, Liaoning, China.

Abstract:
This article investigates the adaptive fuzzy prescribed time tracking control problem for a class of strict-feedback systems simultaneously considering the user-defined asymmetric tracking performance, input saturation, and external disturbances. From the perspective of ensuring the reliability for control implementation, a saturation-based fixed-time funnel boundary is constructed by embedding the modification signals related to input saturation errors into a funnel function, which is capable of automatically enlarging or recovering itself when input saturation occurs or disappears, thereby reducing the risk of system singularity. Subsequently, by constructing a fixed-time tracking performance function, any known bounded tracking error is recast into a new variable with a zero initial value. With such a treatment, funnel boundaries are no longer redeveloped for different initial tracking errors, and meanwhile the behavior of the tracking error is pre-specified as needed over a finite time interval. Also, auxiliary systems are devised to generate the aforesaid modification signals, while compensating for the adverse impact resulting from input saturation. Remarkably, by feat of the backstepping design based on the fuzzy approximation, it is proven that the tracking error converges to a user-defined region within a prescribed time (known as the practically prescribed time tracking), which is achieved without the fractional power feedback of system states. Finally, two simulation examples are presented to confirm the feasibility and effectiveness of the developed approach.
More Related Videos
 06:45
Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
 09:01
Gain-compensation Methodology for a Sinusoidal Scan of a Galvanometer Mirror in Proportional-Integral-Differential Control Using Pre-emphasis Techniques
Published on: April 4, 2017
Related Concept Videos
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:21
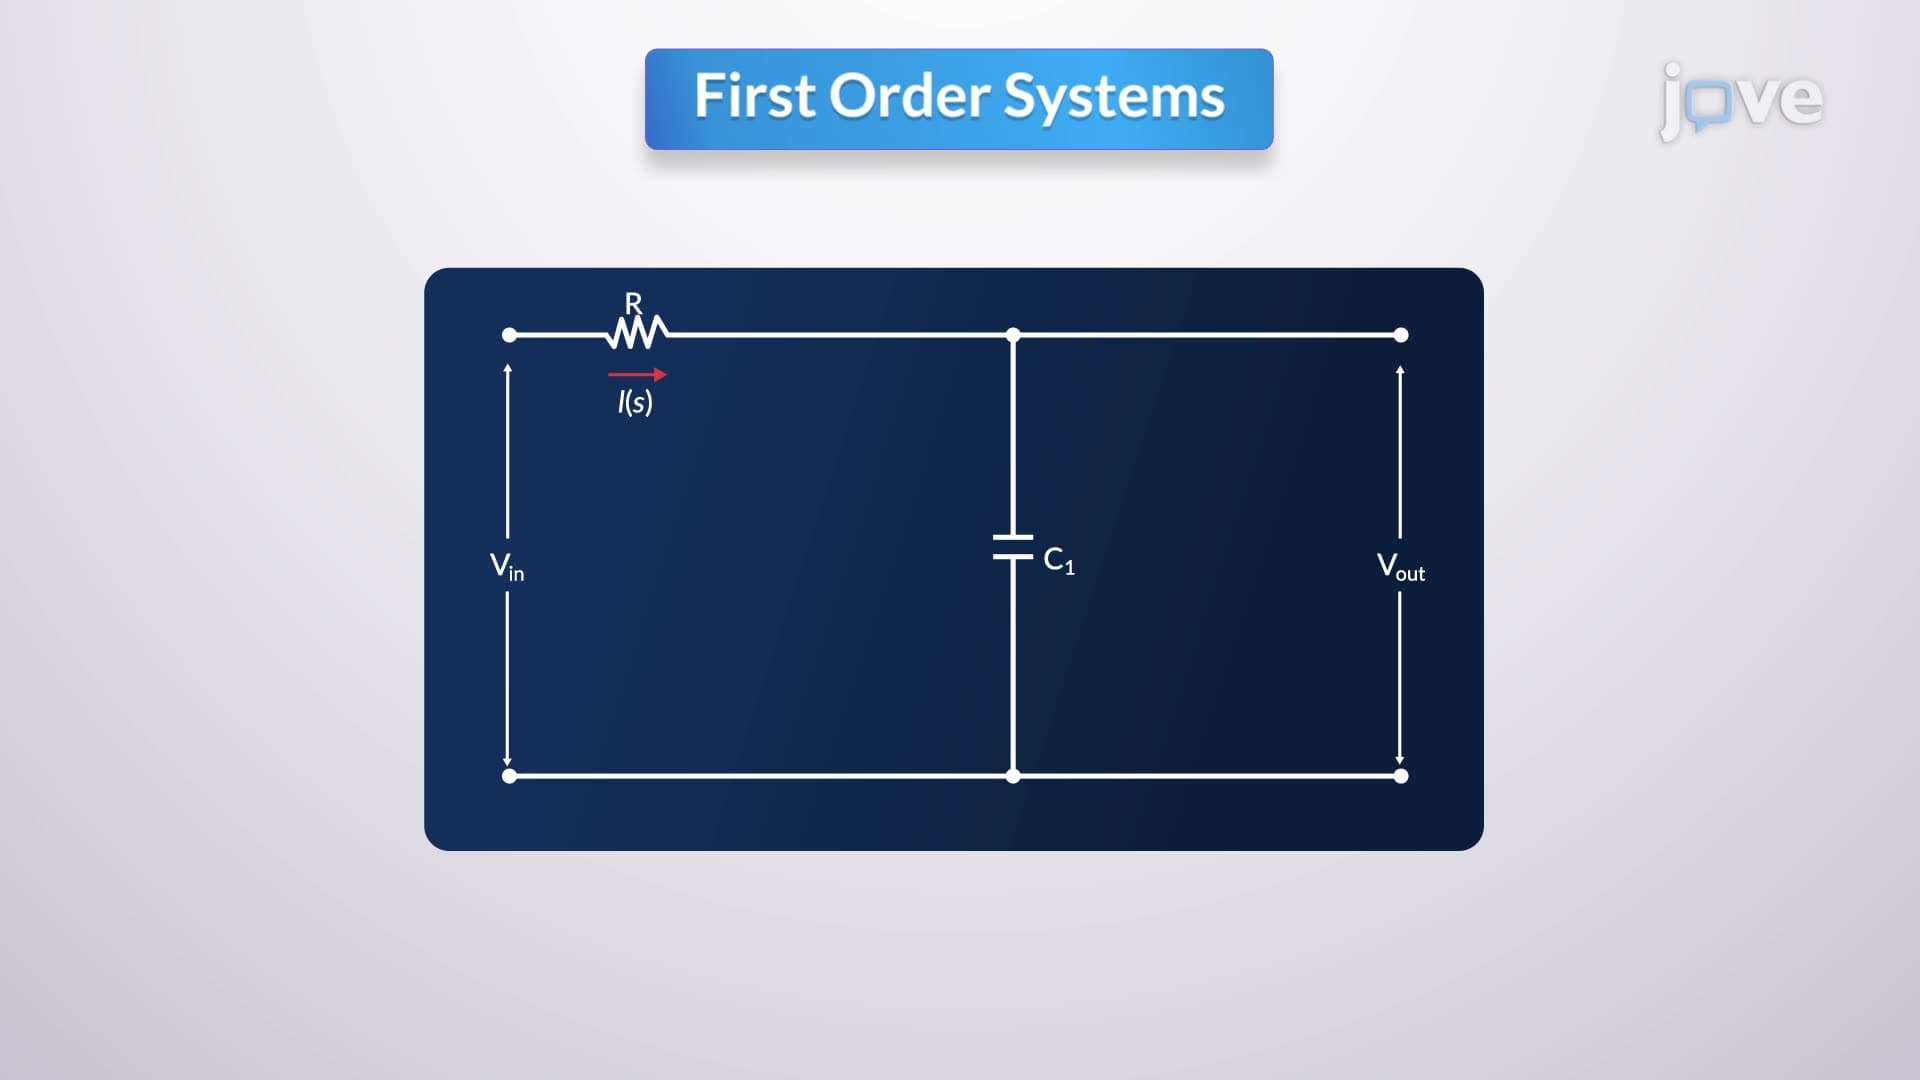
First Order Systems
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....