Related Experiment Video
Updated: Jul 11, 2025

WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
Differential flatness-based adaptive robust tracking control for wheeled mobile robots with slippage disturbances
Wang Yuan1, Yueyue Liu2, Yong-Hua Liu1
1School of Automation, Guangdong University of Technology, and the Guangdong Province Key Laboratory of Intelligent Decision and Cooperative Control, Guangzhou, 510006, China.

Abstract:
Wheeled mobile robots (WMRs) have a wide range of applications in logistics transportation and industrial productions, among which the motion control has always been one of the hot spots in the current WMR researches. However, most of previous designed controllers assumed that the WMR motion had no slippage. Ignoring the slippage factors usually results in a decrease in control performance and even leads to unstable motion. To address such a challenge, a kinematic model with differential flatness is established through dynamic feedback-linearization, which comprehensively considers the multidirectional slippage of mobile robot, including longitudinal and steering slippage. Subsequently, benefited from the one-to-one mapping of states and inputs to flat outputs in differential flat system, an adaptive robust control (ARC) method is proposed to stabilize the system. Different from previous robust control studies, even if the knowledge of the upper bound of system uncertainties is unknown in advance, the proposed adaptive robust controller can still achieve satisfying performance by adaptive estimation of the upper bound of system uncertainties. The effectiveness and feasibility of the proposed method are confirmed by comparative experiments on WMR with slippage disturbance.
More Related Videos
 06:45
Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
 09:00
Insect-controlled Robot: A Mobile Robot Platform to Evaluate the Odor-tracking Capability of an Insect
Published on: December 19, 2016
Related Concept Videos
 01:14
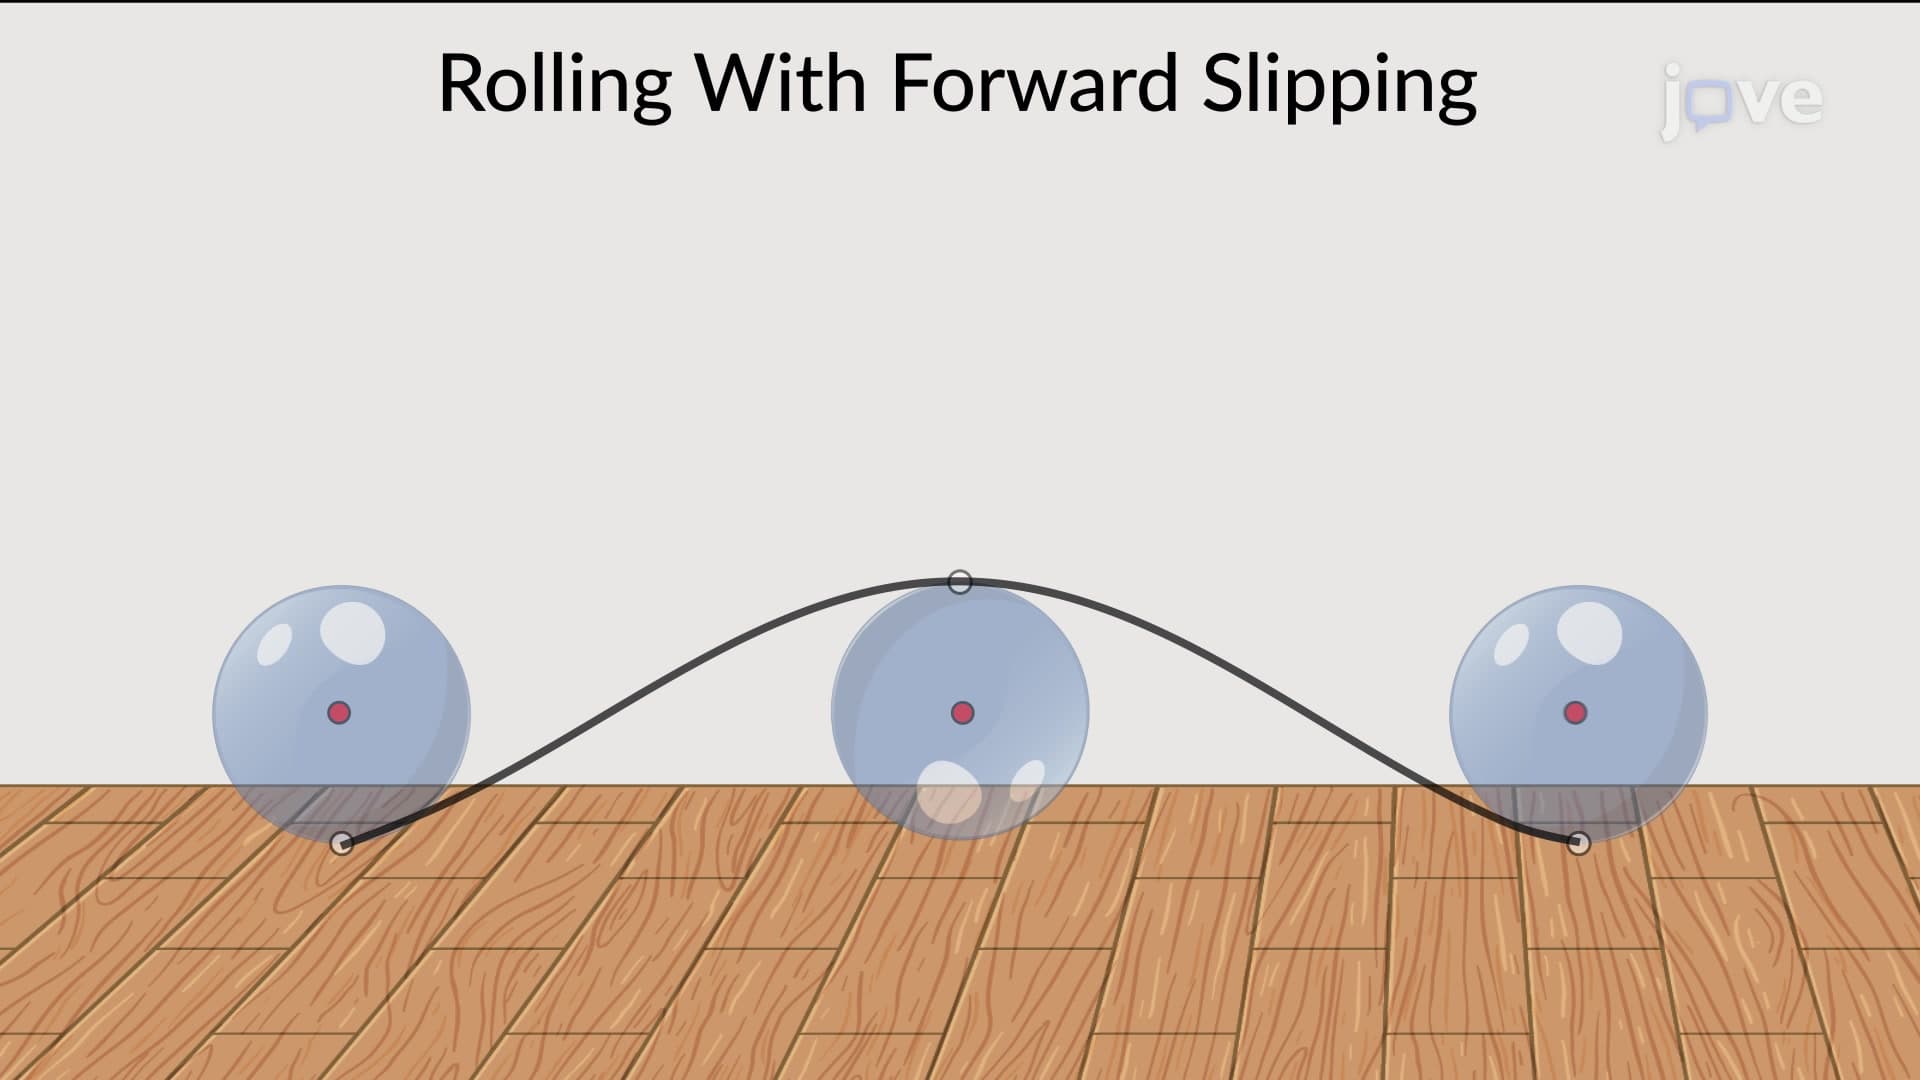
Rolling With Slipping
An object's rolling motion is characterized by its rotation around its axis, while linear motion refers to the object's translational motion along a surface. Frictional forces can...
 01:17
Rolling Resistance: Problem Solving
 01:09
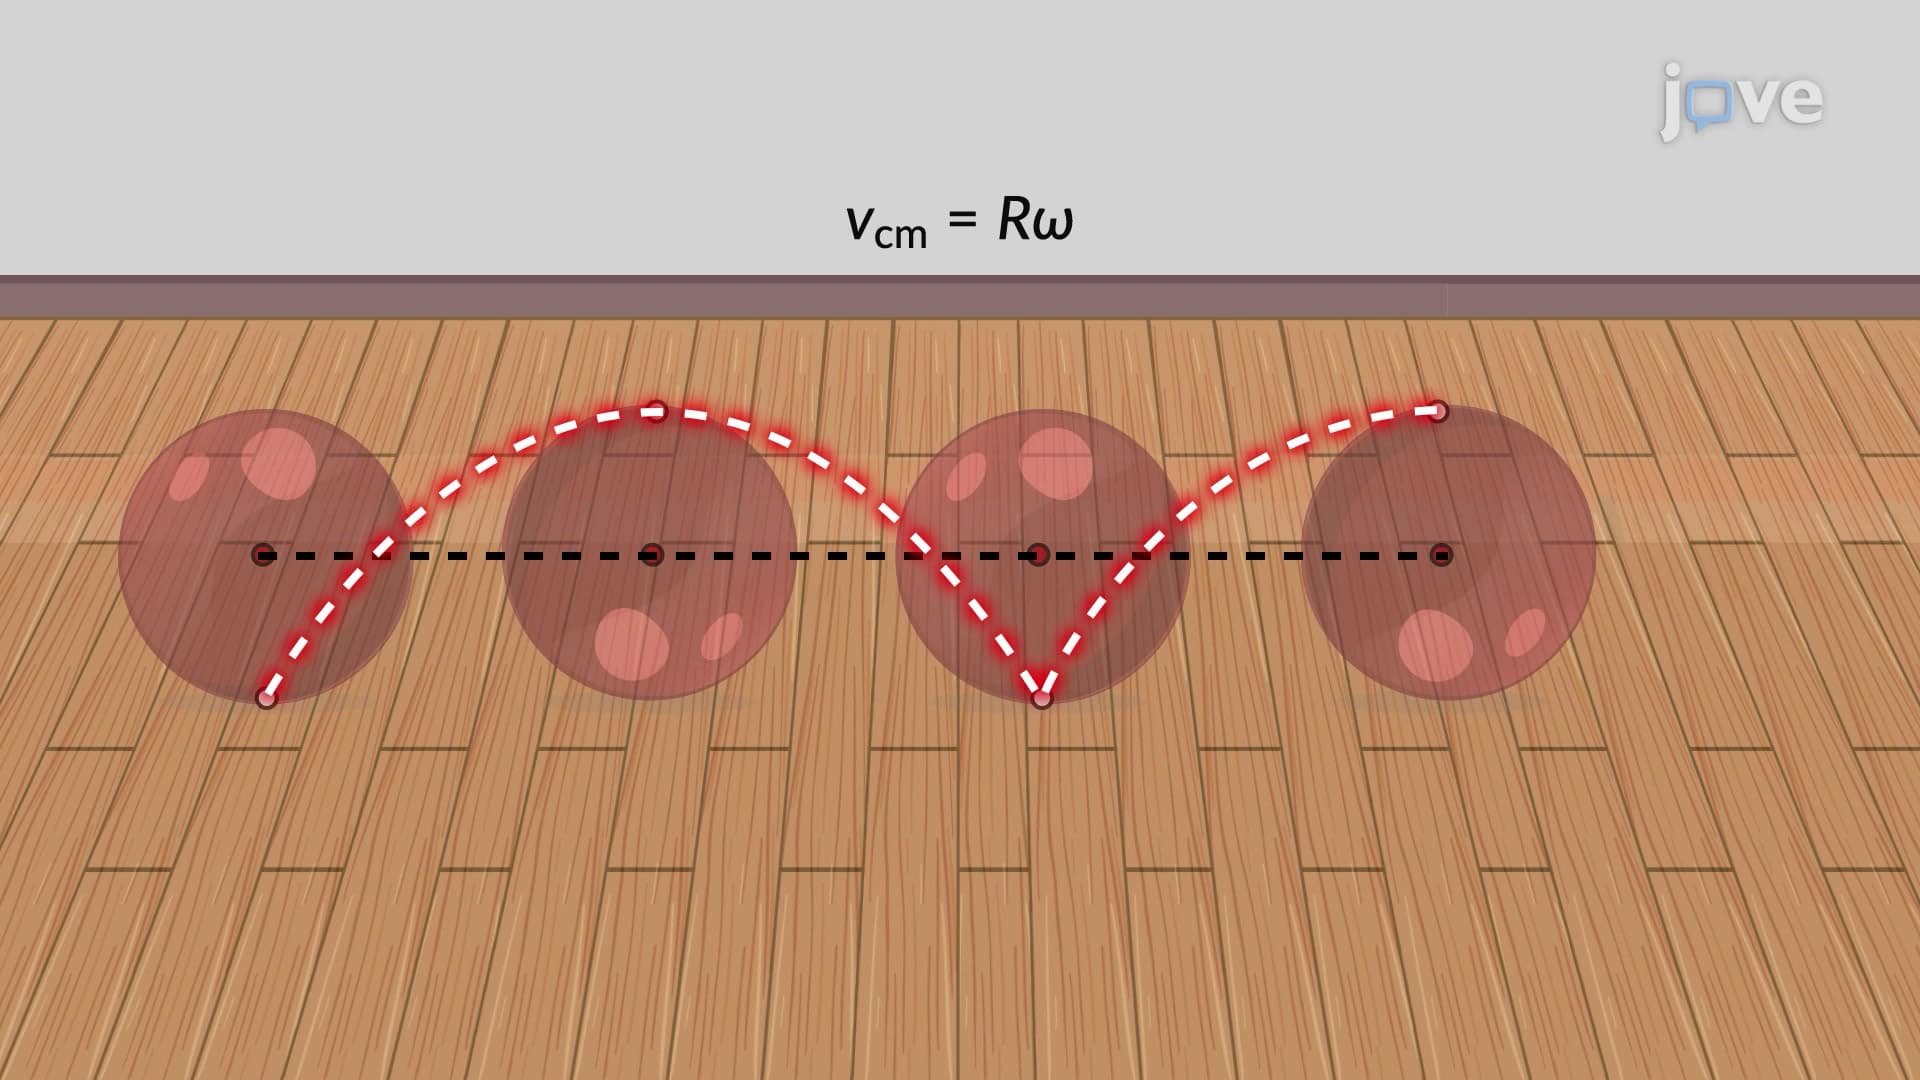
Rolling Without Slipping
 01:16
Equation of Motion: General Plane motion - Problem Solving
The friction between the roller and the ground is characterized by two coefficients. The static friction coefficient is 0.15, while the kinetic friction coefficient is 0.1. These values are crucial in understanding the interaction between...
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...