Related Experiment Video
Updated: Jul 11, 2025
Author Spotlight: Enhancing Engineering Education via WebVR-Based Online Laboratories
Published on: February 23, 2024
Genetic high-gain controller to improve the position perturbation attenuation and compact high-gain controller to
José de Jesús Rubio1, Mario Alberto Hernandez1, Francisco Javier Rosas1
1Sección de Estudios de Posgrado e Investigación, ESIME Azcapotzalco, Instituto Politécnico Nacional Av. de las Granjas no. 682, Col. Santa Catarina, Ciudad de México, 02250, Mexico.

Abstract:
From the control theory, bigger observer and controller gains are utilized to improve the position perturbation attenuation, while smaller observer and controller gains are utilized to improve the velocity perturbation attenuation. Therefore, it would be interesting to suggest optimizers to find the best observer and controller gains to improve the position or velocity perturbation attenuation. In this investigation, a high-gain controller is suggested to obtain the perturbation attenuation, a genetic high-gain controller is suggested to improve the position perturbation attenuation, and a compact high-gain controller is suggested to improve velocity perturbation attenuation in inverted pendulums. The high-gain controller utilizes a high-gain observer and a high-gain estimator to obtain the state and perturbation estimation. The genetic high-gain controller utilizes a genetic optimizer to find the best observer and controller gains. The compact high-gain controller utilizes a compact optimizer to find the best observer and controller gains. The suggested high-gain controllers are compared with the simplex and bat controllers to improve the position or velocity perturbation attenuation in two inverted pendulums.

Related Concept Videos
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:09
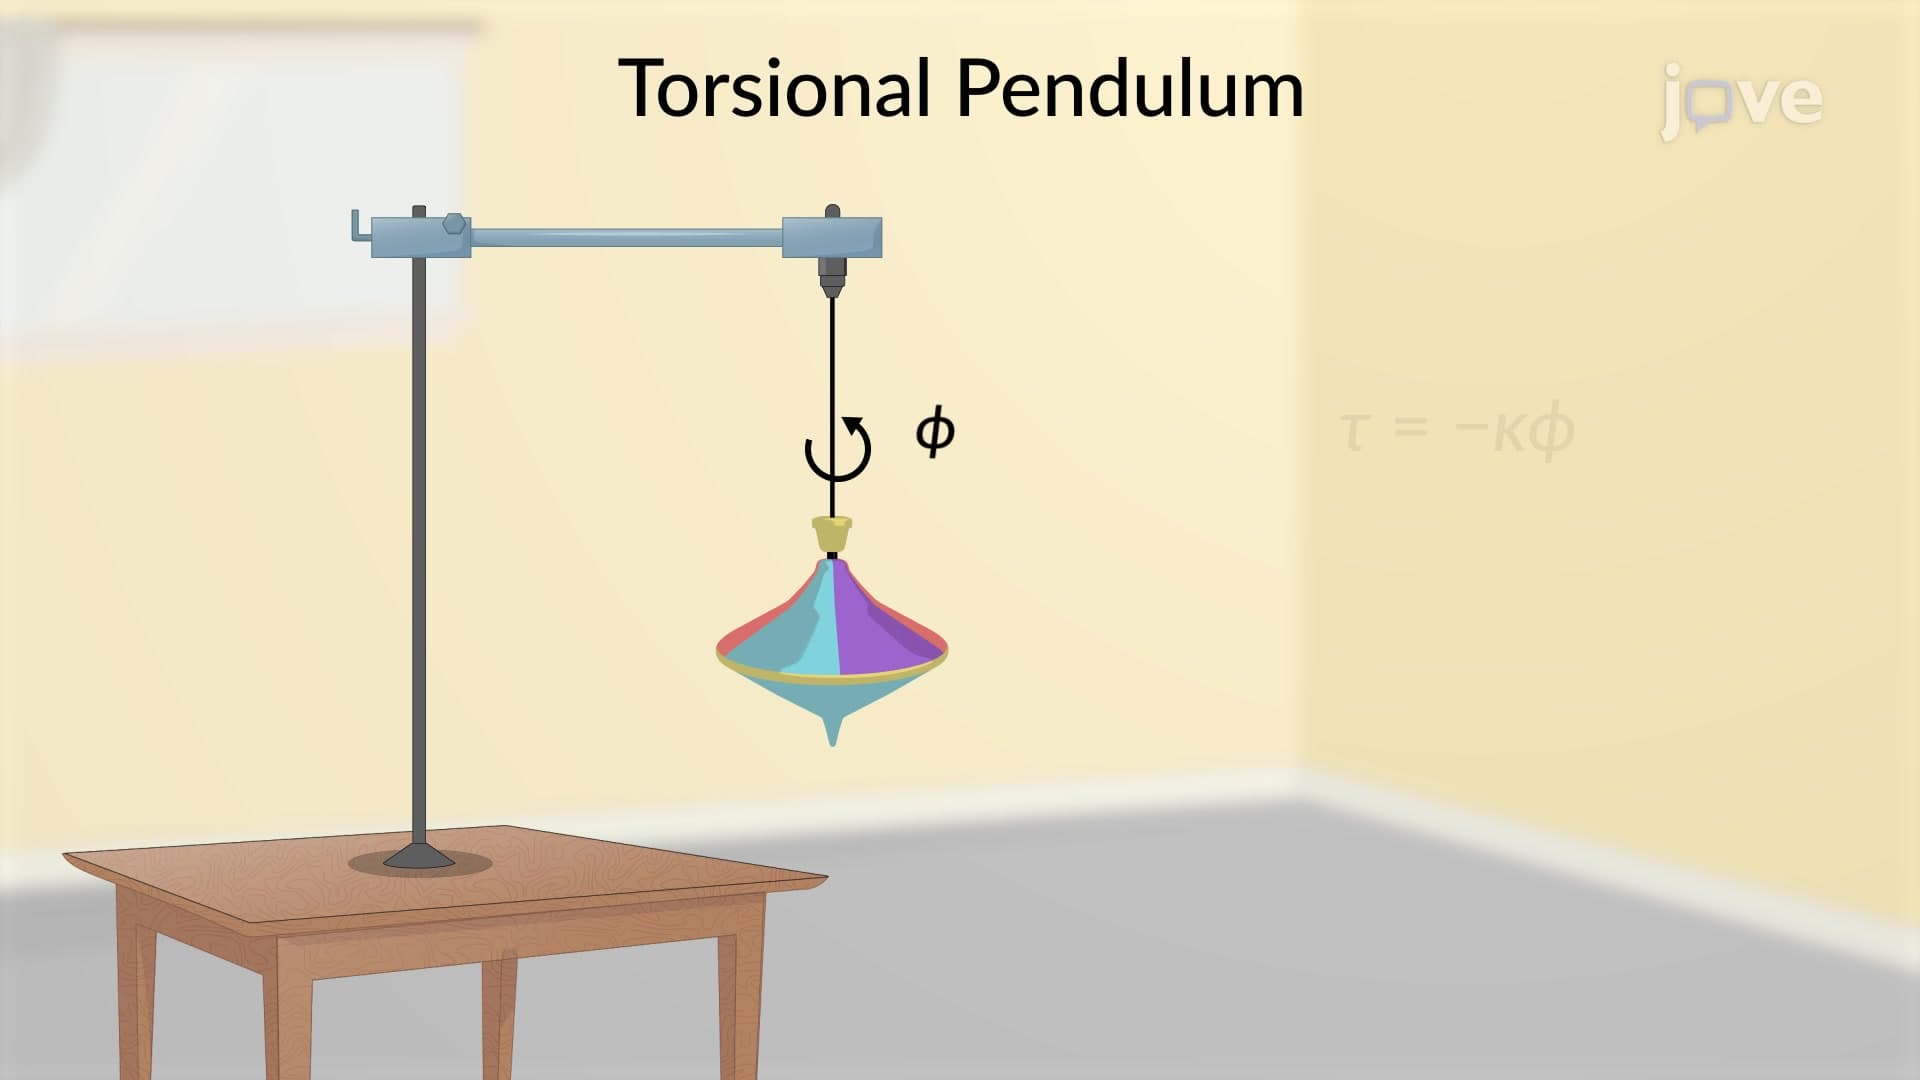
Torsional Pendulum
As long as the rigid body's angular displacement is small, its oscillation can be modeled as a linear angular oscillation. The amplitude of the oscillation is an angle. The role of mass is played...
 01:10
Simple Pendulum
The period of a simple pendulum depends on two factors: its length and the acceleration due to gravity. The period is completely independent of any other factors, such as mass or maximum displacement. For small displacements, a pendulum...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:22
Phase-lead and Phase-lag Controllers
 01:06
Physical Pendulum
When dealing with complicated systems, the mass moment of inertia is an important parameter, as it...