Angle attitude control for a networked pneumatic muscle actuators system with input quantization: A prescribed-time nonlinear ESO approach
Related Experiment Video
Updated: Jun 21, 2025
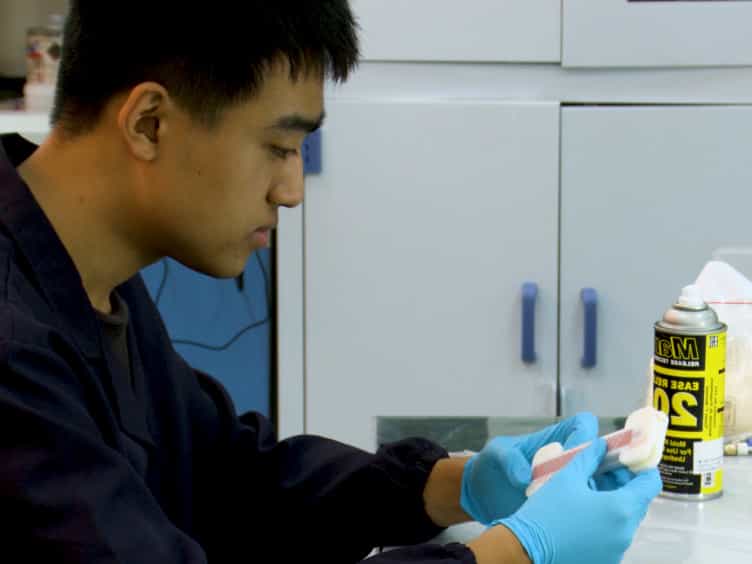
Fabrication of Soft Pneumatic Network Actuators with Oblique Chambers
Published on: August 17, 2018
Yipeng Cao1, Li Li1, Ling Zhao2
1School of Electrical Engineering, Yanshan University, Qinhuangdao 066004, China.

Abstract:
In this paper, angle attitude control is investigated for a networked pneumatic muscle actuators system (NPMAS) with input quantization and disturbance. A hysteretic quantizer is presented to effectively avoid the problem of high frequency oscillation in the process of quantization. A novel prescribed-time nonlinear extended state observer (PTNESO) is designed to continuously observe states and lumped disturbances of NPMAS, which ensures that the observation error converges in prescribed time. An active disturbance rejection control (ADRC) method based on PTNESO is designed to compensate for the lumped disturbances and achieve accurate angle tracking. A sufficient condition of bounded stability for NPMAS is given by the Lyapunov method. Finally, comparative experiments are provided to verify the effectiveness of the proposed control method.


Related Concept Videos
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:27
State Space Representation
Consider an RLC circuit, a...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:24
PI Controller: Design