Related Experiment Video
Updated: Jun 15, 2026

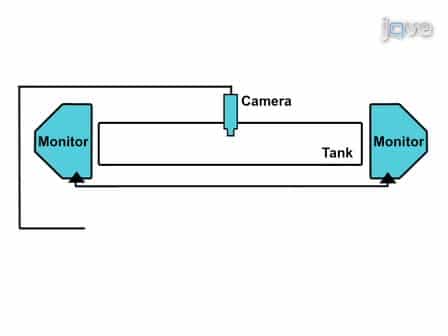
Long-term Video Tracking of Cohoused Aquatic Animals: A Case Study of the Daily Locomotor Activity of the Norway Lobster Nephrops norvegicus
Published on: April 8, 2019
Reinforcement learning-based framework for whale rendezvous via autonomous sensing robots
Ninad Jadhav1,2, Sushmita Bhattacharya1,2, Daniel Vogt1,2
1Project CETI, New York, NY, USA.

Abstract:
Rendezvous with sperm whales for biological observations is made challenging by their prolonged dive patterns. Here, we propose an algorithmic framework that codevelops multiagent reinforcement learning-based routing (autonomy module) and synthetic aperture radar-based very high frequency (VHF) signal-based bearing estimation (sensing module) for maximizing rendezvous opportunities of autonomous robots with sperm whales. The sensing module is compatible with low-energy VHF tags commonly used for tracking wildlife. The autonomy module leverages in situ noisy bearing measurements of whale vocalizations, VHF tags, and whale dive behaviors to enable time-critical rendezvous of a robot team with multiple whales in simulation. We conducted experiments at sea in the native habitat of sperm whales using an "engineered whale"-a speedboat equipped with a VHF-emitting tag, emulating five distinct whale tracks, with different whale motions. The sensing module shows a median bearing error of 10.55° to the tag. Using bearing measurements to the engineered whale from an acoustic sensor and our sensing module, our autonomy module gives an aggregate rendezvous success rate of 81.31% for a 500-meter rendezvous distance using three robots in postprocessing. A second class of fielded experiments that used acoustic-only bearing measurements to three untagged sperm whales showed an aggregate rendezvous success rate of 68.68% for a 1000-meter rendezvous distance using two robots in postprocessing. We further validated these algorithms with several ablation studies using a sperm whale visual encounter dataset collected by marine biologists.
Related Concept Videos
 01:12
Observational Learning
 01:23
Reinforcement
Positive reinforcement occurs when a behavior is followed by the presentation of a rewarding stimulus, increasing the frequency of that behavior. For example: