Related Experiment Video
Updated: May 5, 2026

Method to Measure Tone of Axial and Proximal Muscle
Published on: December 14, 2011
Adaptive terminal super-twisting prescribed performance controller for near-space vehicle based on data-driven model
Tianchen Zhang1, Yibo Ding1, Xiaokui Yue1
1School of Astronautics, Northwestern Polytechnical University, Xi'an 710072, China; Research & Development Institute of Northwestern Polytechnical University in Shenzhen, Sanhang Science &Technology Buliding, No. 45th, Gaoxin South 9th Road, Nanshan District, Shenzhen 518063, China; National Key Laboratory of Aerospace Flight Dynamics, Northwestern Polytechnical University, Xi'an 710072, China.

Abstract:
A data-driven adaptive terminal super-twisting prescribed performance controller (DASTPC) is designed for near-space vehicle (NSV) to satisfy transient and steady-state performance, and prevent scramjet choking. Firstly, a novel predetermined-time performance function is proposed to guarantee that tracking error can converge to a prescribed bound of small residual sets at the predetermined time. Compared with traditional performance functions, the predetermined-time performance function can achieve faster respond speed, realize more accurate convergence, and avoid overlarge initial value of actuators. Secondly, by combining the predetermined-time performance function with sliding mode control, a novel non-singular fast terminal sliding surface and an improved adaptive super-twisting reaching law are proposed to improve computational efficiency and accelerate convergent rate of system. The adaptive reaching law can avoid excessive gains and attenuate chattering by automatically tuning control gain. Thirdly, a deep recurrent neural network-based long-short term memory (LSTM) is employed to learn time-series historical flight dynamics data offline, so as to construct a data-driven LSTM training model. This data-driven model replaces nominal dynamics model of NSV in DASTPC, effectively suppressing model uncertainties. In addition, a homogeneous high-order sliding mode observer is utilized to compensate for external disturbances, avoiding excessive parameter estimation. Since boundary conditions of the predetermined-time performance function are fully satisfied, the DASTPC can effectively restrict amplitude of angle of attack, thus ensuring the intake condition of scramjet. Ultimately, to illustrate the superiority of DASTPC, several sets of simulations are performed on NSV subject to prescribed performance bound, external disturbances and parameter perturbations.

Related Concept Videos
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:25
Control Systems: Applications
In modern vehicles, control systems manage various functions to enhance performance and safety. The steering wheel and accelerator are primary inputs in a car's control system. The...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:21
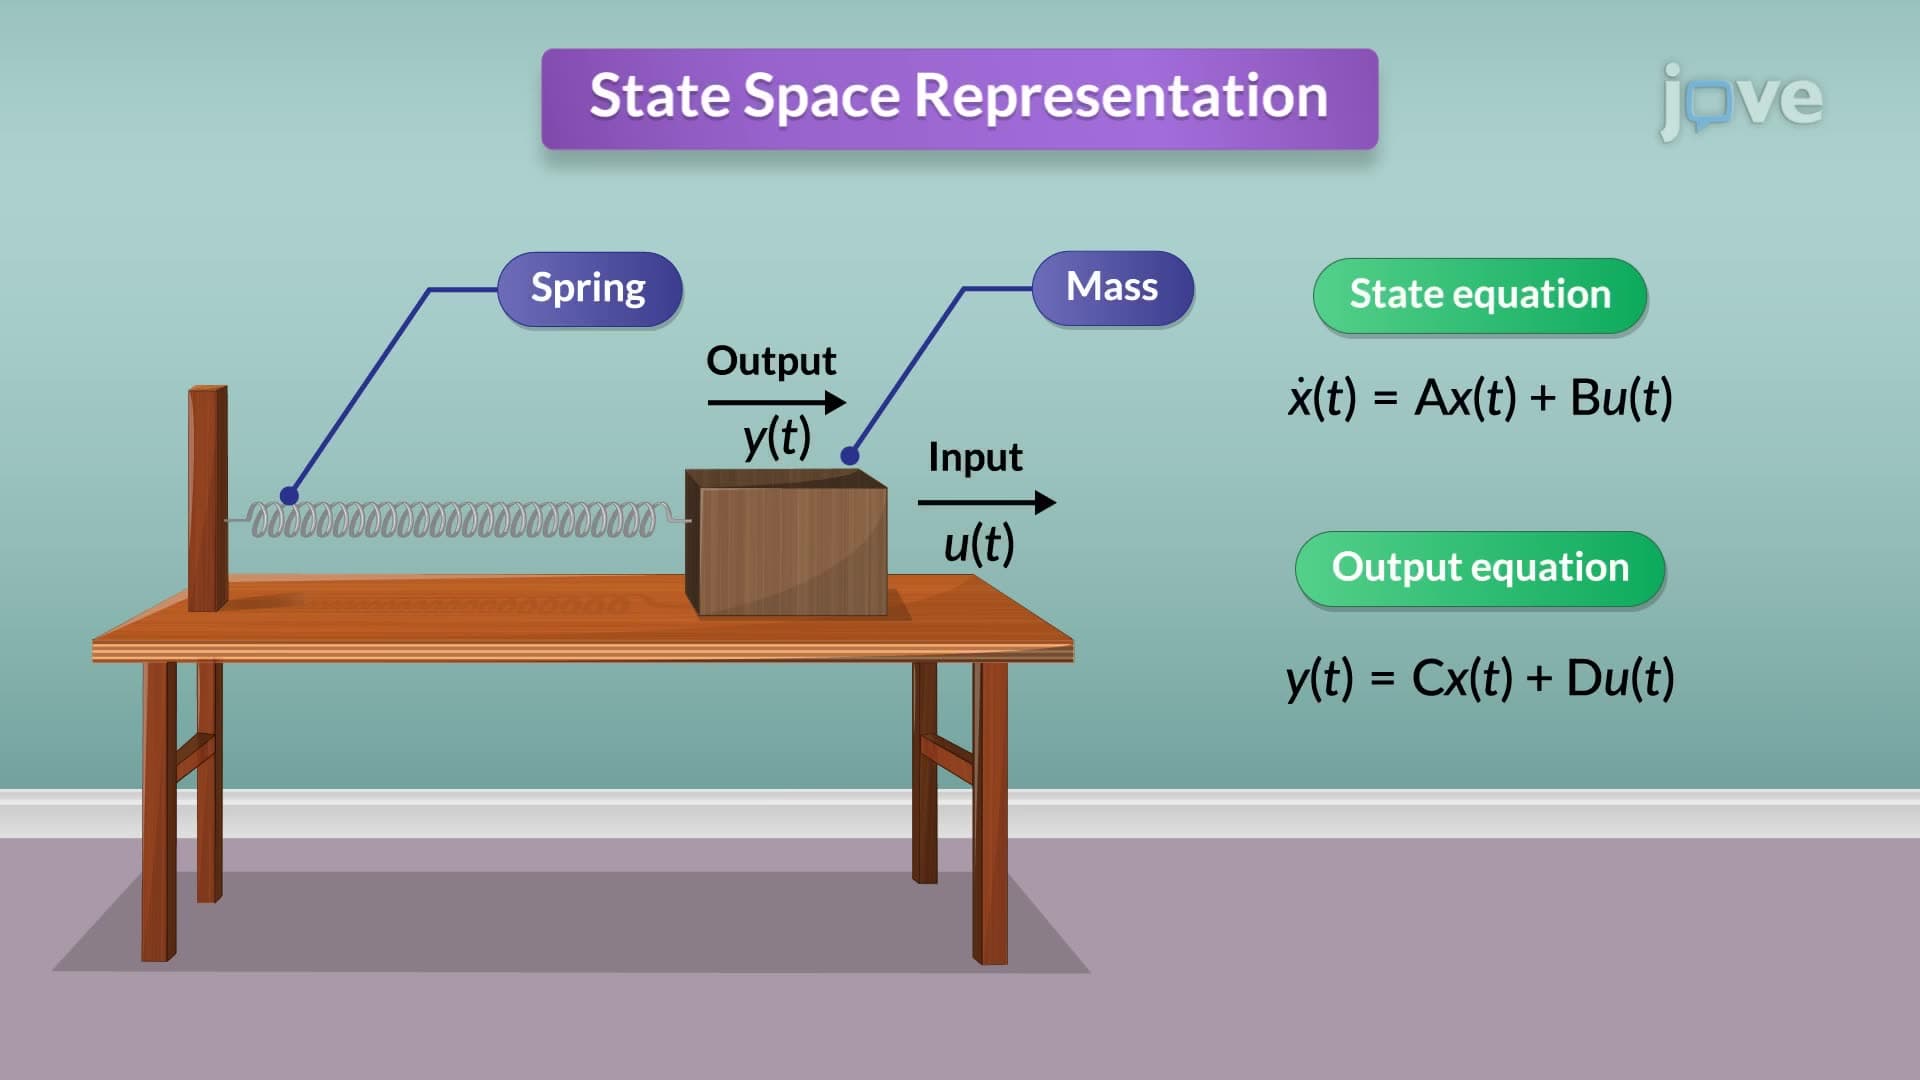
State Space to Transfer Function
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as:
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...