Related Experiment Video
Updated: Jun 16, 2025


Evaluation of an Exclusive Spur Dike U-Turn Design with Radar-Collected Data and Simulation
Published on: February 1, 2020
Modeling decision-making during unprotected left turns using interpretable deep learning and uncertainty
Yubin Chen1, Yajie Zou1, Jun Liu2
1Key Laboratory of Road and Traffic Engineering of Ministry of Education, Tongji University, Shanghai 201804, China.

Abstract:
Unprotected left turns present challenges to drivers, as they must manage potential conflicts at intersections, which requires a decision-making process different from that in other driving scenarios. While many studies have modeled human decision-making in unprotected left-turn situations at a behavioral level, most overlook the variability of key information that influences driving behavior and rarely explore the intrinsic mechanisms of decision-making. This study analyzes the decision-making process of drivers in unprotected left-turn scenarios from the perspective of decision uncertainty and explores the relationship between uncertainty and safety. First, a conflict area calculation method is introduced to identify unprotected left-turn interaction events. Next, a transformer model combined with Shapley Additive Explanations is used to identify the key variables driving left-turn decision-making. Finally, Jensen-Shannon divergence are employed to quantify decision-making uncertainty. We explore two types of unprotected left-turn scenarios: left-turn yielding and left-turn proceeding. The experimental results reveal that: (1) left-turning vehicles prioritize static variables, such as waiting time and vehicle type as key variables, while oncoming vehicles focus more on dynamic variables like time to the stop line and speed difference; (2) increased time pressure leads drivers to emphasize on lateral speed and yaw angles during critical decision phases; and (3) higher uncertainty levels are often accompanied by longer negotiation processes and shorter post-encroachment times, which can increase the likelihood of unsafe maneuvers, such as emergency braking. These insights are instrumental in informing decision-making frameworks for autonomous vehicles navigating unprotected left-turn scenarios.


Related Concept Videos
 01:09
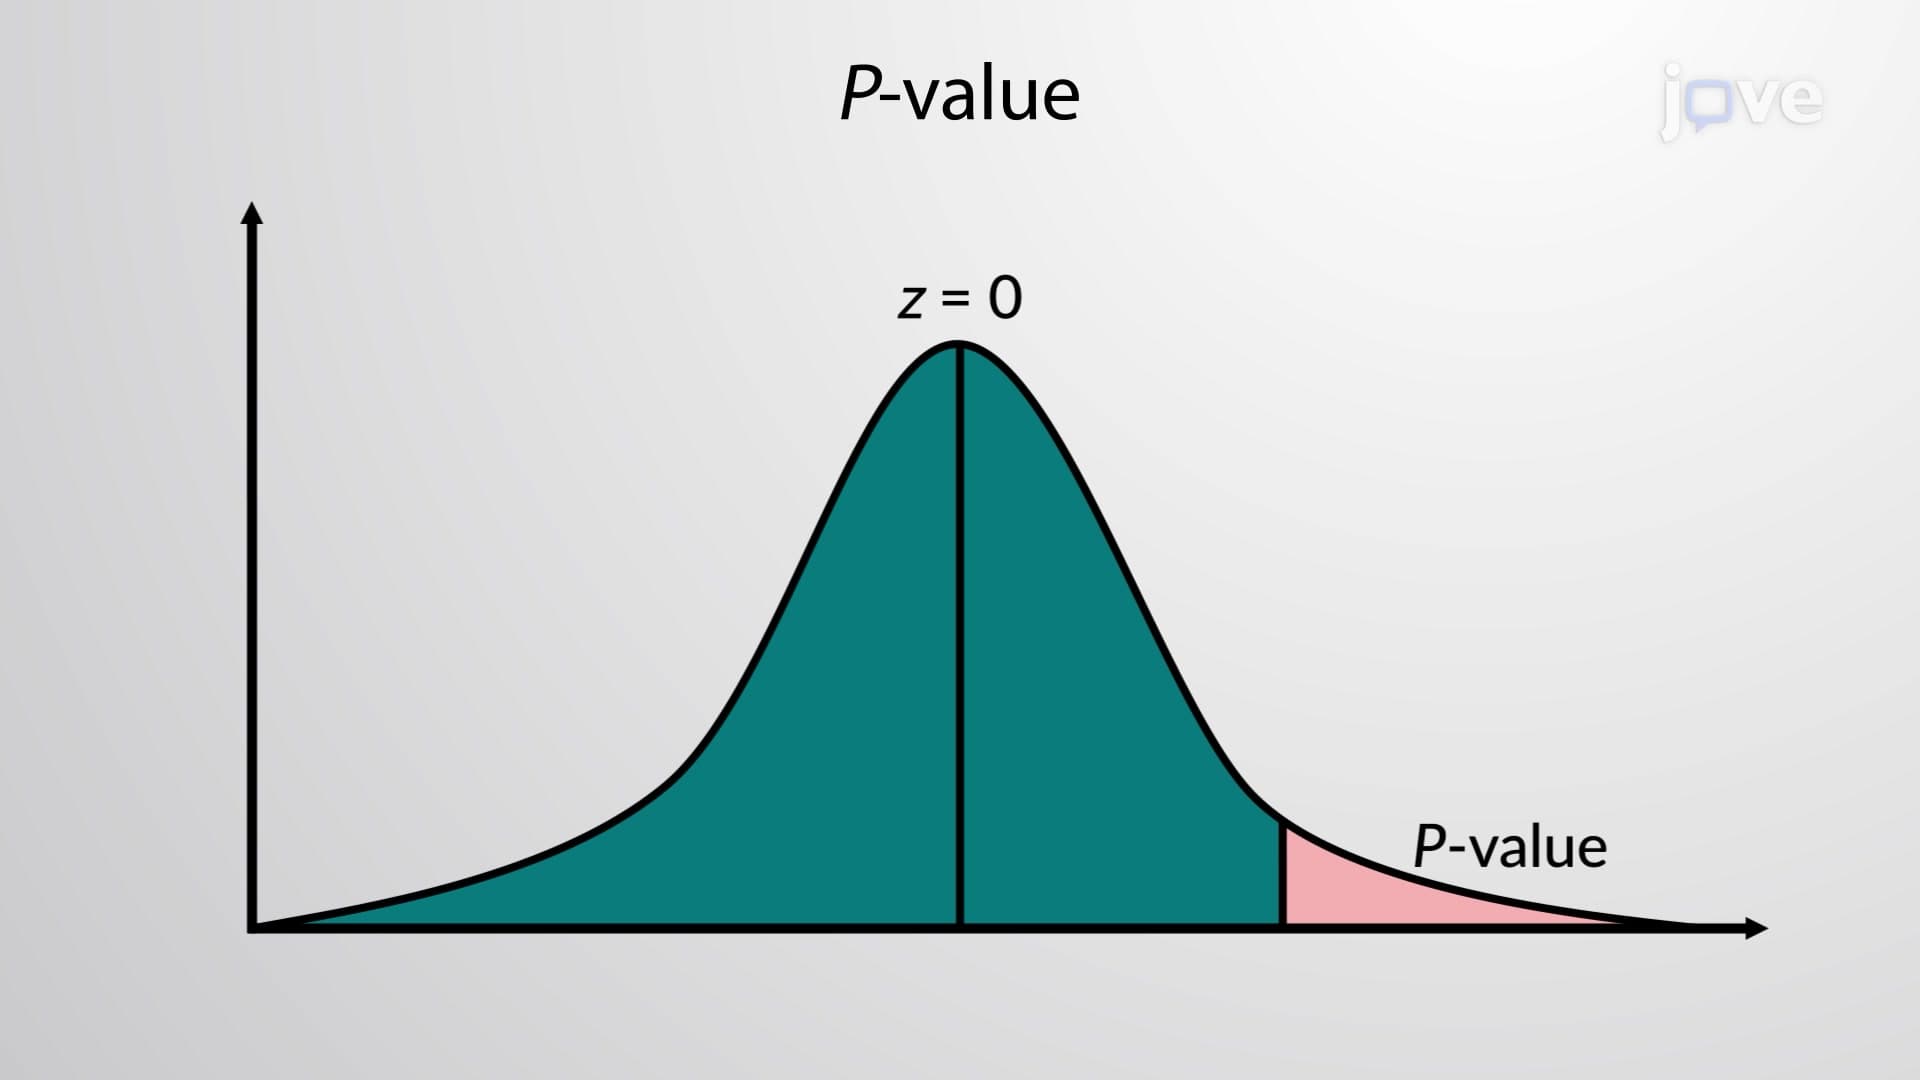
Decision Making: P-value Method
First, a specific claim about the population parameter is proposed. The claim is based on the research question and is stated in a simple form. Further, an opposing statement to the claim is also stated. These statements can act as null and alternative hypotheses: a null hypothesis would be a neutral statement while the alternative hypothesis can...
 00:59
Uncertainty: Overview
 01:14
Decision Making: Traditional Method
First, a specific claim about the population parameter is decided based on the research question and is stated in a simple form. Further, an opposing statement to this claim is also stated. These statements can act as null and alternative hypotheses, out of which a null hypothesis would be a...
 01:34
Woodward–Hoffmann Selection Rules and Microscopic Reversibility
 00:54
Uncertainty: Confidence Intervals
 00:59
Propagation of Uncertainty from Random Error