Related Experiment Video
Updated: Sep 13, 2025
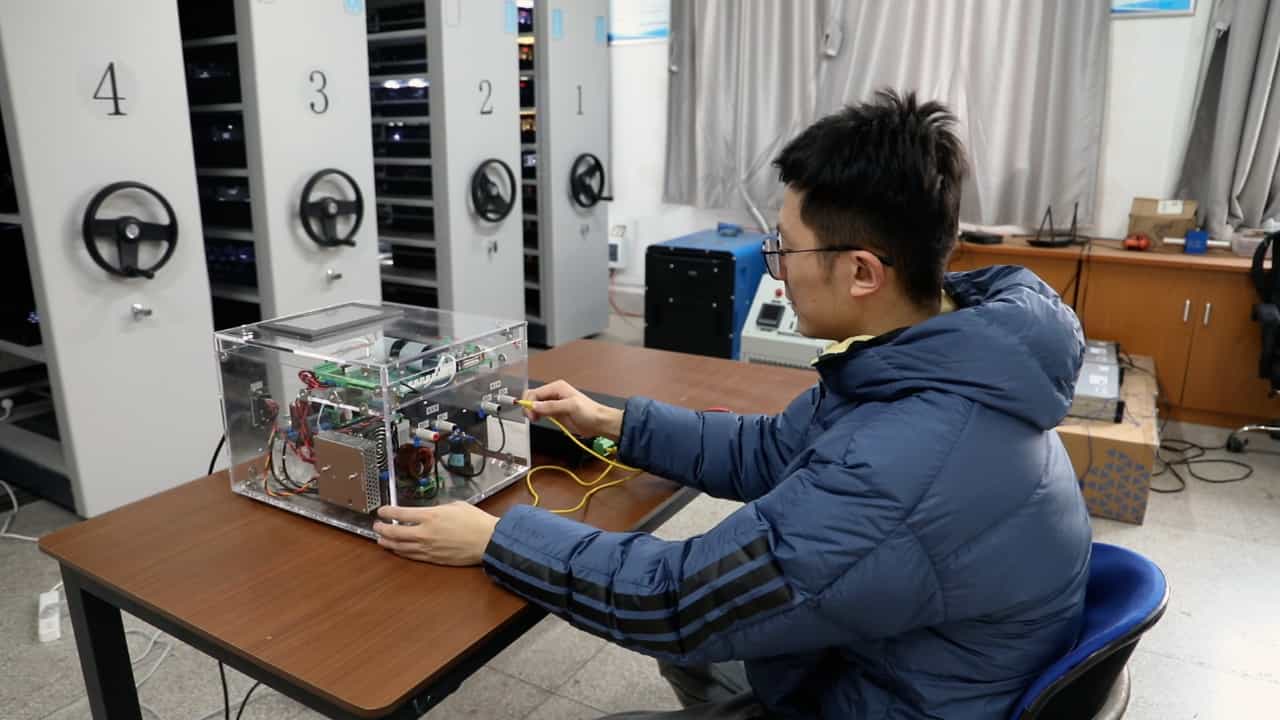
Experimental Investigation of the Hierarchical Control in DC Microgrids Using a Real-time Simulator
Published on: February 14, 2025
Modularized and hierarchical state estimation strategy of 4WIDEV based on global-local dynamics model decoupling
Te Chen1, Zikun Zhang2, Xing Xu2
1Automotive Engineering Research Institute, Jiangsu University, Zhenjiang 212013, China; Key Laboratory of Advanced Manufacture Technology for Automobile Parts (Chongqing University of Technology), Ministry of Education, Chongqing 400054, China; Provincial Engineering Research Center for New Energy Vehicle Intelligent Control and Simulation Test Technology of Sichuan, Xihua University, Chengdu 610039, China.

Abstract:
This study introduces a hierarchically structured estimation strategy for four-wheel independent drive electric vehicles (4WIDEV), employing global-local dynamic model decoupling to achieve high-fidelity state estimation while avoiding reliance on empirical tire models.An electric drive wheel model (EDWM) was established and an unknown input observation equation was constructed using a proportional integral observer (PIO) method, achieving the decoupling between longitudinal tire force and model state variables. Through the local decoupling of the vehicle dynamics model, observation equations for lateral tire forces acting on the front and rear axles were formulated. An unknown input observer (UIO) was subsequently designed to estimate lateral tire forces, accompanied by rigorous stability proofs for the observer's asymptotic convergence.Then, a hierarchical state estimation strategy was proposed based on the strong tracking extended Kalman filter algorithm (STEKF). Simulation analyses and experimental validations collectively demonstrate that the proposed strategy can effectively improve the estimation accuracy of vehicle states.
More Related Videos
 11:53
The Modular Design and Production of an Intelligent Robot Based on a Closed-Loop Control Strategy
Published on: October 14, 2017
 06:45
Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
Related Concept Videos
 01:27
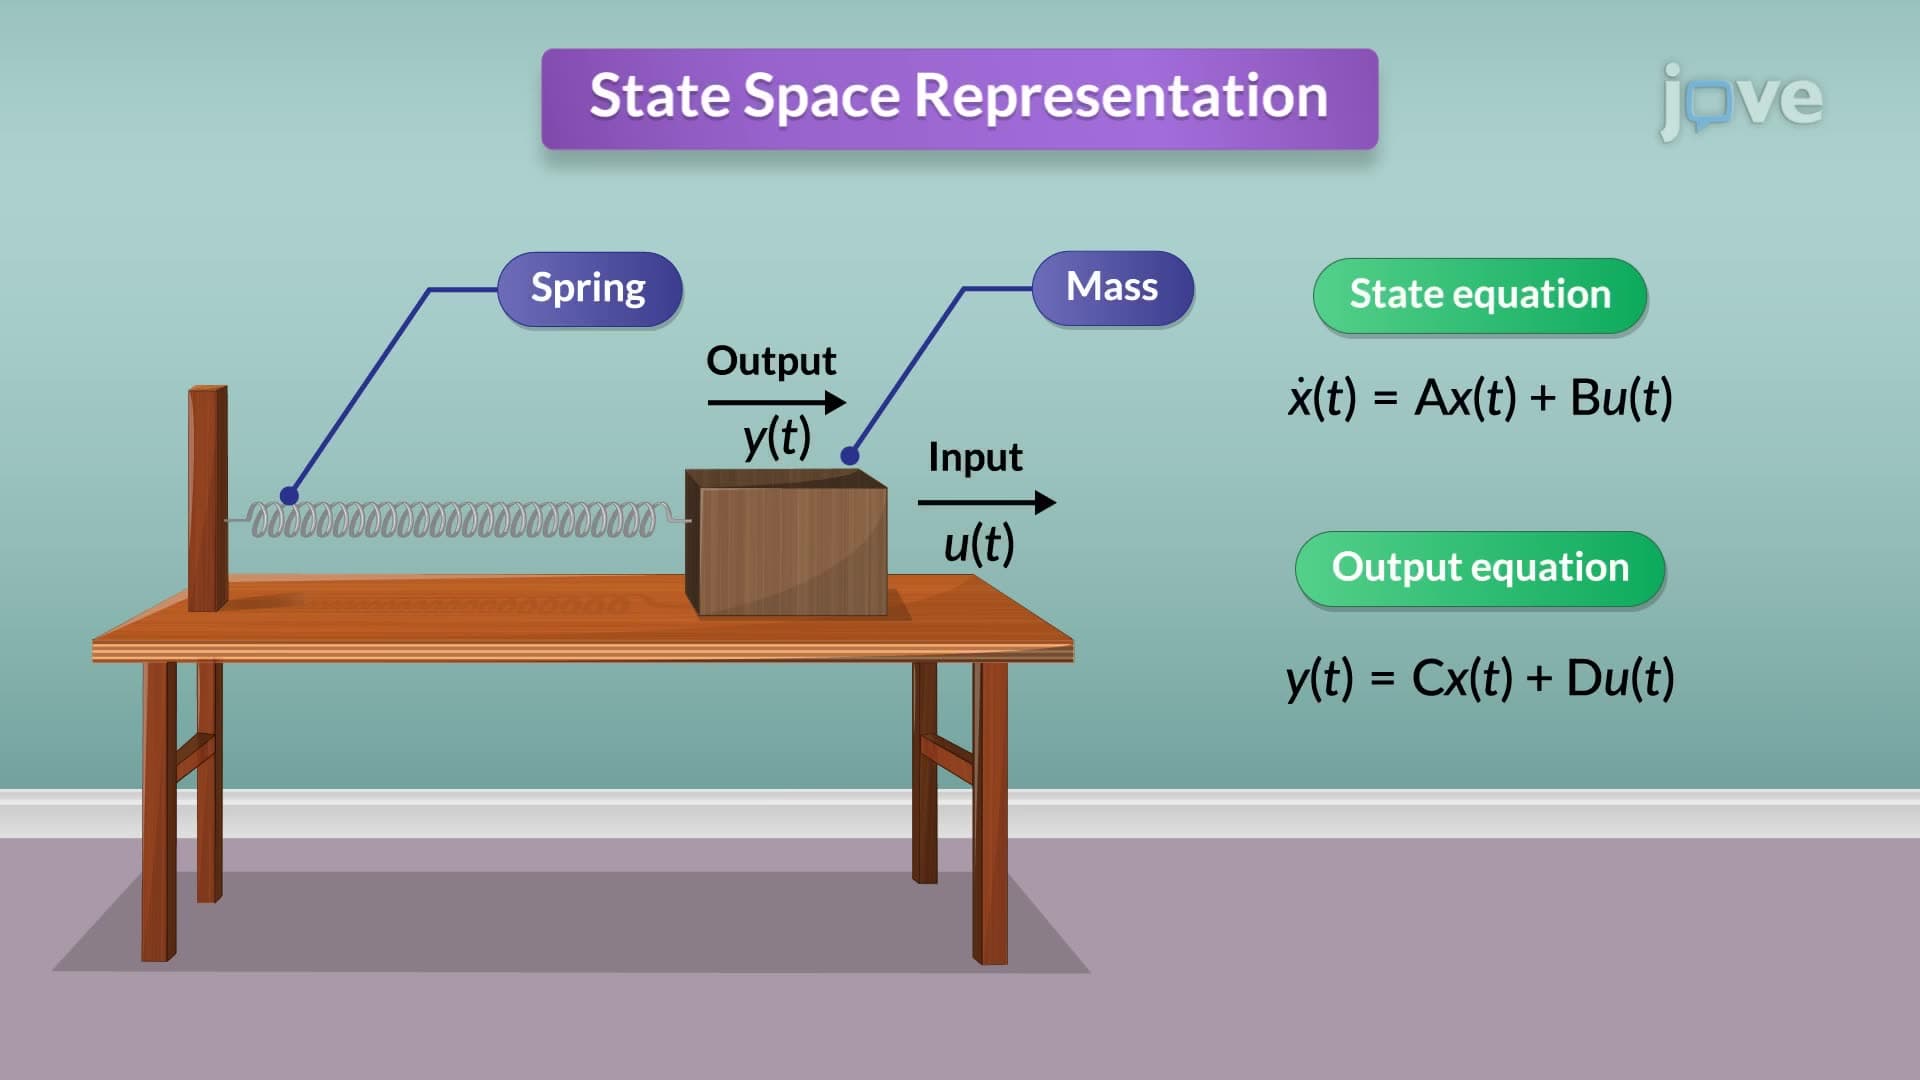
State Space Representation
Consider an RLC circuit, a...
 01:21
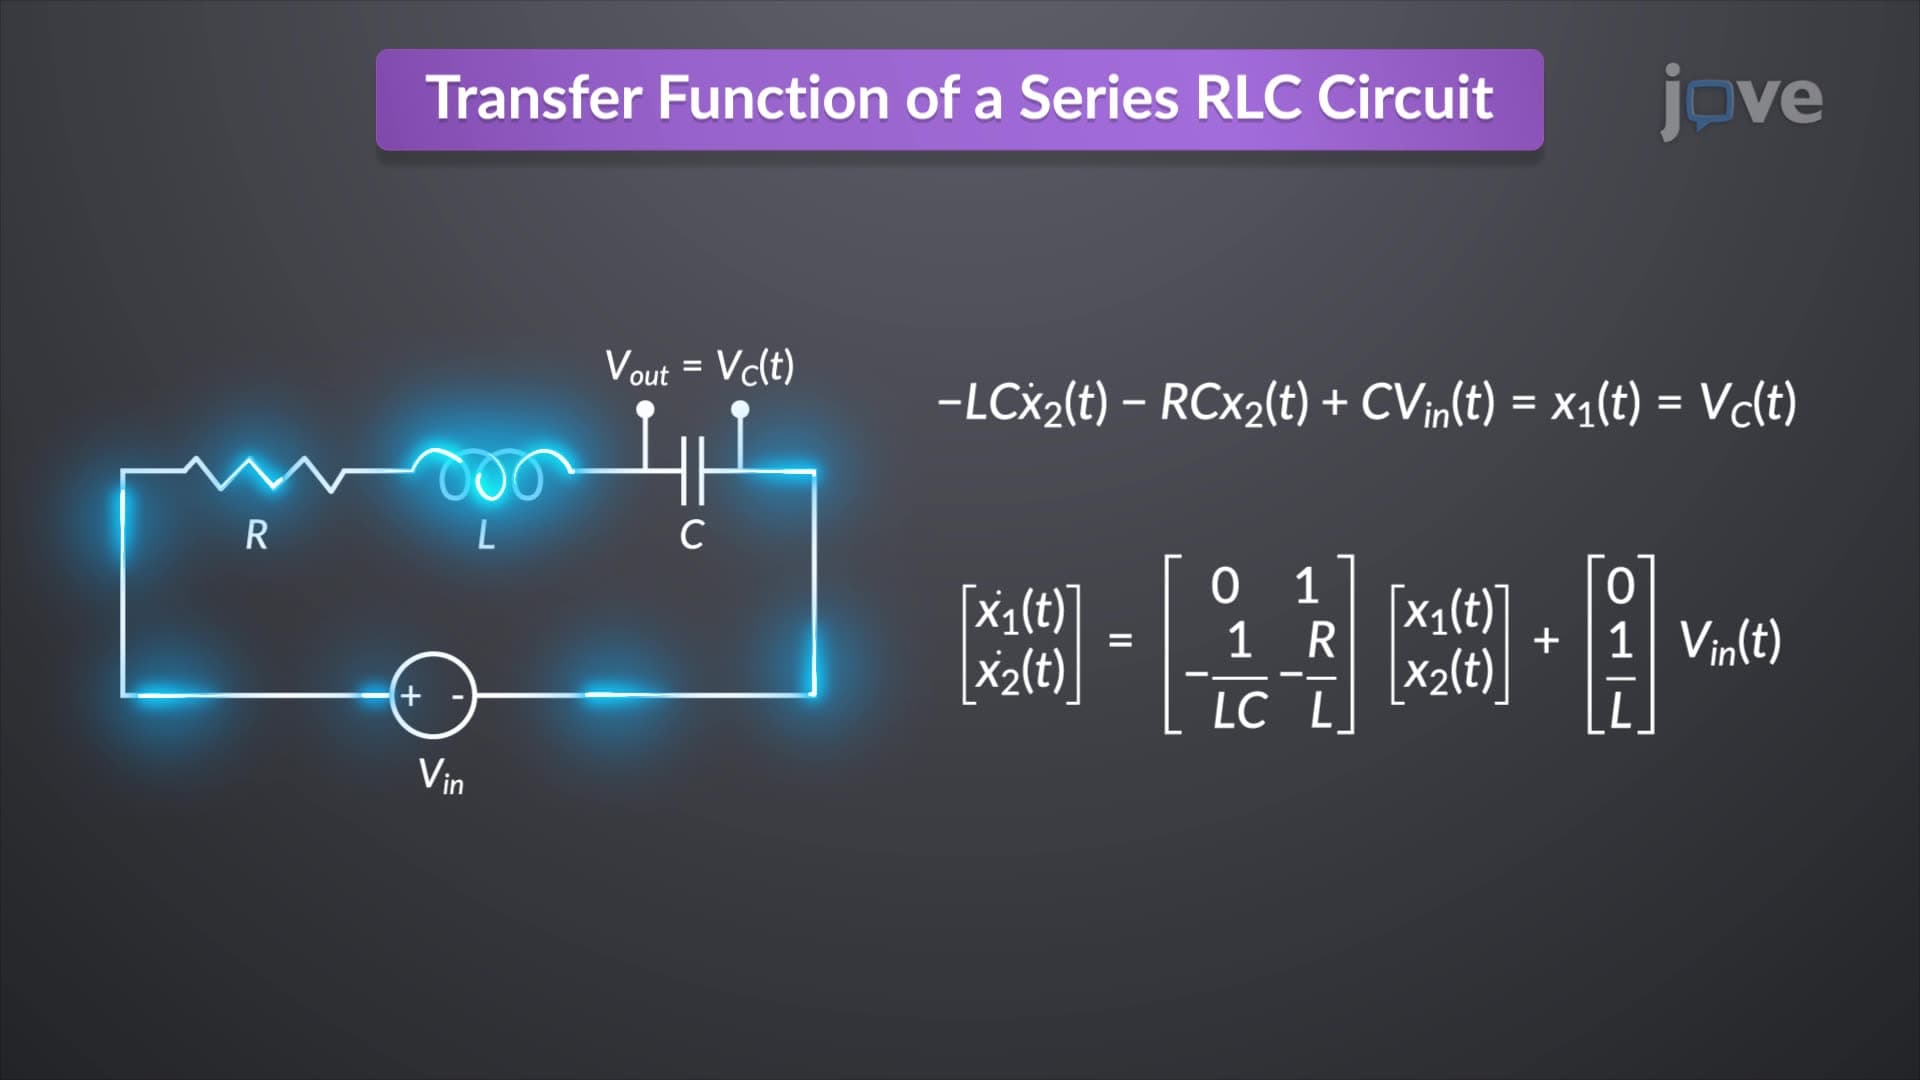
State Space to Transfer Function
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as:
 01:23
Transfer Function to State Space
In an...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:24
One-Compartment Open Model: Wagner-Nelson and Loo Riegelman Method for ka Estimation
On...
 01:22
Multi-input and Multi-variable systems
In the absence...