Related Experiment Video
Updated: Jan 8, 2026


WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
Neuroadaptive fault-tolerant tracking control of fractional-order nonaffine nonlinear systems with output constraints
Fa Chen1, Lu Chen2, Huiyuan Li3
1The College of Information Science and Technology, Donghua University, Shanghai 201620, China.

Abstract:
In this article, a fault-tolerant adaptive tracking control issue is investigated for nonaffine fractional-order nonlinear systems (FONSs) with prescribed-time interval output constraints (PTIOCs), nonlinear input and actuator fault. The PTIOCs mean that the output constraints begin sometime after system operation and have a prescribed-time duration. It should be emphasized that both the start moment and the end moment of the constraints can be determined by the user. Using the improved dependent-constrained-error function and prescribed-time scaling function, as well as with the help of a barrier function, the PTIOCs issue is transformed into verifying the boundedness of the barrier function. Moreover, an adaptive fault-tolerant control algorithm is developed to mitigate the effects of actuator faults in FONSs while accommodating multiple constraints and nonlinear inputs without requiring structural changes to the controller. The validity of the proposed scheme is then substantiated by simulations.
More Related Videos
 06:45
Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
 09:01
Gain-compensation Methodology for a Sinusoidal Scan of a Galvanometer Mirror in Proportional-Integral-Differential Control Using Pre-emphasis Techniques
Published on: April 4, 2017
Related Concept Videos
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:21
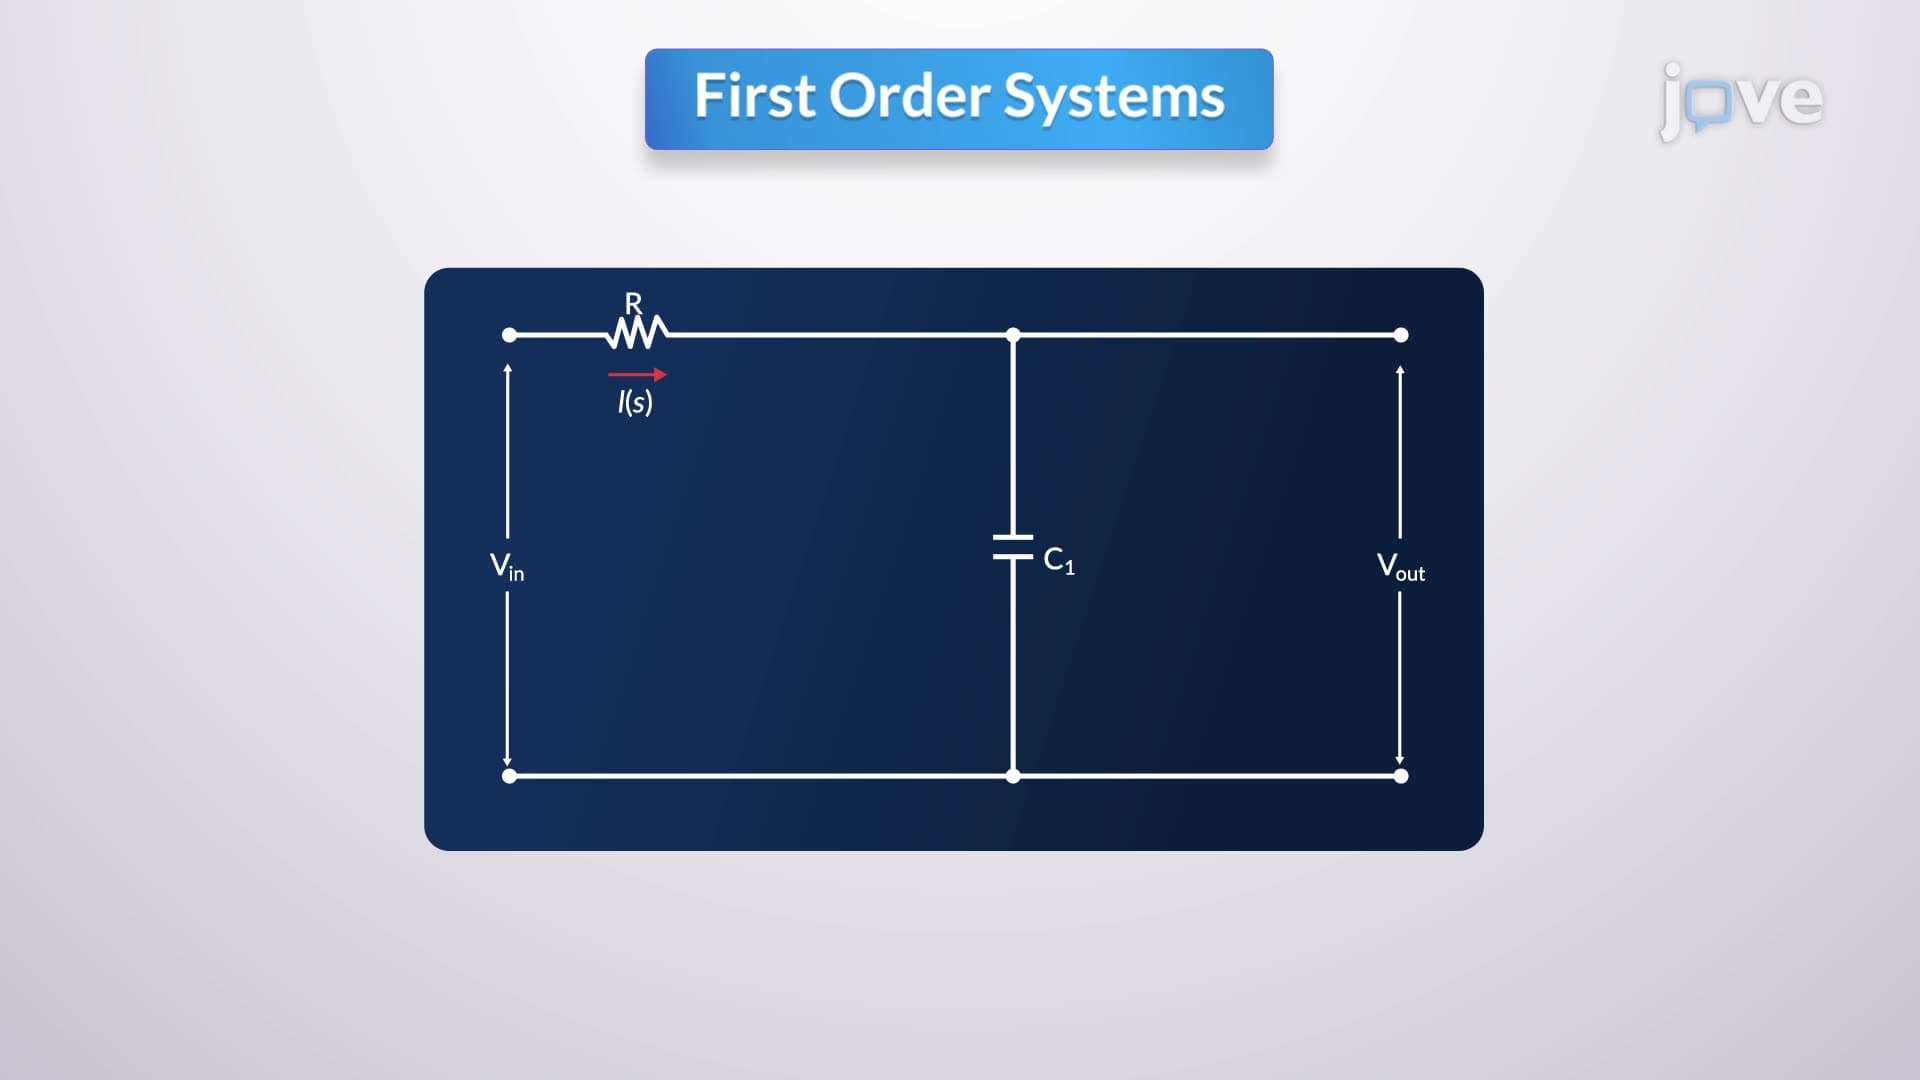
First Order Systems
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...