Fixed-time sliding mode composite control with prescribed performance for uncertain Stewart parallel mechanism tracking in task space
Related Experiment Video
Updated: Jan 7, 2026

Operation of the Collaborative Composite Manufacturing CCM System
Published on: October 1, 2019
1School of Electrical and Information Engineering, Jiangsu University, Zhenjiang 212013, China.

Abstract:
To improve the tracking control performance in task space of the Stewart parallel mechanism (SPM) with disturbances and uncertainties, a fixed-time sliding mode composite control with prescribed performance (FxT-SMCC-PP) method is developed. First, by constructing a sliding mode term adaptive to the changes of the lumped uncertainty, and embedding fixed-time performance parameters, a fixed-time adaptive sliding mode disturbance observer (FxTASMDO) is designed. Second, the SPM's tracking error is constrained by an asymmetric hyperbolic cosecant prescribed performance function and transformed into a steady equivalent error by modifying the constraint transformation function. Based on the equivalent error, a fixed-time sliding mode control with prescribed performance is designed and combined with FxTASMDO to form the FxT-SMCC-PP, which can achieve the SPM's fast and non-overshoot transient response, high steady-state tracking accuracy, and reduction in control energy consumption. Finally, the effectiveness of FxT-SMCC-PP is validated through simulation and prototype experiments.
More Related Videos
 09:01
Gain-compensation Methodology for a Sinusoidal Scan of a Galvanometer Mirror in Proportional-Integral-Differential Control Using Pre-emphasis Techniques
Published on: April 4, 2017
 06:58
A Structured Rehabilitation Protocol for Improved Multifunctional Prosthetic Control: A Case Study
Published on: November 6, 2015
Related Concept Videos
 01:10
Relative Motion Analysis - Acceleration
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:30
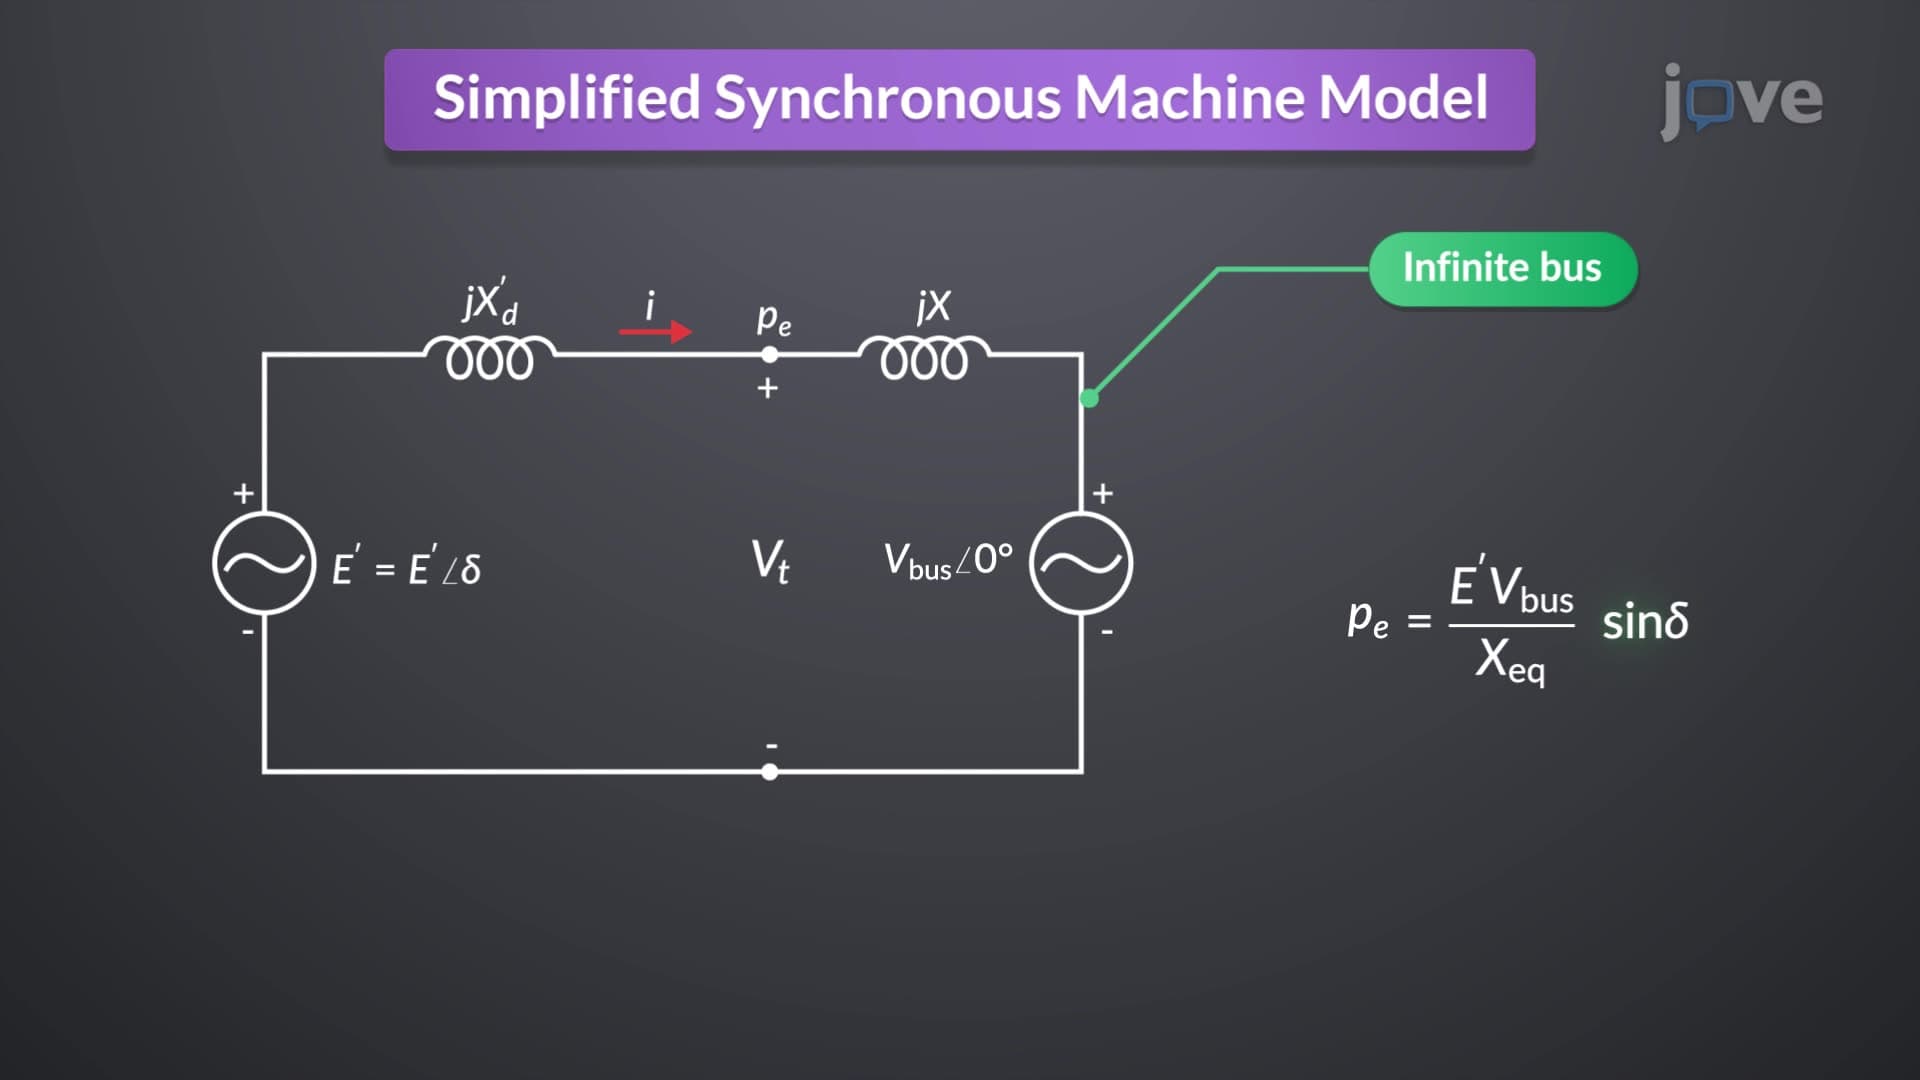
Simplified Synchronous Machine Model
In this model, each generator is connected to a...