Related Experiment Video
Updated: Jan 28, 2026


SSVEP-based Experimental Procedure for Brain-Robot Interaction with Humanoid Robots
Published on: November 24, 2015
Explosive Output to Enhance Jumping Ability: A Variable Reduction Ratio Design Paradigm for Humanoid Robot Knee Joint
Xiaoshuai Ma1, Qingqing Li1, Haochen Xu1
1School of Mechatronic Engineering, Beijing Institute of Technology, Beijing 100081, China.

Abstract:
Enhancing the explosive power output of the knee joints is critical for improving the agility and obstacle crossing of humanoid robots. However, a mismatch between the knee-to-CoM transmission ratio and jumping demands, together with power-loss-induced motor performance degradation at high speeds, shortens the high-power operating window and limits jump performance. To address this, this paper introduces a variable-reduction-ratio knee-joint paradigm in which the reduction ratio is coupled to the joint angle and decreases during extension. Analysis of motor output and knee kinematics motivates coupling the reduction ratio to the joint angle. A high initial ratio increases the takeoff torque, and a gradual decrease limits motor speed and power losses, extending the high-power window. A linear-actuator-driven guide-rod mechanism realizes this strategy, and parameter optimization guided by explosive jump control is employed to select the design parameters. Experimental validation demonstrates a high jump of 0.63 m on a single-joint platform (a theoretical improvement of 31.9% over the optimal fixed-ratio baseline under the tested conditions). Integrated into a humanoid robot, the proposed design enables a 1.1 m long jump, a 0.5 m high jump, and a 0.5 m box jump.
Related Concept Videos
 01:23
Knee Joint
A total of seven ligaments support the knee joint. The patellar ligament, which is also attached to the quadriceps femoris...
 01:28
Design Example: Joints in Concrete Pavements
Contraction joints are typically formed by sawing a groove into the concrete shortly after it has hardened. This creates a weakened vertical plane, deliberately encouraging cracking at...
 01:16
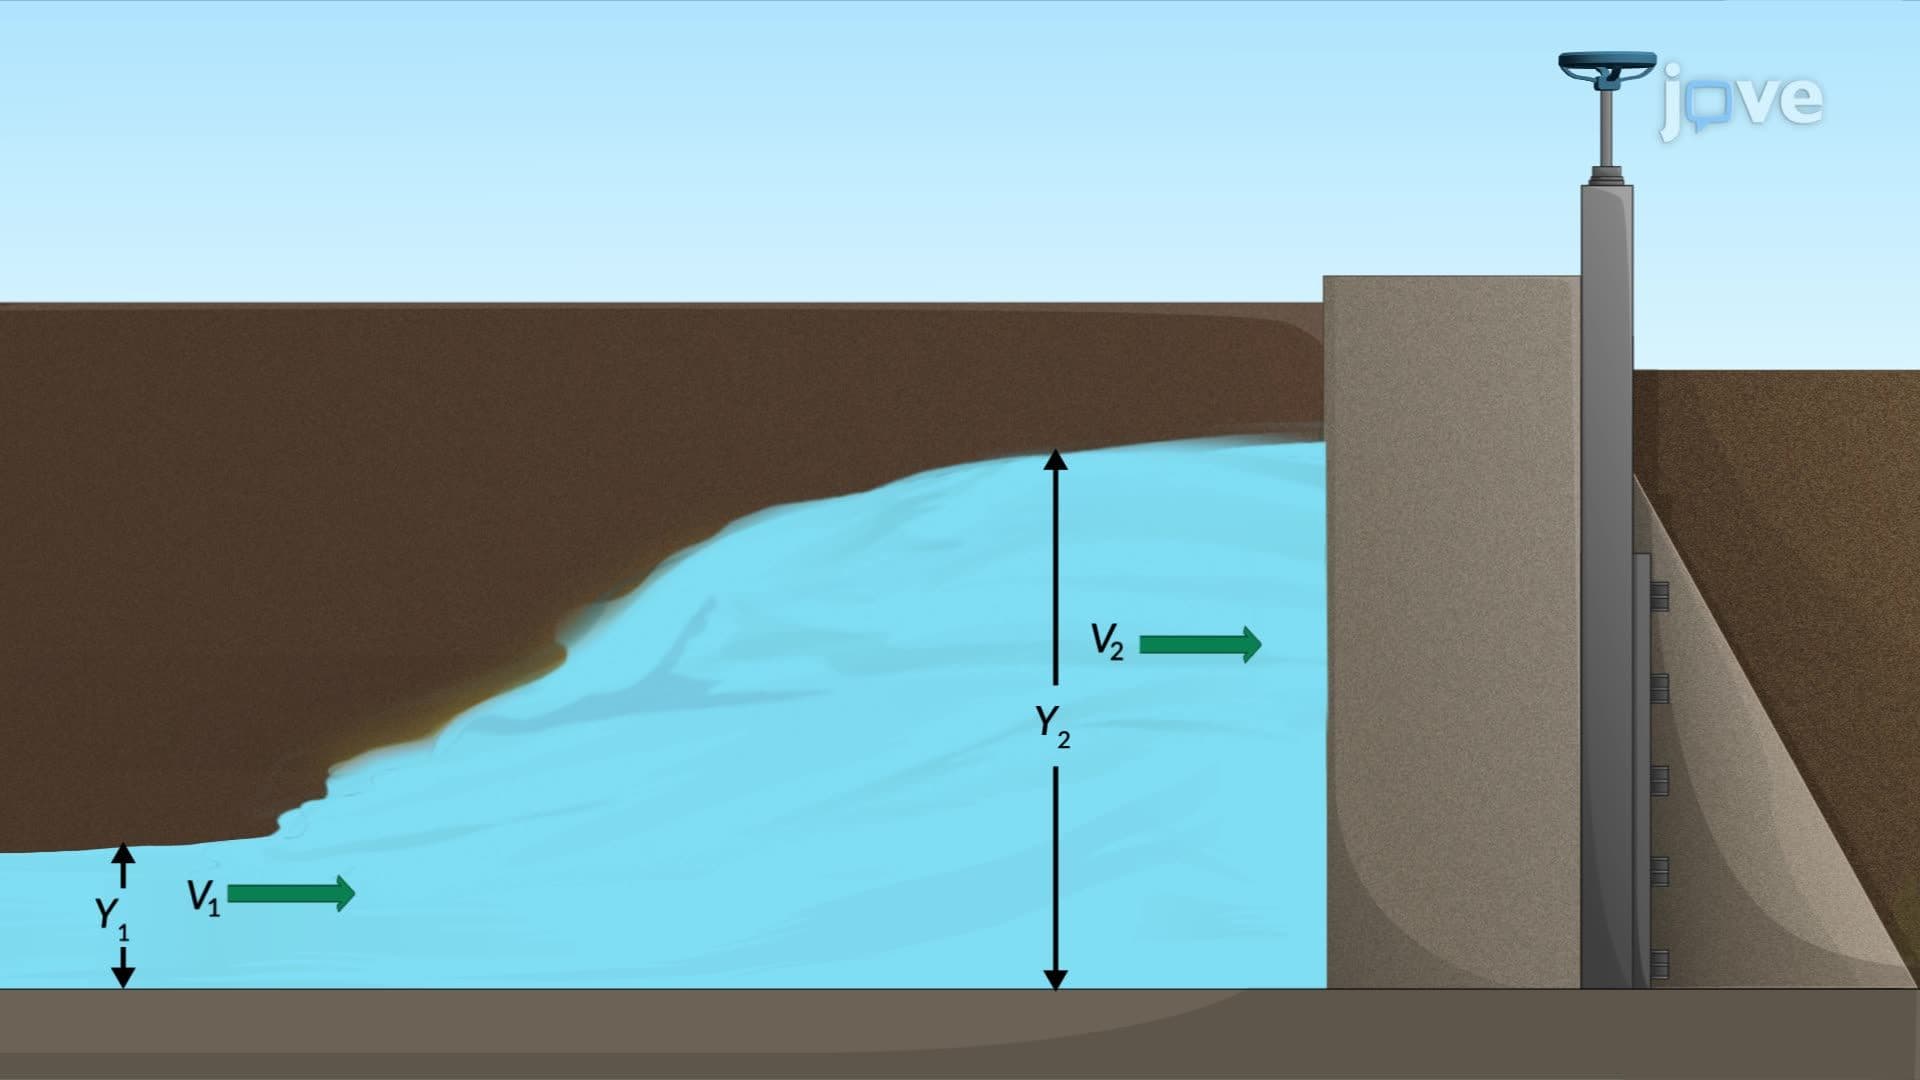
Hydraulic Jump: Problem Solving
 01:29
Hydraulic Jump
 02:01
Group Design
 01:16
Structural Joints: Synovial Joints