Observer-based hierarchical distributed optimal robust safety consensus control of multi-robot systems under actuator faults
Related Experiment Video
Updated: Jun 13, 2026
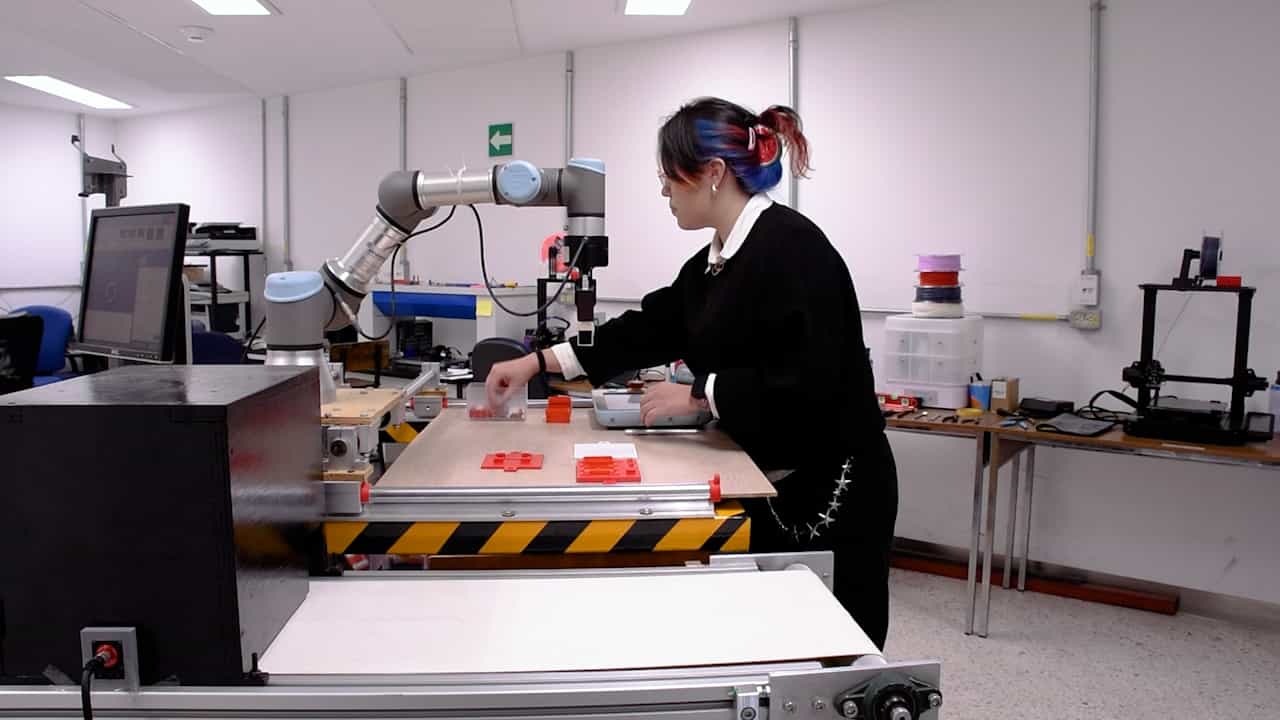
Simulation of a Scaled Assembly Process with Collaboration of a Robotic Arm and Monitoring through a Vision System for Quality Control
Published on: August 29, 2025
1China University of Mining and Technology, School of Information and Control Engineering, Xuzhou 221116, China.

Abstract:
This paper investigates the distributed optimal safety consensus problem for Multi-robot systems (MRSs) subject to channel noises, actuator faults, and external disturbances. To address this, we propose a novel hierarchical distributed robust safety control framework with a three-layer structure. In the upper layer, a resilient distributed optimal coordinator is designed to generate optimal references despite channel noises. Subsequently, the middle layer employs a fixed-time command filter to eliminate the impact of noises, extracting the continuously differentiable reference signals. In the lower layer, an observer-based robust safety control strategy is synthesized. Specifically, a fixed-time fault-disturbance observer (FxT-FDO) is implemented to rapidly estimate the lumped uncertainty. By incorporating the FxT-FDO output into the safety constraints, we develop a composite robust safety controller to guarantee the MRS achieve optimal safety consensus via solving the quadratic programming (QP). Simulation results demonstrate the superior robustness of the proposed control strategy.
Related Concept Videos
 01:10
Control Systems
At the heart...
 01:18
Hierarchy of Motor Control
 01:21
Distributed Loads: Problem Solving
 01:25
Distribution Reliability and Automation
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...