Related Experiment Video
Updated: Jun 17, 2026
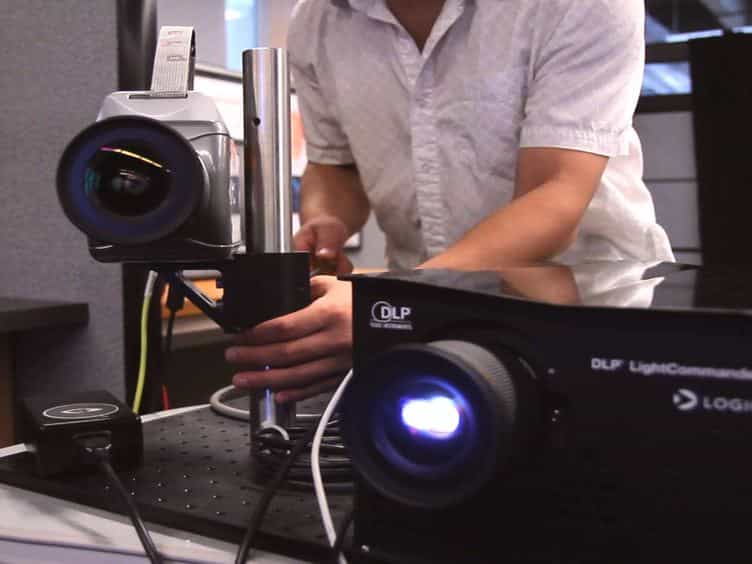
High-resolution, High-speed, Three-dimensional Video Imaging with Digital Fringe Projection Techniques
Published on: December 3, 2013
OmniPrior: A Multi-Prior-Guided Omnidirectional Representation of Dynamic Scenes in Overlapping Ultra-Wide

Abstract:
Omnidirectional capture of dynamic scenes facilitates the creation of immersive virtual reality assets and holistic scene understanding. Outward-facing multi-fisheye camera rigs offer an efficient solution for full-scene coverage, using fewer lenses than conventional pinhole arrays while enabling all-directional observation of complex, time-varying environments. By continuously recording scene evolution from every angle, these systems naturally enable a richer characterization of dynamic interactions. Despite these advantages, dynamic scene modeling in this setting remains underexplored. Existing methods, typically designed for fixed pinhole configurations or monocular setups, rely heavily on photometric cues and often neglect the strong geometric and semantic priors inherent in multi-fisheye omnidirectional data. To address this gap, we present OmniPrior, a Gaussian Splatting-based framework for outward-facing, multi-fisheye omnidirectional capture. Our approach incorporates metric-geometry-aware initialization with multi-prior guidance, introducing a dynamicness-aware Gaussian representation that encodes both object motion and subtle temporal variations. The resulting representations are physically consistent and temporally stable. Extensive experiments validate the effectiveness of our method in novel view synthesis across new viewpoints and timestamps. We demonstrate its utility in two representative applications derived from our learned representations: 6DoF rendering with flexible FoV and motion-freeze rendering.

Related Concept Videos
 01:15
Depth Perception and Spatial Vision
 02:18
Fischer Projections
 02:06
Newman Projections
The organic molecules rotate across the single bonds leading to numerous temporary three-dimensional structures of varying energy known as conformers.
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:26
Orthogonal Trajectories
 01:03
Inertial Frames of Reference