A Semi-Active Ankle Prosthesis With Automatic Transitions Between Passive and Active Modes
Related Experiment Video
Updated: Nov 6, 2026
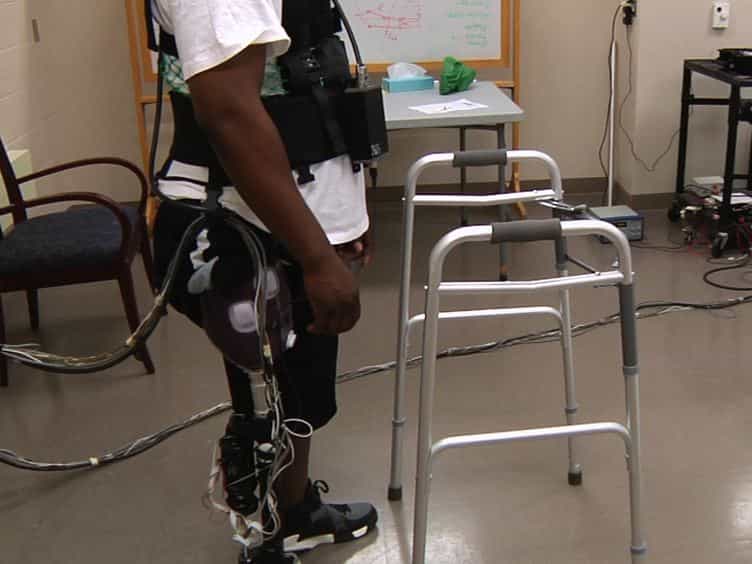
Engineering Platform and Experimental Protocol for Design and Evaluation of a Neurally-controlled Powered Transfemoral Prosthesis
Published on: July 22, 2014
Vishnu Aishwaryan Subra Mani1, Connelly Ray Buchanan1, Lukas Gabert1
1Department of Mechanical Engineering, Utah Robotics Center, The University of Utah, Salt Lake City, UT 84112 USA.

Abstract:
The most commonly prescribed ankle/foot prostheses are energy storage and return (ESR) devices, which have good performance in level ground walking, but have limited functionality in tasks requiring ankle mobility, such as stair ascent or descent. Powered prostheses aim to address this limitation by actively controlling the joint with actuators, but they tend to be heavier and taller and become unusable when the battery is depleted, hindering their clinical adoption. In this paper, we present a semi-active ankle prosthesis that integrates the energy storage and return characteristics of a passive prosthesis with the active joint articulation of a powered prosthesis. The proposed prosthesis combines a novel brake mechanism with a series elastic actuator to enable Passive and Active operation modes within a compact build height (141 mm) and lightweight (1.4 kg without batteries) form factor. Experimental validation with one lower-limb amputee demonstrates that the proposed prosthesis reproduces the gait dynamics of a passive prosthesis, independent of battery charge, in Passive mode, and matches the range of motion and actuation capabilities of a powered device during stair ascent and sit-to-stand transitions in Active mode. Automatic transitions between modes within a gait cycle allow for incline adaptation. Moreover, automatic transitions between gait cycles allow for seamless transitions between passive walking and active stair ambulation. This combination of functionalities has never been demonstrated in an ankle prosthesis and has the potential to improve mobility among the amputee population.