Related Experiment Video
Updated: Jun 12, 2026
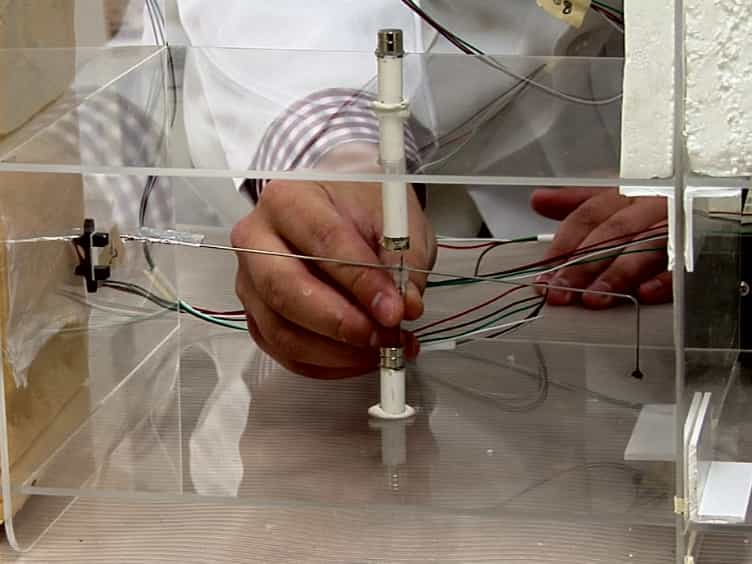
A Simple Flight Mill for the Study of Tethered Flight in Insects
Published on: December 10, 2015
Forward flight of swallowtail butterfly with simple flapping motion
Hiroto Tanaka1, Isao Shimoyama
1School of Engineering and Applied Sciences, Harvard University, 60 Oxford Street, Cambridge, MA 02138, USA.

Abstract:
Unlike other flying insects, the wing motion of swallowtail butterflies is basically limited to flapping because their fore wings partly overlap their hind wings, structurally restricting the feathering needed for active control of aerodynamic force. Hence, it can be hypothesized that the flight of swallowtail butterflies is realized with simple flapping, requiring little feedback control of the feathering angle. To verify this hypothesis, we fabricated an artificial butterfly mimicking the wing motion and wing shape of a swallowtail butterfly and analyzed its flights using images taken with a high-speed video camera. The results demonstrated that stable forward flight could be realized without active feathering or feedback control of the wing motion. During the flights, the artificial butterfly's body moved up and down passively in synchronization with the flapping, and the artificial butterfly followed an undulating flight trajectory like an actual swallowtail butterfly. Without feedback control of the wing motion, the body movement is directly affected by change of aerodynamic force due to the wing deformation; the degree of deformation was determined by the wing venation. Unlike a veinless wing, a mimic wing with veins generated a much higher lift coefficient during the flapping flight than in a steady flow due to the large body motion.
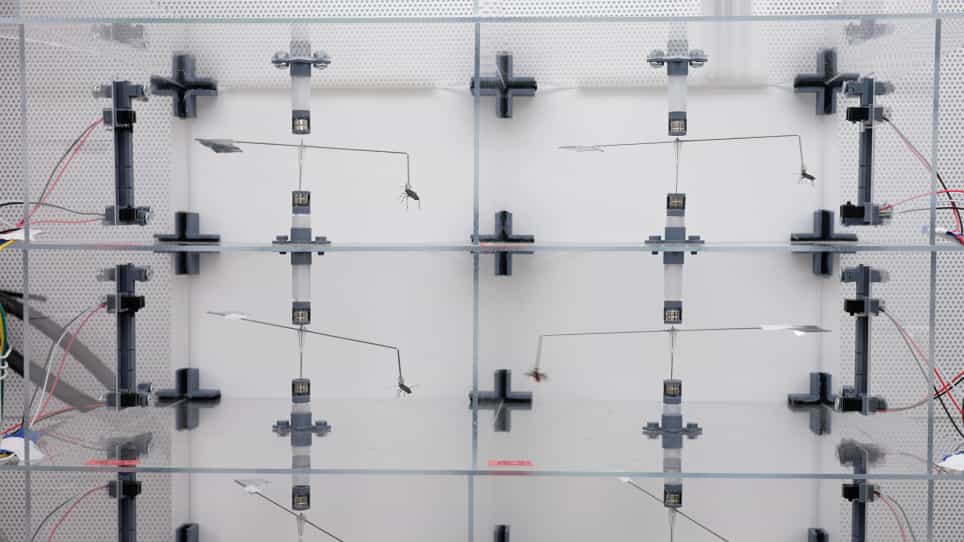
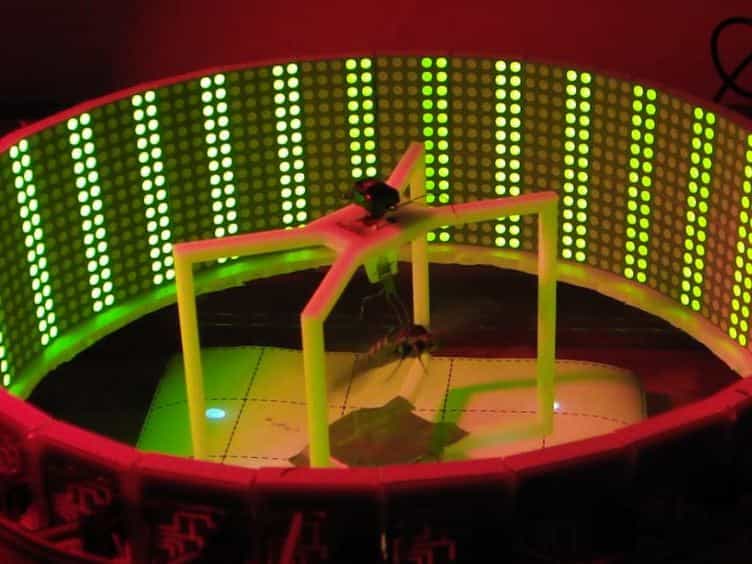
Related Concept Videos
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:54
Convergent Evolution
 01:05
Mechanism of Ciliary Motion
The cilia are made up of microtubules in a 9+2 arrangement, with nine microtubule doublet ring bundles, surrounding a pair of central singlet microtubule bundles. The doublet microtubule bundles are...
01:05Mechanism of Ciliary Motion
The cilia are made up of microtubules in a 9+2 arrangement, with nine microtubule doublet ring bundles, surrounding a pair of central singlet microtubule bundles. The doublet microtubule bundles are...
 01:25
Deglutition
Swallowing can be divided into three stages: the voluntary phase, the pharyngeal phase, and the esophageal phase. Although the...
 00:53
Migration