Robust hopping based on virtual pendulum posture control
Related Experiment Video
Updated: May 10, 2026
Experimental Methods to Study Human Postural Control
Published on: September 11, 2019
Maziar A Sharbafi1, Christophe Maufroy, Majid Nili Ahmadabadi
1School of ECE, Control and Intelligent Processing Center of Excellence CIPCE, College of Engineering, University of Tehran, Tehran, Iran. sharbafi@ut.ac.ir

Abstract:
A new control approach to achieve robust hopping against perturbations in the sagittal plane is presented in this paper. In perturbed hopping, vertical body alignment has a significant role for stability. Our approach is based on the virtual pendulum concept, recently proposed, based on experimental findings in human and animal locomotion. In this concept, the ground reaction forces are pointed to a virtual support point, named virtual pivot point (VPP), during motion. This concept is employed in designing the controller to balance the trunk during the stance phase. New strategies for leg angle and length adjustment besides the virtual pendulum posture control are proposed as a unified controller. This method is investigated by applying it on an extension of the spring loaded inverted pendulum (SLIP) model. Trunk, leg mass and damping are added to the SLIP model in order to make the model more realistic. The stability is analyzed by Poincaré map analysis. With fixed VPP position, stability, disturbance rejection and moderate robustness are achieved, but with a low convergence speed. To improve the performance and attain higher robustness, an event-based control of the VPP position is introduced, using feedback of the system states at apexes. Discrete linear quartic regulator is used to design the feedback controller. Considerable enhancements with respect to stability, convergence speed and robustness against perturbations and parameter changes are achieved.
More Related Videos
 11:06
A Human-machine-interface Integrating Low-cost Sensors with a Neuromuscular Electrical Stimulation System for Post-stroke Balance Rehabilitation
Published on: April 12, 2016
 06:58
A Structured Rehabilitation Protocol for Improved Multifunctional Prosthetic Control: A Case Study
Published on: November 6, 2015
Related Concept Videos
 01:09
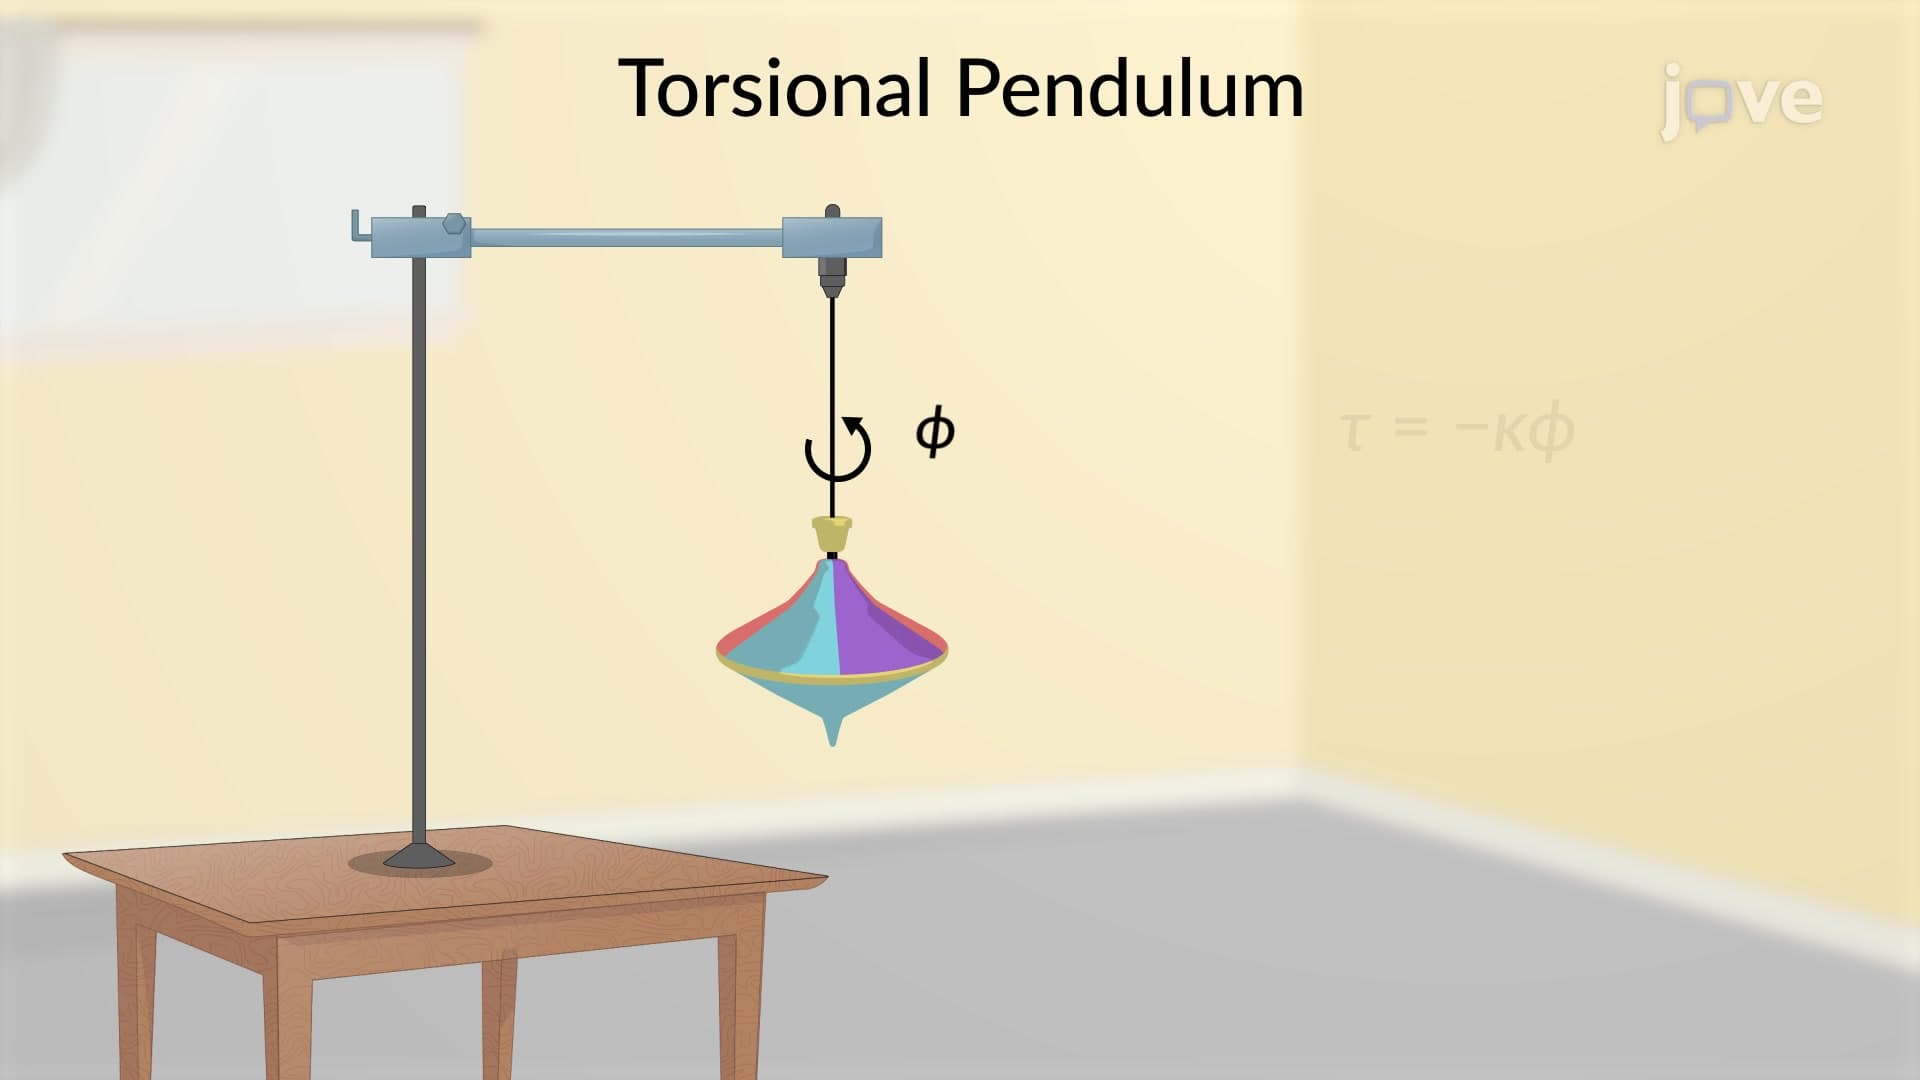
Torsional Pendulum
As long as the rigid body's angular displacement is small, its oscillation can be modeled as a linear angular oscillation. The amplitude of the oscillation is an angle. The role of mass is played by the...
 01:06
Physical Pendulum
When dealing with complicated systems, the mass moment of inertia is an important parameter, as it describes the mass...
 01:10
Simple Pendulum
The period of a simple pendulum depends on two factors: its length and the acceleration due to gravity. The period is completely independent of any other factors, such as mass or maximum displacement. For small displacements, a pendulum is...
 01:21
Simple Harmonic Motion
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:21
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?