Related Experiment Video
Updated: Jan 19, 2026


WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
Observer-based H∞ control design for singular switching semi-Markovian jump systems with random sensor delays
Zhengtian Wu1, Bo Li2, Cunchen Gao3
1School of Electronic and Information Engineering, Suzhou University of Science and Technology, Suzhou, China; Suzhou Institute of Smart City, Suzhou University of Science and Technology, Suzhou, China.

Abstract:
This paper studies the problem of H∞ control design for a class of singular switching semi-Markovian jump systems, in which the transition rates of jumping process are uncertain and the output measurements suffer from random sensor delays. Firstly, a Luenberger observer is designed to estimate the system state components, based on which an error dynamic is obtained. Then, stochastic stability analysis for the overall closed-loop system is given based on the upper and lower bounds of transition rates. Further, the state feedback controller gain matrices are given by solving a set of sufficient conditions in terms of strict linear matrix inequalities (LMIs), which also guarantee the closed-loop system to be stochastically stabilizable and has a prescribed H∞ performance index γ. Finally, a numerical example is provided to verify the effectiveness of the obtained result.
Related Concept Videos
 01:24
BIBO stability of continuous and discrete -time systems
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:22
Multi-input and Multi-variable systems
In the absence of...
 01:31
Classification of Systems-II
 01:21
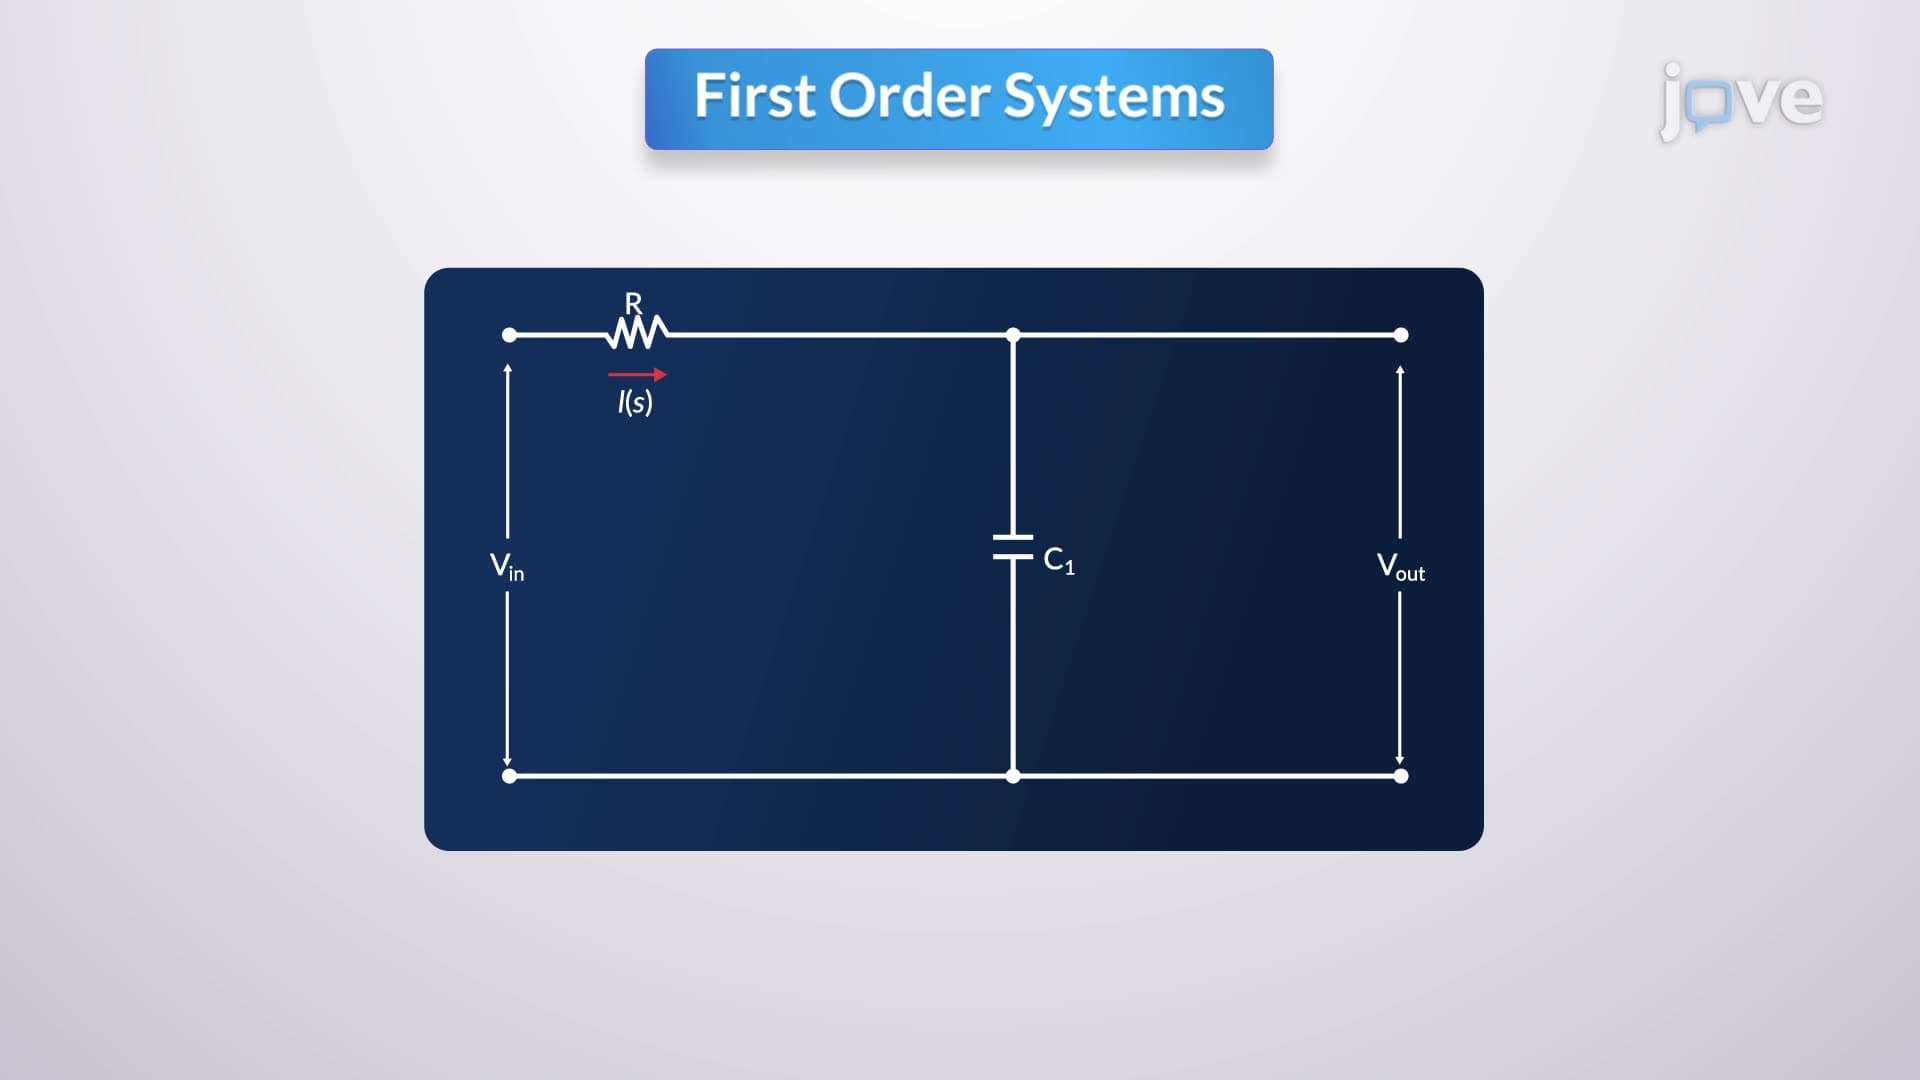
First Order Systems
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...