

Event-triggered observer-based H∞ sliding mode control of nonlinear systems
Zhengtian Wu1, Baoping Jiang1, Mingyang Xie2
1School of Electronic and Information Engineering, Suzhou University of Science and Technology, Suzhou, China.

Abstract:
The problem of sliding mode control for a class of Takagi-Sugeno fuzzy model-based nonlinear one-sided Lipschitz systems is investigated in the paper. Due to the state components are not available, a state observer is designed based on an event-triggering mechanism. Meanwhile, the output measurements transmitted through the communication channels suffer from signal delays. Based on the estimated state, an integral sliding surface is proposed. Then, the sliding mode dynamics is obtained by virtue of equivalent control principle. Further, by constructing appropriate sliding mode controller, the finite-time reachability of predefined sliding surface is surely guaranteed. Moreover, the stability with an H∞ performance analysis of sliding mode dynamics is undertaken via Lyapunov function theory and the criteria are established in terms of LMI. Finally, numerical examples are provided to demonstrate the effectiveness of the proposed method.
More Related Videos
 09:01
Gain-compensation Methodology for a Sinusoidal Scan of a Galvanometer Mirror in Proportional-Integral-Differential Control Using Pre-emphasis Techniques
Published on: April 4, 2017
 10:51
An Experimental Platform to Study the Closed-loop Performance of Brain-machine Interfaces
Published on: March 10, 2011
Related Concept Videos
 01:18
Second Order systems II
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
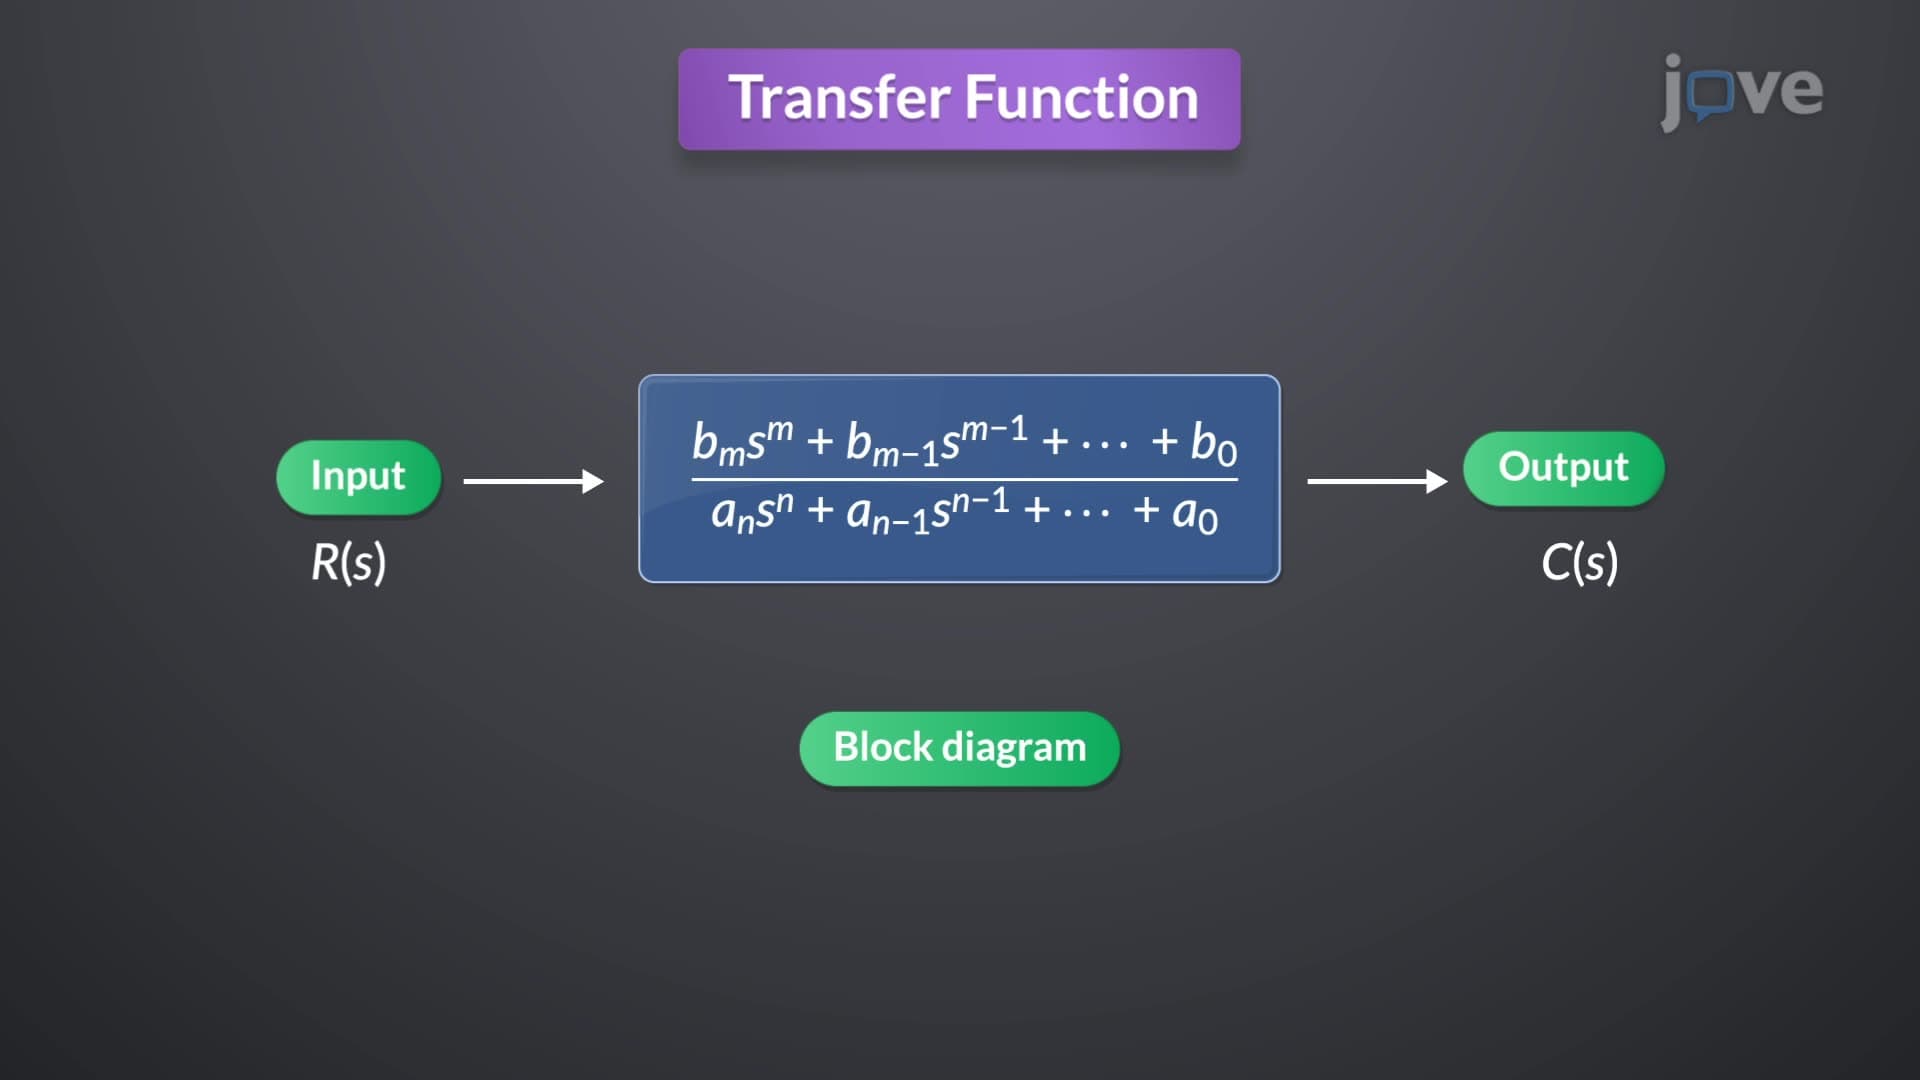 01:21
Transfer Function in Control Systems
To derive the transfer function, consider a general nth-order linear time-invariant...
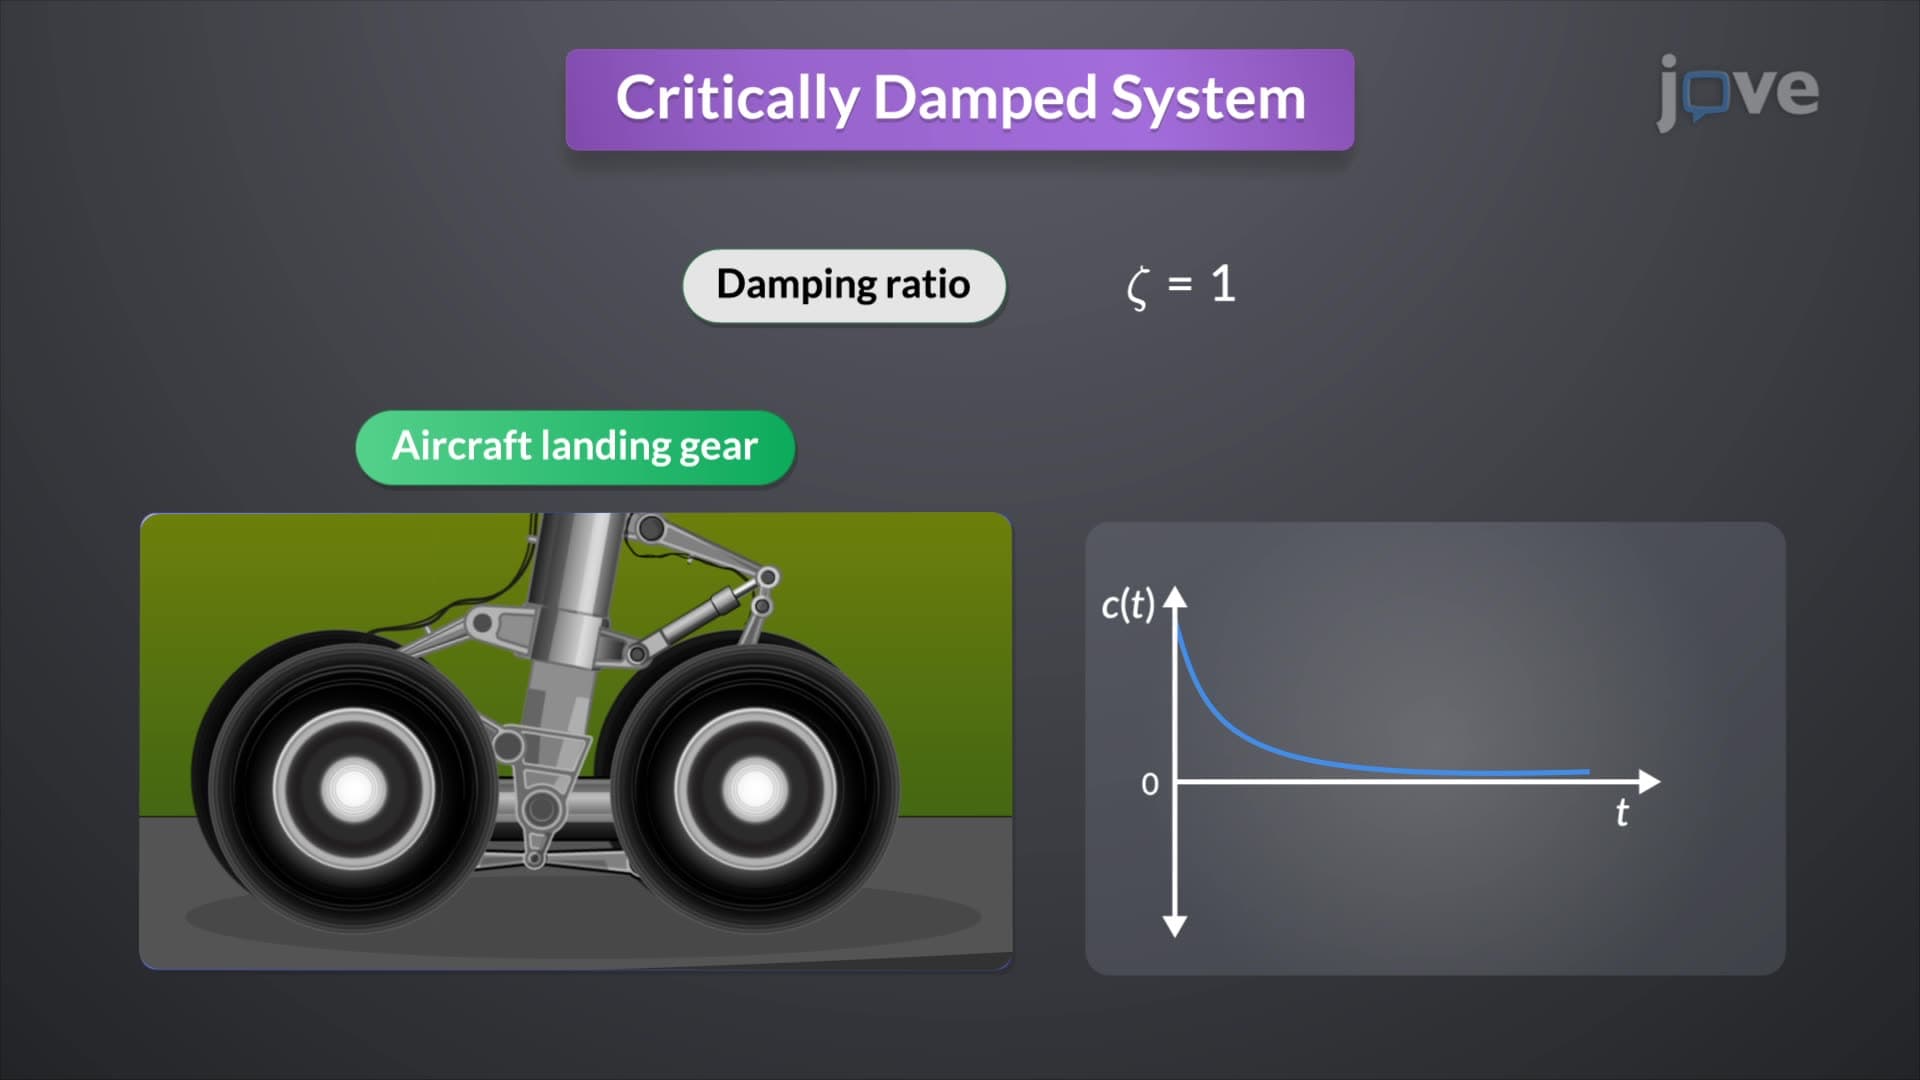 01:20
Second Order systems I
By reinterpreting the system, one can derive the closed-loop transfer function, which...