Related Experiment Video
Updated: Nov 8, 2025

An Experimental Platform to Study the Closed-loop Performance of Brain-machine Interfaces
Published on: March 10, 2011
Non-singular terminal sliding-mode control for a manipulator robot using a barrier Lyapunov function
David Cruz-Ortiz1, Isaac Chairez2, Alexander Poznyak3
1Department of Bioprocesses, UPIBI - Instituto Politécnico Nacional, Mexico City, Mexico; Department of Automatic Control, CINVESTAV-IPN, Av. IPN 2508, San Pedro Zacatenco, 07360, Mexico City, Mexico; Tecnológico Nacional de México/TES Ixtapaluca, State of Mexico, Mexico.

Abstract:
This study introduces a design of robust finite-time controllers that aims to solve the trajectory tracking of robot manipulators with full-state constraints. The control design is based on the construction of a distributed state constraint non-singular terminal sliding mode (CNTSM). The CNTSM design includes the gain self-adapting tuning method, which can ensure finite-time convergence to the sliding surface aside from the states to its corresponding reference trajectories. The implementation of the time-varying gain ensures the fulfillment of the accurate tracking for the references while the position and velocity constraints are satisfied permanently. A barrier Lyapunov function is proposed to develop the finite-time stability analysis of the designed controllers. The CNTSM realization uses the tracking error as well as its estimated derivative, which is calculated using a variant of adaptive super-twisting algorithm operating as robust differentiator. The proposed CNTSM is numerically evaluated on a two-link RM with uncertain inertia and Coriolis matrices. Simulation and experimental results evidence the efficiency of the CNTSM controller demonstrating a better tracking performance while the full-state constraints are satisfied in counterpart with the classical non-singular terminal sliding mode which is not able to keep such restrictions.


Related Concept Videos
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:19
Root-Locus Method
This system can be represented by a block...
 01:11
Design Example: Forces in Sluice Gate
Key variables in...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
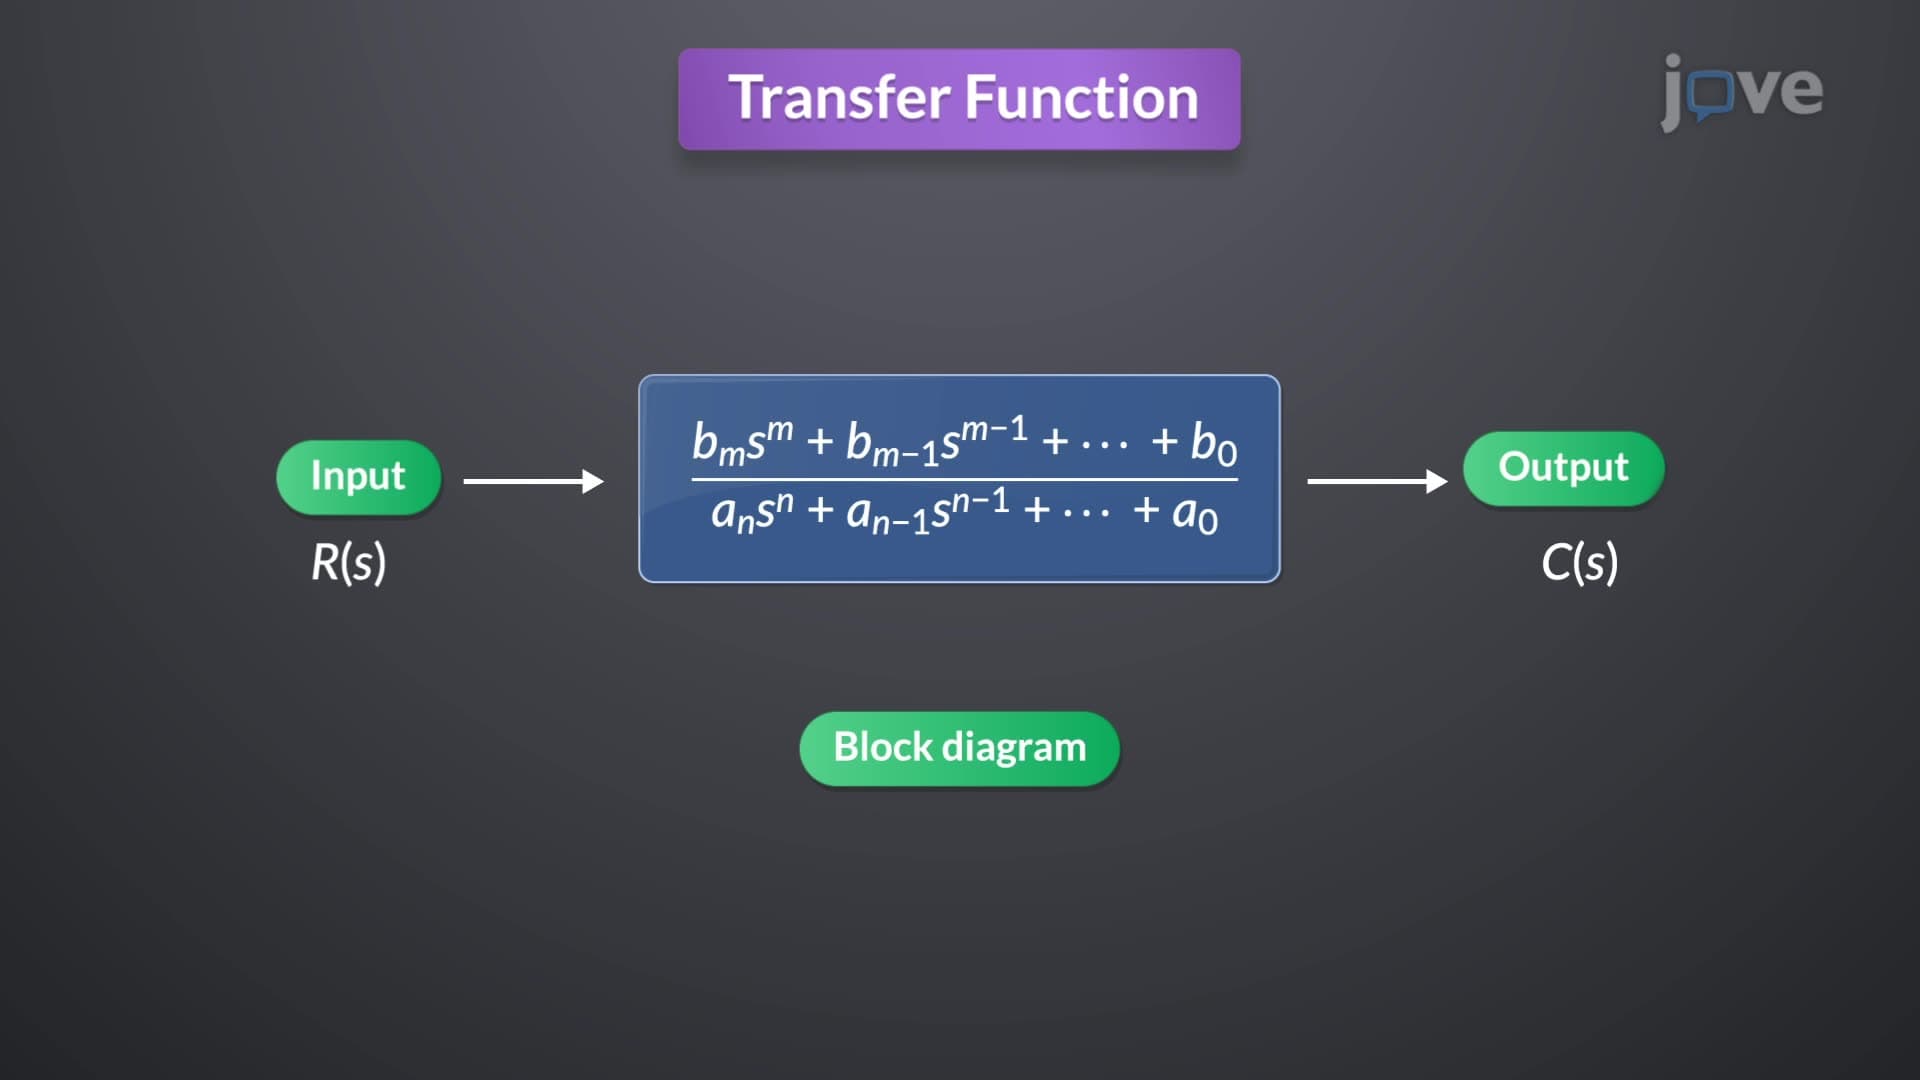 01:21
Transfer Function in Control Systems
To derive the transfer function, consider a general nth-order linear time-invariant...