Related Experiment Video
Updated: Oct 2, 2025
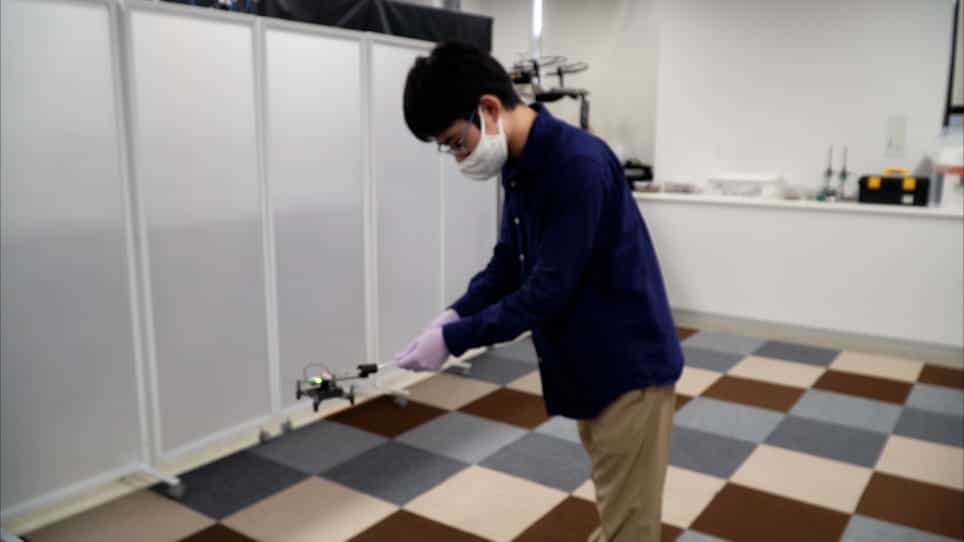

Electroantennography-based Bio-hybrid Odor-detecting Drone using Silkmoth Antennae for Odor Source Localization
Published on: August 27, 2021
AlphaPilot: autonomous drone racing
Philipp Foehn1, Dario Brescianini1, Elia Kaufmann1
1Dep. of Informatics, Dep. of Neuroinformatics, University of Zurich and ETH, Zurich, Switzerland.

Abstract:
This paper presents a novel system for autonomous, vision-based drone racing combining learned data abstraction, nonlinear filtering, and time-optimal trajectory planning. The system has successfully been deployed at the first autonomous drone racing world championship: the 2019 AlphaPilot Challenge. Contrary to traditional drone racing systems, which only detect the next gate, our approach makes use of any visible gate and takes advantage of multiple, simultaneous gate detections to compensate for drift in the state estimate and build a global map of the gates. The global map and drift-compensated state estimate allow the drone to navigate through the race course even when the gates are not immediately visible and further enable to plan a near time-optimal path through the race course in real time based on approximate drone dynamics. The proposed system has been demonstrated to successfully guide the drone through tight race courses reaching speeds up to and ranked second at the 2019 AlphaPilot Challenge.
More Related Videos
Related Concept Videos
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:24
PI Controller: Design
 01:19
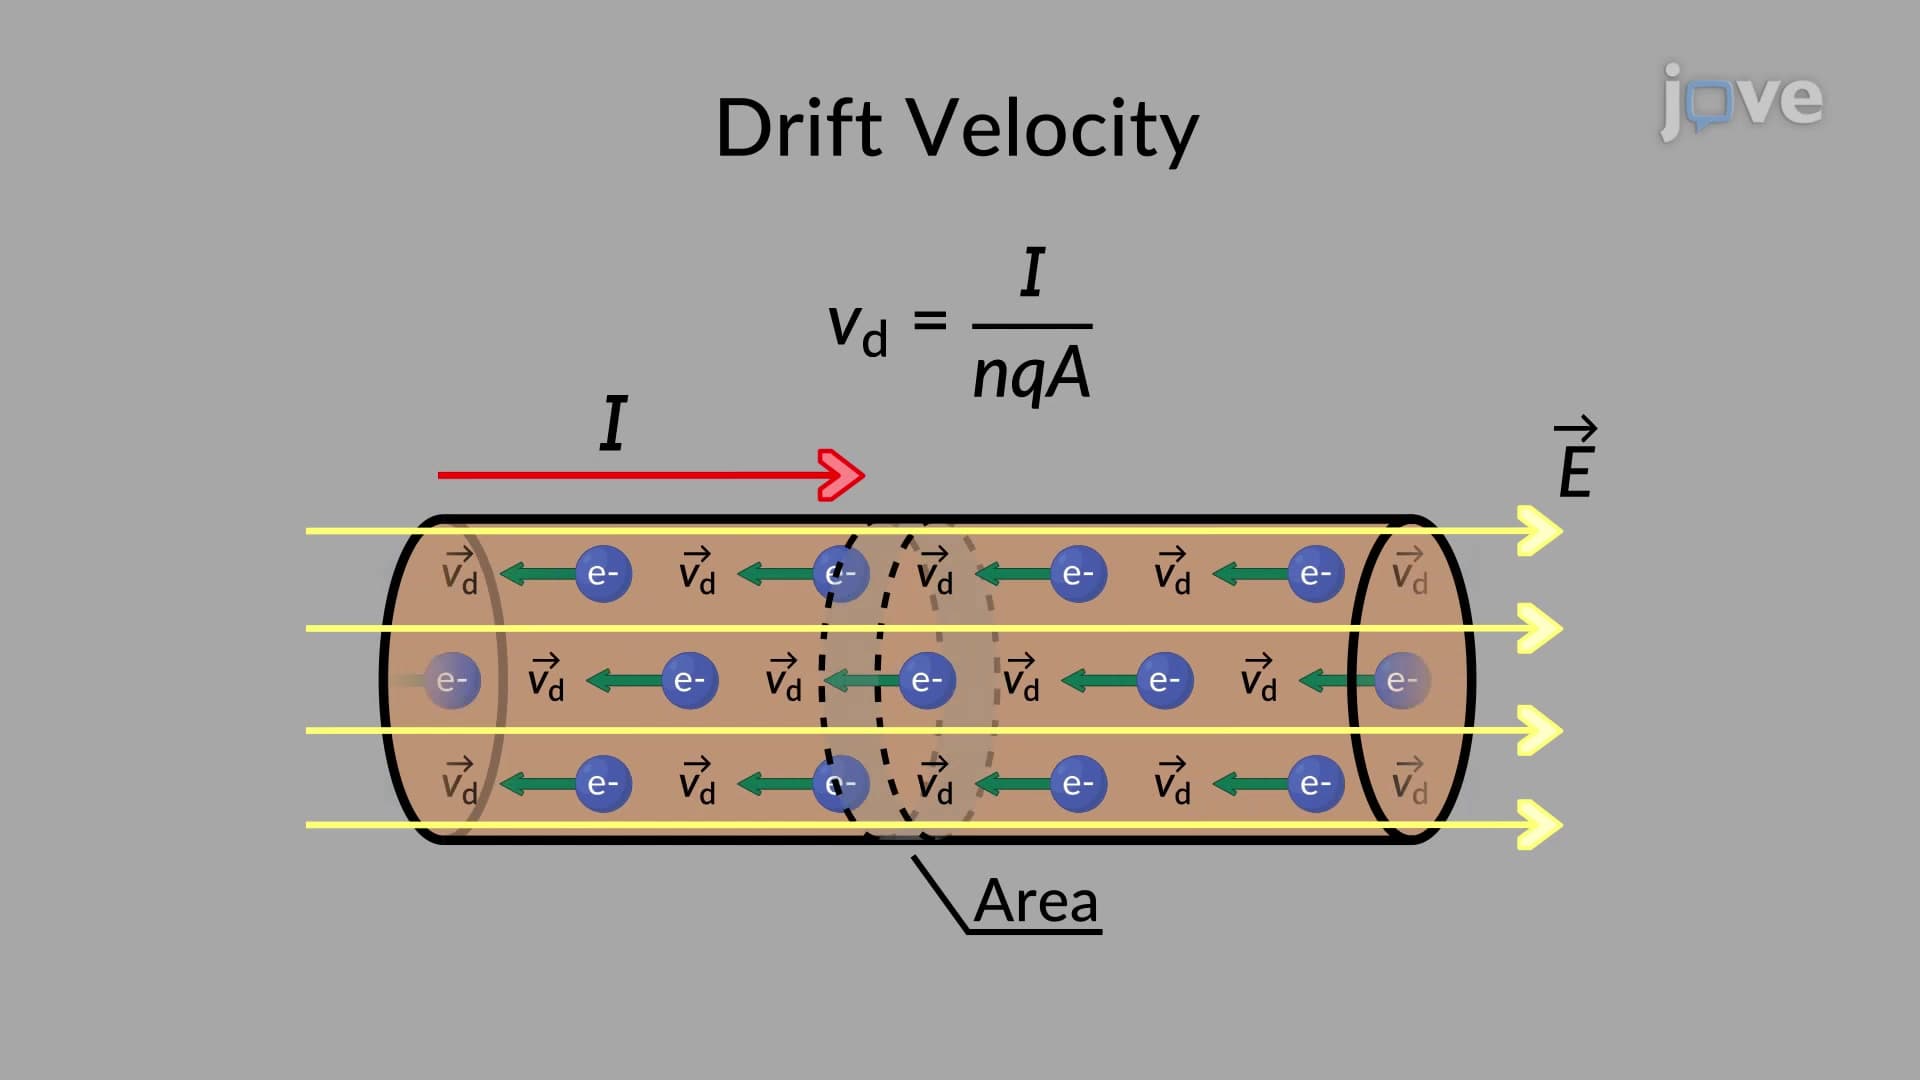
Drift Velocity
 01:21
Pilot and Numeric Relaying
 01:13
Rocket Propulsion in Empty Space - I
 01:12
Rocket Propulsion In Empty Space - II