Related Experiment Video
Updated: Sep 3, 2025


Manufacturing, Control, and Performance Evaluation of a Gecko-Inspired Soft Robot
Published on: June 10, 2020
Path Planning for Wheeled Mobile Robot in Partially Known Uneven Terrain
Bo Zhang1,2, Guobin Li1,2, Qixin Zheng1,2
1College of Mechatronics and Control Engineering, Shenzhen University, Shenzhen 518060, China.

Abstract:
Path planning for wheeled mobile robots on partially known uneven terrain is an open challenge since robot motions can be strongly influenced by terrain with incomplete environmental information such as locally detected obstacles and impassable terrain areas. This paper proposes a hierarchical path planning approach for a wheeled robot to move in a partially known uneven terrain. We first model the partially known uneven terrain environment respecting the terrain features, including the slope, step, and unevenness. Second, facilitated by the terrain model, we use A⋆ algorithm to plan a global path for the robot based on the partially known map. Finally, the Q-learning method is employed for local path planning to avoid locally detected obstacles in close range as well as impassable terrain areas when the robot tracks the global path. The simulation and experimental results show that the designed path planning approach provides satisfying paths that avoid locally detected obstacles and impassable areas in a partially known uneven terrain compared with the classical A⋆ algorithm and the artificial potential field method.


Related Concept Videos
 01:17
Rolling Resistance: Problem Solving
 01:16
Equation of Motion: General Plane motion - Problem Solving
The friction between the roller and the ground is characterized by two coefficients. The static friction coefficient is 0.15, while the kinetic friction coefficient is 0.1. These values are crucial in understanding the interaction between...
 01:19
Design Example: Maintaining Level of an Embankment
 01:22
Planar Rigid-Body Motion
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...
 01:09
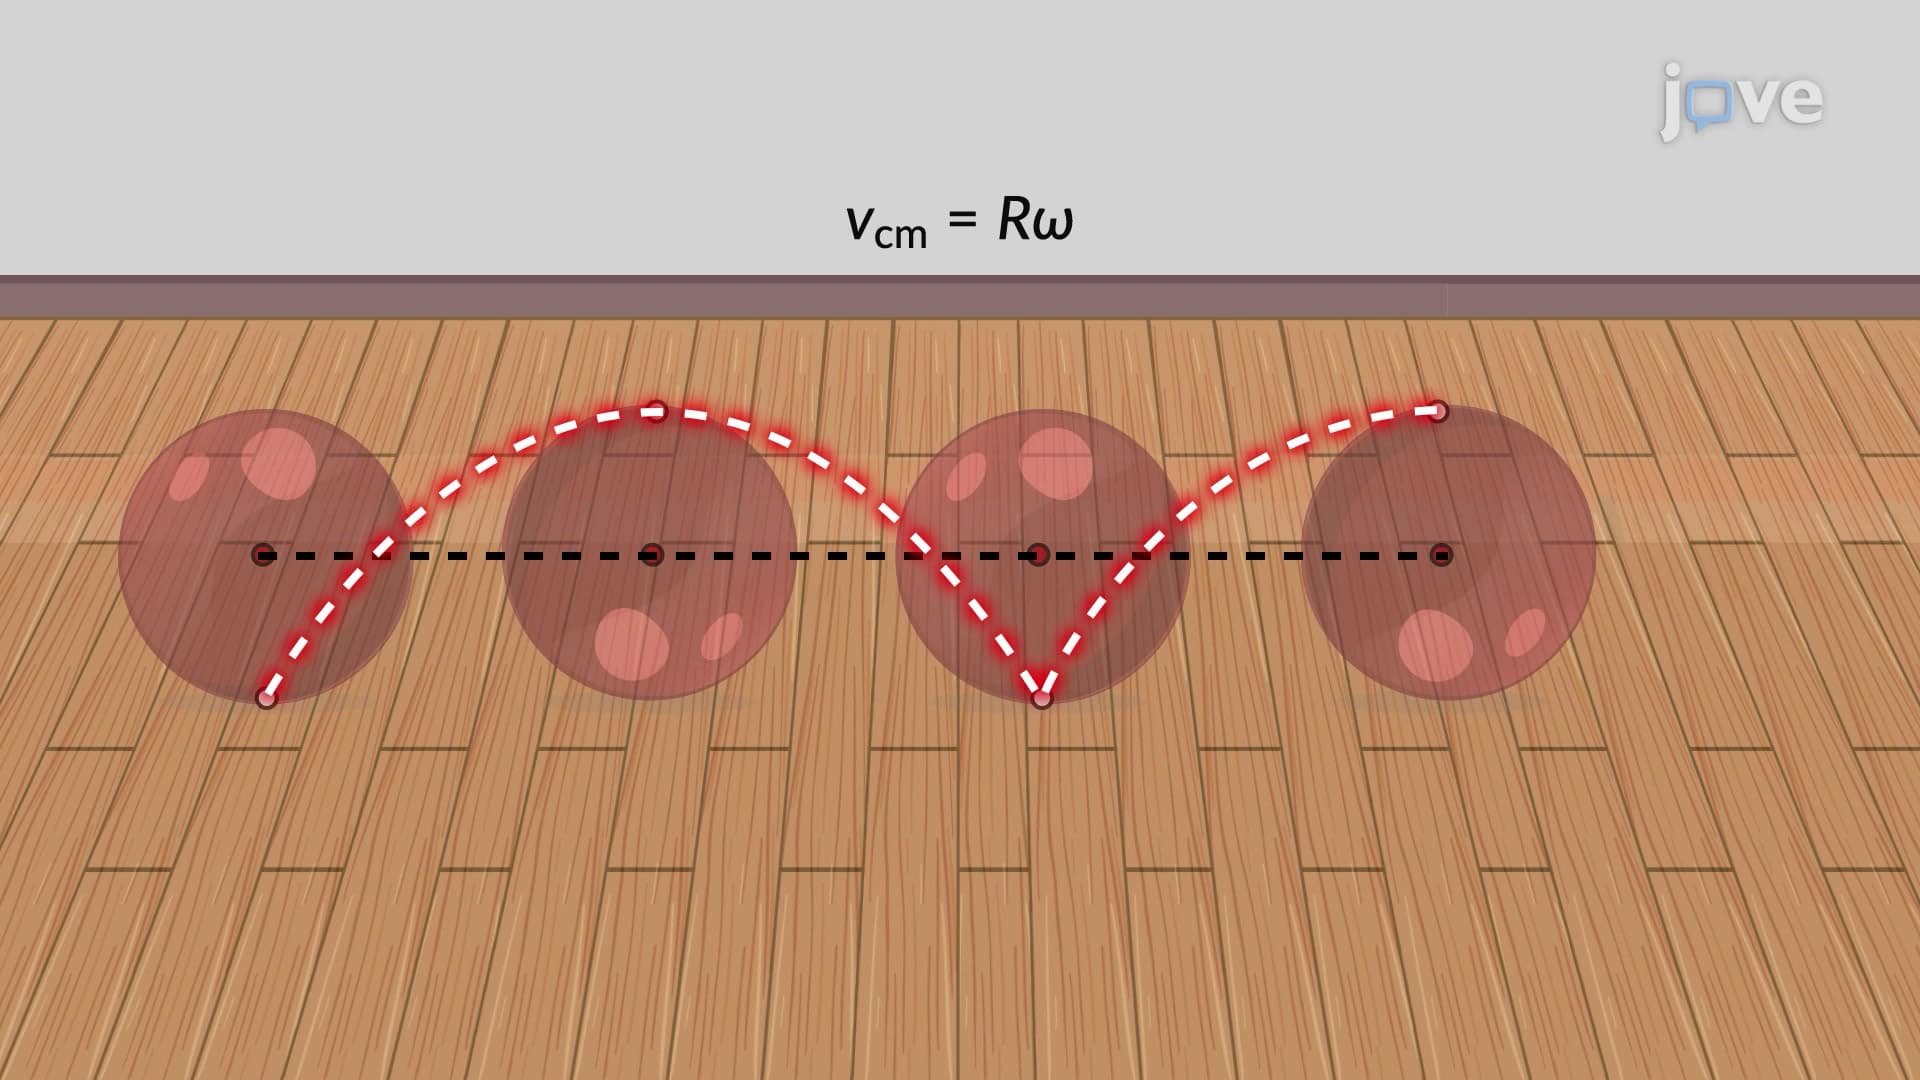
Rolling Without Slipping
 01:21
Rolling Resistance
For instance, imagine a hard cylinder rolling on a comparatively soft surface. The cylinder's weight compresses the surface beneath it. As the cylinder moves, the material in front of it slows down...